Related Experiment Videos
State-Rate Bumpless Transfer Control for Quadrotor Systems Subject to Incomplete Statistics Information

Abstract:
This article deals with the state-rate bumpless transfer control problem where the quadrotor systems suffer the synthetic effects produced by incomplete information of statistics, which includes hidden modes and a partially known semi-Markov kernel (S-MK). Upon modeling the stochastic uncertainties by a hidden semi-Markov chain (HS-MC), the inevitable bumps of quadrotor states caused by stochastic switching dynamics are taken into account. Provided that the state-rate bumpless transfer performance is considered in the design of control laws, an observed-mode-dependent control scheme is presented to weaken the effect that results from mode mismatch while it restrains the state-rate bumps. Motivated by the statistical properties of sojourn time and mode transitions, sojourn-time probability mass functions (PMFs) and transition probabilities (TPs) of an embedded Markov chain (EMC) are regarded as partially unknown in view of the difficulty of acquiring these jump parameters in reality, which makes the class of systems under consideration more general. Sufficient conditions are established ensuring that the dynamic system is error-mean square stable; the existence criterion of the bumpless-transfer controller is further developed via bump-limitation constraints. The developed strategy is examined, and the benefits of introducing the bumpless constraints are also shown in a numerical validation.
Related Concept Videos
 01:30
Vector Functions and Motion: Problem Solving
 01:29
Application of Linearization and Approximation
 01:24
Absolute Motion Analysis- General Plane Motion
As the drone's propellers rotate, an upward force is generated that counteracts the force of gravity, enabling the drone to lift off from the ground. This initial movement of the drone is along a straight path, representing a form of translational motion. In this phase, every point on the drone...
 01:22
Multi-input and Multi-variable systems
In the absence of...
 01:22
Controller Configurations
Control-system compensation involves various configurations, most commonly series or cascade compensation, in which the controller aligns...
 01:21
State Space to Transfer Function
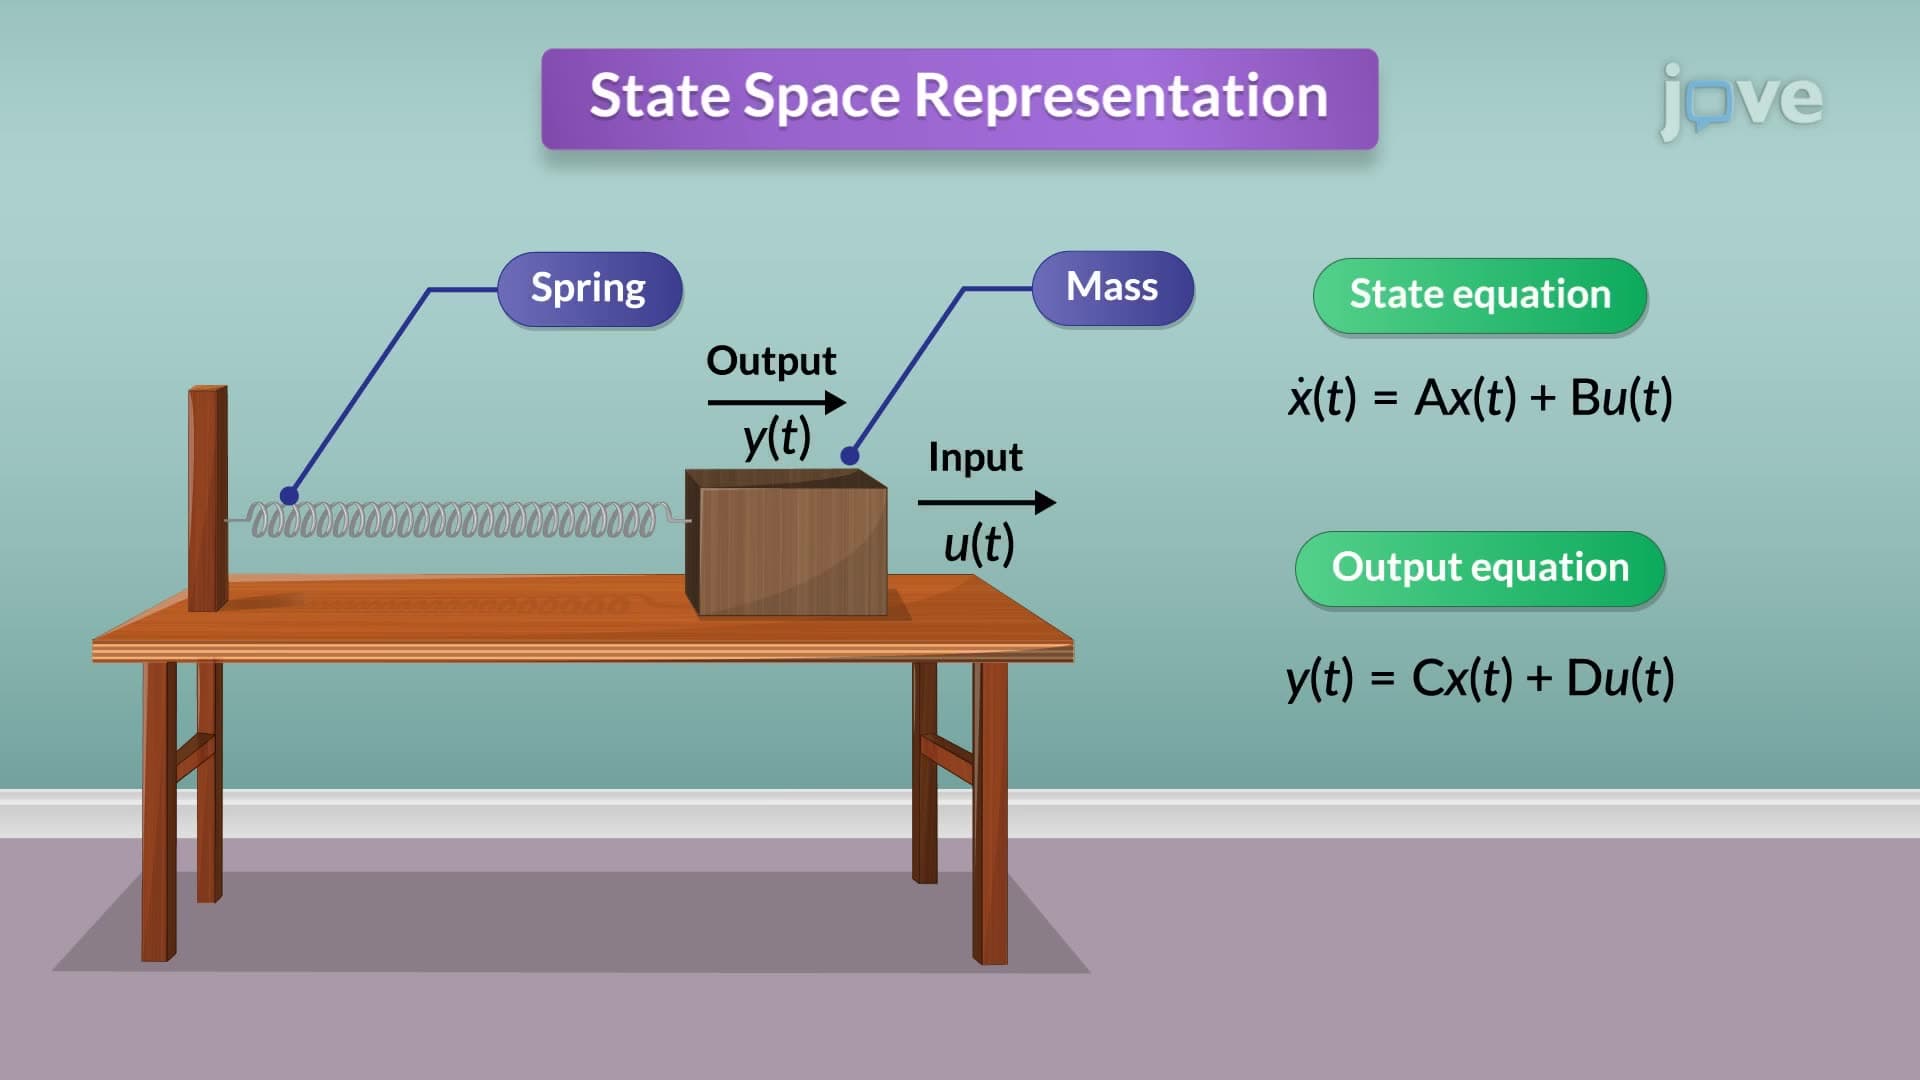
The transformation process begins with the state-space representation, characterized by the state equation and the output equation. These equations are typically represented as: