Related Experiment Video
Updated: May 8, 2026
Movement Retraining using Real-time Feedback of Performance
Published on: January 17, 2013
Monotonicity and error type differentiability in performance measures for target detection and tracking in video
1Advanced Technology Labs Israel, Microsoft Research, Microsoft R&D Center, Matam Park, Haifa, Israel. idol@microsoft.com

Abstract:
There exists an abundance of systems and algorithms for multiple target detection and tracking in video, and many measures for evaluating the quality of their output have been proposed. The contribution of this paper lies in the following: first, it argues that such performance measures should have two fundamental properties--monotonicity and error type differentiability; second, it shows that the recently proposed measures do not have either of these properties and are, thus, less usable; third, it composes a set of simple measures, partly built on common practice, that does have these properties. The informativeness of the proposed set of performance measures is demonstrated through their application on face detection and tracking results.
Related Concept Videos
 01:30
Derivatives of Inverse Trigonometric Functions
 01:12
Types of Errors: Detection and Minimization
Absolute error in a measurement is the numerical difference from the true or central value. Relative error is the ratio between absolute error and the true or central value, expressed as a percentage.
Errors can be classified by source, magnitude, and sign. There are three types of errors: systematic, random, and gross.
Systematic or...
 03:37
Uncertainty in Measurement: Accuracy and Precision
 01:05
Difference from Background: Limit of Detection
The LOD indicates the presence or absence...
 01:26
Feedback control systems
Linear feedback systems are theoretical models that simplify analysis and design. These systems operate under the principle that their output is directly proportional to their input within certain ranges. For instance, an amplifier in a control system behaves linearly as long as the input signal remains within a specific range. However, most physical systems exhibit inherent nonlinearity...
 01:28
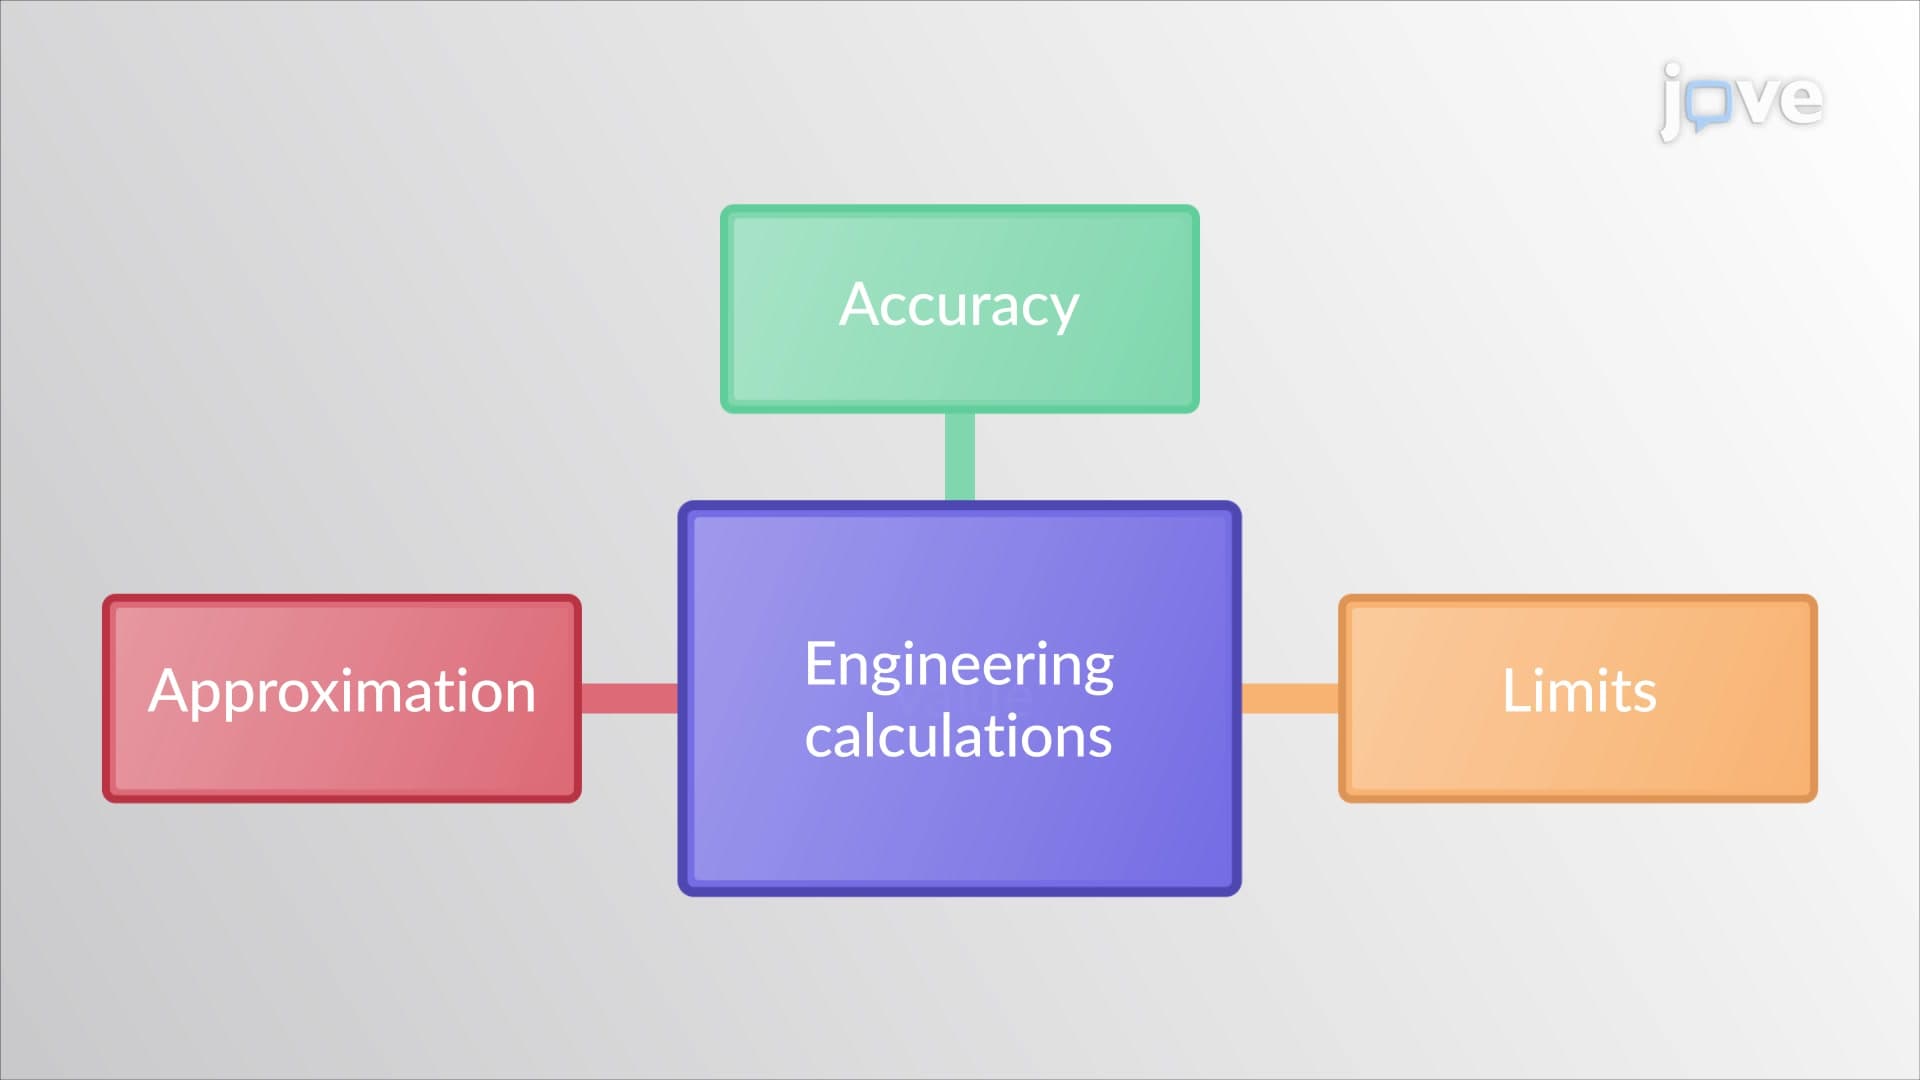
Accuracy, limits, and approximation
Accuracy is defined as the closeness of the measured value to the true or actual value. In engineering mechanics, repeated measurements are taken during theoretical or experimental analyses to ensure that the result is precise and accurate.
The accuracy of any solution is based on the...