Related Experiment Video
Updated: Oct 26, 2026
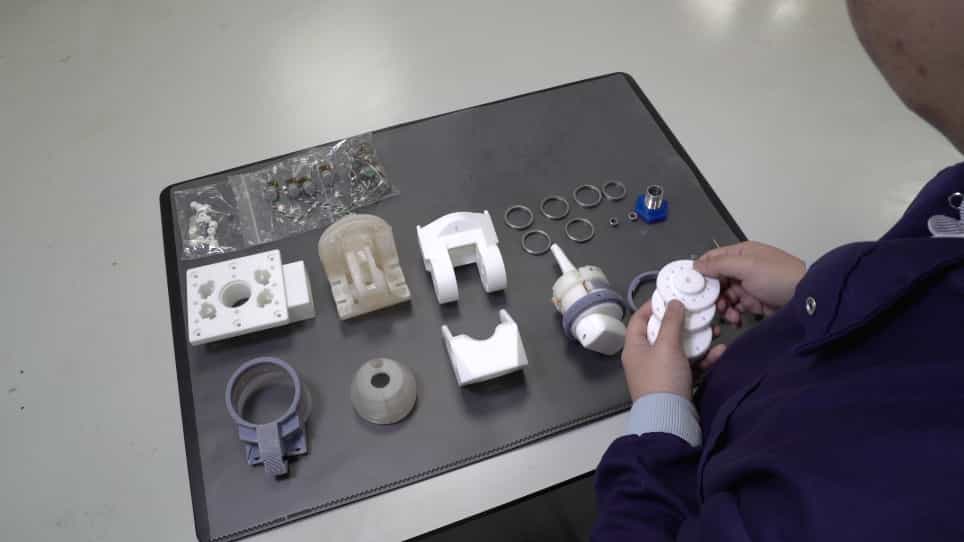
Design and Implementation of a Bespoke Robotic Manipulator for Extra-corporeal Ultrasound
Published on: January 7, 2019
Design, Development, and Validation of a Self-Aligning Mechanism for High-Torque Powered Knee Exoskeletons
Sergei V Sarkisian1, Marshall K Ishmael1, Grace R Hunt1
1Department of Mechanical Engineering, University of Utah, Salt Lake City, UT 84112 USA, and also with the Utah Robotics Center, University of Utah, Salt Lake City, UT 84112 USA.

Abstract:
Powered knee exoskeletons aim to assist individuals with lower limb impairments by providing power and torque at the joint level. However, if the anatomical and exoskeleton joints are not perfectly aligned, the exoskeleton assistance may result in spurious forces and torques transferred to the user's limb. These spurious forces and torques can then generate undesired loads on the user's joint and shear stress on the user's skin, causing pain and ultimately undermining the exoskeleton assistance. To address this issue, we propose a novel powered knee exoskeleton with a self-aligning mechanism using a prismatic-revolute-revolute (PRR) configuration. The proposed self-aligning mechanism weighs 190 g (i.e., 5.3% of the total exoskeleton weight) and can transmit up to 120 Nm of torque at the knee joint (i.e., biological peak torque for a 50th percentile male climbing stairs). Our experiments show that during assisted sit-to-stand transfers the peaks of the spurious torques and forces are below 0.5 Nm and 5 N, respectively, even if misalignments are intentionally added between the user and the exoskeleton. This study supports the use of self-aligning mechanisms in powered exoskeletons.
Related Concept Videos
 01:09
Transmission Shafts: Problem Solving
Next, use bending moment diagrams for the shaft to...
 01:16
Design of Transmission Shafts
 01:22
Mechanical Systems