Related Experiment Video
Updated: Oct 17, 2026
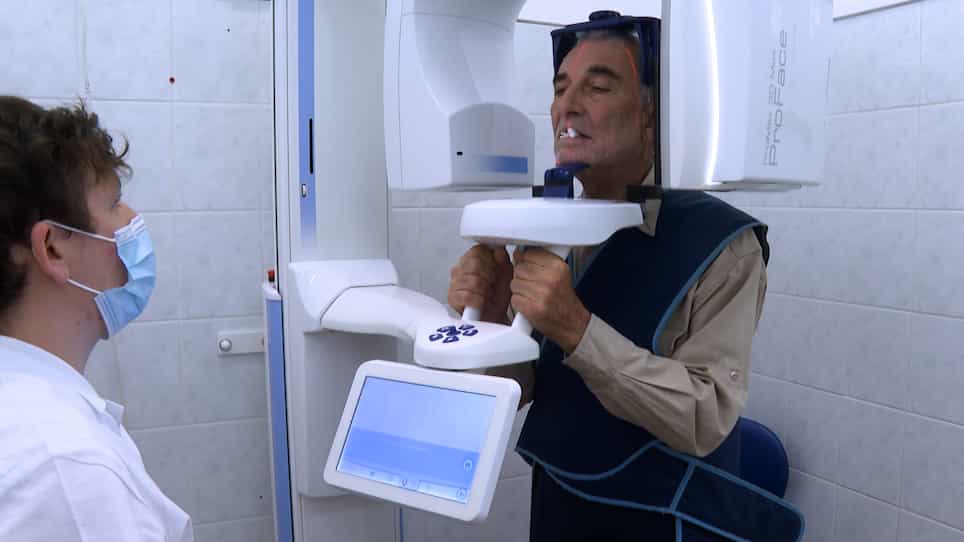
Dynamic Navigation for Dental Implant Placement
Published on: September 13, 2022
ENTRI: Enhanced Navigational Toolkit for Robotic Interventions
Manish Sahu1, Hisashi Ishida1, Laura Connolly2
1Laboratory for Computational Sensing and Robotics, Johns Hopkins University, Baltimore, MD 21218 USA.

Abstract:
Image-guided robotic interventions represent a transformative frontier in surgery, blending advanced imaging and robotics for improved precision and outcomes. This paper addresses the critical need for integrating open-source platforms to enhance situational awareness in image-guided robotic research. We present an open-source toolkit, named ENTRI, that seamlessly combines a physics-based constraint formulation framework, AMBF, with a state-of-the-art imaging platform application, 3D Slicer. ENTRI facilitates the creation of highly customizable interactive digital twins, that incorporate processing and visualization of medical imaging, robot kinematics, and scene dynamics for real-time robot control. Through a feasibility study, we showcase real-time synchronization of a physical robotic interventional environment in both 3D Slicer and AMBF, highlighting low-latency updates and improved visualization. The source code and supplementary materials for this study are available at https://github.com/LCSR-CIIS/ENTRI.