Related Experiment Video
Updated: May 7, 2026
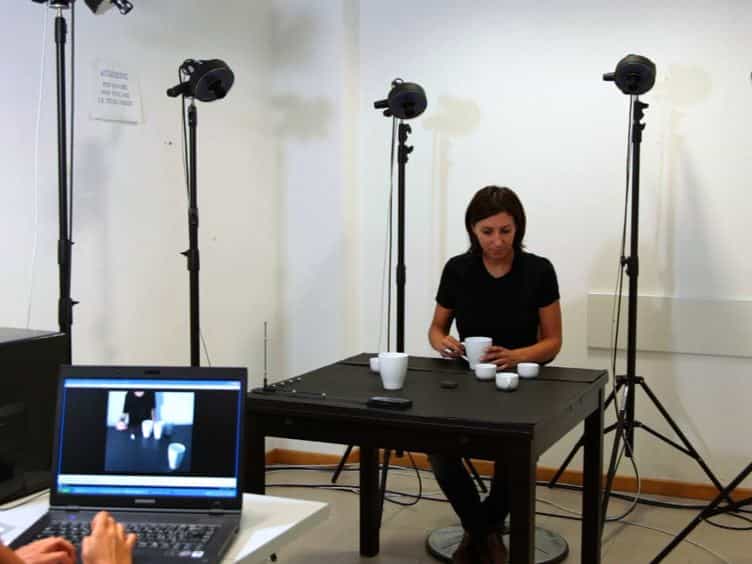

Corticospinal Excitability Modulation During Action Observation
Published on: December 31, 2013
Exemplar-based human action pose correction

Abstract:
The launch of Xbox Kinect has built a very successful computer vision product and made a big impact on the gaming industry. This sheds lights onto a wide variety of potential applications related to action recognition. The accurate estimation of human poses from the depth image is universally a critical step. However, existing pose estimation systems exhibit failures when facing severe occlusion. In this paper, we propose an exemplar-based method to learn to correct the initially estimated poses. We learn an inhomogeneous systematic bias by leveraging the exemplar information within a specific human action domain. Furthermore, as an extension, we learn a conditional model by incorporation of pose tags to further increase the accuracy of pose correction. In the experiments, significant improvements on both joint-based skeleton correction and tag prediction are observed over the contemporary approaches, including what is delivered by the current Kinect system. Our experiments for the facial landmark correction also illustrate that our algorithm can improve the accuracy of other detection/estimation systems.

Related Concept Videos
 01:06
Fixed Action Patterns
 01:24
Muscle Coordination and Action
Agonists
Agonist muscles, often called prime movers, are the primary muscles responsible for producing a specific movement.
 00:51
Anatomical Movements
Here are some common anatomical movements:
Flexion and extension motions are in the sagittal (anterior–posterior) plane of motion. These movements take place at the shoulder, hip, elbow, knee, wrist, metacarpophalangeal,...
 01:29
Relative Motion Analysis using Rotating Axes-Problem Solving
Here, in order to determine the magnitude of velocity and acceleration for point...
 01:15
Kinematic Equations: Problem Solving
 01:24
Absolute Motion Analysis- General Plane Motion
As the drone's propellers rotate, an upward force is generated that counteracts the force of gravity, enabling the drone to lift off from the ground. This initial movement of the drone is along a straight path, representing a form of translational motion. In this phase, every point on the drone...