Related Experiment Video
Updated: May 7, 2026
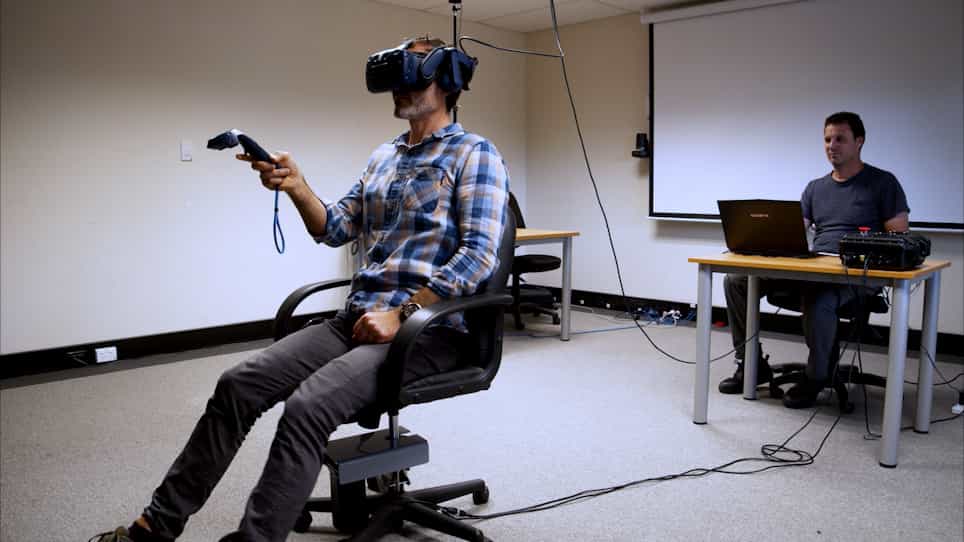
Controlled Rotation of Human Observers in a Virtual Reality Environment
Published on: April 21, 2022
Multi-degree of freedom joystick for virtual reality simulation
M J Head1, C A Nelson, K C Siu
1Department of Mechanical and Materials Engineering, University of Nebraska- Lincoln , Lincoln, NE , USA .

Abstract:
A modular control interface and simulated virtual reality environment were designed and created in order to determine how the kinematic architecture of a control interface affects minimally invasive surgery training. A user is able to selectively determine the kinematic configuration of an input device (number, type and location of degrees of freedom) for a specific surgical simulation through the use of modular joints and constraint components. Furthermore, passive locking was designed and implemented through the use of inflated latex tubing around rotational joints in order to allow a user to step away from a simulation without unwanted tool motion. It is believed that these features will facilitate improved simulation of a variety of surgical procedures and, thus, improve surgical skills training.
Related Concept Videos
 01:24
One-Degree-of-Freedom System
A one-degree-of-freedom system is defined by an independent variable that determines its state and behavior. One example of a one-degree-of-freedom system is a simple harmonic oscillator, such as a...
 01:30
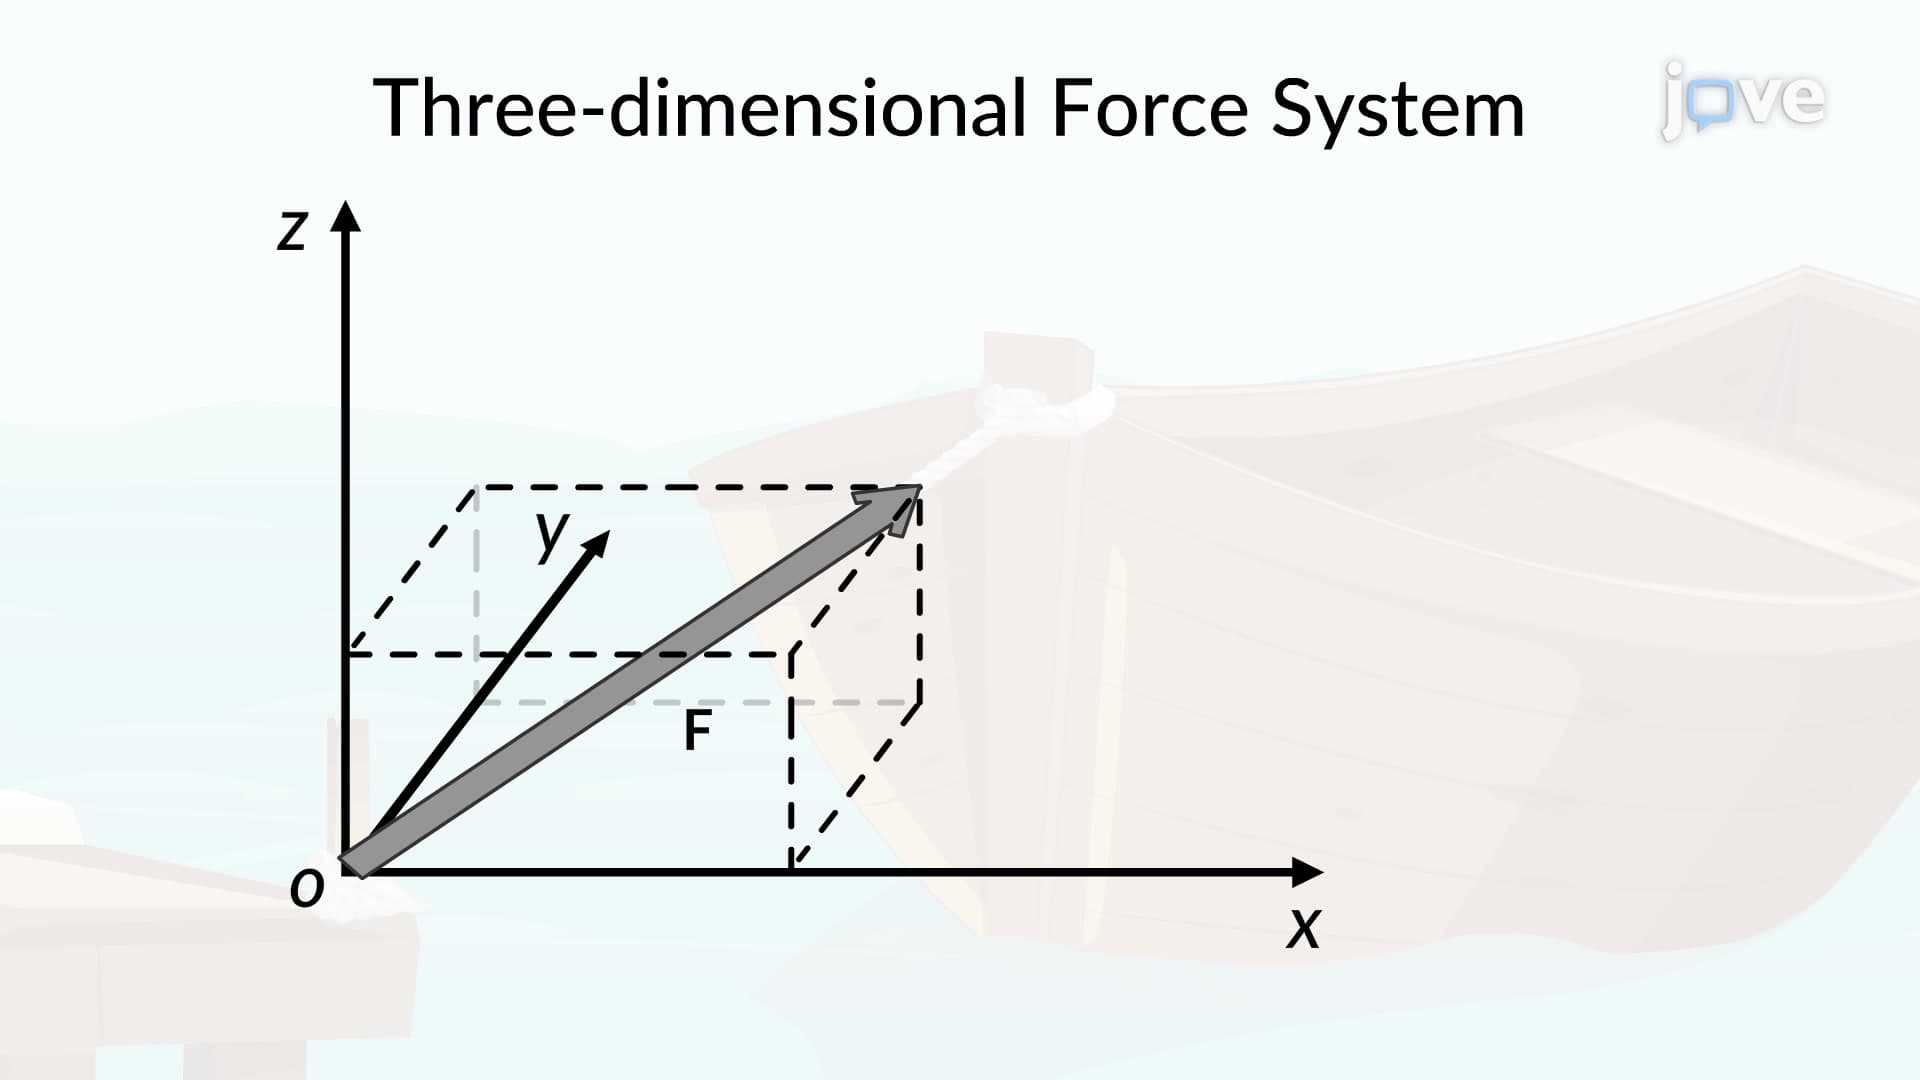
Three-Dimensional Force System
 01:30
Three-Dimensional Force System:Problem Solving
To solve a three-dimensional force system, first resolve each force into its respective scalar components. Do this using...
 01:06
Virtual Work for a System of Connected Rigid Bodies
Next,...
 01:20
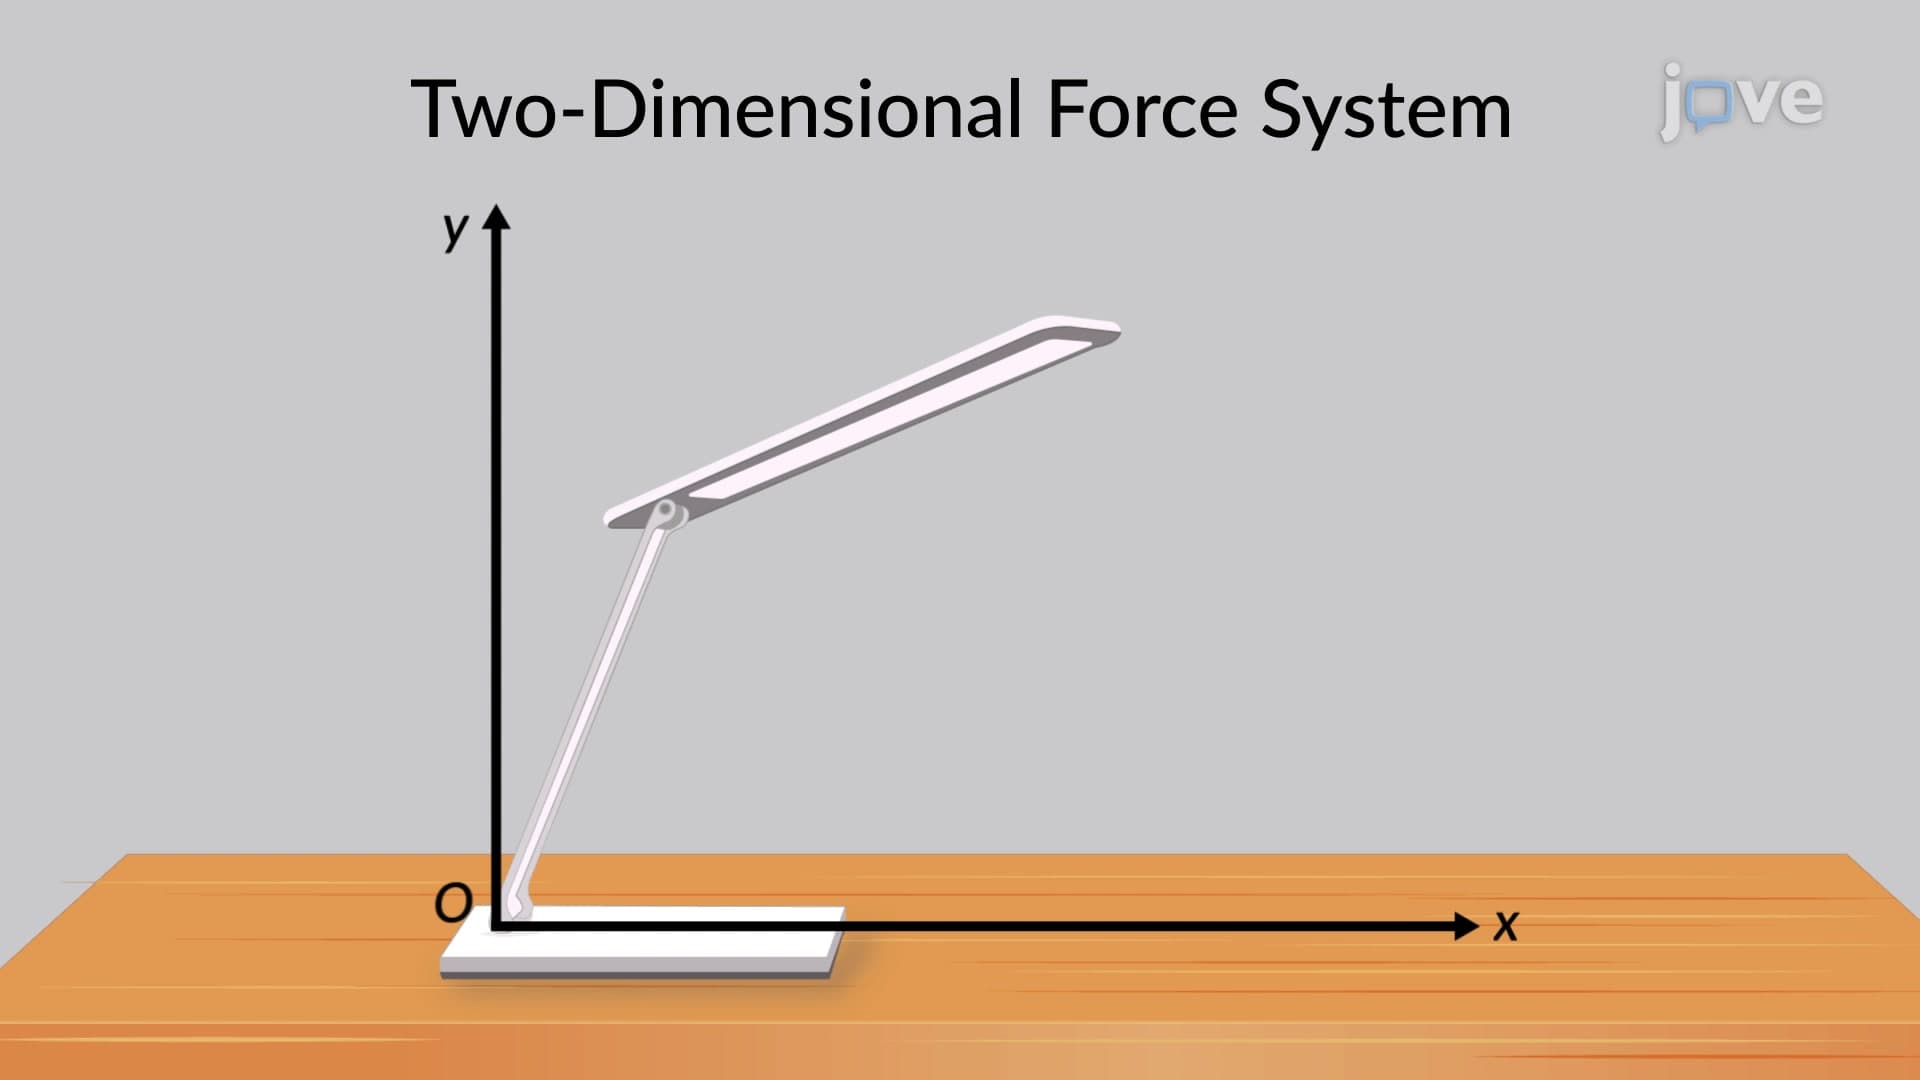
Two-Dimensional Force System
 01:02
Degrees of Freedom
For example, suppose there are three unknown numbers whose mean is 10; although we can freely assign values to the first and second numbers, the value of the last number can not be arbitrarily assigned.