Related Experiment Video
Updated: May 7, 2026
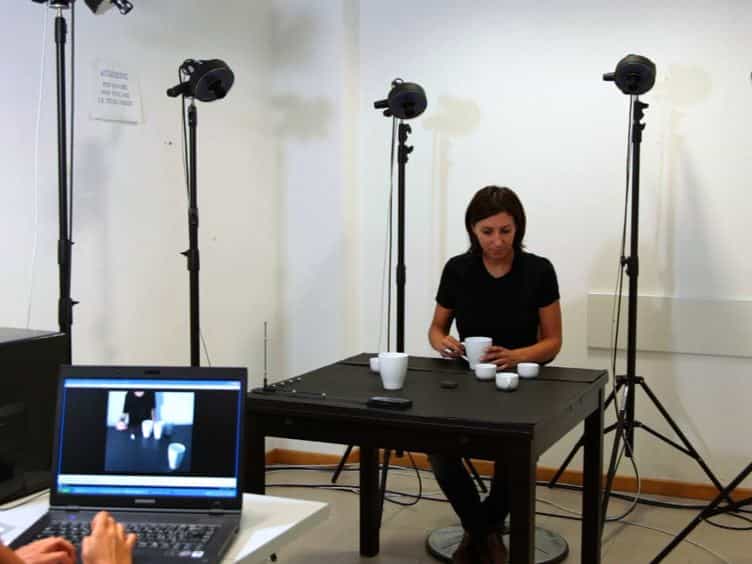

Corticospinal Excitability Modulation During Action Observation
Published on: December 31, 2013
Effects of social intention on movement kinematics in cooperative actions
François Quesque1, Daniel Lewkowicz, Yvonne N Delevoye-Turrell
1Université Lille Nord de France Lille, France ; Unité de Recherche en Sciences Cognitives et Affectives, Université de Lille 3 Villeneuve d'Ascq, France.

Abstract:
Optimal control models of biological movements are used to account for those internal variables that constrain voluntary goal-directed actions. They, however, do not take into account external environmental constraints as those associated to social intention. We investigated here the effects of the social context on kinematic characteristics of sequential actions consisting in placing an object on an initial pad (preparatory action) before reaching and grasping as fast as possible the object to move it to another location (main action). Reach-to-grasp actions were performed either in an isolated condition or in the presence of a partner (audience effect), located in the near or far space (effect of shared reachable space), and who could intervene on the object in a systematic fashion (effect of social intention effect) or not (effect of social uncertainty). Results showed an absence of audience effect but nevertheless an influence of the social context both on the main and the preparatory actions. In particular, a "localized" effect of shared reachable space was observed on the main action, which was smoother when performed within the reachable space of the partner. Furthermore, a "global" effect of social uncertainty was observed on both actions with faster and jerkier movements. Finally, social intention affected the preparatory action with higher wrist displacements and slower movements when the object was placed for the partner rather than placed for self-use. Overall, these results demonstrate specific effects of action space, social uncertainty and social intention on the planning of reach-to-grasp actions, in particular on the preparatory action, which was performed with no specific execution constraint. These findings underline the importance of considering the social context in optimal models of action control for human-robot interactions, in particular when focusing on the implementation of motor parameters required to afford intuitive interactions.
More Related Videos
 06:17
A Task for Assessing the Impact of a Partner on the Speed and Accuracy of Motor Performance in Rats
Published on: October 17, 2019
 11:14
A Novel Experimental and Analytical Approach to the Multimodal Neural Decoding of Intent During Social Interaction in Freely-behaving Human Infants
Published on: October 4, 2015
Related Concept Videos
 01:30
Causes of Social Behavior I: Actions and Characteristics of Individuals
 01:30
Impact of Individuals on Individuals
 01:13
Nonconscious Mimicry
 01:21
Secondary Motives: Affiliation Motivation and Aggression Motivation
 01:24
Muscle Coordination and Action
Agonists
Agonist muscles, often called prime movers, are the primary muscles responsible for producing a specific movement....
 01:17
Kinematic Equations - II
Suppose a car merges into freeway traffic on a 200 m long ramp. If its initial velocity is 10 m/s and it accelerates at 2 m/s2, then the...