Related Experiment Video
Updated: May 6, 2026
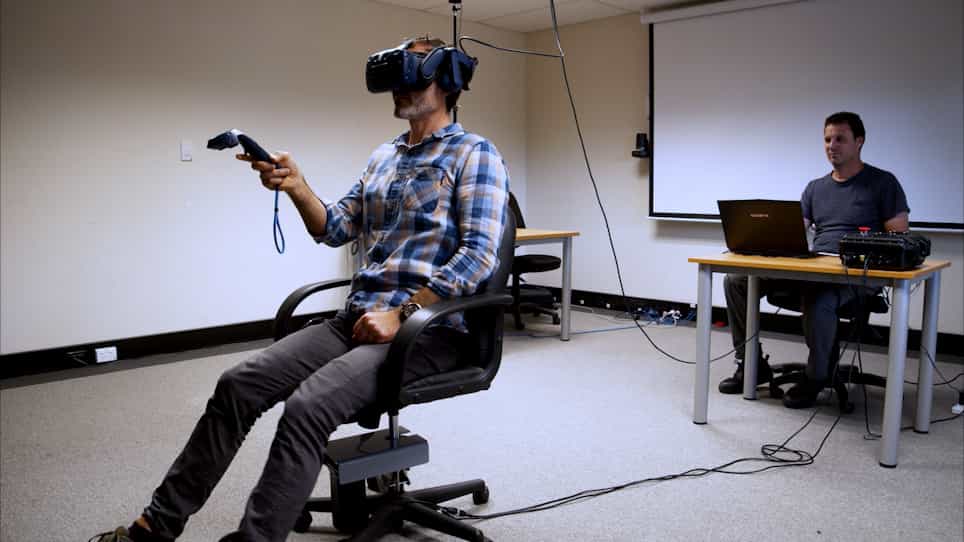
Controlled Rotation of Human Observers in a Virtual Reality Environment
Published on: April 21, 2022
Towards identifying the roll motion parameters of a motorcycle simulator
Amit Shahar1, Virginie Dagonneau1, Séphane Caro1
1Laboratory of Operations, Perception, Simulators and Simulations (LEPSiS), French Institute of Sciences and Technology for Transport, Development and Networks (IFSTTAR), 14-20 Boulevard Newton, Cité Descartes, Champs sur Marne, F-77447 Marne la Vallée Cedex 2, France.

Abstract:
This study aimed at identifying the roll motion parameters of a motorcycle simulator prototype. Experienced motorcyclists tuned the angular physical movement of the mock-up and that of the visual scene to achieve an optimal riding experience during curves. The participants exceeded the rolling angles that would be required in real-world riding, while avoiding leaning the mock-up beyond 10°. In addition, they were more influenced by the speed of the virtual motorcycle than by road curvature, especially in a wide field of view. Heterogeneity was found in the roll applied to the visual scene. The overall patterns suggest that at least when washout is not applied to remove the side forces that in real-world riding are compensated by a centrifugal force, greater roll of the visual at the expense of the mock-up is mandatory to avoid performance biases that might be enhanced due to fear of falling off the simulator. Future roll motion models must take into consideration factors such as riding postures, which might not only influence the forces operating on the rider-motorcycle system, but also how motorcyclists perceive the visual world.
More Related Videos
Related Concept Videos
 01:16
Equation of Motion: General Plane motion - Problem Solving
The friction between the roller and the ground is characterized by two coefficients. The static friction coefficient is 0.15, while the kinetic friction coefficient is 0.1. These values are crucial in understanding the interaction between...
 01:10
Relative Motion Analysis - Acceleration
 01:24
Absolute Motion Analysis- General Plane Motion
As the drone's propellers rotate, an upward force is generated that counteracts the force of gravity, enabling the drone to lift off from the ground. This initial movement of the drone is along a straight path, representing a form of translational motion. In this phase, every point on the...
 01:24
Relative Motion Analysis - Velocity
When an external force is exerted, it sets the crank into a rotational movement. This, in turn, instigates the motion of the connecting rod, leading to what is referred to as a general plane motion. This process involves two key points - point A on the connecting rod...
 01:17
Rolling Resistance: Problem Solving
 01:25
Relative Motion Analysis using Rotating Axes
However, to express the relative position of point B relative to point A, an additional frame of reference, denoted as x'y', is necessary. This additional frame not only translates but also rotates relative to the fixed frame, making it...