Related Experiment Videos
Integrated physics-data-based LPV-LMS-MPC coordinated control for simultaneous luffing-slewing of truck cranes
Rui Zhou1, Zhenzhi Zhang2, Xiuheng Wu2
1Faculty of Innovation Engineering, Macau University of Science and Technology, Macau, 999078, China.

Abstract:
Simultaneous luffing-slewing control of truck cranes is challenging due to nonlinear dynamics, parameter variations, and motion coupling. To overcome these issues, this article introduces an integrated physics-data-based LPV-LMS-MPC framework for the coordinated control of an electro-hydraulic system. A physics-based affine linear parameter-varying (LPV) model is first derived from fundamental principles to capture cross-coupling dynamics. To address parameter time-variation without compromising model interpretability, a Kronecker-product reformulation is introduced. This transformation enables the least mean square (LMS) algorithm to selectively update only the uncertain coefficients online using real system output data while preserving the predefined physical structure and structural zeros. The updated coefficients are mapped back to the LPV state-space matrices to reconstruct a constrained incremental model predictive control (MPC) prediction model, enabling real-time adaptive optimization. Simulation and prototype experiments validate the framework. Results show that the LPV-LMS model reliably captures disturbed system dynamics, and the integrated LPV-LMS-MPC scheme delivers superior coordinated tracking while requiring far less computation time than nonlinear MPC.
Related Concept Videos
 01:28
Load-frequency control
 01:19
Distributed Loads
For example, consider a bookshelf filled with books stacked vertically adjacent to each other. The weight of the books is evenly distributed over the length of the shelf. As a result, the pressure at different locations on the surface of the...
 01:26
PD Controller: Design
Designing a continuous-data controller requires selecting and linking components like adders and integrators, which are fundamental in Proportional,...
 01:13
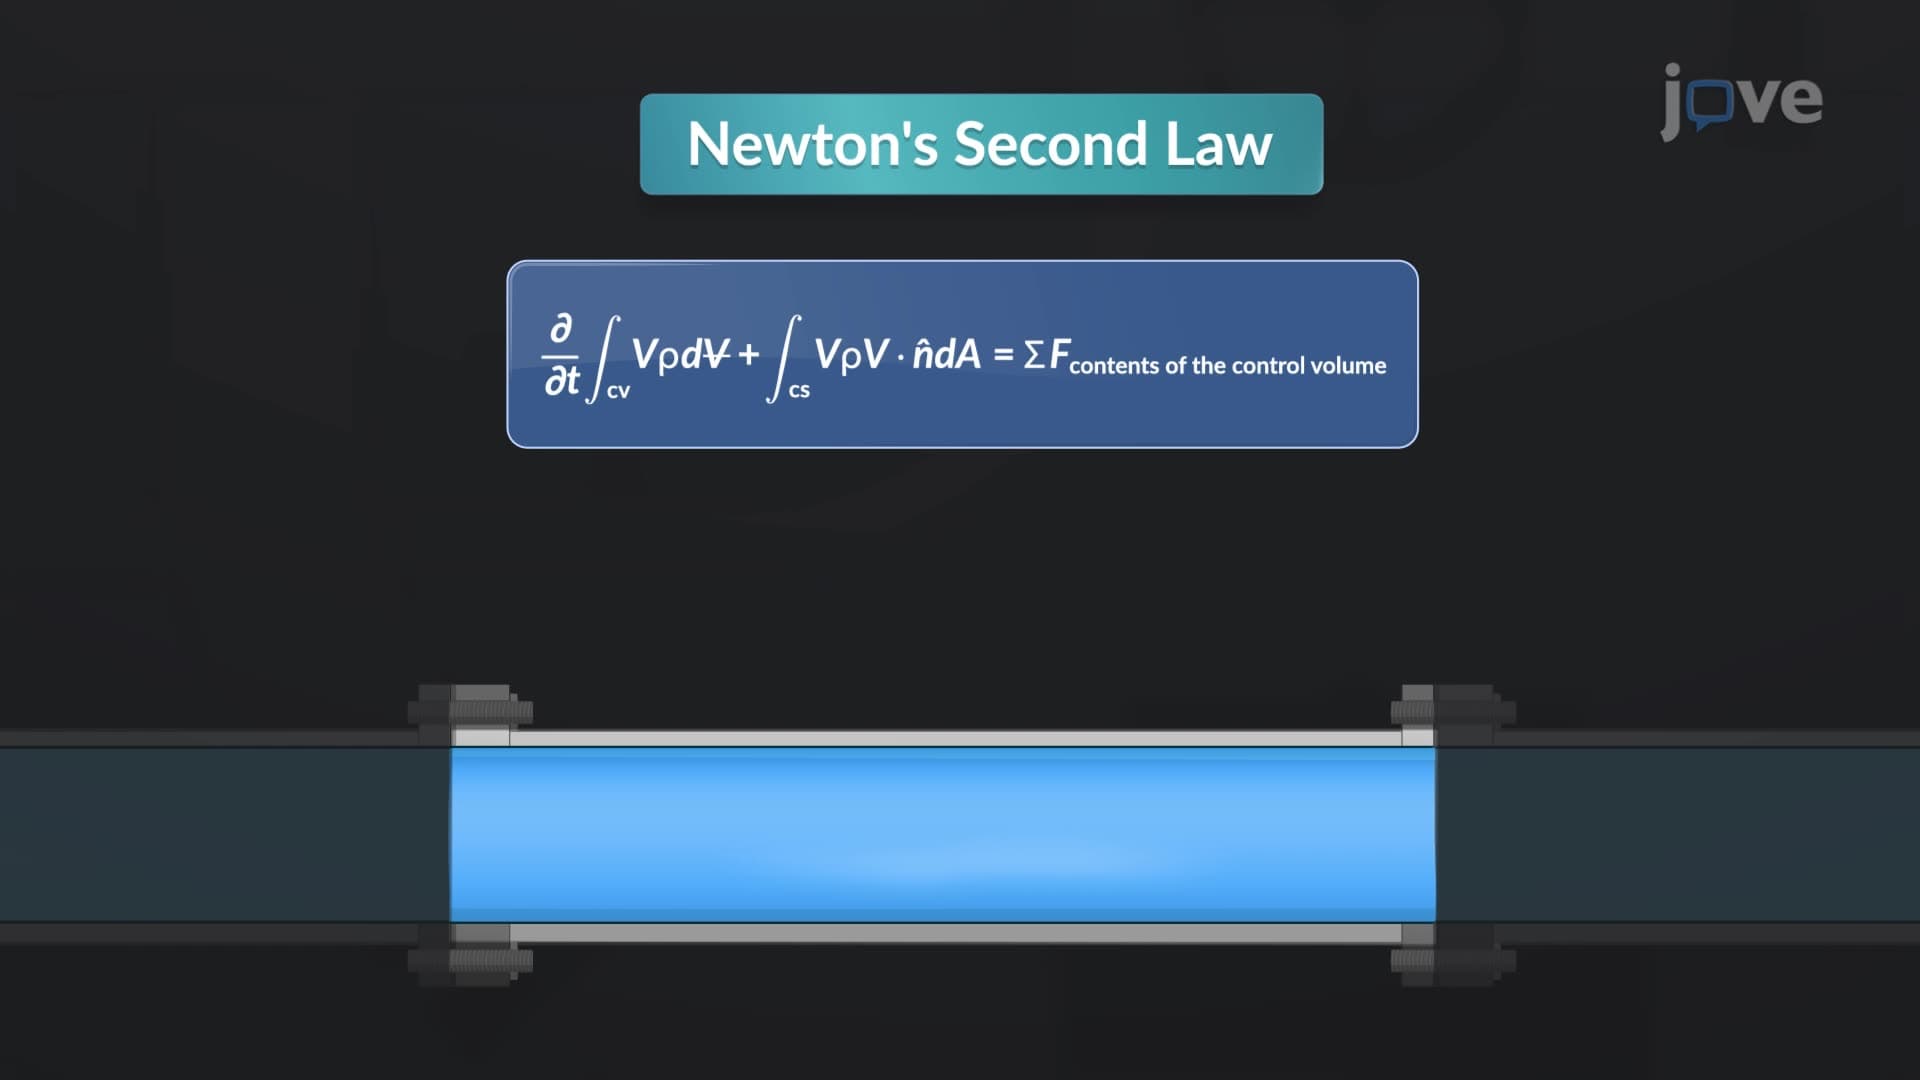
Linear Momentum in Control Volume
 01:24
PI Controller: Design
 01:21
Distributed Loads: Problem Solving