Related Experiment Video
Updated: May 6, 2026

Efficiently Recording the Eye-Hand Coordination to Incoordination Spectrum
Published on: March 21, 2019
Characterizing coordination of grasp and twist in hand function of healthy and post-stroke subjects

Abstract:
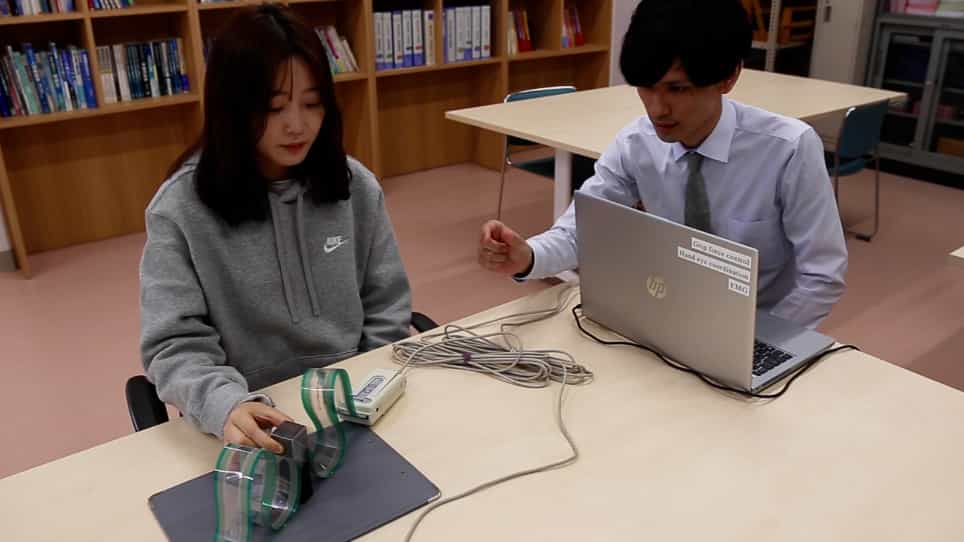
The goal of this study was to characterize the coordination of grasp and twist in hand function of normal and post-stroke subjects using a two degree of freedom hand robot. Results of the analysis of data from eight control subjects indicated that normal grip coordination involves the linear modulation of grip force with load torque. Thus, there was a high correlation between grip force and load torque. Also, the force generated by the thumb was highly correlated with the force generated by the index, middle and ring fingers. Finally, the safety margin used to stabilize grasp and avoid slip was consistent across normal subjects. In contrast, results from chronic post-stroke subjects indicated that they generally: (1) exerted excessive grip force to stabilize grasp using their ipsilesional hand; (2) lost the close amplitude coupling between grip force and load torque; and (3) lost the close modulation of the thumb force with finger force. These results suggest that our methods may provide objective, quantitative means of characterizing coordination problems following stroke.