Related Experiment Video
Updated: May 6, 2026


Development of a Novel Task-oriented Rehabilitation Program using a Bimanual Exoskeleton Robotic Hand
Published on: May 20, 2020
Design of Wrist Gimbal: a forearm and wrist exoskeleton for stroke rehabilitation

Abstract:
In this paper, we present design, implementation and specifications of the Wrist Gimbal, a three degree-of-freedom (DOF) exoskeleton developed for forearm and wrist rehabilitation. Wrist Gimbal has three active DOF, corresponding to pronation/supination, flexion/extension and adduction/abduction joints. We mainly focused on a robust, safe and practical device design to facilitate clinical implementation, testing and acceptance. Robustness and mechanical rigidity was achieved by implementing two bearing supports for each of the pronation/supination and adduction/abduction axes. Rubber hard stops for each axis, an emergency stop button and software measures ensured safe operation. An arm rest with padding and straps, a handle with adjustable distal distance and height and a large inner volume contribute to ease of use, of patient attachment and to comfort. We present the specifications of Wrist Gimbal in comparison with similar devices in the literature and example data collected from a healthy subject.
More Related Videos


Related Concept Videos
 01:16
Muscles of the Forearm that Move the Hand and Fingers
Anterior Compartment
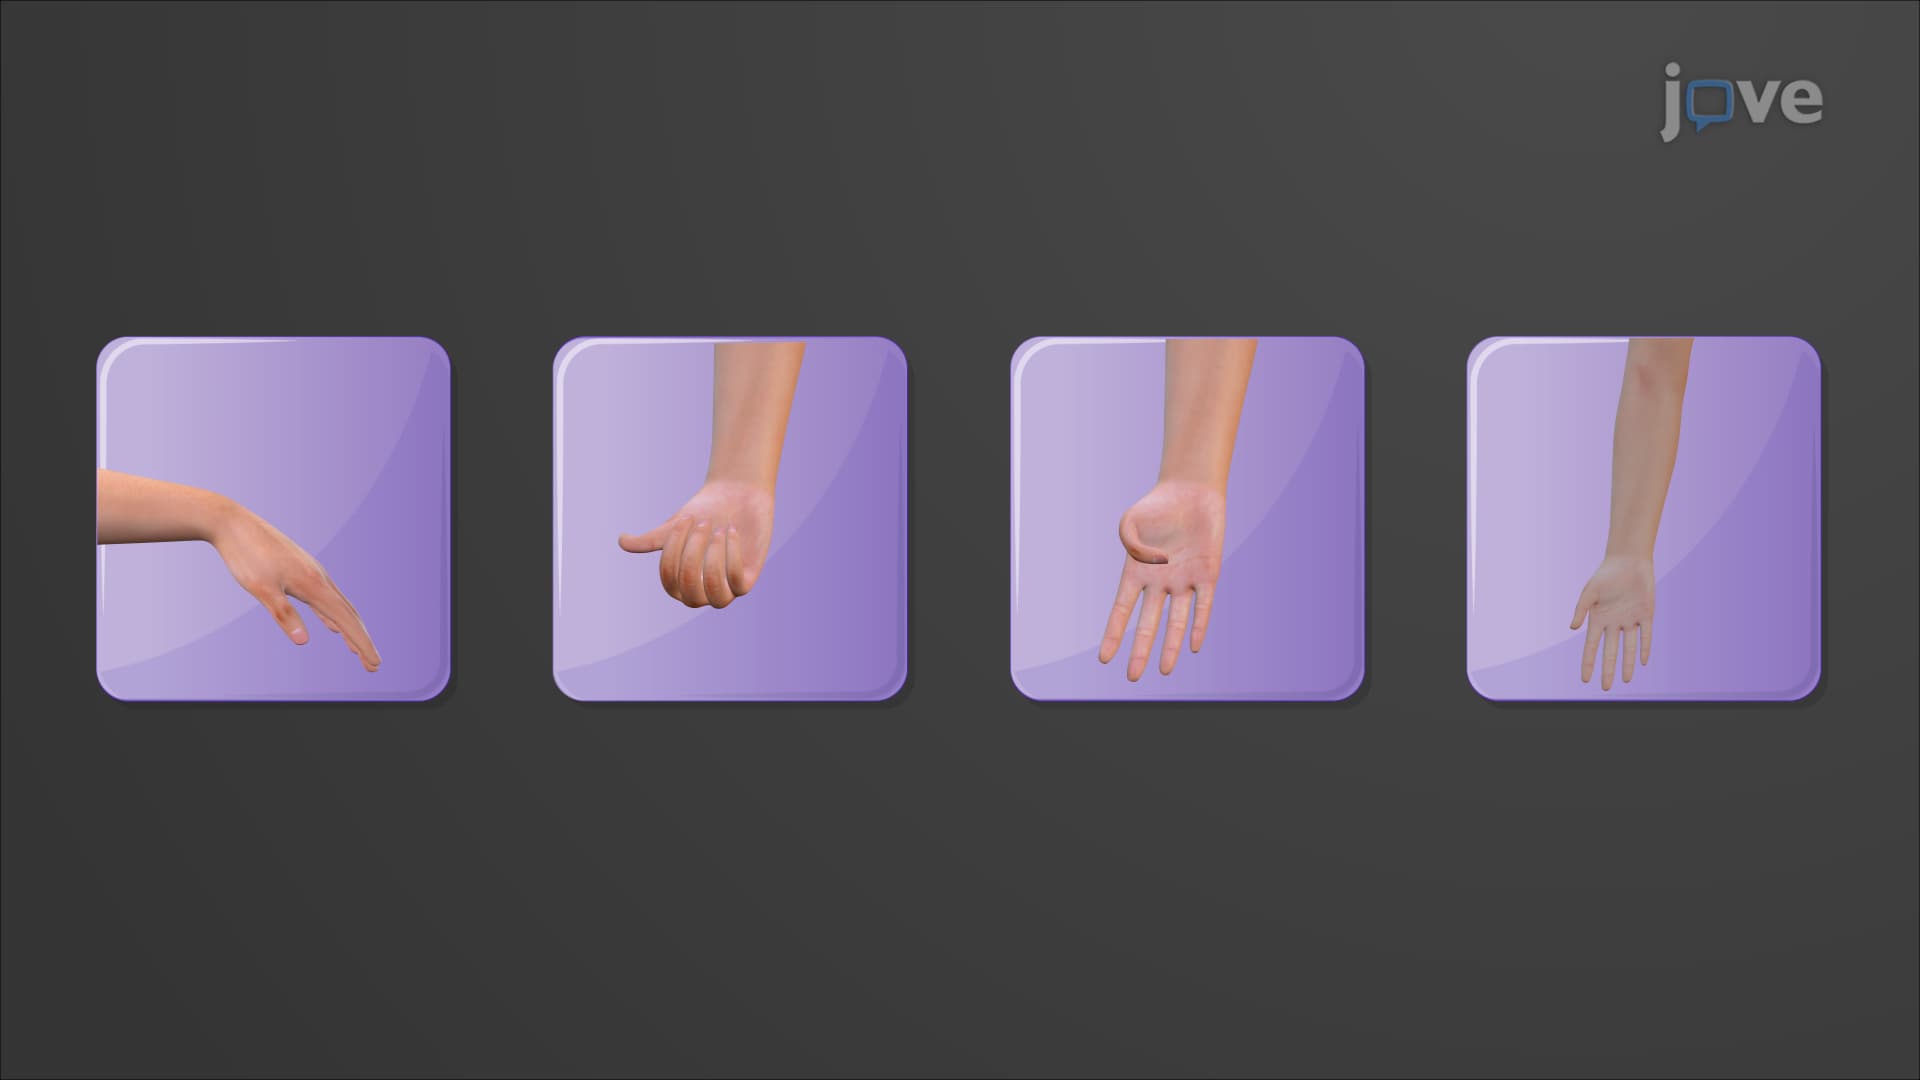
The anterior compartment muscles originate from the humerus. They primarily function as flexors and are also known as flexor muscles. They typically insert on the carpals, metacarpals, and phalanges. The superficial layer includes the flexor carpi...
 01:16
Muscles that Move the Forearm
Forearm Flexors
The biceps brachii, brachialis, and brachioradialis are forearm flexors. The biceps brachii is made up of two heads. Its long head originates at the supraglenoid tubercle of the scapula, whereas that of the short head is...