Related Experiment Video
Updated: May 4, 2026
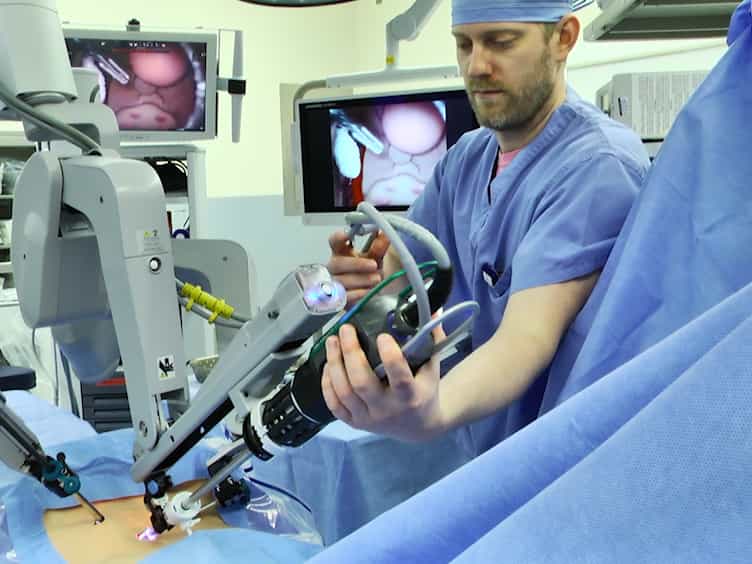

Emergency Undocking in Robotic Surgery: A Simulation Curriculum
Published on: May 20, 2018
Task and crisis analysis during surgical training
Patrick Wucherer1, Philipp Stefan, Simon Weidert
1Technische Universität München, Munich, Germany, p.wucherer@mytum.de.

Purpose:
To design a surgical training environment based on task and crisis analysis of the surgical workflow.
Method:
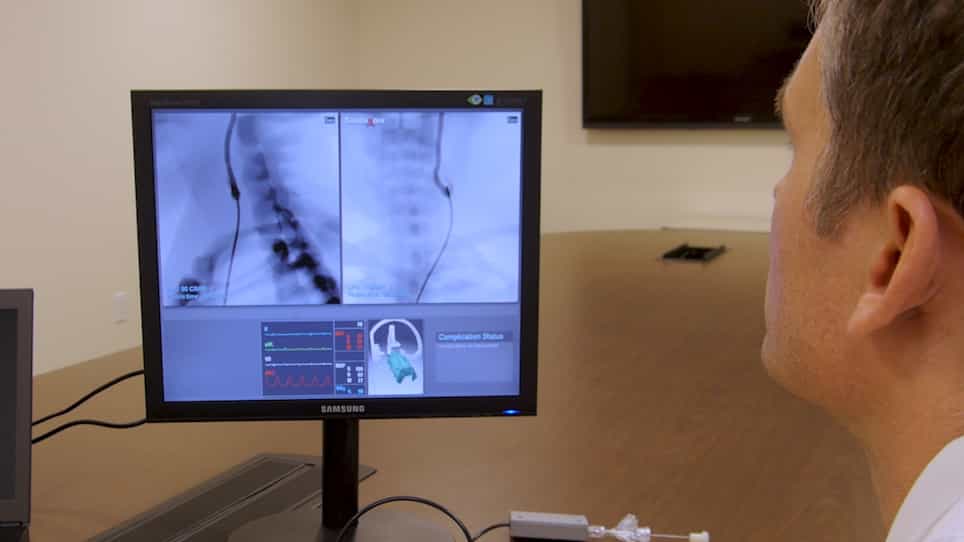
The environment consists of: (1) real surgical instruments that are augmented with realistic haptic feedback and VR capabilities, (2) human sensory channels such as tactile, auditory and visual in real time, and (3) the ability to facilitate deliberate exposure to adverse events enabling mediation of error recovery strategies.
Validation:
Five surgeons were immersed in our medical simulation environment through task and crisis scenarios of a typical vertebroplasty workflow.
Results:
Based on a five-point Likert-scale survey, the face validity of our simulation environment was confirmed by investigating surgeon behavior and workflow response.
Conclusions:
The result of the conducted user-study corroborates our unique medical simulation concept of combining VR and human multisensory responses into surgical workflow.
Related Concept Videos
 01:22
Aneurysm IV: Nursing Management
 01:24
Critical Thinking I
 01:23
Peripheral Artery Disease V: Postoperative Nursing Management