Related Experiment Video
Updated: May 3, 2026

Measuring Attention and Visual Processing Speed by Model-based Analysis of Temporal-order Judgments
Published on: January 23, 2017
Parameter estimation for a dual-rate system with time delay
Lei Chen1, Lili Han2, Biao Huang2
1Key Laboratory of Advanced Process Control for Light Industry (Ministry of Education), Institute of Automation, Jiangnan University, Wuxi 214122, PR China; Department of Chemical and Materials Engineering, University of Alberta, Edmonton, Canada AB T6G 2G6.

Abstract:
This paper investigates the parameter estimation problem of the dual-rate system with time delay. The slow-rate model of the dual-rate system with time delay is derived by using the discretization technique. The parameters and states of the system are simultaneously estimated. The states are estimated by using the Kalman filter, and the parameters are estimated based on the stochastic gradient algorithm or the recursive least squares algorithm. When concerning state estimate of the dual-rate system with time delay, the state augmentation method is employed with lower computational load than that of the conventional one. Simulation examples and an experimental study are given to illustrate the proposed algorithm.
Related Concept Videos
 01:07
Time-Domain Interpretation of PD Control
Consider the example of control of motor torque. Initially, a positive...
 01:18
Second Order systems II
 01:21
Linear Approximation in Time Domain
For a simple pendulum with a mass evenly distributed along its length and the center of mass located at half the pendulum's length,...
 01:31
Classification of Systems-II
 01:24
Time and frequency -Domain Interpretation of Phase-lead Control
The design of phase-lead control involves the strategic placement of poles and zeros to balance steady-state error and system...
 01:21
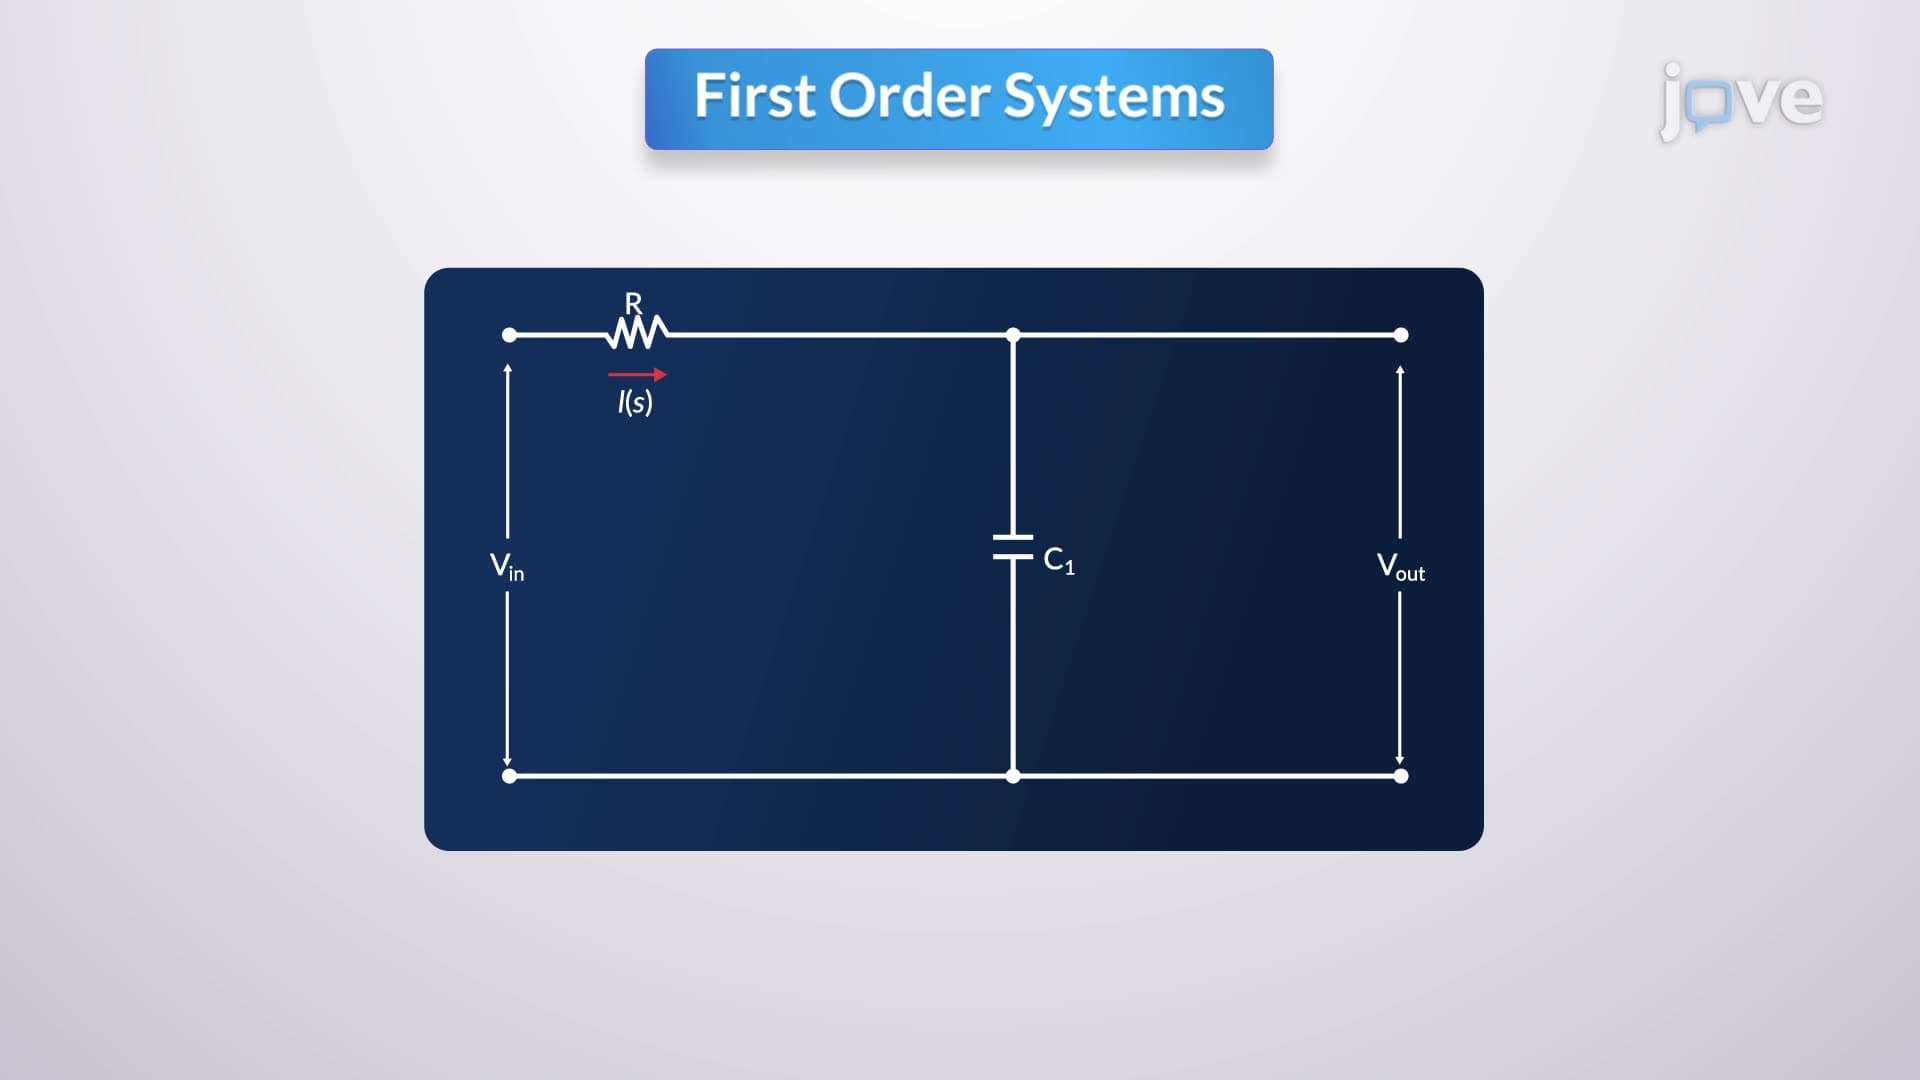
First Order Systems
When a first-order system is subjected to a unit-step input, its response is characterized by its transfer function. By applying the Laplace transform of the unit-step input to the transfer function, expanding the...