Related Experiment Video
Updated: May 1, 2026
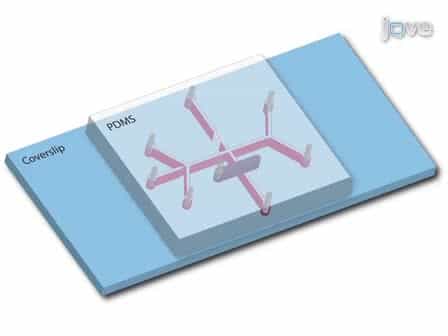

A Microfluidic-based Hydrodynamic Trap for Single Particles
Published on: January 21, 2011
Dynamic trapping and two-dimensional transport of swimming microorganisms using a rotating magnetic microrobot
1Department of Mechanical Engineering, Carnegie Mellon University, Pittsburgh, Pennsylvania 15213, USA. sitti@cmu.edu.

Abstract:
Manipulation of microorganisms with intrinsic motility is a challenging yet important task for many biological and biomedical applications. Currently, such a task has only been accomplished using optical tweezers, while at the risk of averse heating and photodamage of the biological samples. Here, we proposed a new micro-robotic approach for fluidic trapping and two-dimensional transportation of motile microorganisms near a solid surface in fluids. We demonstrated selective trapping and transportation of individual freely swimming multi-flagellated bacteria over a distance of 30 μm (7.5 body length of the carrier) on a surface, using the rotational flows locally induced by a rotating magnetic microparticle. Only a weak uniform magnetic field (<3 mT) was applied to actuate the microparticle. The microparticle can translate on a glass substrate by rotating at a speed of up to 100 μm s(-1), while providing a fluidic force of a few to tens of pico-Newtons.