Related Experiment Video
Updated: May 1, 2026
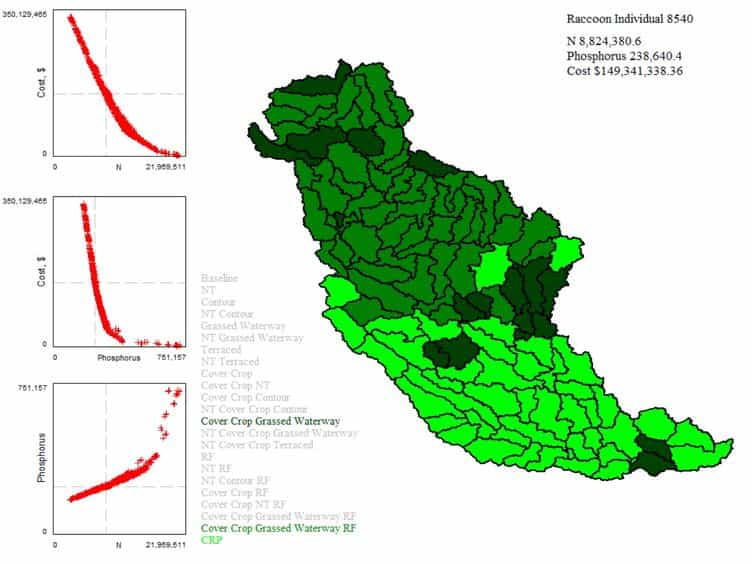
Spatial Multiobjective Optimization of Agricultural Conservation Practices using a SWAT Model and an Evolutionary Algorithm
Published on: December 9, 2012
Order-2 Stability Analysis of Particle Swarm Optimization
1College of Computing, Dongguan University of Technology, Dongguan, 523808, China liuqf@dgut.edu.cn.

Abstract:
Several stability analyses and stable regions of particle swarm optimization (PSO) have been proposed before. The assumption of stagnation and different definitions of stability are adopted in these analyses. In this paper, the order-2 stability of PSO is analyzed based on a weak stagnation assumption. A new definition of stability is proposed and an order-2 stable region is obtained. Several existing stable analyses for canonical PSO are compared, especially their definitions of stability and the corresponding stable regions. It is shown that the classical stagnation assumption is too strict and not necessary. Moreover, among all these definitions of stability, it is shown that our definition requires the weakest conditions, and additional conditions bring no benefit. Finally, numerical experiments are reported to show that the obtained stable region is meaningful. A new parameter combination of PSO is also shown to be good, even better than some known best parameter combinations.
Related Concept Videos
 01:13
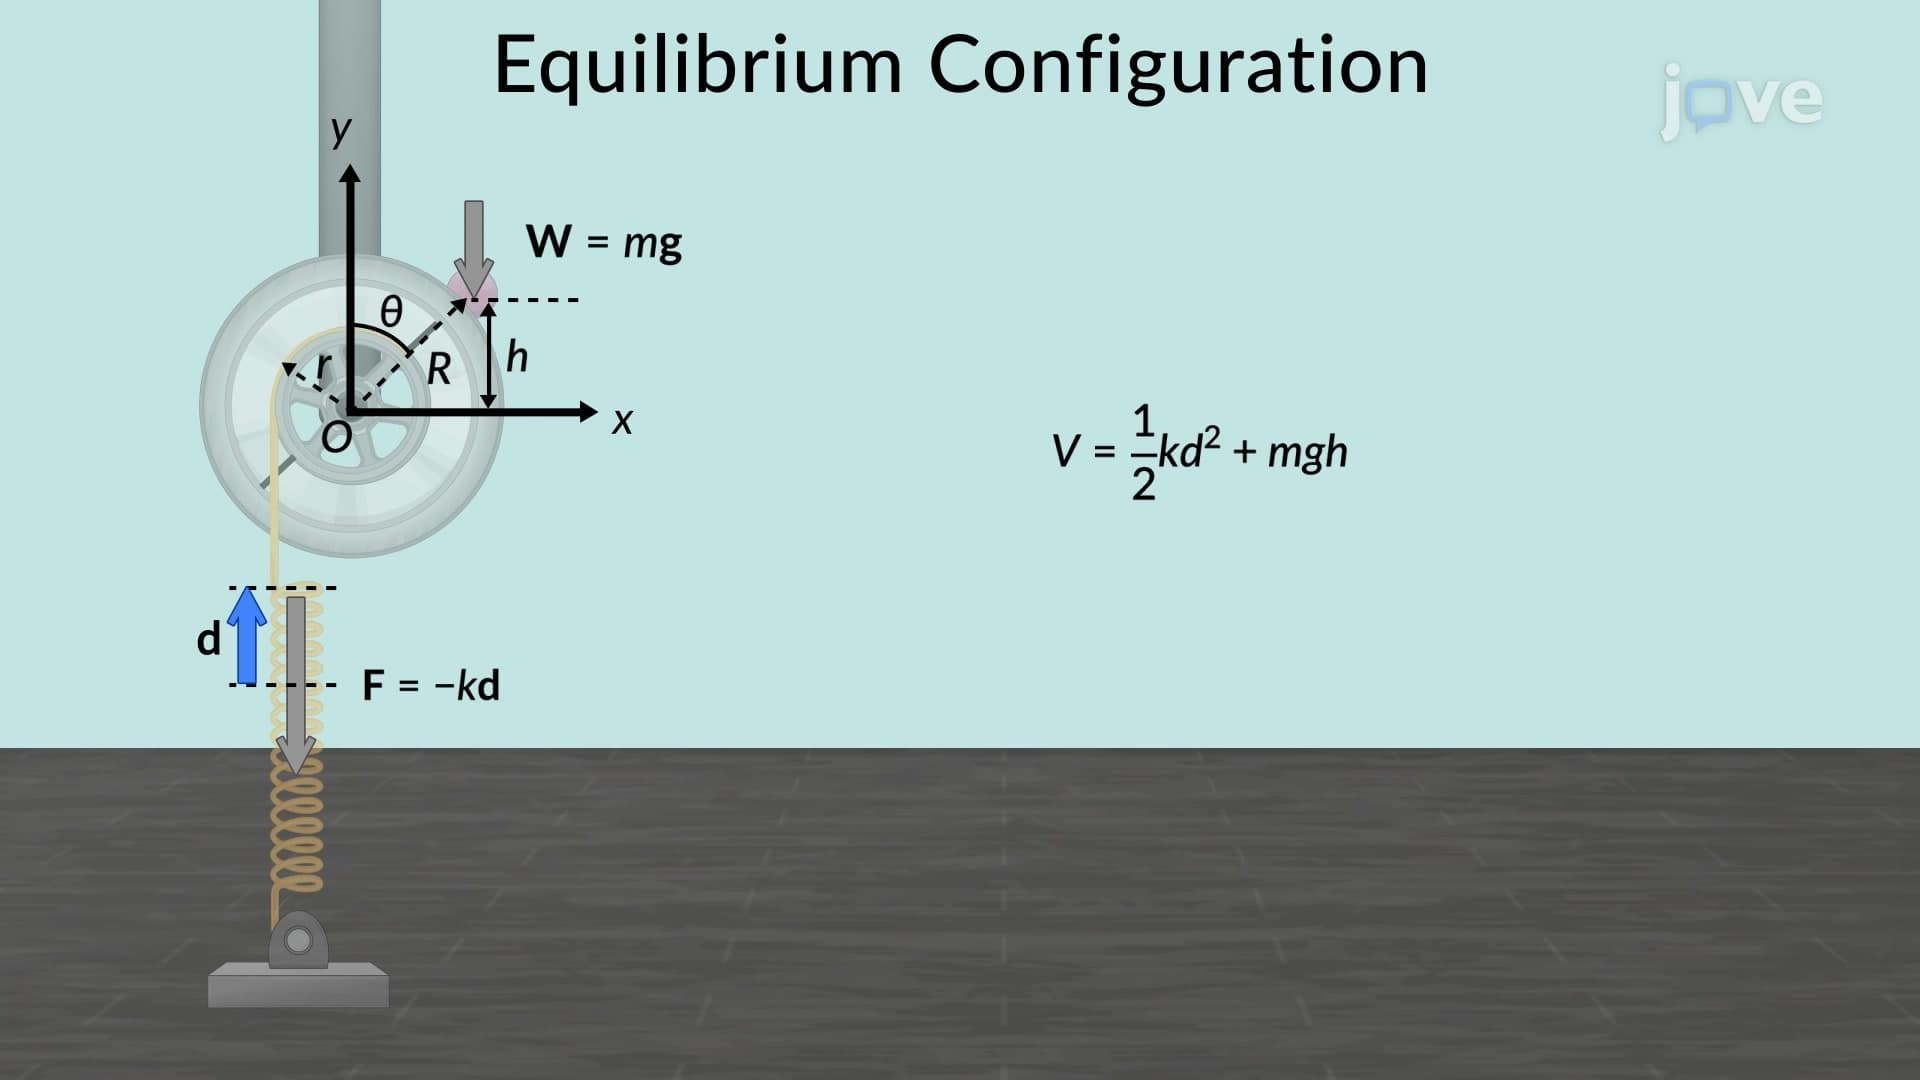
Stability of Equilibrium Configuration: Problem Solving
Problem-solving in the context of the stability of equilibrium configuration...
 01:24
Pole and System Stability
Simple poles are unique roots of the denominator polynomial. Each simple pole corresponds to a distinct solution to the system's characteristic equation, typically resulting in exponential decay terms in the system's...
 01:23
Stability of Equilibrium Configuration
A stable equilibrium occurs when a system tends to return to its original position when given a small displacement, and the potential energy is at its minimum. An example of a stable equilibrium is when a cantilever beam is fixed at one end and a weight is attached to the other end. If the weight...
 01:24
One-Degree-of-Freedom System
A one-degree-of-freedom system is defined by an independent variable that determines its state and behavior. One example of a one-degree-of-freedom system is a simple harmonic oscillator, such as a...
 01:04
Oscillations about an Equilibrium Position
 01:28
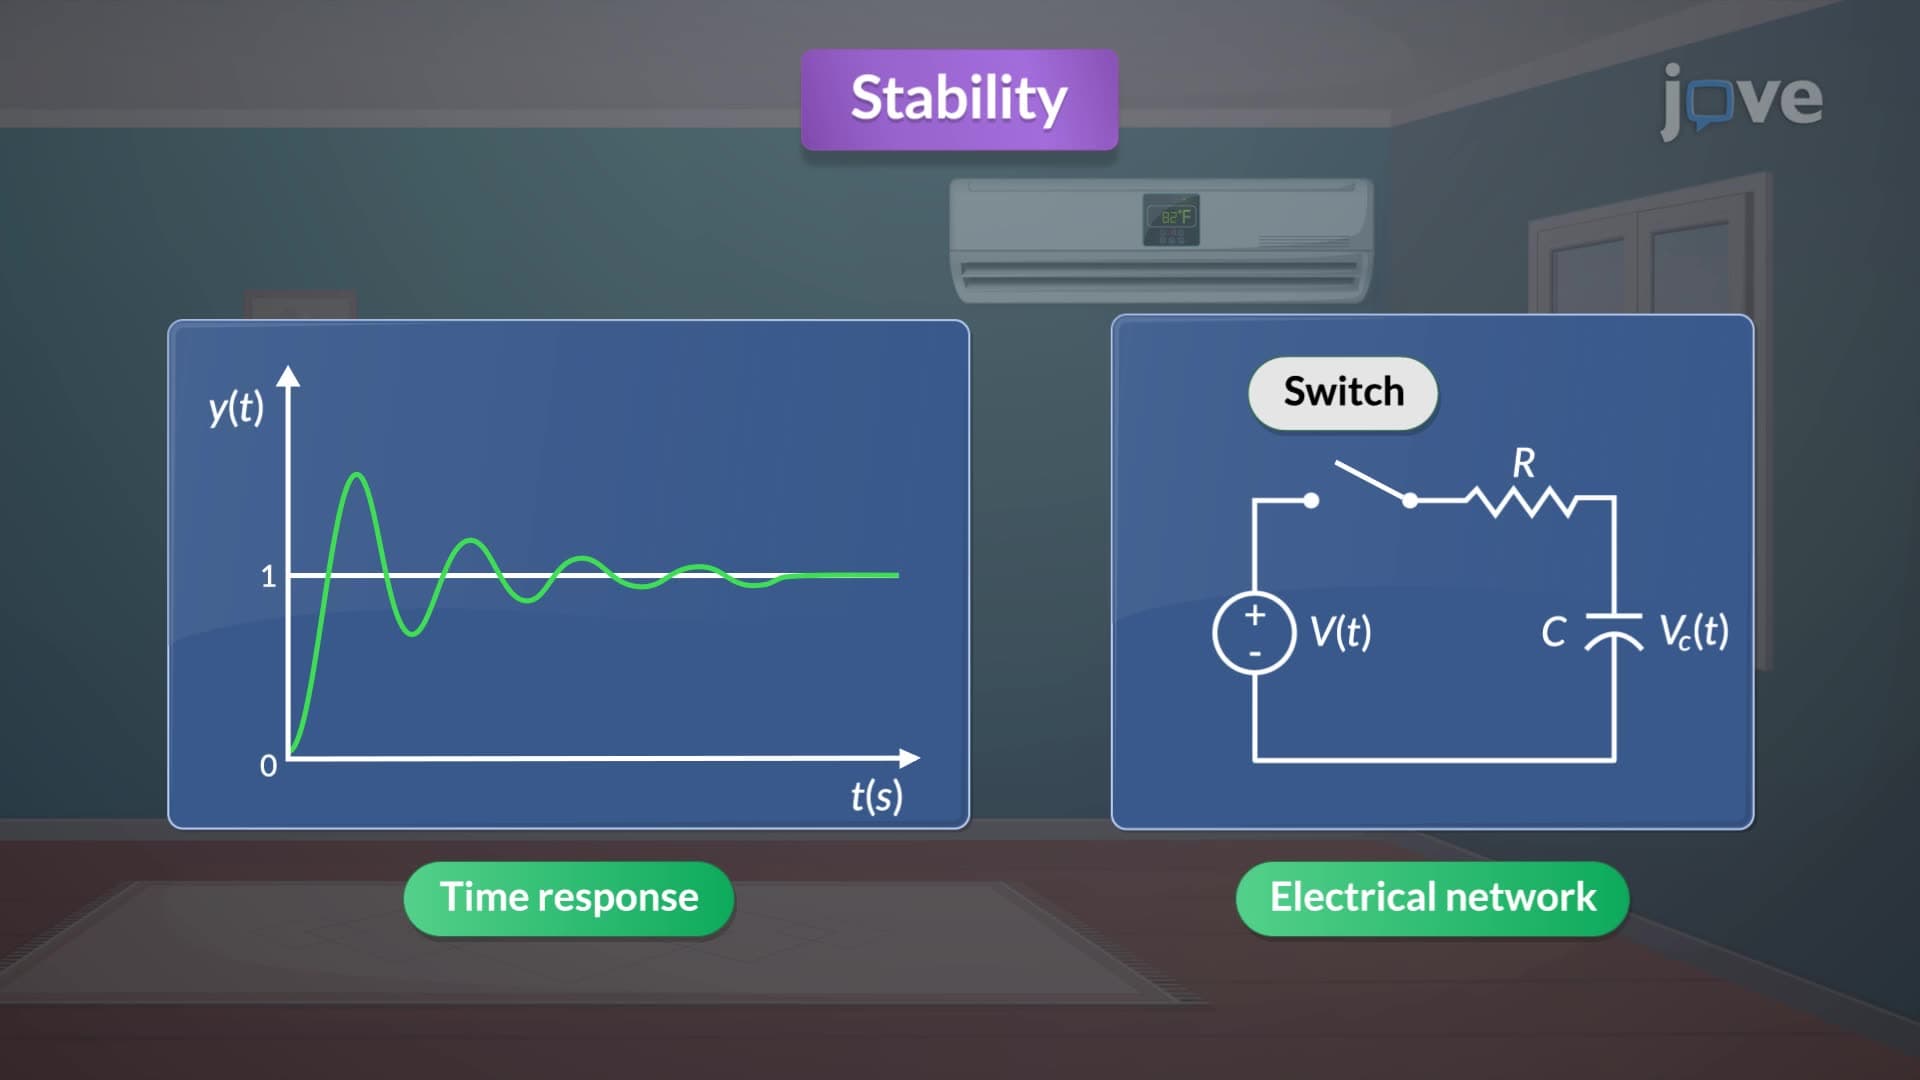
Stability
The stability of an LTI system is determined by the roots of its characteristic equation, known as poles. A system is stable if it produces a bounded...