Related Experiment Video
Updated: May 1, 2026


Robotized Testing of Camera Positions to Determine Ideal Configuration for Stereo 3D Visualization of Open-Heart Surgery
Published on: August 12, 2021
On the use of orientation filters for 3D reconstruction in event-driven stereo vision
Luis A Camuñas-Mesa1, Teresa Serrano-Gotarredona1, Sio H Ieng2
1Instituto de Microelectrónica de Sevilla (IMSE-CNM), CSIC y Universidad de Sevilla Sevilla, Spain.

Abstract:
The recently developed Dynamic Vision Sensors (DVS) sense visual information asynchronously and code it into trains of events with sub-micro second temporal resolution. This high temporal precision makes the output of these sensors especially suited for dynamic 3D visual reconstruction, by matching corresponding events generated by two different sensors in a stereo setup. This paper explores the use of Gabor filters to extract information about the orientation of the object edges that produce the events, therefore increasing the number of constraints applied to the matching algorithm. This strategy provides more reliably matched pairs of events, improving the final 3D reconstruction.
Related Concept Videos
 01:15
Depth Perception and Spatial Vision
 01:20
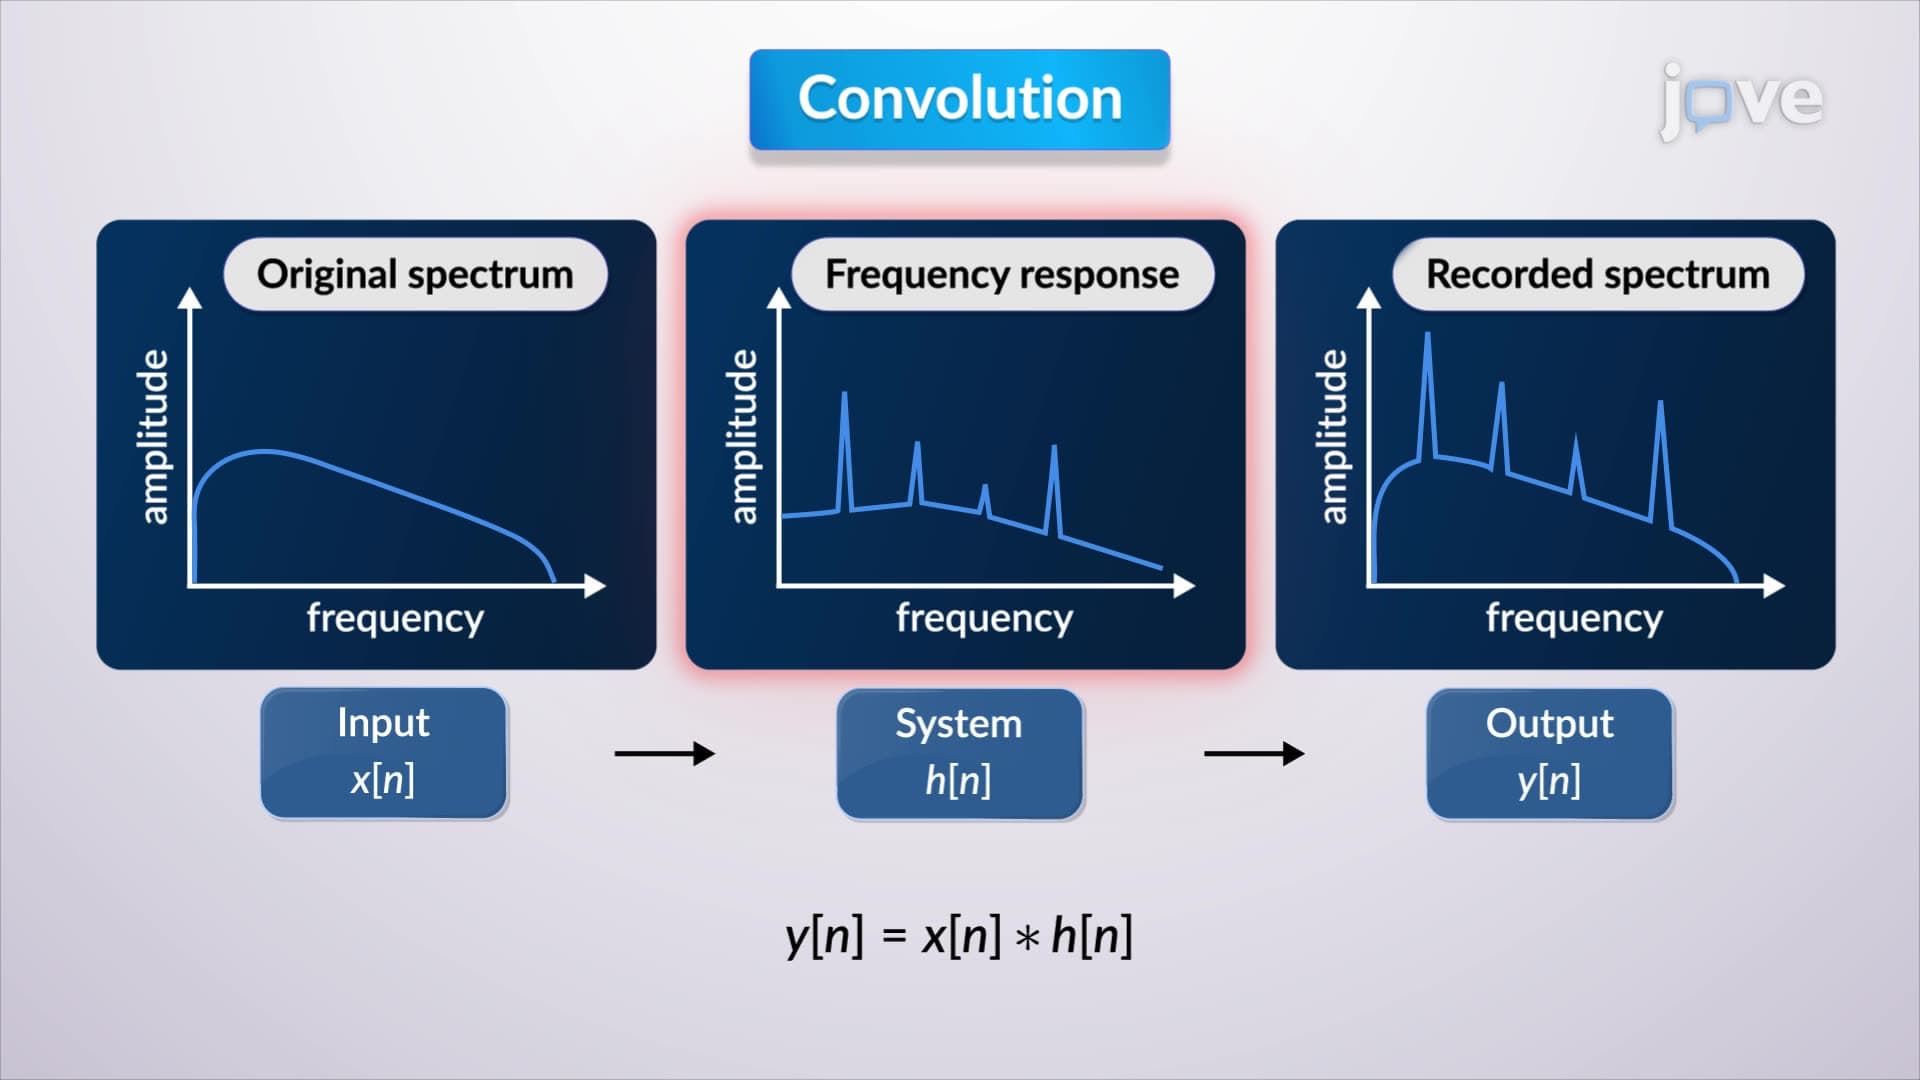
Deconvolution
Deconvolution involves several mathematical techniques to derive the impulse response. One common approach is polynomial division. In this method, the input and output sequences are treated as coefficients of...
 01:25
Relative Motion Analysis using Rotating Axes
However, to express the relative position of point B relative to point A, an additional frame of reference, denoted as x'y', is necessary. This additional frame not only translates but also rotates relative to the fixed frame, making it...