Related Experiment Video
Updated: Apr 29, 2026
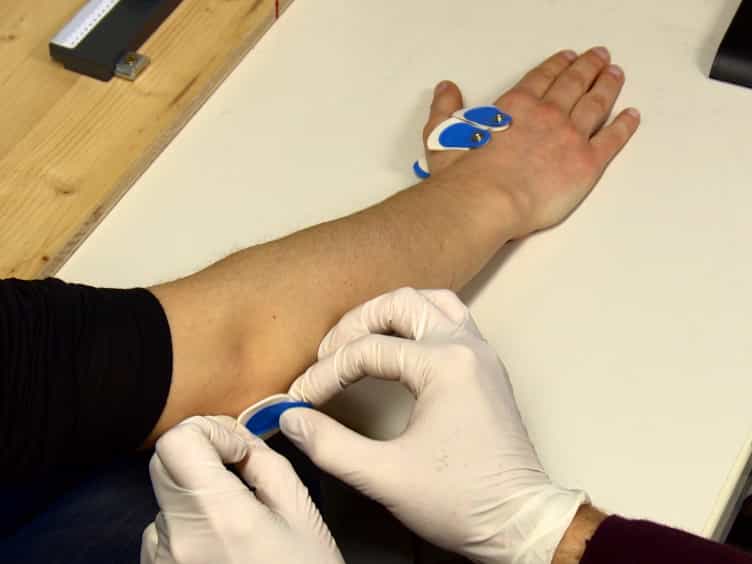

Force and Position Control in Humans - The Role of Augmented Feedback
Published on: June 19, 2016
Grip force control during virtual object interaction: effect of force feedback,accuracy demands, and training

Abstract:
When grasping and manipulating objects, people are able to efficiently modulate their grip force according to the experienced load force. Effective grip force control involves providing enough grip force to prevent the object from slipping, while avoiding excessive force to avoid damage and fatigue. During indirect object manipulation via teleoperation systems or in virtual environments, users often receive limited somatosensory feedback about objects with which they interact. This study examines the effects of force feedback, accuracy demands, and training on grip force control during object interaction in a virtual environment. The task required subjects to grasp and move a virtual object while tracking a target. When force feedback was not provided, subjects failed to couple grip and load force, a capability fundamental to direct object interaction. Subjects also exerted larger grip force without force feedback and when accuracy demands of the tracking task were high. In addition, the presence or absence of force feedback during training affected subsequent performance, even when the feedback condition was switched. Subjects' grip force control remained reminiscent of their employed grip during the initial training. These results motivate the use of force feedback during telemanipulation and highlight the effect of force feedback during training.

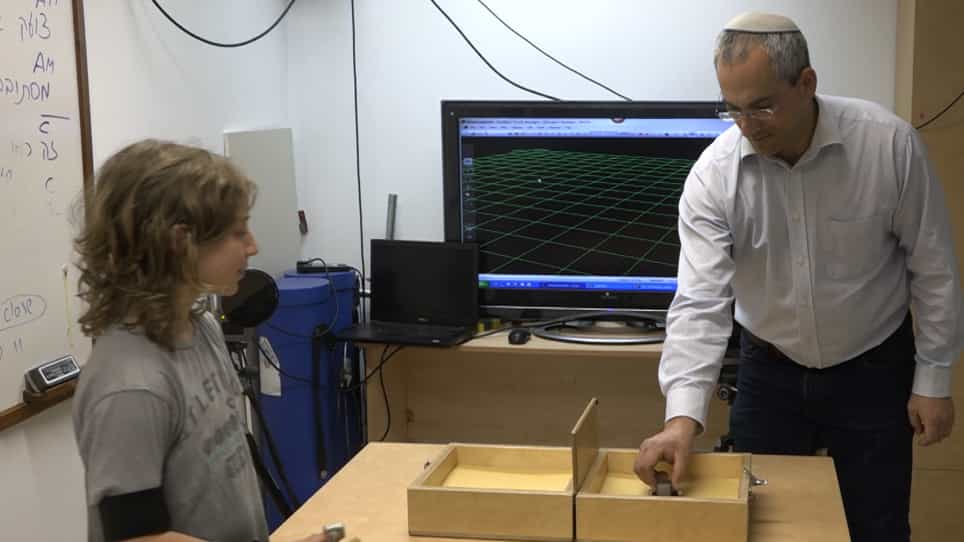
Related Concept Videos
 01:05
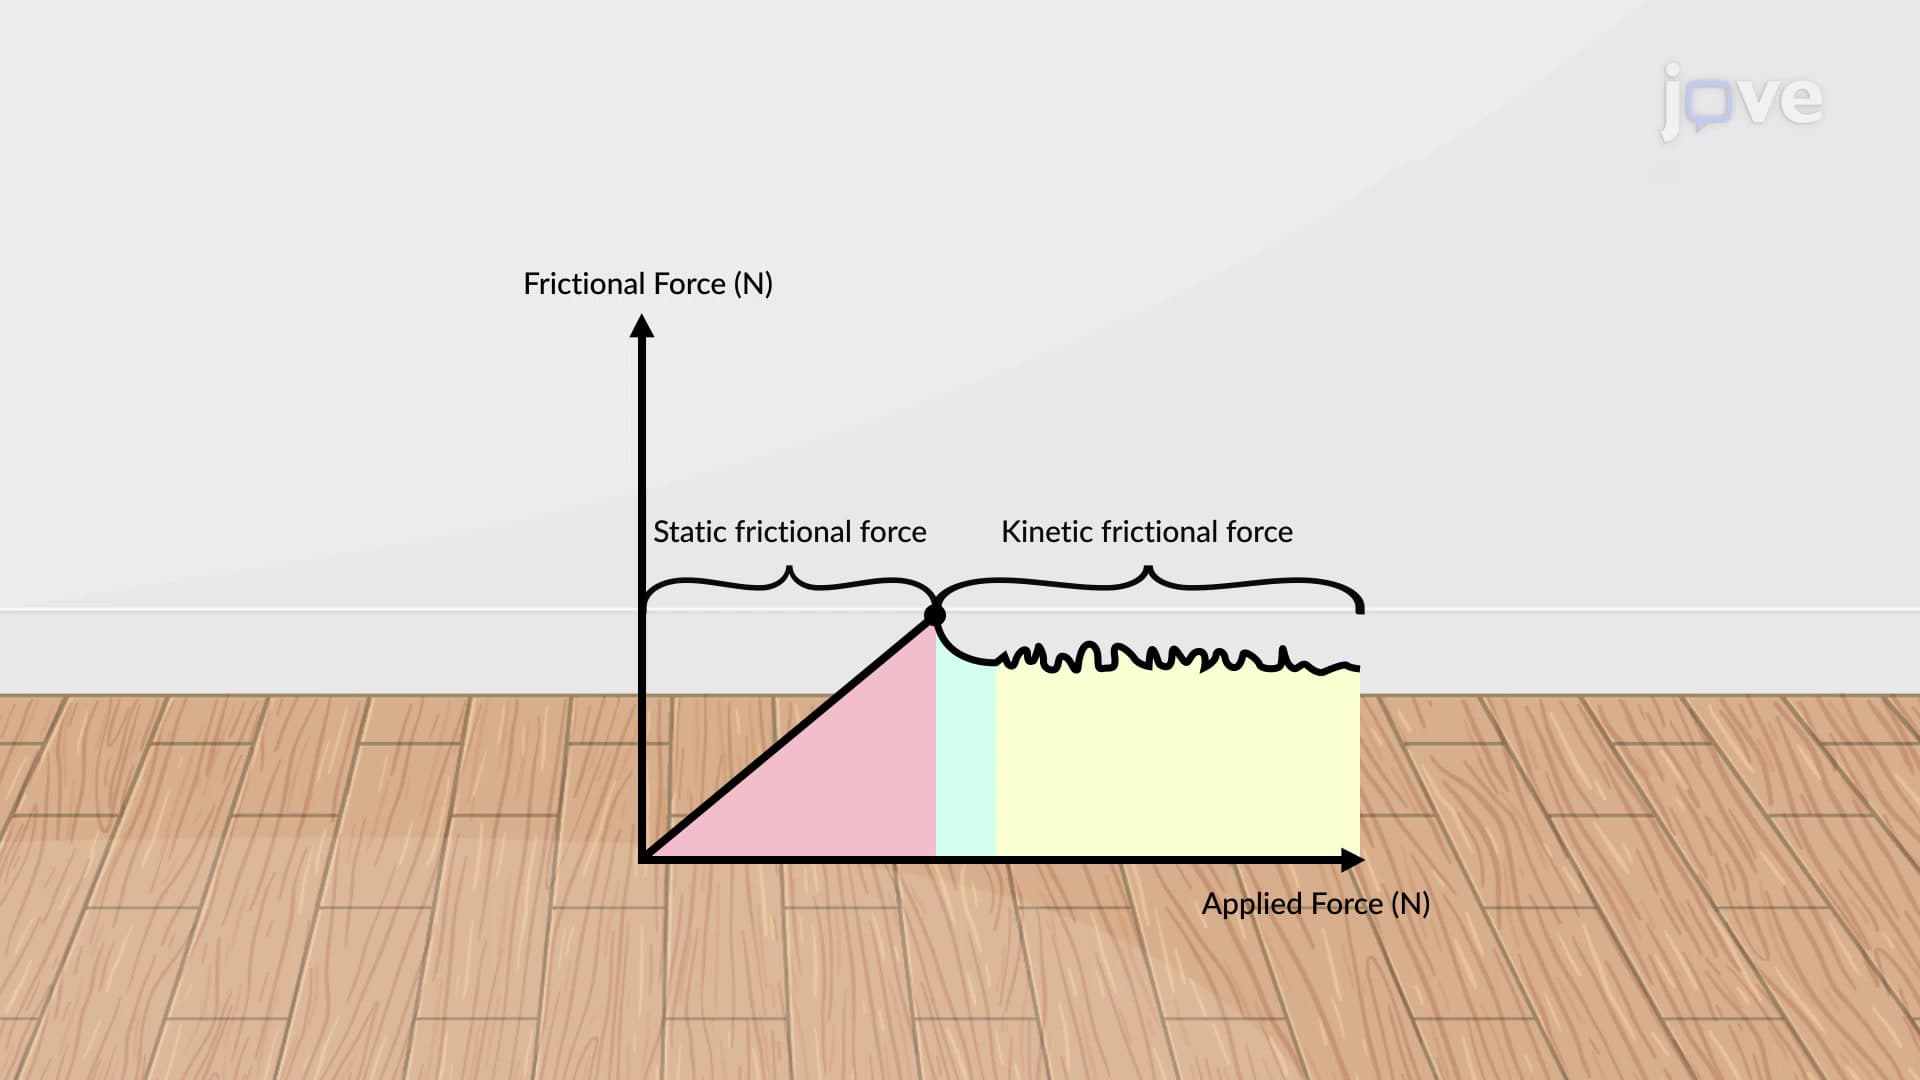
Static and Kinetic Frictional Force
However, if two systems are in contact and are stationary relative to one...
 01:30
Three-Dimensional Force System
 01:30
Three-Dimensional Force System:Problem Solving
To solve a three-dimensional force system, first resolve each force into its respective scalar components. Do this using...
 01:07
Frictional Force
 01:26
Feedback control systems
Linear feedback systems are theoretical models that simplify analysis and design. These systems operate under the principle that their output is directly proportional to their input within certain ranges. For instance, an amplifier in a control system behaves linearly as long as the input signal remains within a specific range. However, most physical systems exhibit inherent nonlinearity...
 01:17
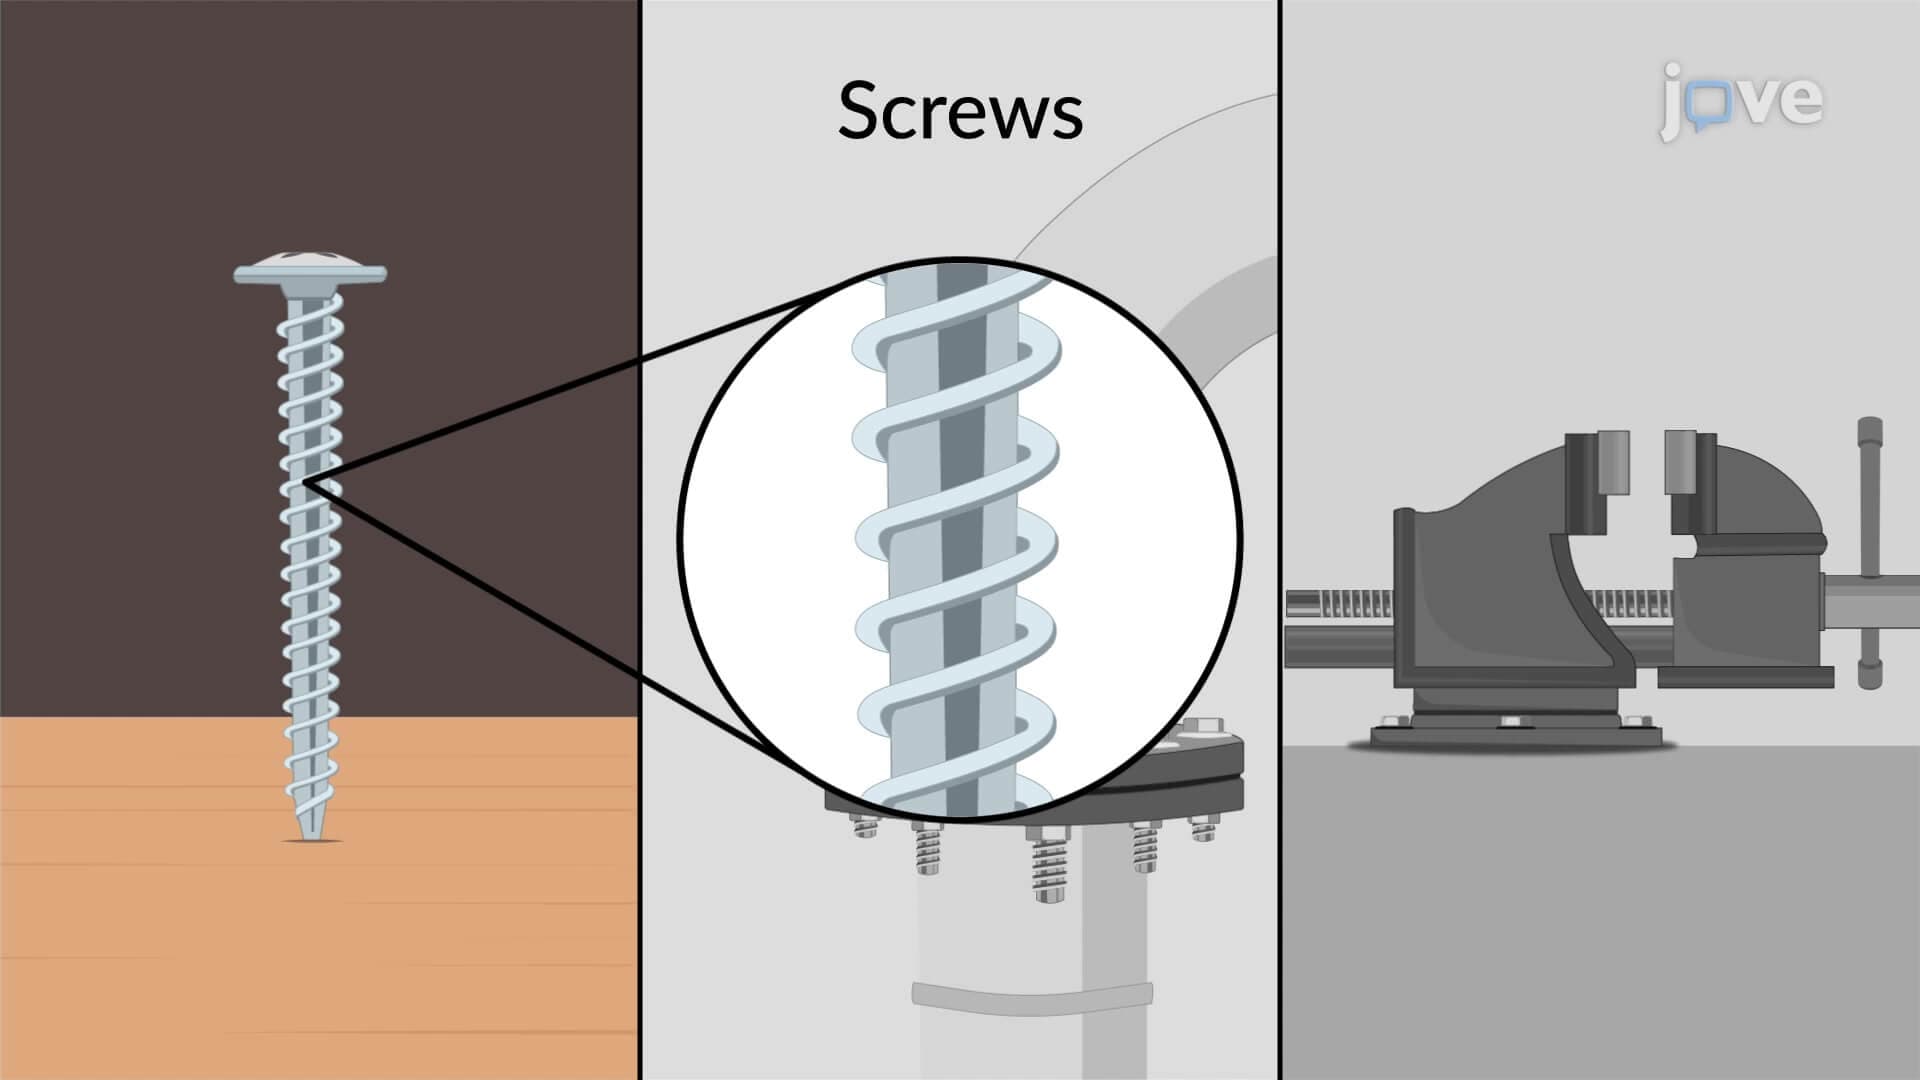
Frictional Forces on Screws
A jack with a square-threaded screw is a mechanical device used to lift heavy loads by applying a force at its handle. When the force is applied, the screw turns, raising the load. The screw can...