Related Experiment Video
Updated: Apr 29, 2026
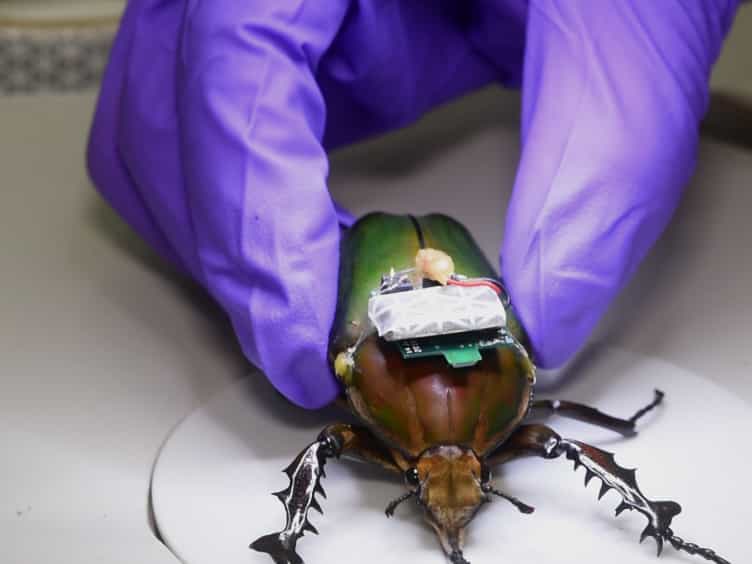
Insect-machine Hybrid System: Remote Radio Control of a Freely Flying Beetle Mercynorrhina torquata
Published on: September 2, 2016
Adaptive control of a millimeter-scale flapping-wing robot
Pakpong Chirarattananon1, Kevin Y Ma, Robert J Wood
1Harvard University School of Engineering and Applied Sciences, Cambridge, MA 02138, USA.

Abstract:
Challenges for the controlled flight of a robotic insect are due to the inherent instability of the system, complex fluid-structure interactions, and the general lack of a complete system model. In this paper, we propose theoretical models of the system based on the limited information available from previous work and a comprehensive flight controller. The modular flight controller is derived from Lyapunov function candidates with proven stability over a large region of attraction. Moreover, it comprises adaptive components that are capable of coping with uncertainties in the system that arise from manufacturing imperfections. We have demonstrated that the proposed methods enable the robot to achieve sustained hovering flights with relatively small errors compared to a non-adaptive approach. Simple lateral maneuvers and vertical takeoff and landing flights are also shown to illustrate the fidelity of the flight controller. The analysis suggests that the adaptive scheme is crucial in order to achieve millimeter-scale precision in flight control as observed in natural insect flight.


Related Concept Videos
 01:17
Open and closed-loop control systems
An open-loop control system operates without feedback from the output. It consists of two primary elements: the controller and the controlled process. The controller receives an input signal...
 01:26
Feedback control systems
Linear feedback systems are theoretical models that simplify analysis and design. These systems operate under the principle that their output is directly proportional to their input within certain ranges. For instance, an amplifier in a control system behaves linearly as long as the input signal remains within a specific range. However, most physical systems exhibit inherent nonlinearity...
 01:22
Controller Configurations
Control-system compensation involves various configurations, most commonly series or cascade compensation, in which the controller...
 01:24
One-Degree-of-Freedom System
A one-degree-of-freedom system is defined by an independent variable that determines its state and behavior. One example of a one-degree-of-freedom system is a simple harmonic oscillator, such as a...
 01:24
PI Controller: Design
 01:10
Control Systems
At the heart...