Controller design for TS models using delayed nonquadratic Lyapunov functions
Related Experiment Video
Updated: Apr 27, 2026
Age-dependent Dynamics of Locomotion in Caenorhabditis elegans: A Lyapunov Exponent Analysis
Published on: September 23, 2025

Abstract:
In the last few years, nonquadratic Lyapunov functions have been more and more frequently used in the analysis and controller design for Takagi-Sugeno fuzzy models. In this paper, we developed relaxed conditions for controller design using nonquadratic Lyapunov functions and delayed controllers and give a general framework for the use of such Lyapunov functions. The two controller design methods developed in this framework outperform and generalize current state-of-the-art methods. The proposed methods are extended to robust and H∞ control and α -sample variation.

Related Concept Videos
 01:21
Linear Approximation in Time Domain
For a simple pendulum with a mass evenly distributed along its length and the center of mass located at half the pendulum's length,...
 01:23
Linear time-invariant Systems
The input-output behavior of an LTI system can be fully defined by its response to an impulsive excitation at its input. Once this impulse response is known, the system's reaction to any other input can be...
 01:26
Linear Approximation in Frequency Domain
In contrast, nonlinear systems do not inherently possess these properties. However, for small deviations around an operating point, a nonlinear system can often be approximated as linear....
 01:26
PD Controller: Design
Designing a continuous-data controller requires selecting and linking components like adders and integrators, which are fundamental in Proportional,...
 01:26
Feedback control systems
Linear feedback systems are theoretical models that simplify analysis and design. These systems operate under the principle that their output is directly proportional to their input within certain ranges. For instance, an amplifier in a control system behaves linearly as long as the input signal remains within a specific range. However, most physical systems exhibit inherent nonlinearity...
 01:21
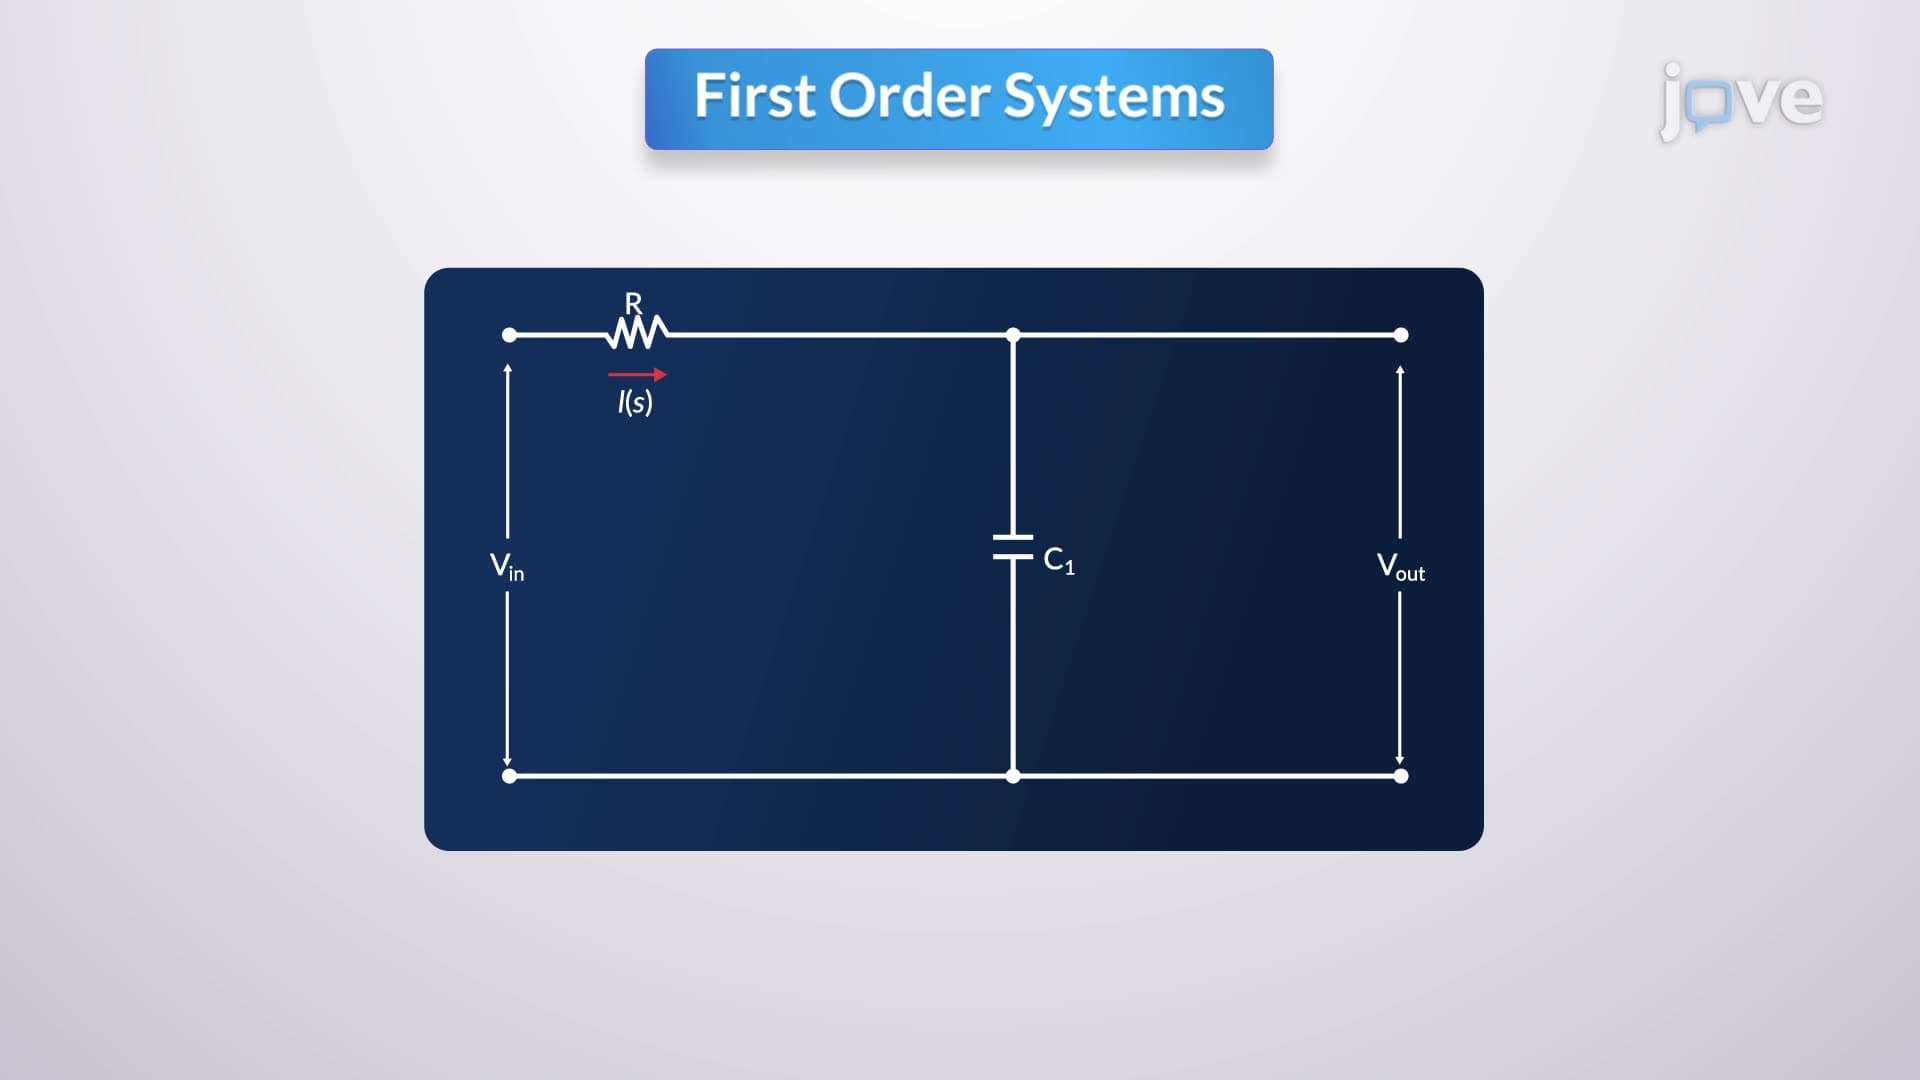
First Order Systems
When a first-order system is subjected to a unit-step input, its response is characterized by its transfer function. By applying the Laplace transform of the unit-step input to the transfer function, expanding the...