Related Experiment Video
Updated: Apr 27, 2026

A Structured Rehabilitation Protocol for Improved Multifunctional Prosthetic Control: A Case Study
Published on: November 6, 2015
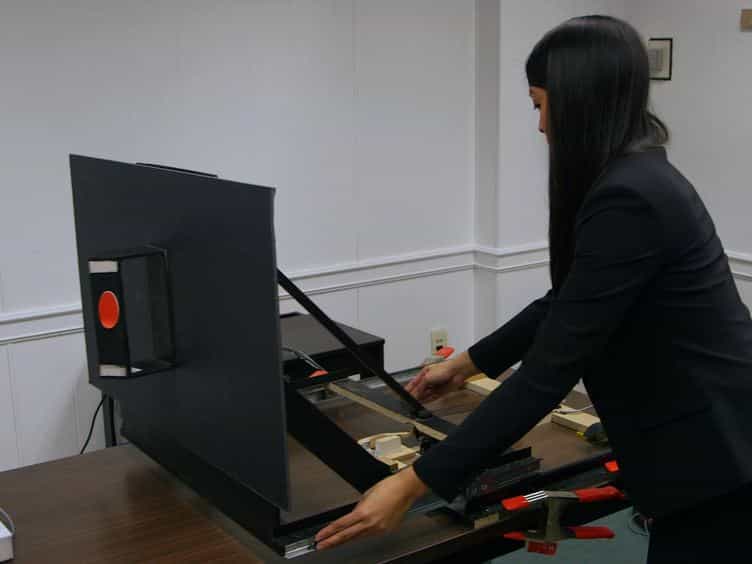
3DOM: a 3 degree of freedom manipulandum to investigate redundant motor control

Abstract:
This paper presents a novel robotic interface to investigate the neuromechanical control of redundant planar arm movements. A unique aspect of this device is the third axis by which the wrist, and hence the pose of the arm can be fully constrained. The topology is based on a 5R, closed loop pantograph, with a decoupled wrist flexion/extension cable actuated mechanism. The design and characterization (in terms of range of motion, impedance, friction and dynamics) are described in this paper. This device is lightweight, safe and has high force capabilities and low impedance. Simple experiments illustrate the advantages of this device for the investigation of redundant motor control in humans.
More Related Videos
Related Concept Videos
 01:18
Hierarchy of Motor Control
 01:22
Controller Configurations
Control-system compensation involves various configurations, most commonly series or cascade compensation, in which the controller...
 01:24
One-Degree-of-Freedom System
A one-degree-of-freedom system is defined by an independent variable that determines its state and behavior. One example of a one-degree-of-freedom system is a simple harmonic oscillator, such as a...
 01:30
Three-Dimensional Force System:Problem Solving
To solve a three-dimensional force system, first resolve each force into its respective scalar components. Do this using...