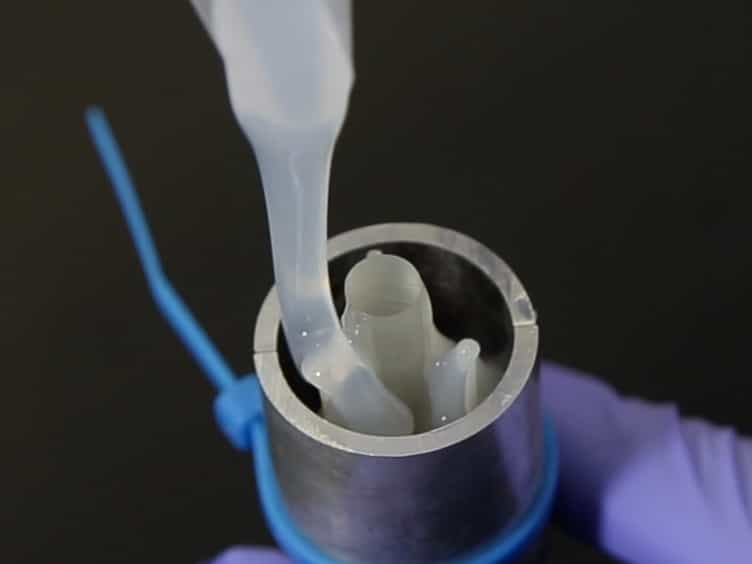
Related Experiment Video
Updated: Apr 20, 2026
Design and Implementation of a Bespoke Robotic Manipulator for Extra-corporeal Ultrasound
Published on: January 7, 2019
Manipulator Design and Operation for a Six-Degree-of-Freedom Handheld Tremor-Canceling Microsurgical Instrument
Sungwook Yang1, Robert A MacLachlan1, Cameron N Riviere1
1Robotics Institute, Carnegie Mellon University, Pittsburgh, PA 15213 USA.

Abstract:
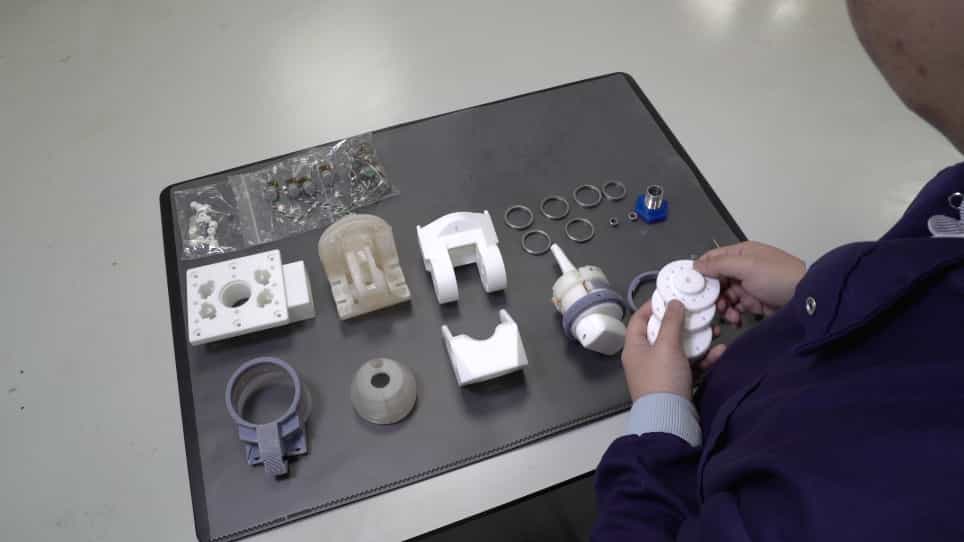
This paper presents the design and actuation of a six-degree-of-freedom (6-DOF) manipulator for a handheld instrument, known as "Micron," which performs active tremor compensation during microsurgery. The design incorporates a Gough-Stewart platform based on piezoelectric linear motor, with a specified minimum workspace of a cylinder 4 mm long and 4 mm in diameter at the end-effector. Given the stall force of the motors and the loading typically encountered in vitreoretinal microsurgery, the dimensions of the manipulator are optimized to tolerate a transverse load of 0.2 N on a remote center of motion near the midpoint of the tool shaft. The optimization yields a base diameter of 23 mm and a height of 37 mm. The fully handheld instrument includes a custom-built optical tracking system for control feedback, and an ergonomic housing to serve as a handle. The manipulation performance was investigated in both clamped and handheld conditions. In positioning experiments with varying side loads, the manipulator tolerates side load up to 0.25 N while tracking a sinusoidal target trajectory with less than 20 μm error. Physiological hand tremor is reduced by about 90% in a pointing task, and error less than 25 μm is achieved in handheld circle-tracing.