On computation of stabilizing loop gain and delay ranges for bi-proper delay systems

Binh Nguyen Le1, Qing-Guo Wang1, Tong Heng Lee1
1Department of Electrical and Computer Engineering, National University of Singapore, 119260 Singapore.

Abstract:
A graphical method for exactly computing the stabilizing loop gain and delay ranges was proposed [Le BN, Wang Q-G, Lee T-H. Development of D-decomposition method for computing stabilizing gain ranges for general delay systems. J Process Control 2012] for a strictly proper process by determining the boundary functions which may change system׳s stability. A bi-proper process is rare but causes great complications for the method, due to the new phenomena that do not exist for a strictly proper process, such as a non-zero gain at infinity frequency, which may cause infinite intersections of boundary functions within a finite delay range. This paper addresses such a kind of processes and develops a general method that can produce the exact and complete set of the loop gain and delay for closed-loop stabilization, which is hard to find with analytical methods.


Related Concept Videos
 01:21
Control System Problem
When forming a closed-loop system, issues can arise if the poles cross into the unstable region, leading to potential...
 01:19
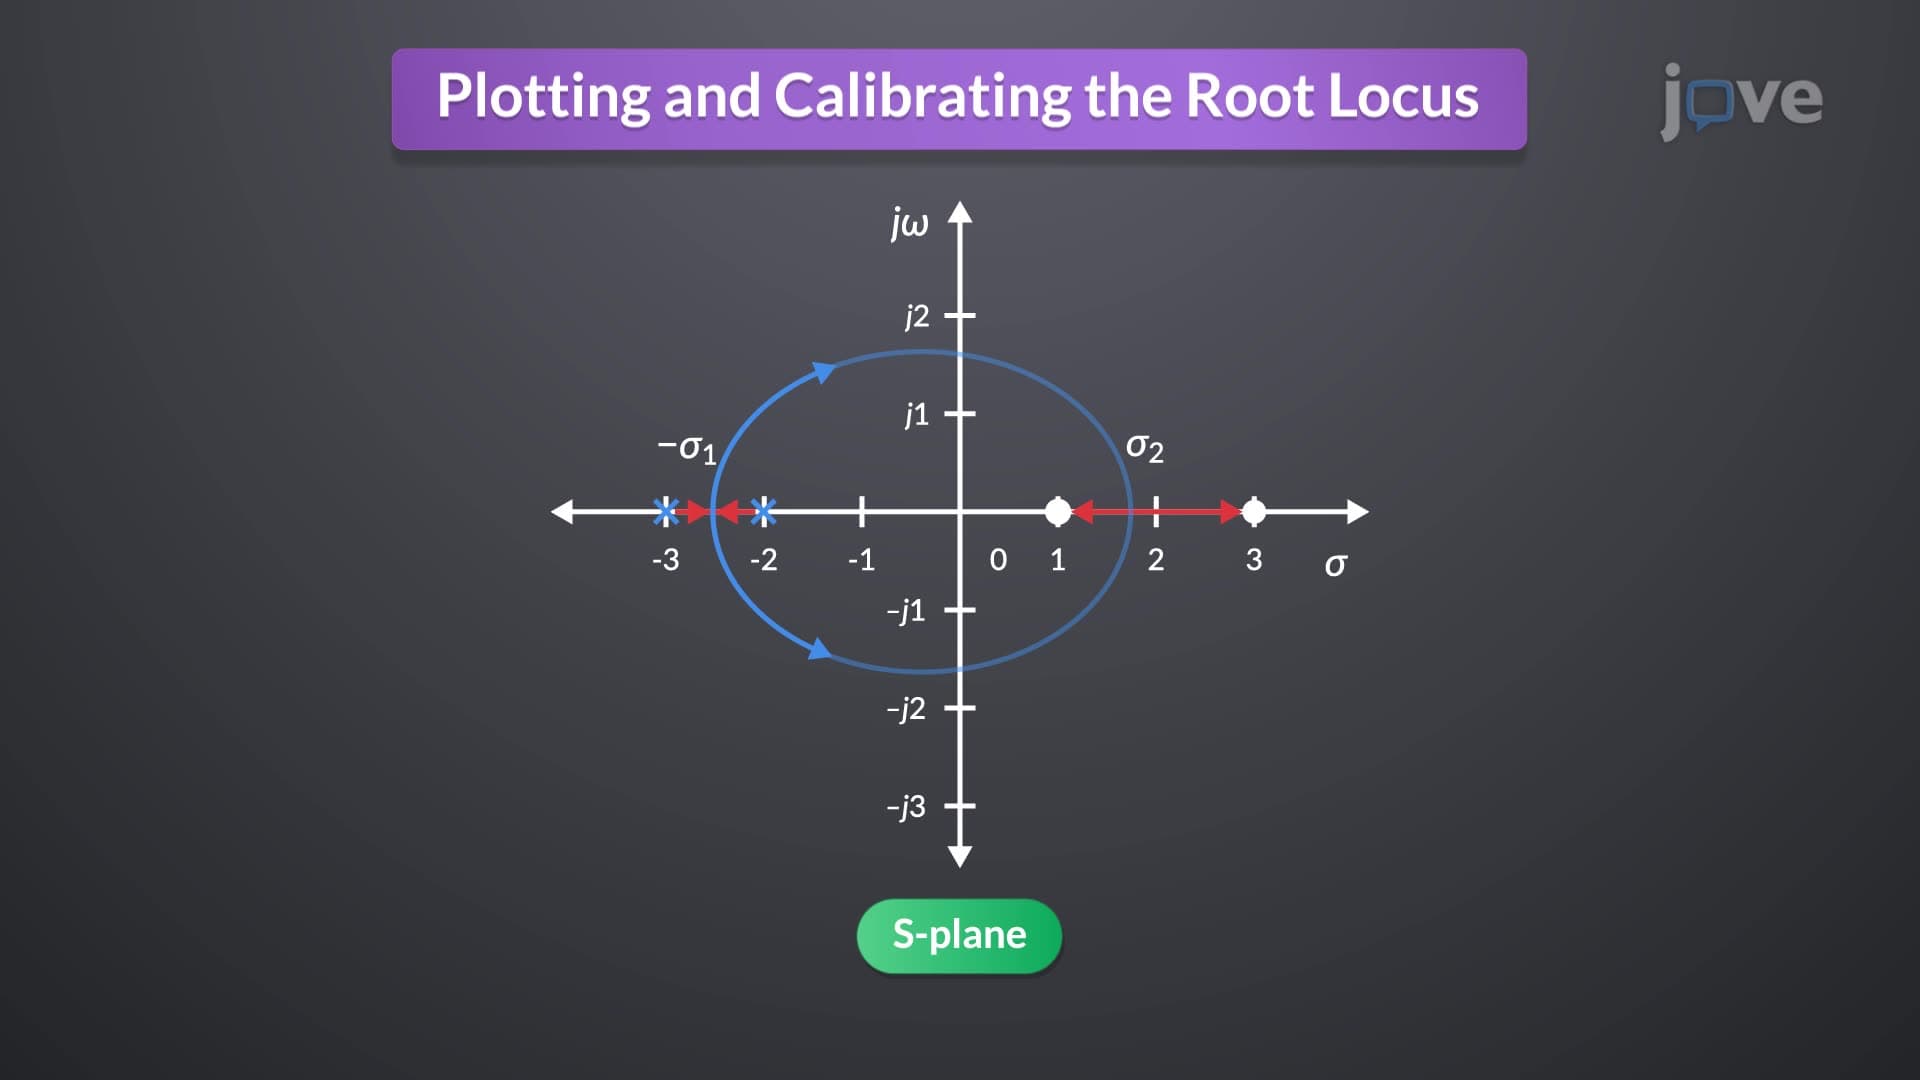
Plotting and Calibrating the Root Locus
The maximum gain occurs at the breakaway points between open-loop poles on the real axis, while the minimum gain is...
 01:27
Time and frequency -Domain Interpretation of PI Control
Acting as a low-pass filter, the PI controller slows the system's response and extends settling times. This requires...
 01:24
Pole and System Stability
Simple poles are unique roots of the denominator polynomial. Each simple pole corresponds to a distinct solution to the system's characteristic equation, typically resulting in exponential decay terms in the system's...
 01:24
Effects of feedback
Feedback significantly modifies the gain of a control system. The gain of a system without feedback is altered by a factor of one plus GH, where G represents...
 01:15
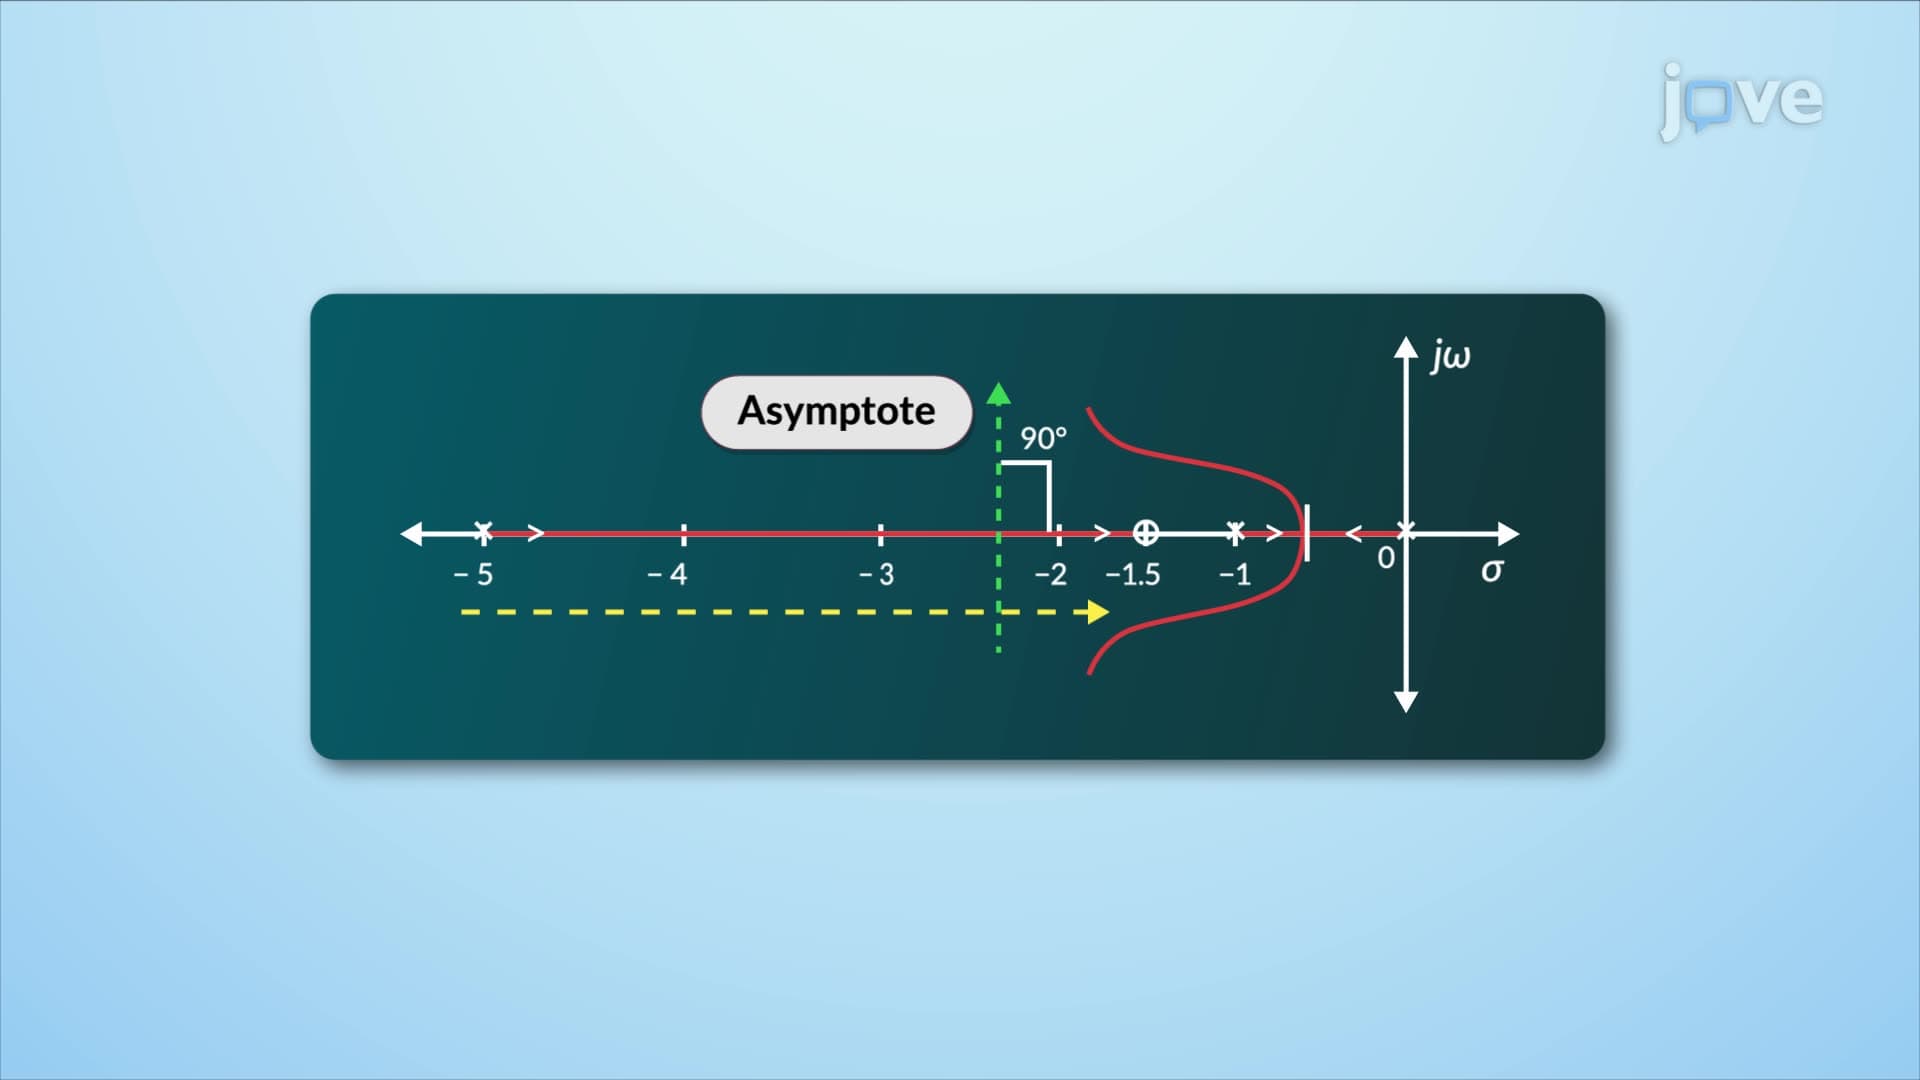
Construction of Root Locus
For positive gain values, the root locus exists on the real axis to the left of an odd number of finite open-loop poles or zeros. The root locus starts at the open-loop poles and traces the paths of the closed-loop poles as the gain...