Related Experiment Video
Updated: Apr 19, 2026


Robotic Mirror Therapy System for Functional Recovery of Hemiplegic Arms
Published on: August 15, 2016
Alteration of a motor learning rule under mirror-reversal transformation does not depend on the amplitude of visual
Shoko Kasuga1, Makiko Kurata1, Meigen Liu2
1Department of Biosciences and Informatics, Faculty of Science and Technology, Keio University, 3-14-1 Hiyoshi, Kohoku-ku, Yokohama, Kanagawa 223-8522, Japan.

Abstract:
Human's sophisticated motor learning system paradoxically interferes with motor performance when visual information is mirror-reversed (MR), because normal movement error correction further aggravates the error. This error-increasing mechanism makes performing even a simple reaching task difficult, but is overcome by alterations in the error correction rule during the trials. To isolate factors that trigger learners to change the error correction rule, we manipulated the gain of visual angular errors when participants made arm-reaching movements with mirror-reversed visual feedback, and compared the rule alteration timing between groups with normal or reduced gain. Trial-by-trial changes in the visual angular error was tracked to explain the timing of the change in the error correction rule. Under both gain conditions, visual angular errors increased under the MR transformation, and suddenly decreased after 3-5 trials with increase. The increase became degressive at different amplitude between the two groups, nearly proportional to the visual gain. The findings suggest that the alteration of the error-correction rule is not dependent on the amplitude of visual angular errors, and possibly determined by the number of trials over which the errors increased or statistical property of the environment. The current results encourage future intensive studies focusing on the exact rule-change mechanism.
Related Concept Videos
 01:20
Transformations of Functions III
 01:34
Woodward–Hoffmann Selection Rules and Microscopic Reversibility
 01:29
Transformations of Functions II
 01:20
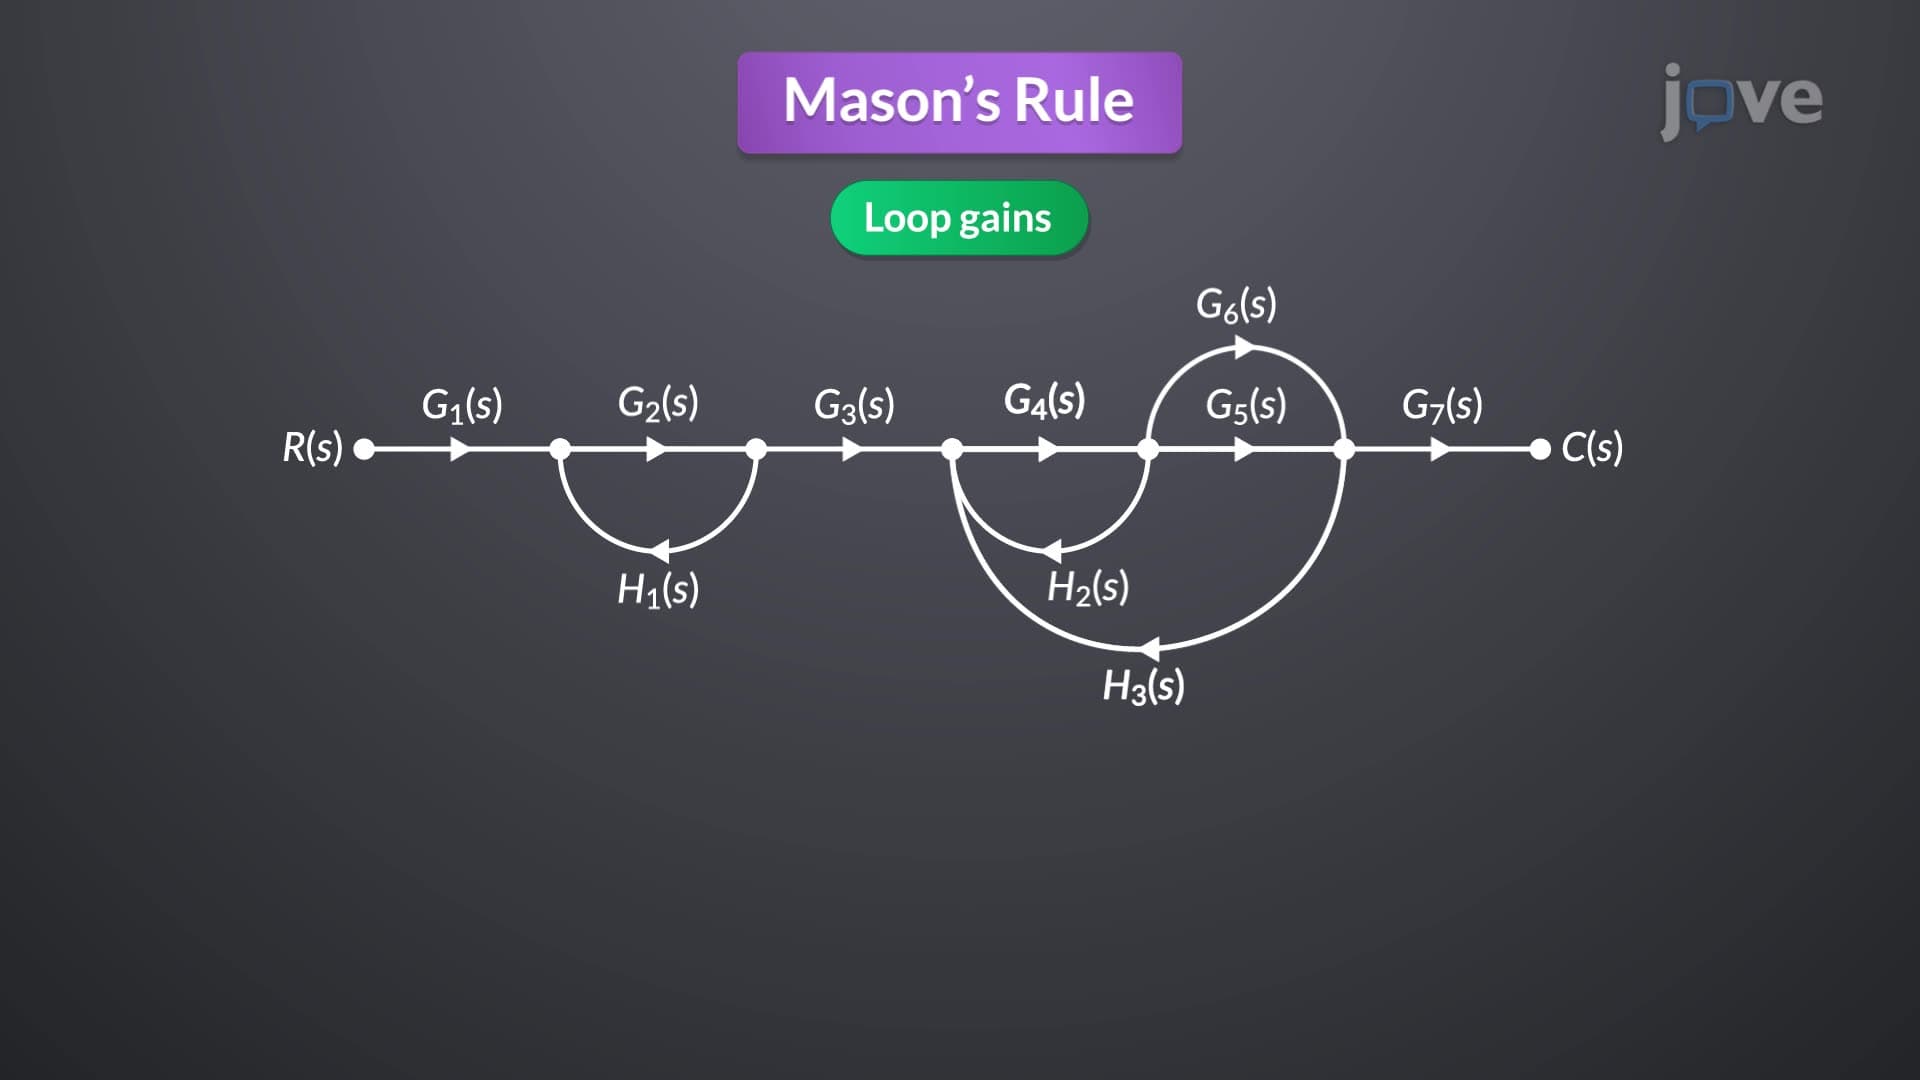
Mason's Rule
Loop gain is determined by identifying and tracing a path from a node back to itself. This involves computing the product of branch gains along the loop. Each loop's gain is crucial for further...
 01:26
Transformation
 01:12
Observational Learning