A continuum body force sensor designed for flexible surgical robotics devices
Related Experiment Video
Updated: Apr 18, 2026
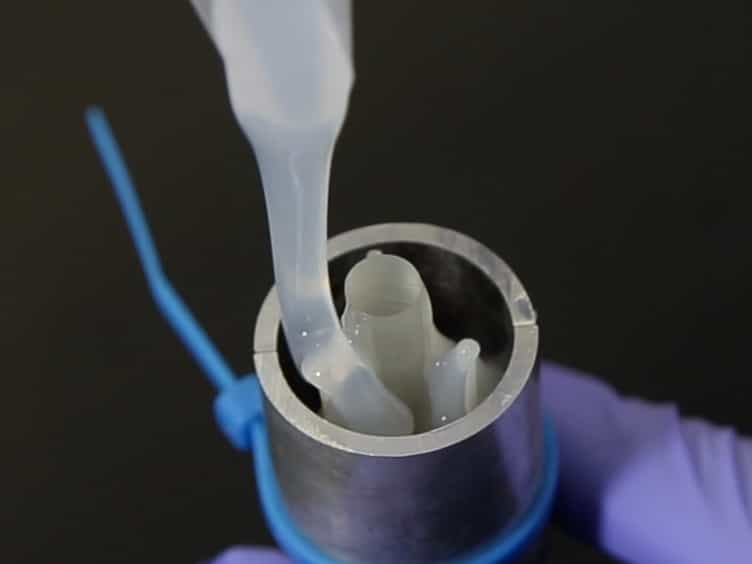
Design and Fabrication of an Elastomeric Unit for Soft Modular Robots in Minimally Invasive Surgery
Published on: November 14, 2015

Abstract:
This paper presents a novel three-axis force sensor based on optical photo interrupters and integrated with the robot arm STIFF-FLOP (STIFFness controllable Flexible and Learnable Manipulator for Surgical Operations) to measure external interacting forces and torques. The ring-shape bio-compatible sensor presented here embeds the distributed actuation and sensing system of the STIFF-FLOP manipulator and is applicable to the geometry of its structure as well to the structure of any other similar soft robotic manipulator. Design and calibration procedures of the device are introduced: experimental results allow defining a stiffness sensor matrix for real-time estimation of force and torque components and confirm the usefulness of the proposed optical sensing approach.
Related Concept Videos
 01:30
Three-Dimensional Force System
 01:22
Mechanical Systems
 01:25
Ultrasound II: Endoscopic Ultrasound and FibroScan
Endoscopic Ultrasound (EUS):
 01:13
Cell-matrix's Response to Mechanical Forces
Anchoring junctions mechanically attach a cell to the...
 01:15
Torque Free Motion
 01:20
Two-Dimensional Force System