Related Experiment Video
Updated: Apr 18, 2026


Experimental Methods to Study Human Postural Control
Published on: September 11, 2019
Stability analysis of a class of fractional order nonlinear systems with order lying in (0, 2)
Ruoxun Zhang1, Gang Tian2, Shiping Yang2
1College of Teacher Education, Xingtai University, Xingtai 054001, China; College of Physics Science and Information Engineering, Hebei Normal University, Shijiazhuang 050016, China.

Abstract:
This paper investigates the stability of n-dimensional fractional order nonlinear systems with commensurate order 0 <α<2. By using the Mittag-Leffler function, Laplace transform and the Gronwall-Bellman lemma, one sufficient condition is attained for the local asymptotical stability of a class of fractional order nonlinear systems with order lying in (0, 2). According to this theory, stabilizing a class of fractional order nonlinear systems only need a linear state feedback controller. Simulation results demonstrate the effectiveness of the proposed theory.
More Related Videos
 06:44
Age-dependent Dynamics of Locomotion in Caenorhabditis elegans: A Lyapunov Exponent Analysis
Published on: September 23, 2025
 06:45
Design and Application of a Fault Detection Method Based on Adaptive Filters and Rotational Speed Estimation for an Electro-Hydrostatic Actuator
Published on: October 28, 2022
Related Concept Videos
 01:24
Pole and System Stability
Simple poles are unique roots of the denominator polynomial. Each simple pole corresponds to a distinct solution to the system's characteristic equation, typically resulting in exponential decay terms in the system's...
 01:21
Linear Approximation in Time Domain
For a simple pendulum with a mass evenly distributed along its length and the center of mass located at half the pendulum's length,...
 01:28
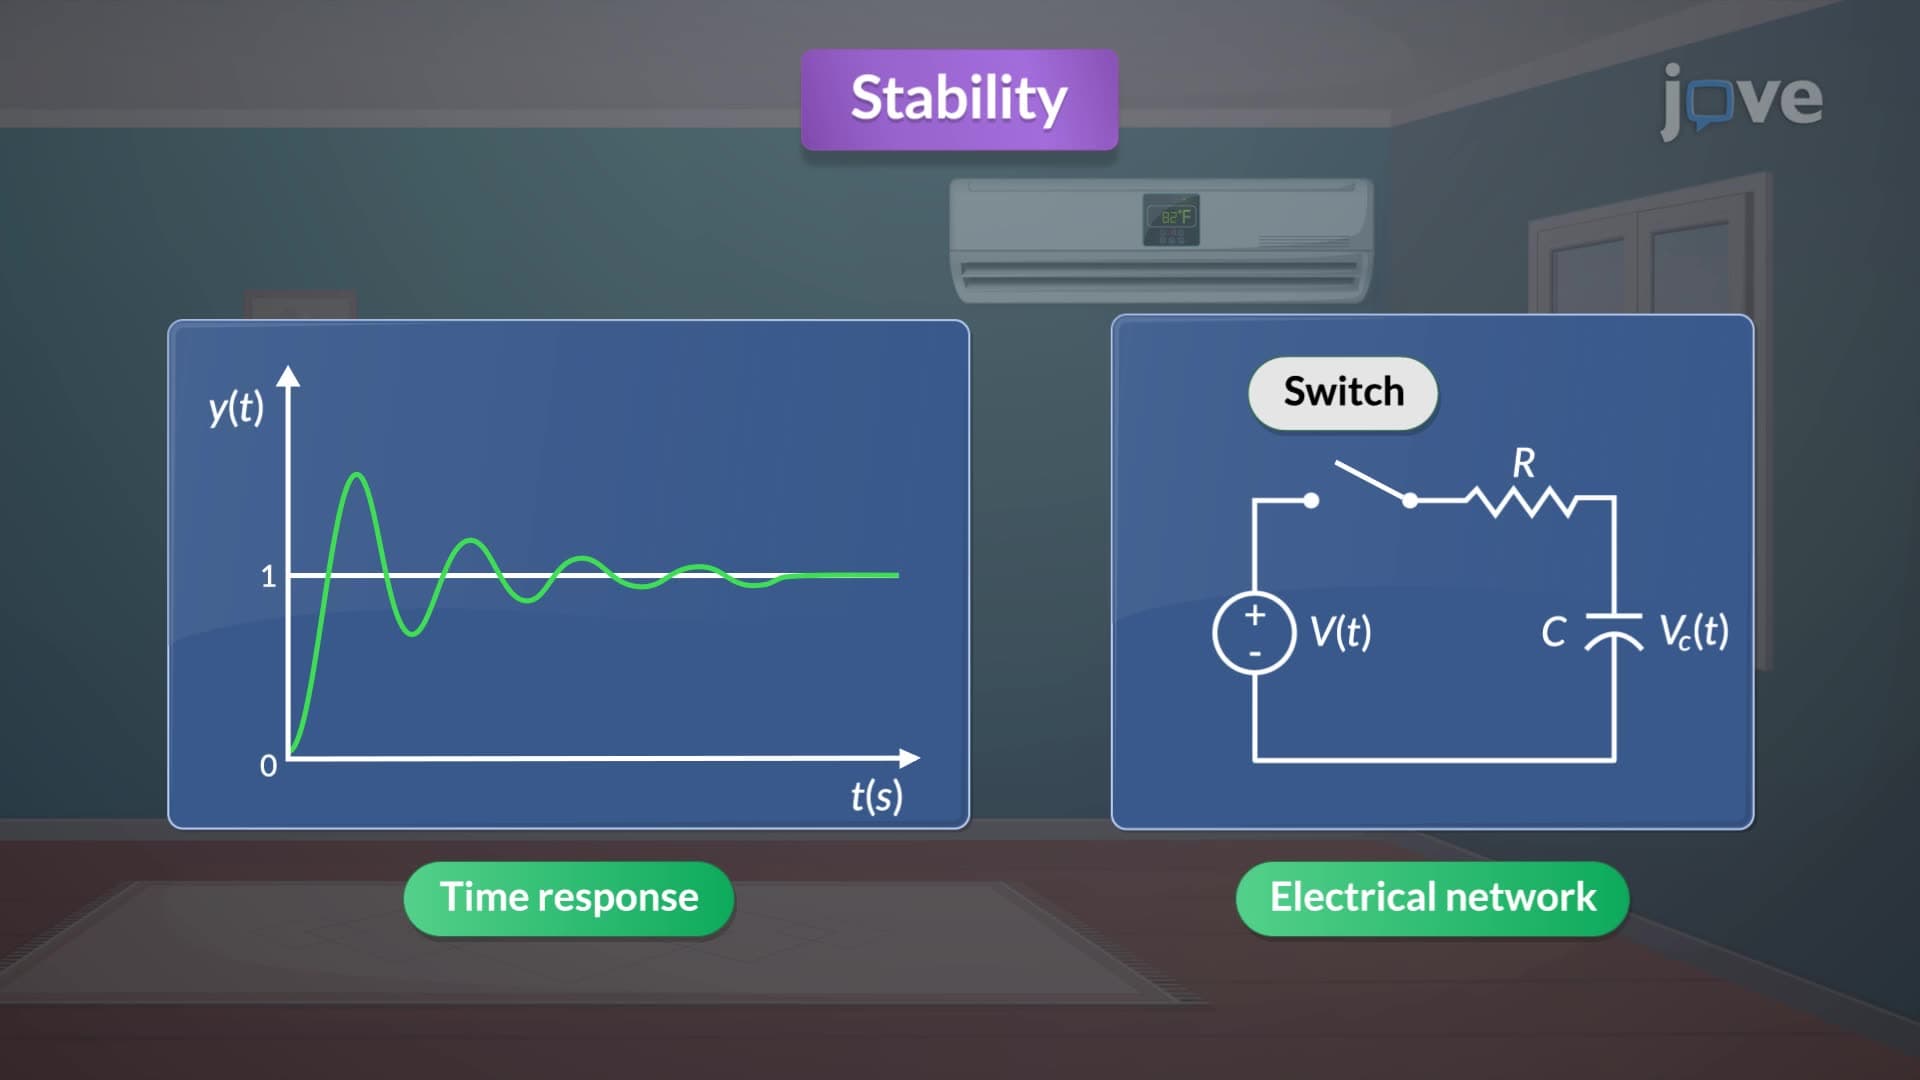
Stability
The stability of an LTI system is determined by the roots of its characteristic equation, known as poles. A system is stable if it produces a bounded...
 01:21
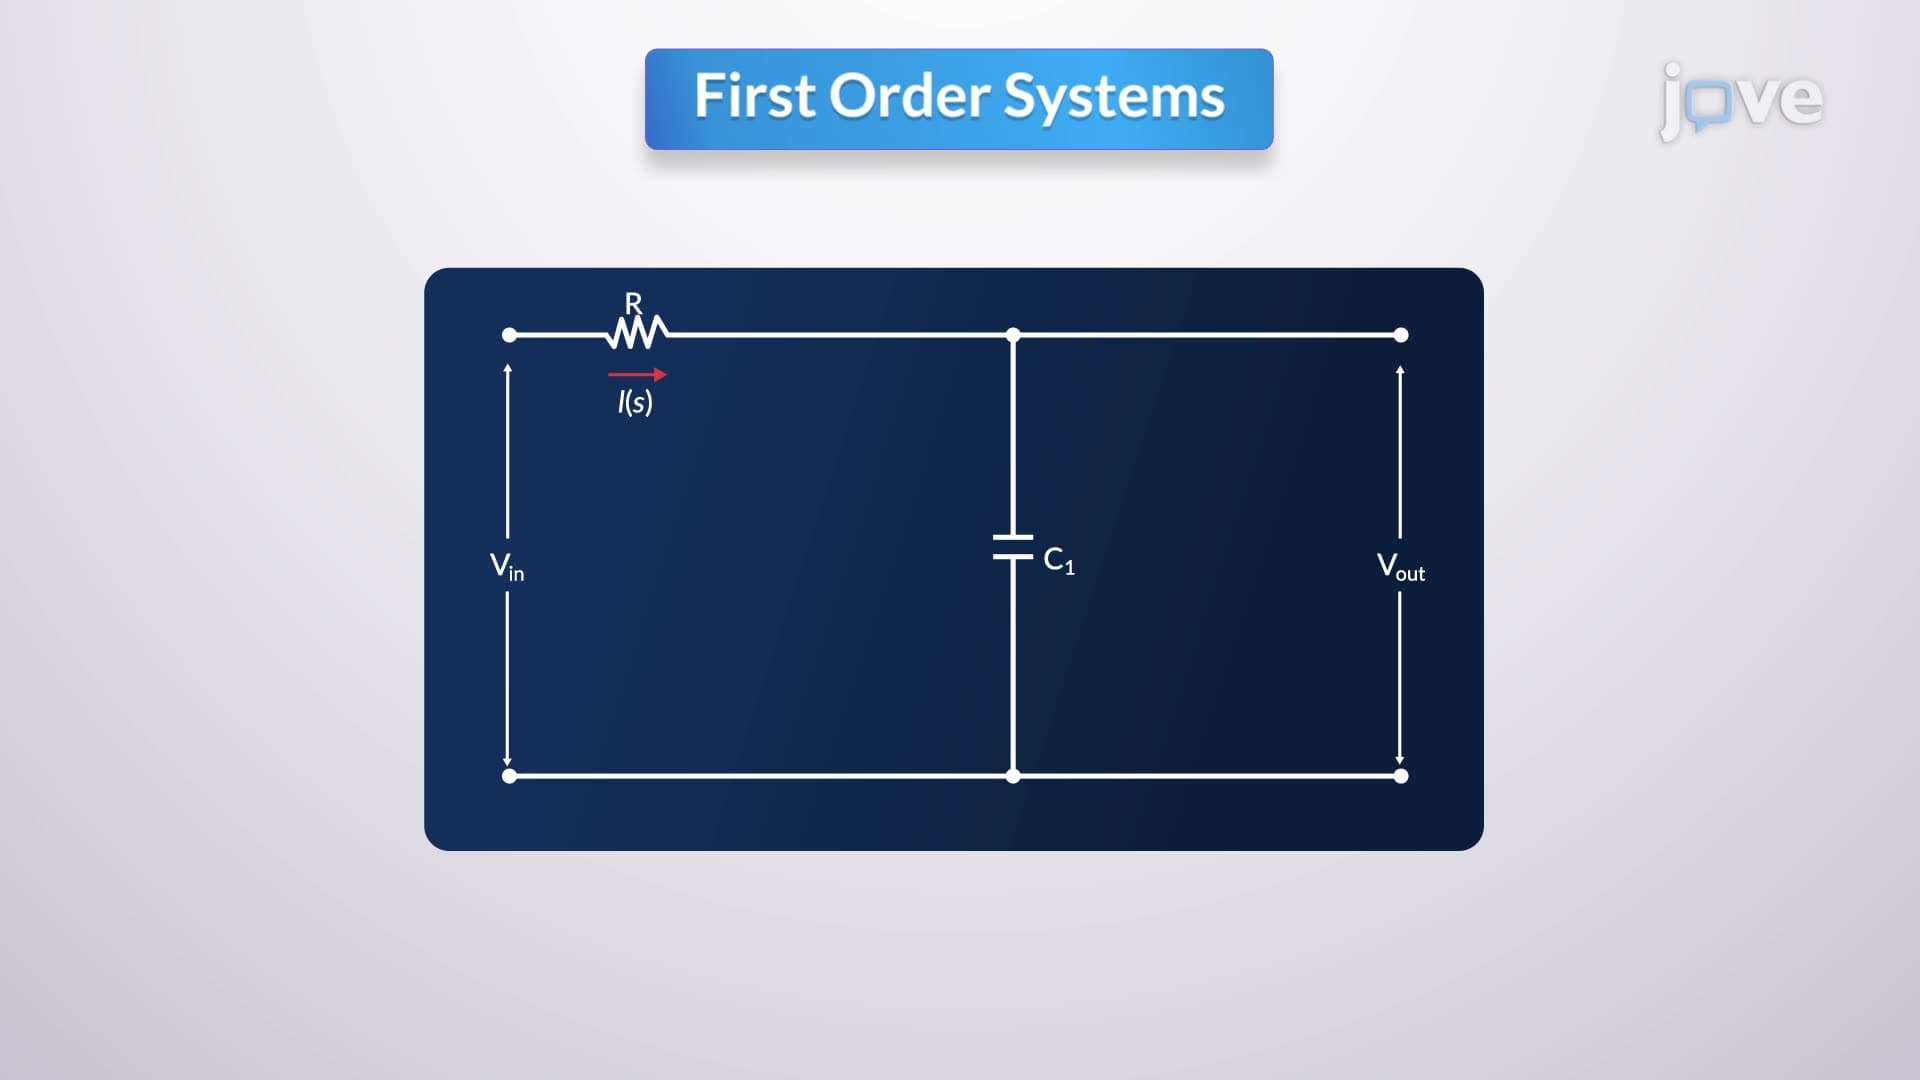
First Order Systems
When a first-order system is subjected to a unit-step input, its response is characterized by its transfer function. By applying the Laplace transform of the unit-step input to the transfer function, expanding the...
 01:26
Linear Approximation in Frequency Domain
In contrast, nonlinear systems do not inherently possess these properties. However, for small deviations around an operating point, a nonlinear system can often be approximated as linear....
 01:18
Second Order systems II