Dynamic message-passing equations for models with unidirectional dynamics

Andrey Y Lokhov1, Marc Mézard2, Lenka Zdeborová3

  • 1Université Paris-Sud/CNRS, LPTMS, UMR8626, Bât. 100, 91405 Orsay, France.

Related Concept Videos

Modeling with Differential Equations01:25

Modeling with Differential Equations
Population dynamics can be described mathematically by considering the population size P(t) as a function of time. The rate of change of the population is then represented by the derivative of P(t). A simple assumption is that the rate of growth is proportional to the size of the population itself. This leads to an exponential growth model, where the population increases rapidly without bound. While this is a useful first approximation, it does not reflect realistic long-term...
289
Relation between Mathematical Equations and Block Diagrams01:20

Relation between Mathematical Equations and Block Diagrams
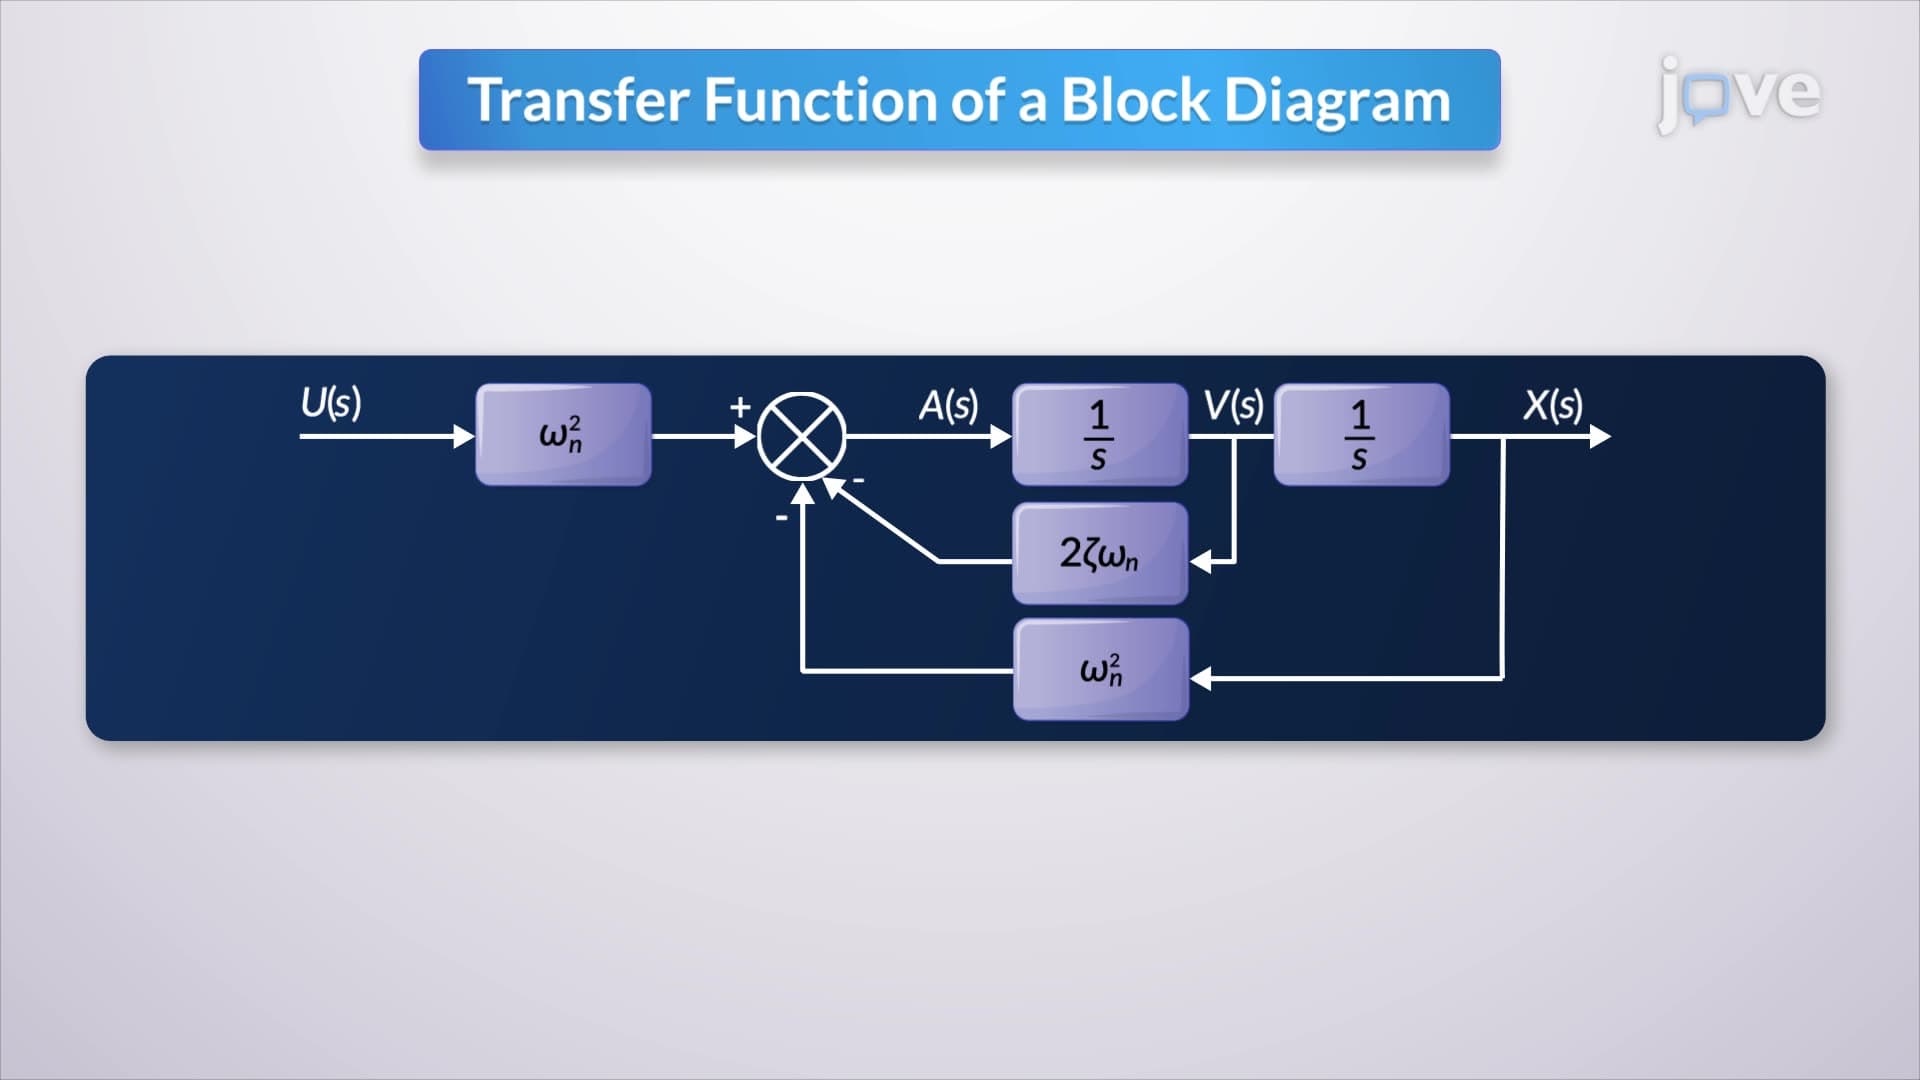
In a spring-mass-damper system, the second-order differential equation describes the dynamic behavior of the system. When transformed into the Laplace domain under zero initial conditions, this equation can be effectively analyzed and manipulated. The transformation into the Laplace domain converts differential equations into algebraic equations, simplifying the process of isolating the output.
3.9K
Pharmacodynamic Models: Link Model and Systems Pharmacodynamic Model01:14

Pharmacodynamic Models: Link Model and Systems Pharmacodynamic Model

The link model is a fundamental pharmacokinetic-pharmacodynamic (PK–PD) approach to account for delayed drug responses when the observed effect does not immediately correlate with the drug's plasma concentration peak. This delay is mathematically addressed by introducing an effect compartment concentration, Ce, which is kinetically linked to the plasma concentration, Cp, via a first-order rate constant, ke0. The linkage allows for a more accurate prediction of drug effects over time. A...
128
Kinematic Equations - III01:18

Kinematic Equations - III

The first two kinematic equations have time as a variable, but the third kinematic equation is independent of time. This equation expresses final velocity as a function of the acceleration and distance over which it acts. The fourth kinematic equation does not have an acceleration term and provides the final position of the object at time t in terms of the initial and final velocities. This equation is useful when the value of the constant acceleration is unknown.
Using the kinematic equations,...
12.6K
Linear Approximation in Time Domain01:21

Linear Approximation in Time Domain

Nonlinear systems often require sophisticated approaches for accurate modeling and analysis, with state-space representation being particularly effective. This method is especially useful for systems where variables and parameters vary with time or operating conditions, such as in a simple pendulum or a translational mechanical system with nonlinear springs.
For a simple pendulum with a mass evenly distributed along its length and the center of mass located at half the pendulum's length,...
427
Introduction to Differential Equations01:20

Introduction to Differential Equations

A differential equation is a mathematical expression that establishes a relationship between a function and its derivatives. These equations are fundamental in modeling dynamic systems across various fields of science and engineering. The order of a differential equation is defined by the highest order derivative present in the equation. A first-order differential equation includes only the first derivative, while a second-order differential equation includes up to the second derivative of the...
461