Related Experiment Video
Updated: Apr 16, 2026


Oscillation and Reaction Board Techniques for Estimating Inertial Properties of a Below-knee Prosthesis
Published on: May 8, 2014
An object oriented implementation of the Yeadon human inertia model
Christopher Dembia1, Jason K Moore2, Mont Hubbard3
1Mechanical Engineering, Stanford University, Stanford, CA, 94305, USA.

Abstract:
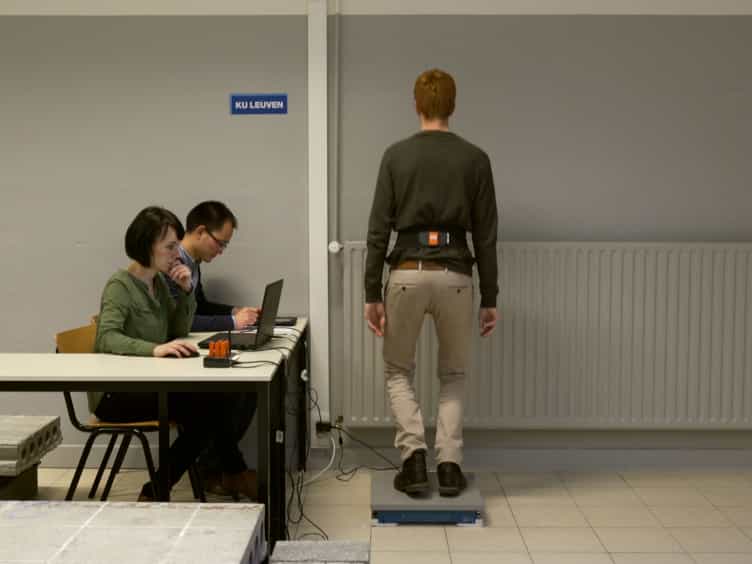
We present an open source software implementation of a popular mathematical method developed by M.R. Yeadon for calculating the body and segment inertia parameters of a human body. The software is written in a high level open source language and provides three interfaces for manipulating the data and the model: a Python API, a command-line user interface, and a graphical user interface. Thus the software can fit into various data processing pipelines and requires only simple geometrical measures as input.

Related Concept Videos
 01:09
Angular Momentum and Principle Axes of Inertia
To put this equation into simpler terms, it can be reconfigured using rectangular coordinates. This involves choosing an alternative set of XYZ axes that are arbitrarily inclined with respect to the reference frame. The process of deriving the rectangular...
 01:21
Rigid Body Equilibrium Problems - II
Consider two children sitting on a seesaw, which has negligible mass. The first child has a mass (m1) of 26 kg and sits at point A, which is 1.6 meters (r1) from the pivot point B; the second child has a mass (m2) of 32 kg and sits at point C. How far from the pivot point B should the second child sit (r2) to balance the seesaw?
 01:13
Kinetic Energy for a Rigid Body
 00:49
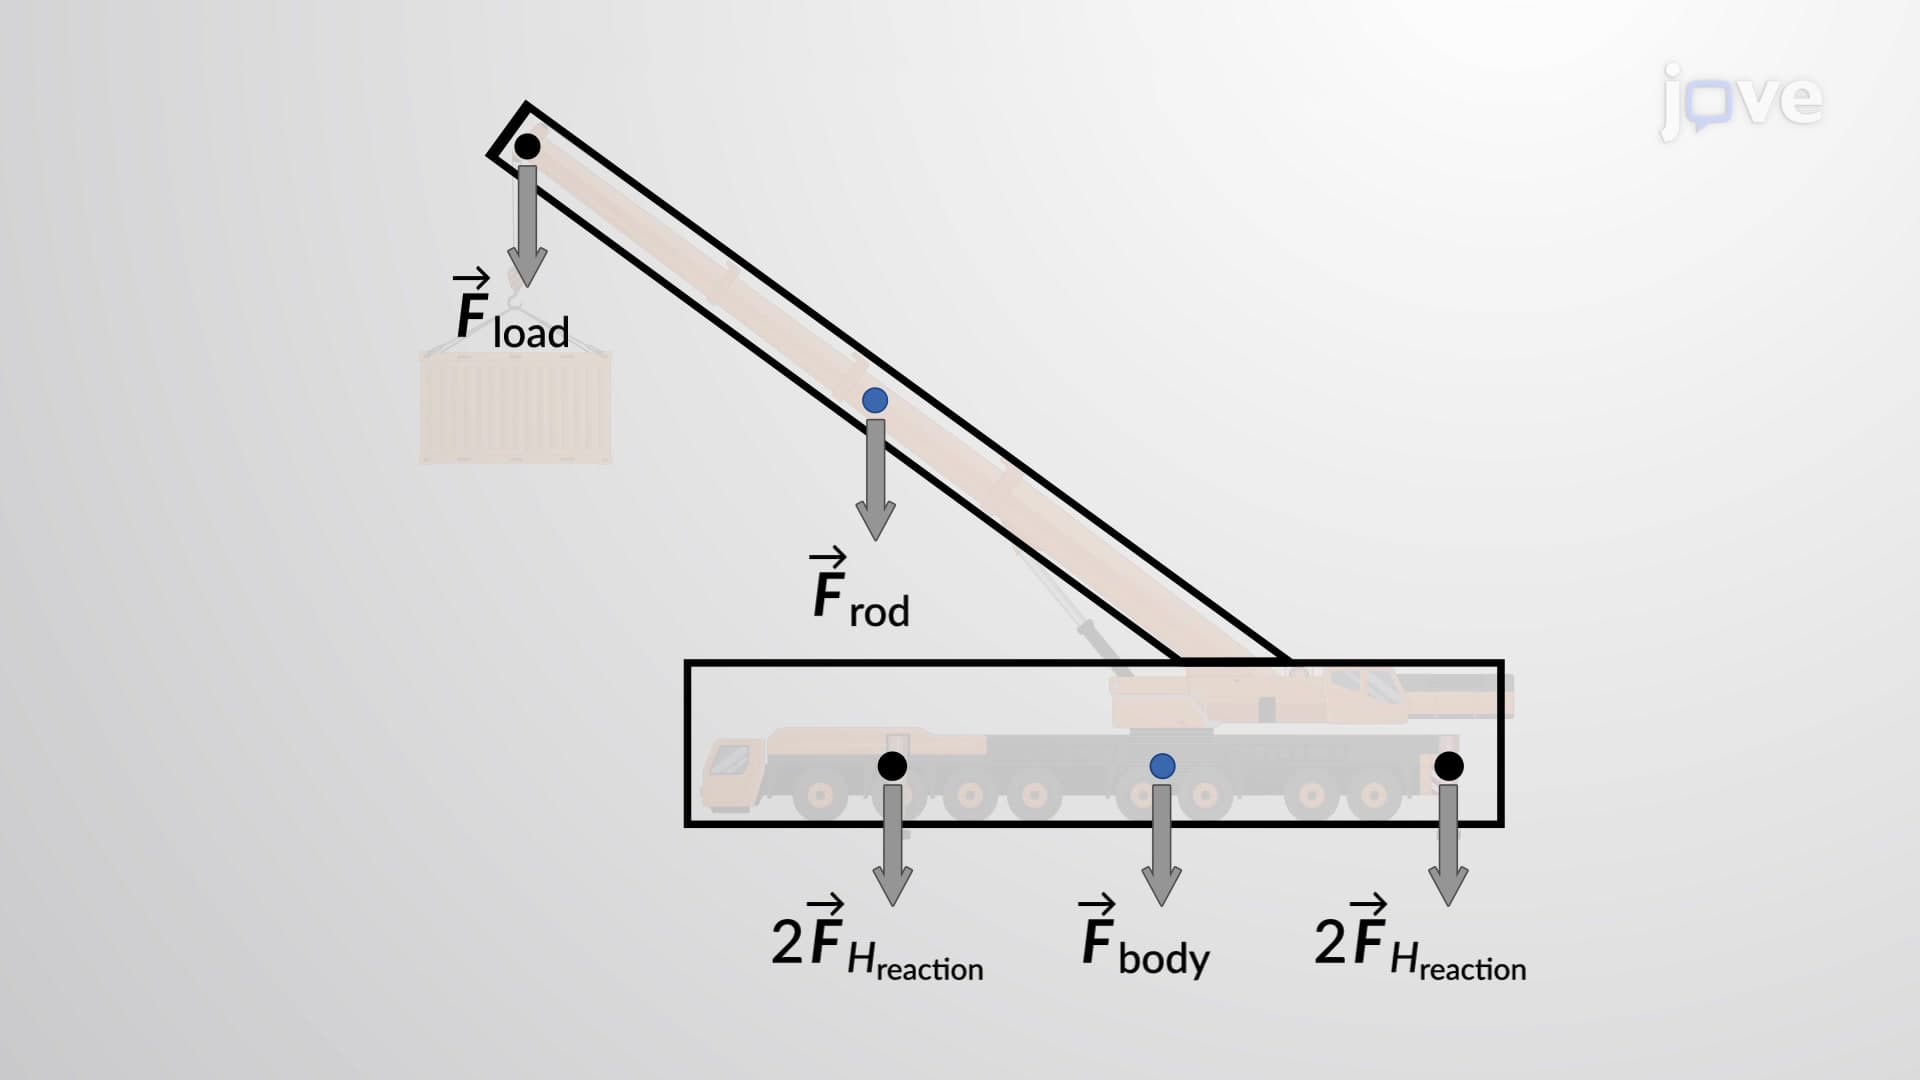
Rigid Body Equilibrium Problems - I
 01:21
Mechanistic Models: Overview of Compartment Models
 01:15
Model Approaches for Pharmacokinetic Data: Physiological Models