Robust pole assignment using velocity-acceleration feedback for second-order dynamical systems with singular mass matrix
Related Experiment Video
Updated: Apr 16, 2026

Robotic Mirror Therapy System for Functional Recovery of Hemiplegic Arms
Published on: August 15, 2016
1Department of Mechanical Engineering, Faculty of Engineering, Helwan University, 11792 Helwan, Cairo, Egypt.

Abstract:
In this paper the robust pole assignment problem using combined velocity and acceleration feedback for second-order linear systems with singular mass matrix is illustrated. This is promising for better applicability in several practical applications where the acceleration signals are easier to obtain than the proportional ones. First, the explicit parametric expressions of both the feedback gain controller and the eigenvector matrix are derived. The parametric solution involves manipulations only on the original second-order model. The available degrees of freedom offered by the velocity-acceleration feedback in selecting the associated eigenvectors are utilized to improve robustness of the closed-loop system. Straight-forward computational algorithms are introduced to demonstrate the effectiveness of the proposed approach. These algorithms are applicable for a dynamical system with mass matrices that can be either singular or nonsingular. Numerical examples are provided to illustrate the application of the proposed procedure.


Related Concept Videos
 01:24
Pole and System Stability
Simple poles are unique roots of the denominator polynomial. Each simple pole corresponds to a distinct solution to the system's characteristic equation, typically resulting in exponential decay terms in the system's...
 01:22
Relative Motion Analysis using Rotating Axes - Acceleration
Time differentiation is...
 01:14
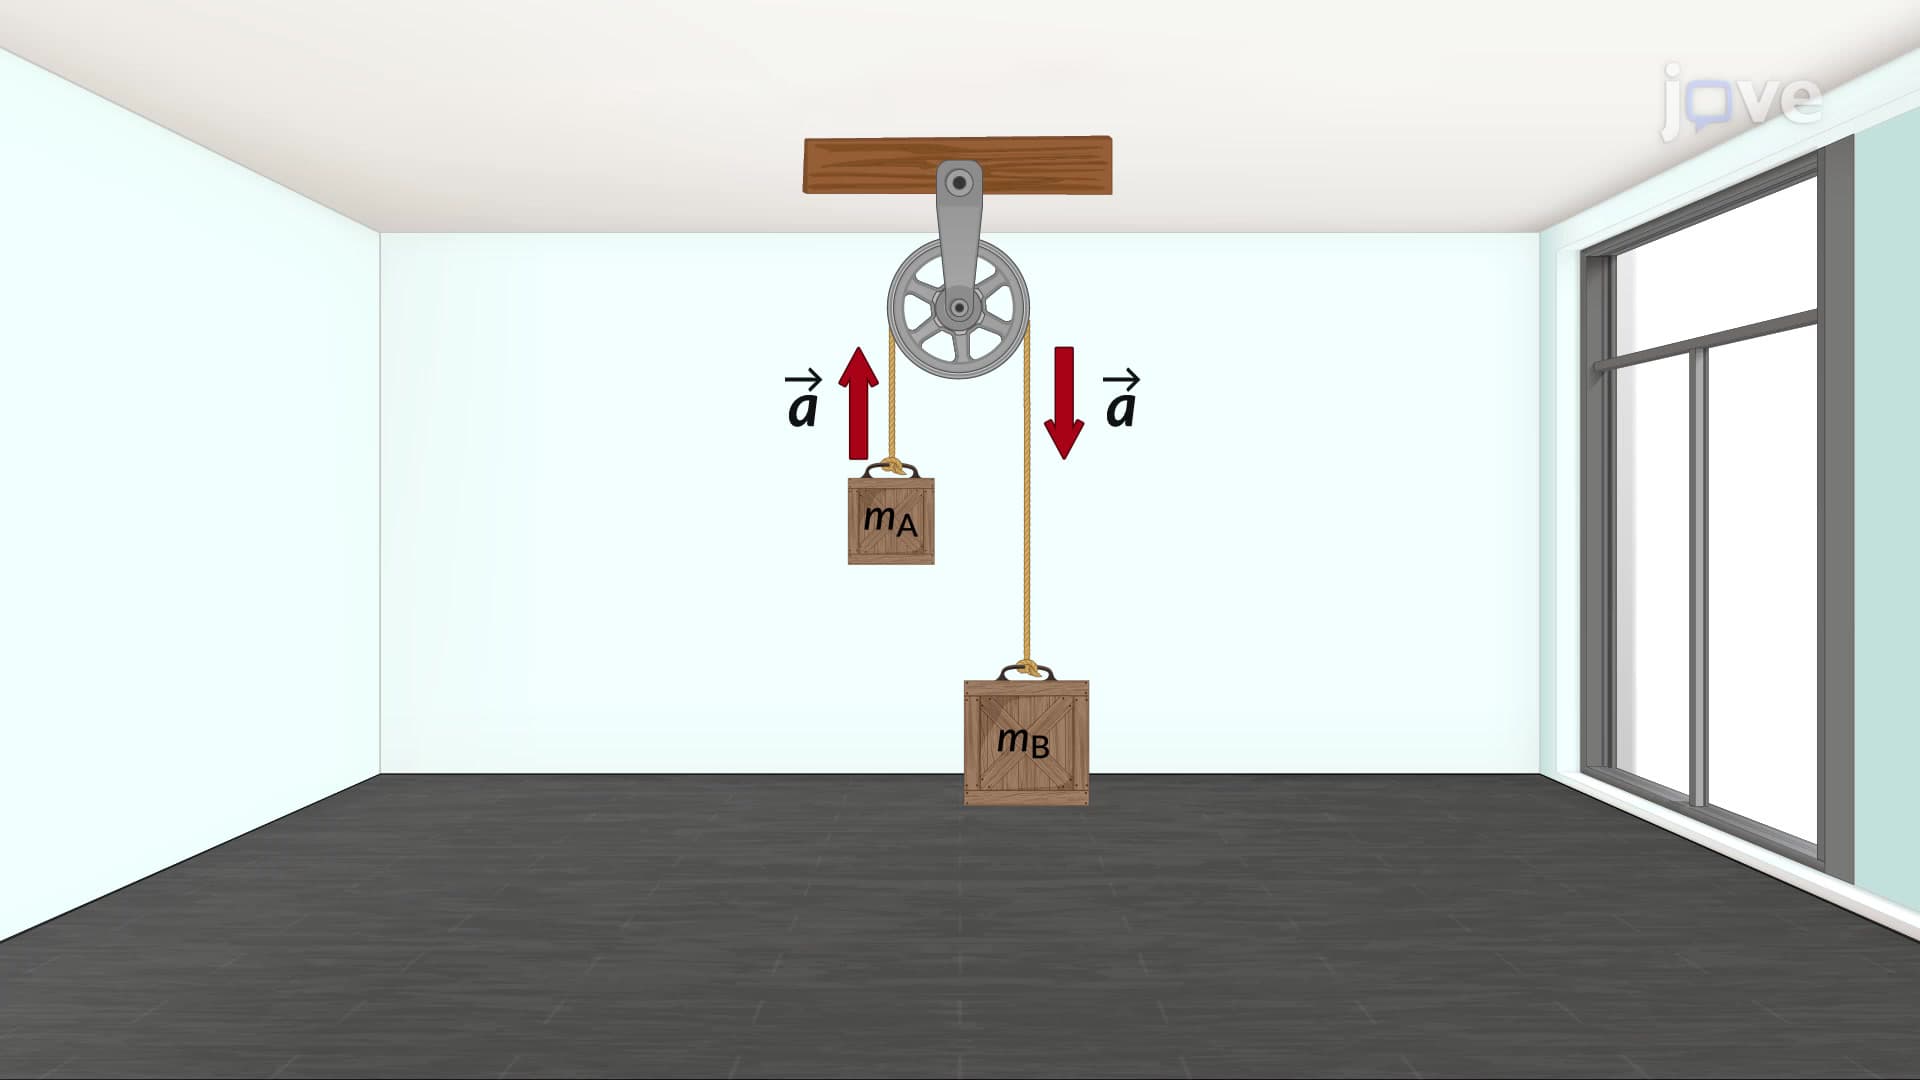
Second Law: Motion under Same Acceleration
 01:17
Kinematic Equations - II
Suppose a car merges into freeway traffic on a 200 m long ramp. If its initial velocity is 10 m/s and it accelerates at 2 m/s2, then the...
 01:13
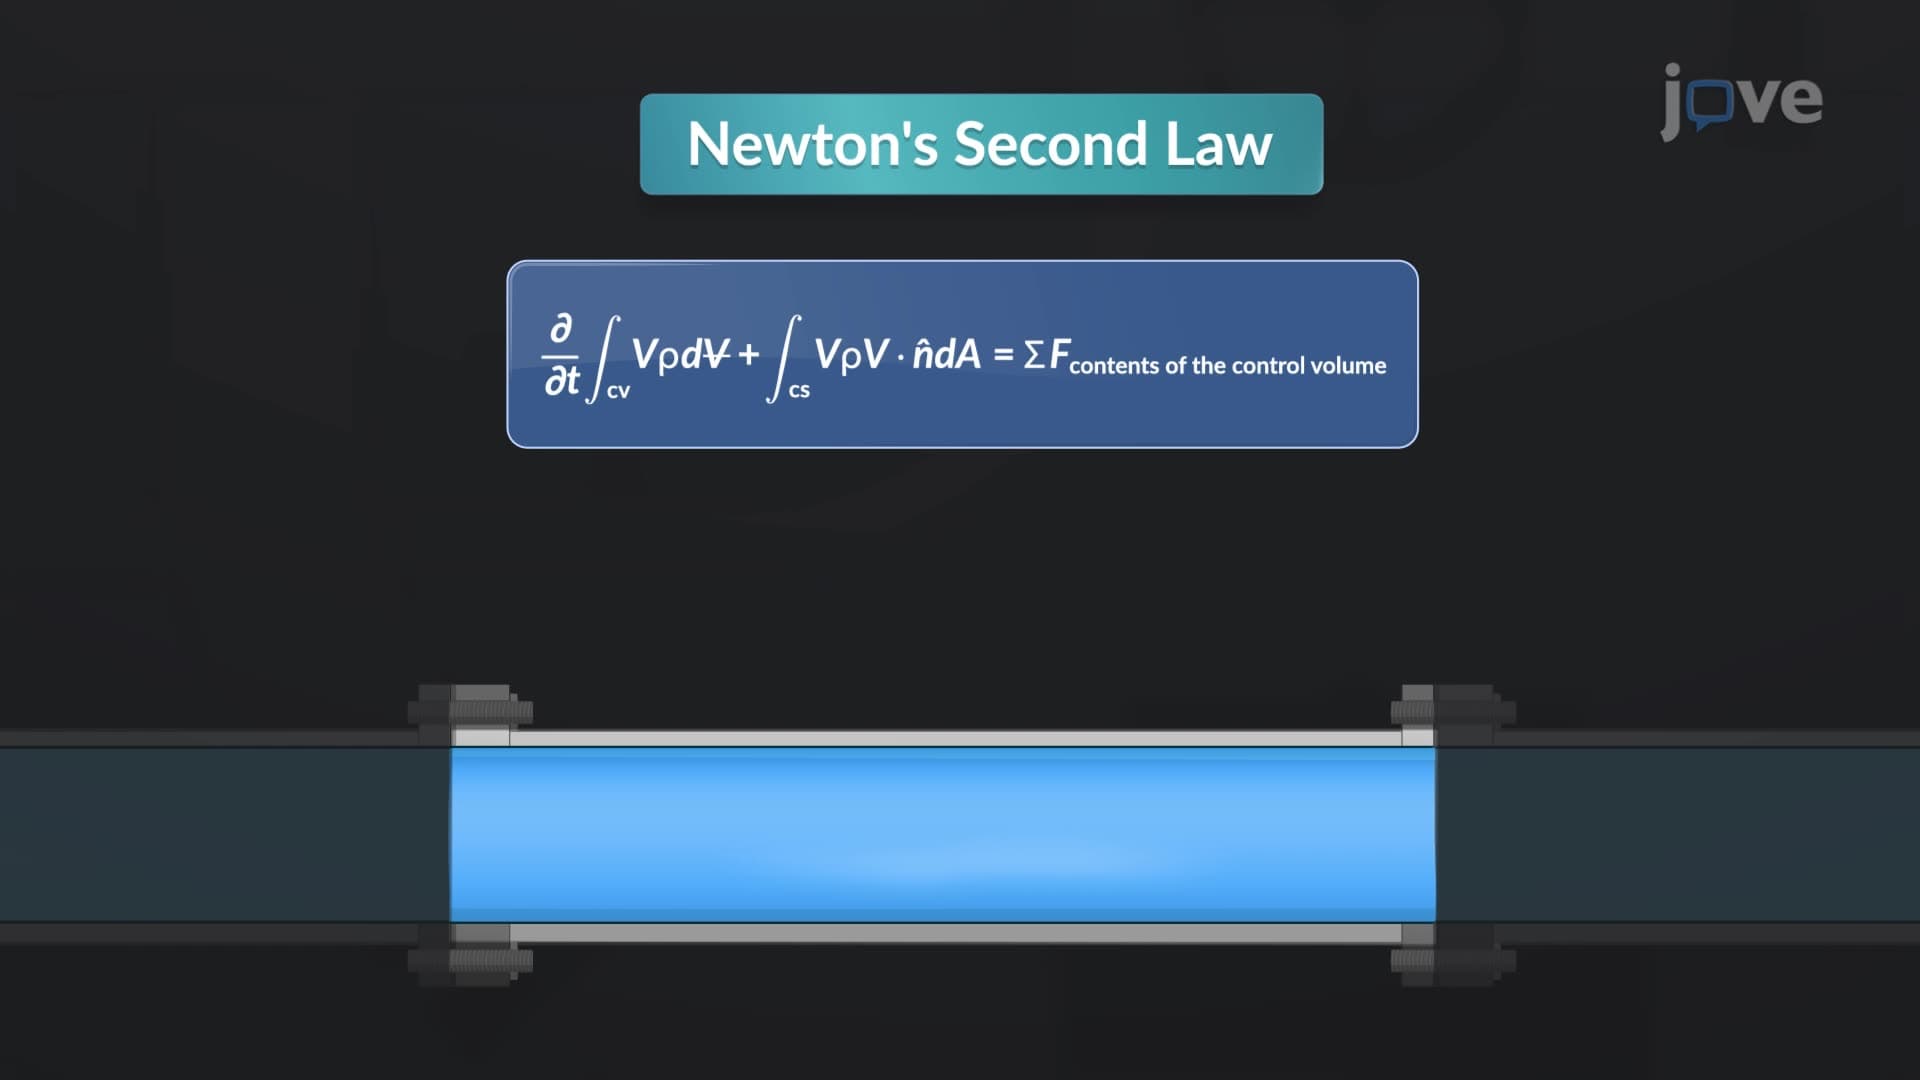
Linear Momentum in Control Volume
 01:10
Relative Motion Analysis - Acceleration