Design and implementation of fractional order pole placement controller to control the magnetic flux in Damavand tokamak

H Rasouli1, A Fatehi1, H Zamanian2
1Advanced Process Automation and Control (APAC) Research Group, Industrial Control Center of Excellence, Faculty of Electrical Engineering, K. N. Toosi University of Technology, Seyyed Khandan, P.O. Box 16315-1355 Tehran, Iran.

Abstract:
In this paper, a routine algorithm is presented to design a fractional order controller for tracking the reference model. Using this algorithm, a pole placement controller can be designed by assigning the desired integer and fractional order closed loop transfer functions. Considering the desired time response and using the generalized characteristic ratio assignment (CRA) method for fractional order systems and coefficient diagram method (CDM) for integer order systems, the desired closed loop system can be achieved. For various practical experiments, having the desired time responses is vital for magnetic flux in Damavand tokamak. To approach this, at first, the desired reference models are obtained based on CRA and CDM methods. After that, a fractional order pole placement controller is designed and simulated by this algorithm. At last, this controller is implemented on a digital signal processor to control the vertical magnetic flux of Damavand tokamak plant. The practical results show the satisfactory performance of the controller.
Related Concept Videos
 01:27
Time and frequency -Domain Interpretation of PI Control
Acting as a low-pass filter, the PI controller slows the system's response and extends settling times. This requires...
 01:24
Time and frequency -Domain Interpretation of Phase-lead Control
The design of phase-lead control involves the strategic placement of poles and zeros to balance steady-state error and system...
 01:13
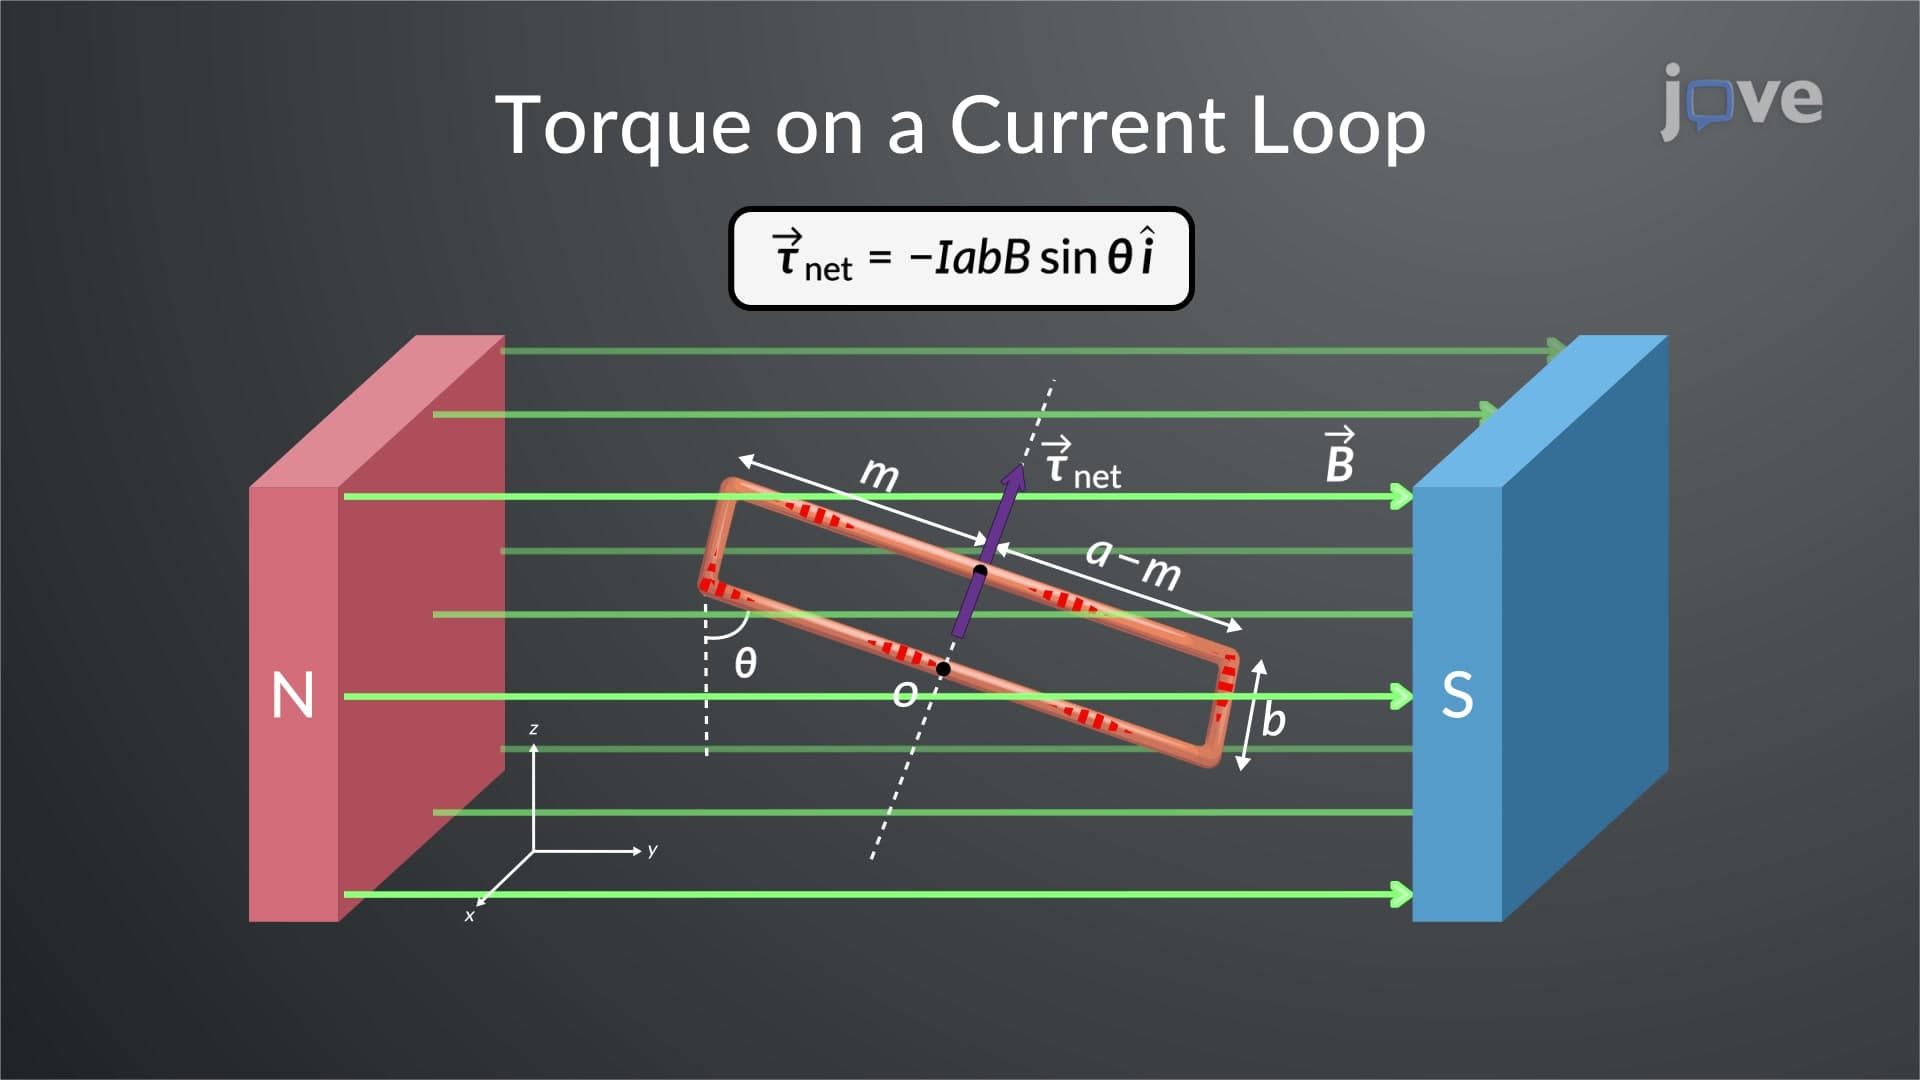
Torque On A Current Loop In A Magnetic Field
Consider a rectangular current-carrying loop containing N turns of wire, placed in a uniform magnetic field. The net force on a current-carrying loop...
 01:17
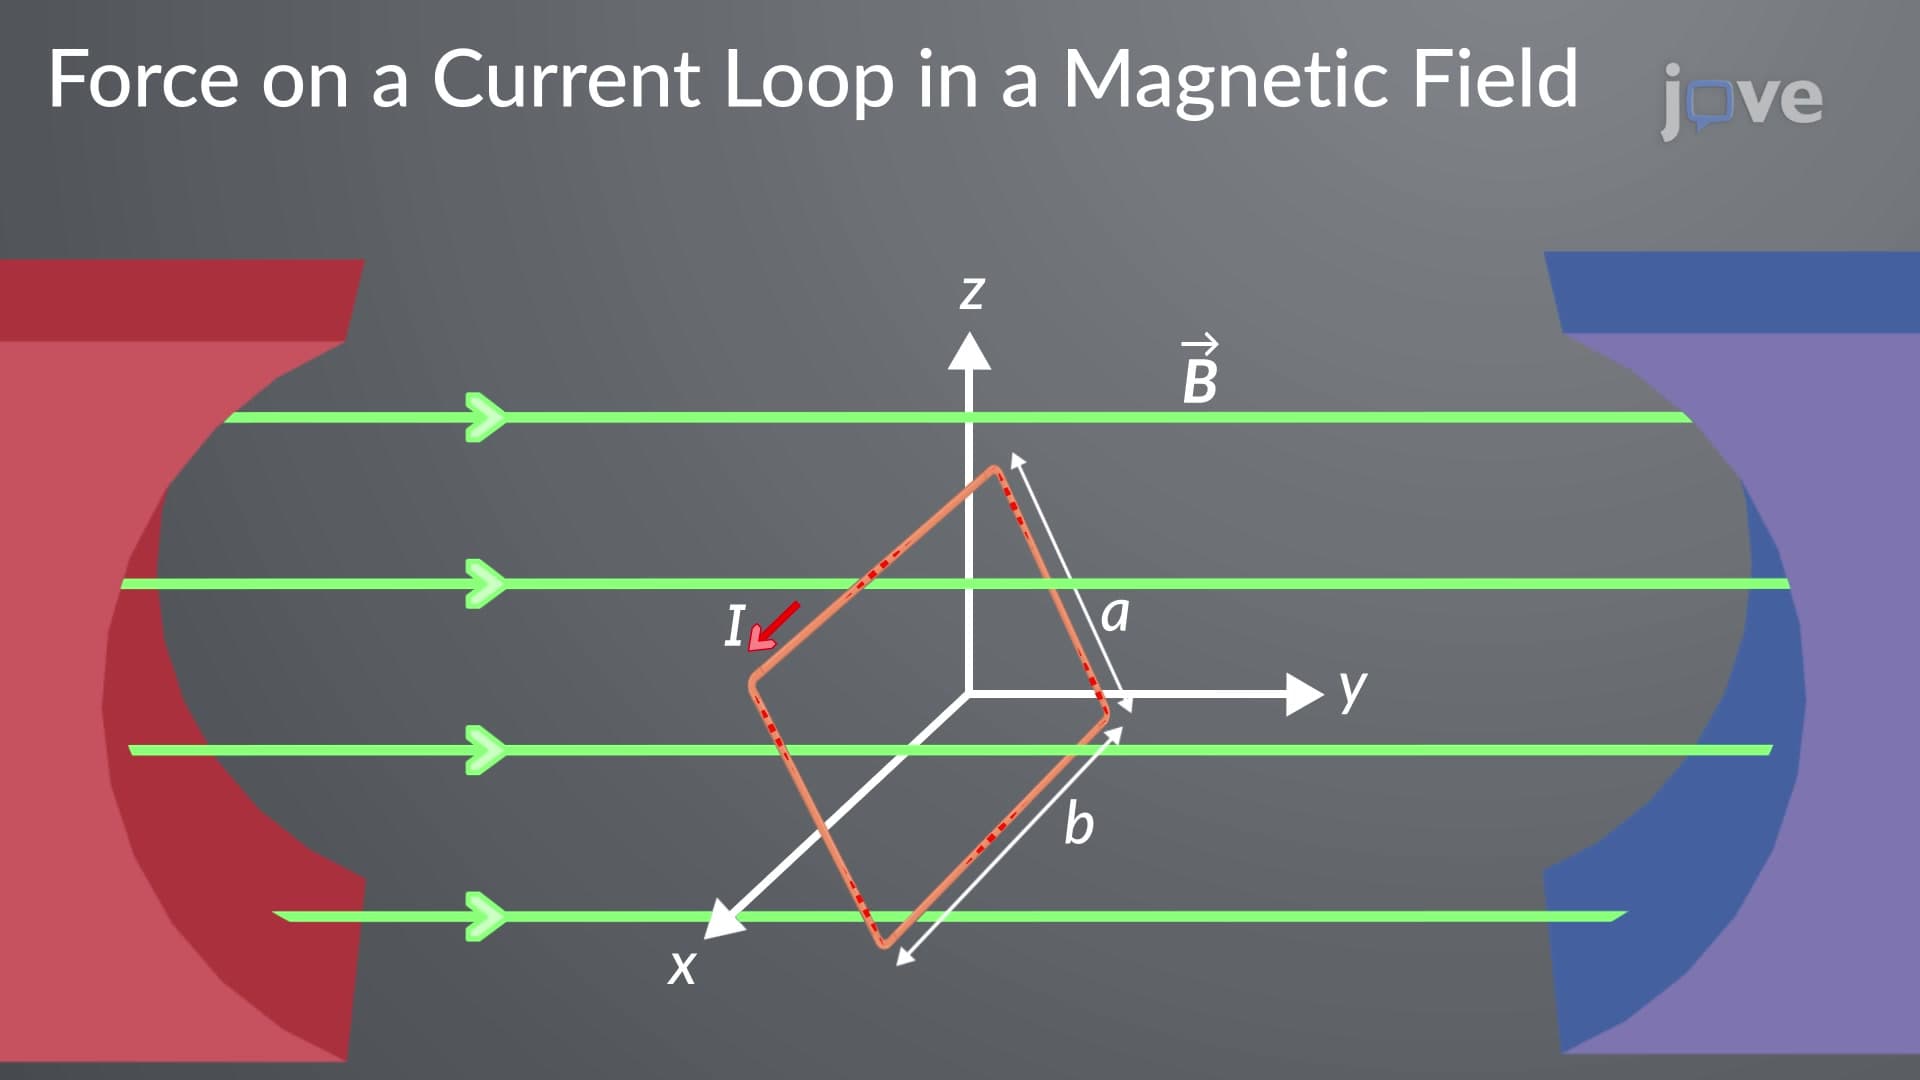
Force On A Current Loop In A Magnetic Field
 01:17
Magnetic Damping
If, however, the bob is a slotted metal plate, the magnet produces a much smaller effect. When a slotted metal plate enters the field, an emf is induced by the change in flux; however, it is less effective because the slots limit the...
 01:28
Magnetostatic Boundary Conditions