Related Experiment Video
Updated: Apr 14, 2026

Continuous Measurement of Biological Noise in Escherichia Coli Using Time-lapse Microscopy
Published on: April 27, 2021
Identification of non-minimum phase processes with time delay in the presence of measurement noise
Bajarangbali1, Somanath Majhi1
1Department of Electronics and Electrical Engineering, Indian Institute of Technology Guwahati, 781039, India.

Abstract:
Time domain based generalized analytical expressions are derived to estimate the exact model parameters of a class of stable non-minimum phase (NMP) processes with time delay. The novelty of the proposed method lies in generalizing a second order plus time delay (SOPDT) NMP process model in terms of a class of models like first order plus time delay (FOPDT), SOPDT underdamped, critically damped and integrating processes. The mathematical expressions are employed to estimate four accurate parameters at a time. Relay with hysteresis reduces the effect of noise and further mitigation of noise is achieved through a denoising block yielding a clean process output. Processes modeled in the form of transfer functions are considered to validate the technique.
Related Concept Videos
 01:24
Time and frequency -Domain Interpretation of Phase-lead Control
The design of phase-lead control involves the strategic placement of poles and zeros to balance steady-state error and system...
 01:21
Time and frequency -Domain Interpretation of Phase-lag Control
Phase-lag controllers do not place a pole at zero, but instead influence the steady-state error by amplifying any...
 01:10
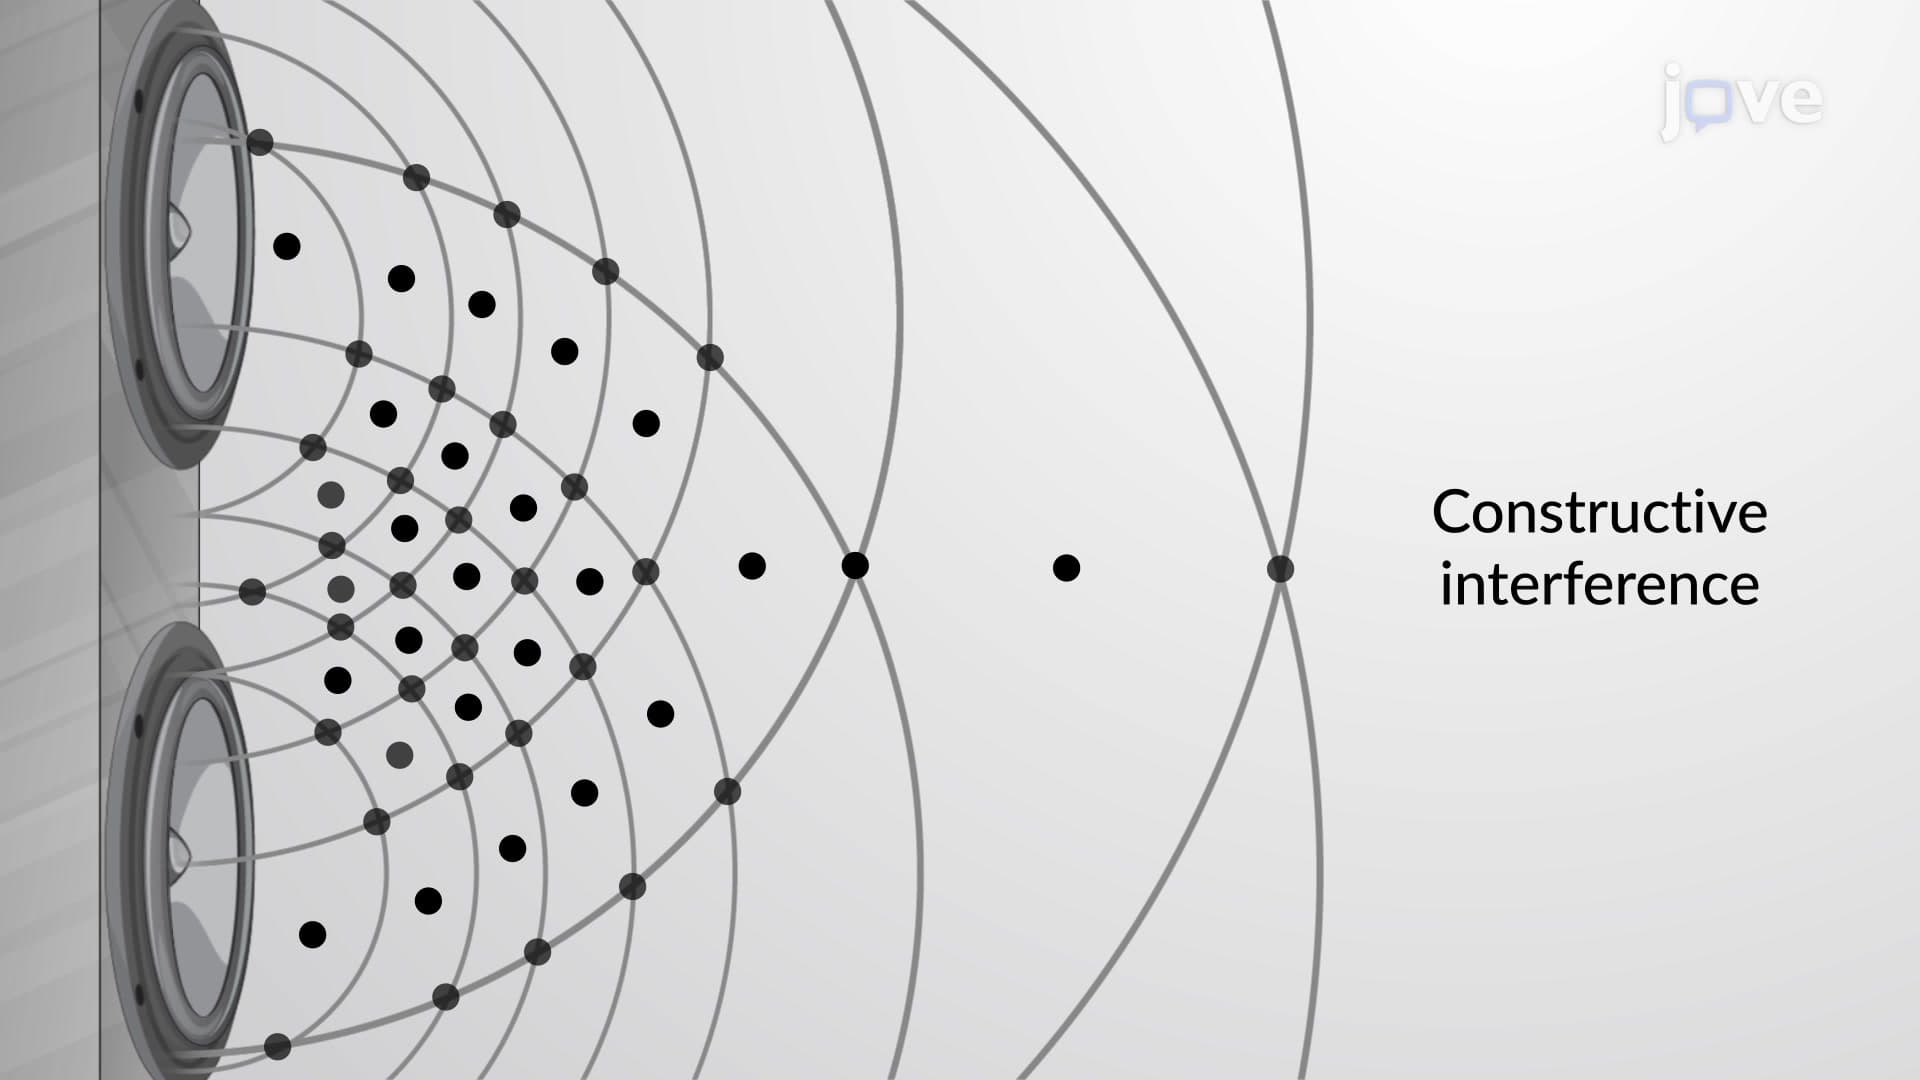
Interference: Path Lengths
Two special sources may be considered when they are in phase. This can be easily achieved by feeding the two sources from the same source. An example would be synchronizing the two speakers by feeding them with the same source, such as the sound waves produced by a tuning fork. This setup ensures that the two sources have the same frequency and are...
 01:20
The Phase Rule
 01:22
Phase-lead and Phase-lag Controllers
 01:23
Linear time-invariant Systems
The input-output behavior of an LTI system can be fully defined by its response to an impulsive excitation at its input. Once this impulse response is known, the system's reaction to any other input can be...