Related Experiment Video
Updated: Apr 14, 2026

Enabling High Grayscale Resolution Displays and Accurate Response Time Measurements on Conventional Computers
Published on: February 29, 2012
Linear tuning of gamma amplitude and frequency to luminance contrast: evidence from a continuous mapping paradigm
Gavin Perry1, James M Randle1, Loes Koelewijn1
1Cardiff University Brain Imaging Centre (CUBRIC), School of Psychology, Cardiff University, Cardiff, United Kingdom.

Abstract:
Individual differences in the visual gamma (30-100 Hz) response and their potential as trait markers of underlying physiology (particularly related to GABAergic inhibition) have become a matter of increasing interest in recent years. There is growing evidence, however, that properties of the gamma response (e.g., its amplitude and frequency) are highly stimulus dependent, and that individual differences in the gamma response may reflect individual differences in the stimulus tuning functions of gamma oscillations. Here, we measured the tuning functions of gamma amplitude and frequency to luminance contrast in eighteen participants using MEG. We used a grating stimulus in which stimulus contrast was modulated continuously over time. We found that both gamma amplitude and frequency were linearly modulated by stimulus contrast, but that the gain of this modulation (as reflected in the linear gradient) varied across individuals. We additionally observed a stimulus-induced response in the beta frequency range (10-25 Hz), but neither the amplitude nor the frequency of this response was consistently modulated by the stimulus over time. Importantly, we did not find a correlation between the gain of the gamma-band amplitude and frequency tuning functions across individuals, suggesting that these may be independent traits driven by distinct neurophysiological processes.
Related Concept Videos
 01:21
Time and frequency -Domain Interpretation of Phase-lag Control
Phase-lag controllers do not place a pole at zero, but instead influence the steady-state error by amplifying any...
 01:20
Calibration Curves: Linear Least Squares
For data that follow a straight line, the standard method for fitting is the linear...
 01:24
Time and frequency -Domain Interpretation of Phase-lead Control
The design of phase-lead control involves the strategic placement of poles and zeros to balance steady-state error and system...
 01:26
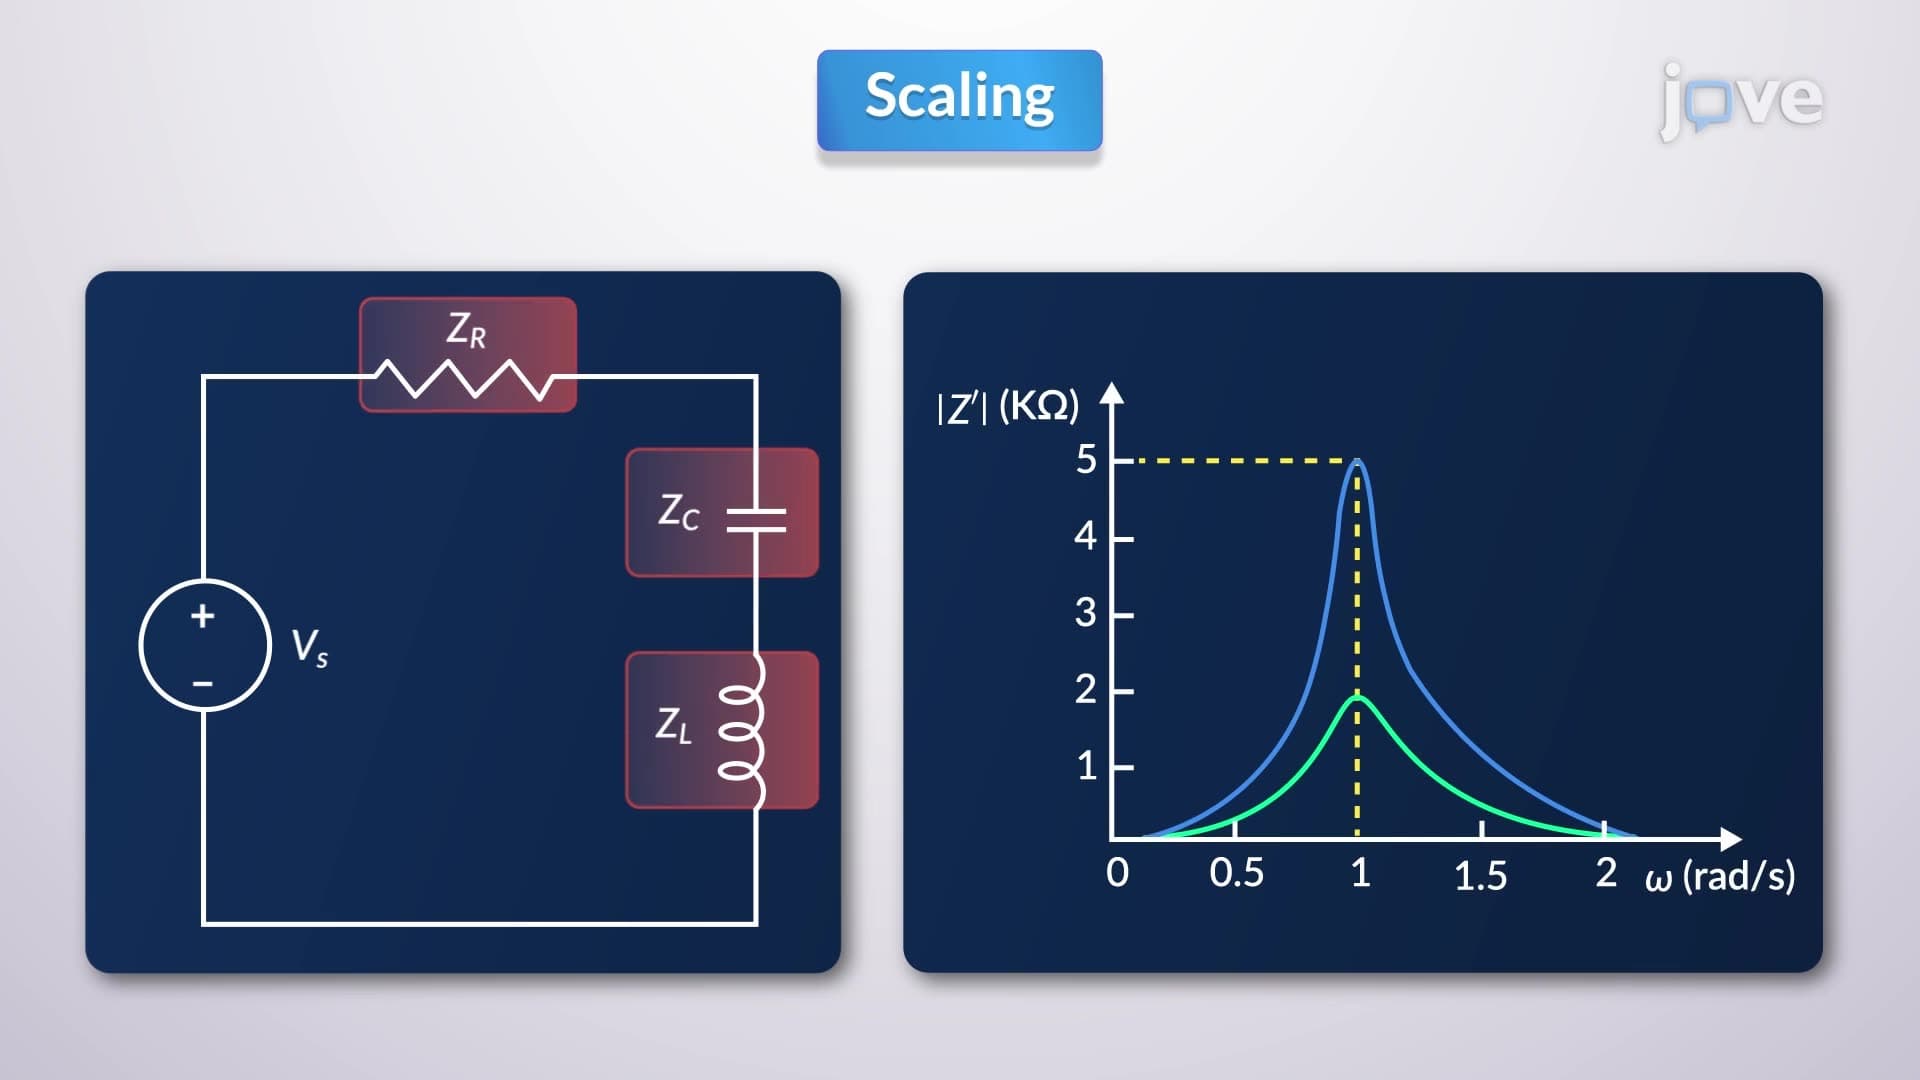
Scaling
 01:26
Linear Approximation in Frequency Domain
In contrast, nonlinear systems do not inherently possess these properties. However, for small deviations around an operating point, a nonlinear system can often be approximated as linear....
 01:05
Difference from Background: Limit of Detection
The LOD indicates the presence or absence...