Signaling equilibria in sensorimotor interactions
Felix Leibfried1, Jordi Grau-Moya1, Daniel A Braun2
1Max Planck Institute for Biological Cybernetics, Tübingen, Germany; Max Planck Institute for Intelligent Systems, Tübingen, Germany; Graduate Training Centre of Neuroscience, Tübingen, Germany.

Abstract:
Although complex forms of communication like human language are often assumed to have evolved out of more simple forms of sensorimotor signaling, less attention has been devoted to investigate the latter. Here, we study communicative sensorimotor behavior of humans in a two-person joint motor task where each player controls one dimension of a planar motion. We designed this joint task as a game where one player (the sender) possesses private information about a hidden target the other player (the receiver) wants to know about, and where the sender's actions are costly signals that influence the receiver's control strategy. We developed a game-theoretic model within the framework of signaling games to investigate whether subjects' behavior could be adequately described by the corresponding equilibrium solutions. The model predicts both separating and pooling equilibria, in which signaling does and does not occur respectively. We observed both kinds of equilibria in subjects and found that, in line with model predictions, the propensity of signaling decreased with increasing signaling costs and decreasing uncertainty on the part of the receiver. Our study demonstrates that signaling games, which have previously been applied to economic decision-making and animal communication, provide a framework for human signaling behavior arising during sensorimotor interactions in continuous and dynamic environments.
Related Concept Videos
 01:04
Oscillations about an Equilibrium Position
 01:15
Equilibrium and Balance
 01:21
Rigid Body Equilibrium Problems - II
Consider two children sitting on a seesaw, which has negligible mass. The first child has a mass (m1) of 26 kg and sits at point A, which is 1.6 meters (r1) from the pivot point B; the second child has a mass (m2) of 32 kg and sits at point C. How far from the pivot point B should the second child sit (r2) to balance the seesaw?
 01:28
Major Somatic Sensory Pathways
 01:30
Categories of Equilibrium
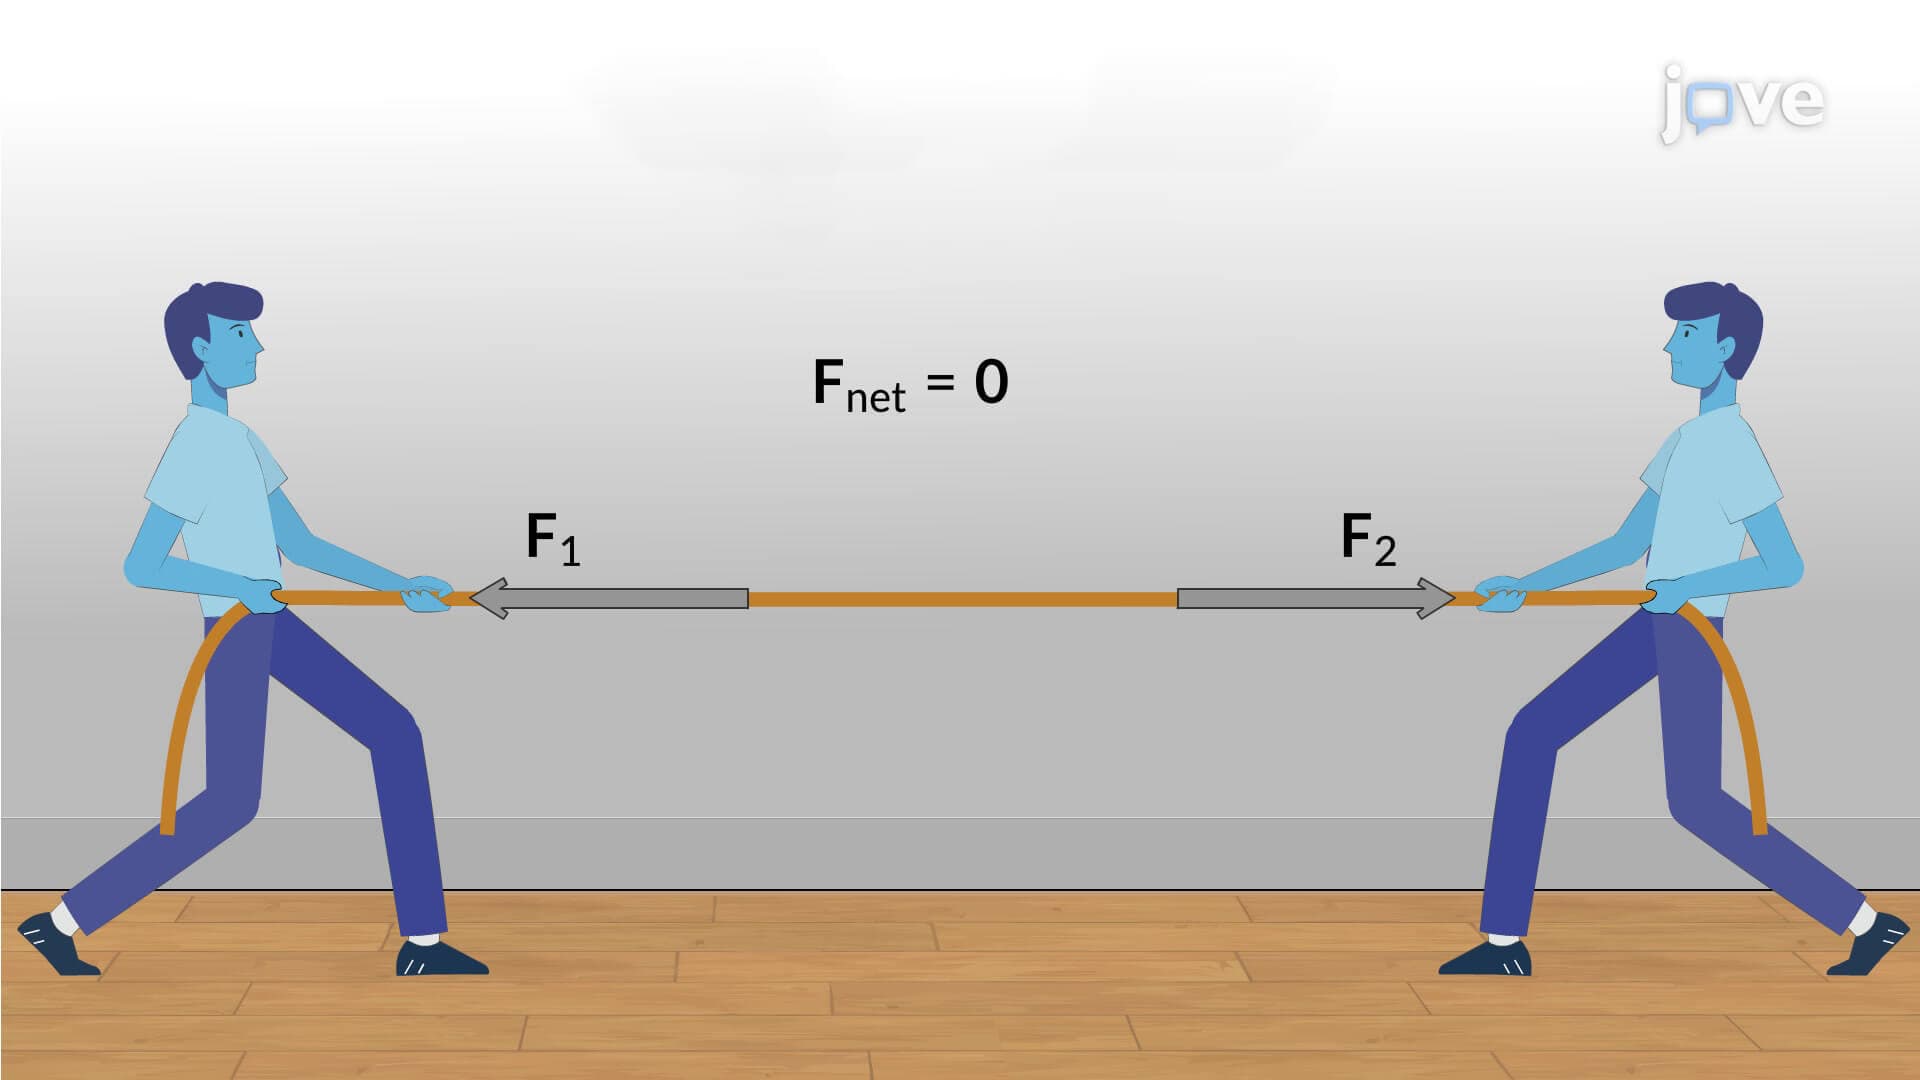
One of the categories of equilibrium is collinear equilibrium, which involves forces acting along a straight line. This type of equilibrium requires only one force equation in the direction of the forces, as the other equations are...
 01:23
Stability of Equilibrium Configuration
A stable equilibrium occurs when a system tends to return to its original position when given a small displacement, and the potential energy is at its minimum. An example of a stable equilibrium is when a cantilever beam is fixed at one end and a weight is attached to the other end. If the weight...