Robust set-point regulation for ecological models with multiple management goals
Related Experiment Video
Updated: Apr 6, 2026
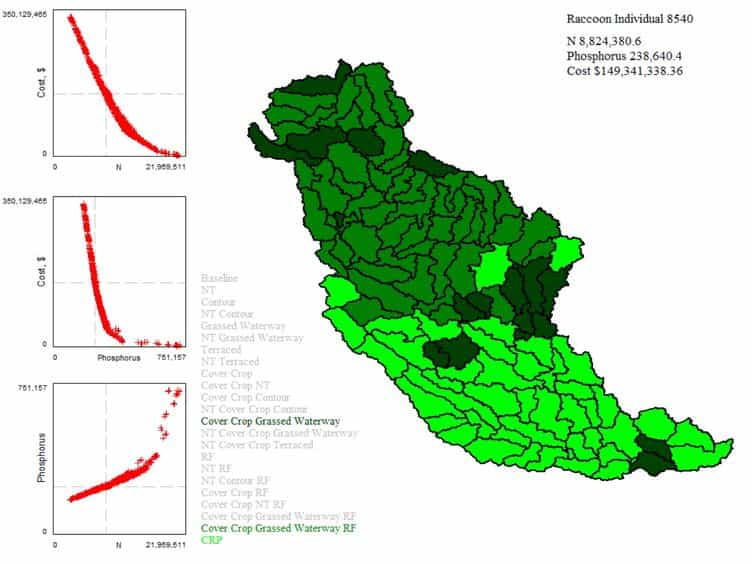
Spatial Multiobjective Optimization of Agricultural Conservation Practices using a SWAT Model and an Evolutionary Algorithm
Published on: December 9, 2012
Chris Guiver1, Markus Mueller2, Dave Hodgson3
1Environment and Sustainability Institute, College of Engineering Mathematics and Physical Sciences, University of Exeter, Penryn Campus, Penryn, Cornwall, TR10 9FE, UK. c.guiver@ex.ac.uk.

Abstract:
Population managers will often have to deal with problems of meeting multiple goals, for example, keeping at specific levels both the total population and population abundances in given stage-classes of a stratified population. In control engineering, such set-point regulation problems are commonly tackled using multi-input, multi-output proportional and integral (PI) feedback controllers. Building on our recent results for population management with single goals, we develop a PI control approach in a context of multi-objective population management. We show that robust set-point regulation is achieved by using a modified PI controller with saturation and anti-windup elements, both described in the paper, and illustrate the theory with examples. Our results apply more generally to linear control systems with positive state variables, including a class of infinite-dimensional systems, and thus have broader appeal.
Related Concept Videos
 00:48
Optimal Foraging
 01:18
Positive and Negative Feedback Loops
 01:25
Self-Regulation
 01:23
Mechanistic Models: Compartment Models in Individual and Population Analysis
 02:45
Self-Discrepancy Theory
 02:02
Ecological Niches