Related Experiment Video
Updated: Apr 5, 2026
08:55

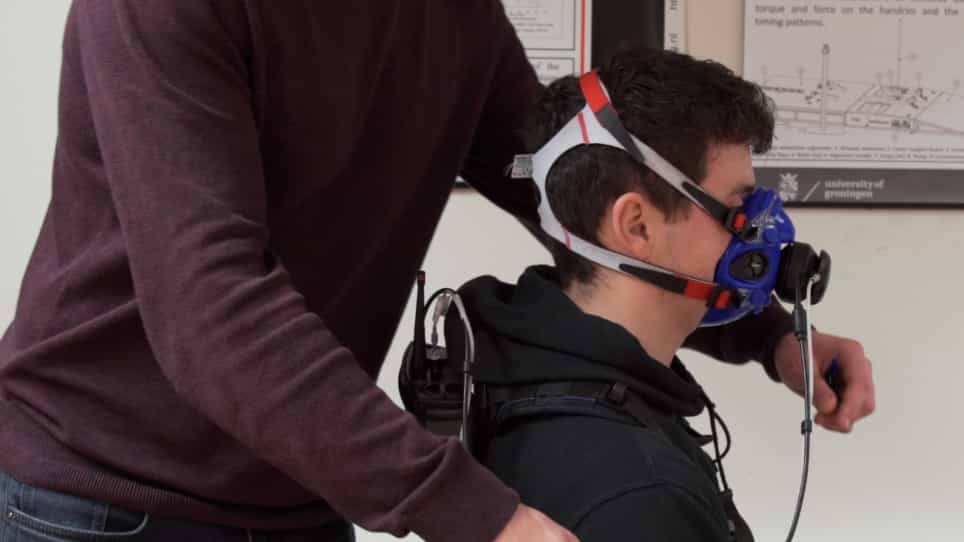
Determining and Controlling External Power Output During Regular Handrim Wheelchair Propulsion
Published on: February 5, 2020
8.0K
Symbolic representation of propulsion cycles in manual wheelchair locomotion
V S Siyou Fotso1,2, E Mephu Nguifo1,2, Ph Vaslin1,2
1a LIMOS , Clermont Université, Université Blaise Pascal , Clermont-Ferrand.
Computer Methods in Biomechanics and Biomedical Engineering
|August 15, 2015

Abstract
No abstract available in PubMed .
More Related Videos


Related Concept Videos
 01:24
Relative Motion Analysis - Velocity
937
A stroke engine has a slider-crank mechanism that converts rotational motion from the crank into linear motion of the slider or vice versa. This mechanism consists of three main parts: the crank, the connecting rod, and the slider.
When an external force is exerted, it sets the crank into a rotational movement. This, in turn, instigates the motion of the connecting rod, leading to what is referred to as a general plane motion. This process involves two key points - point A on the connecting rod...
When an external force is exerted, it sets the crank into a rotational movement. This, in turn, instigates the motion of the connecting rod, leading to what is referred to as a general plane motion. This process involves two key points - point A on the connecting rod...
937
 01:10
Relative Motion Analysis - Acceleration
1.0K
A slider-crank mechanism converts rotational motion from the crank into linear motion of the slider or vice versa. This mechanism consists of three main parts: the crank, the connecting rod, and the slider. The movement of the slider-crank is an example of general plane motion as the fluctuating angle between the crank and the connecting rod. Consider a segment AB where point A is at the end of the slider and point B is on the diametrically opposite end to point A, on a crack. The variance in...
1.0K
 01:18
Hierarchy of Motor Control
6.8K
The hierarchy of motor control refers to the different levels of organization and processing involved in controlling movement in the body. These levels range from higher cortical areas involved in planning and decision-making to lower spinal cord reflexes that respond automatically to external stimuli.
6.8K
 01:11
Direct Motor Pathways
5.3K
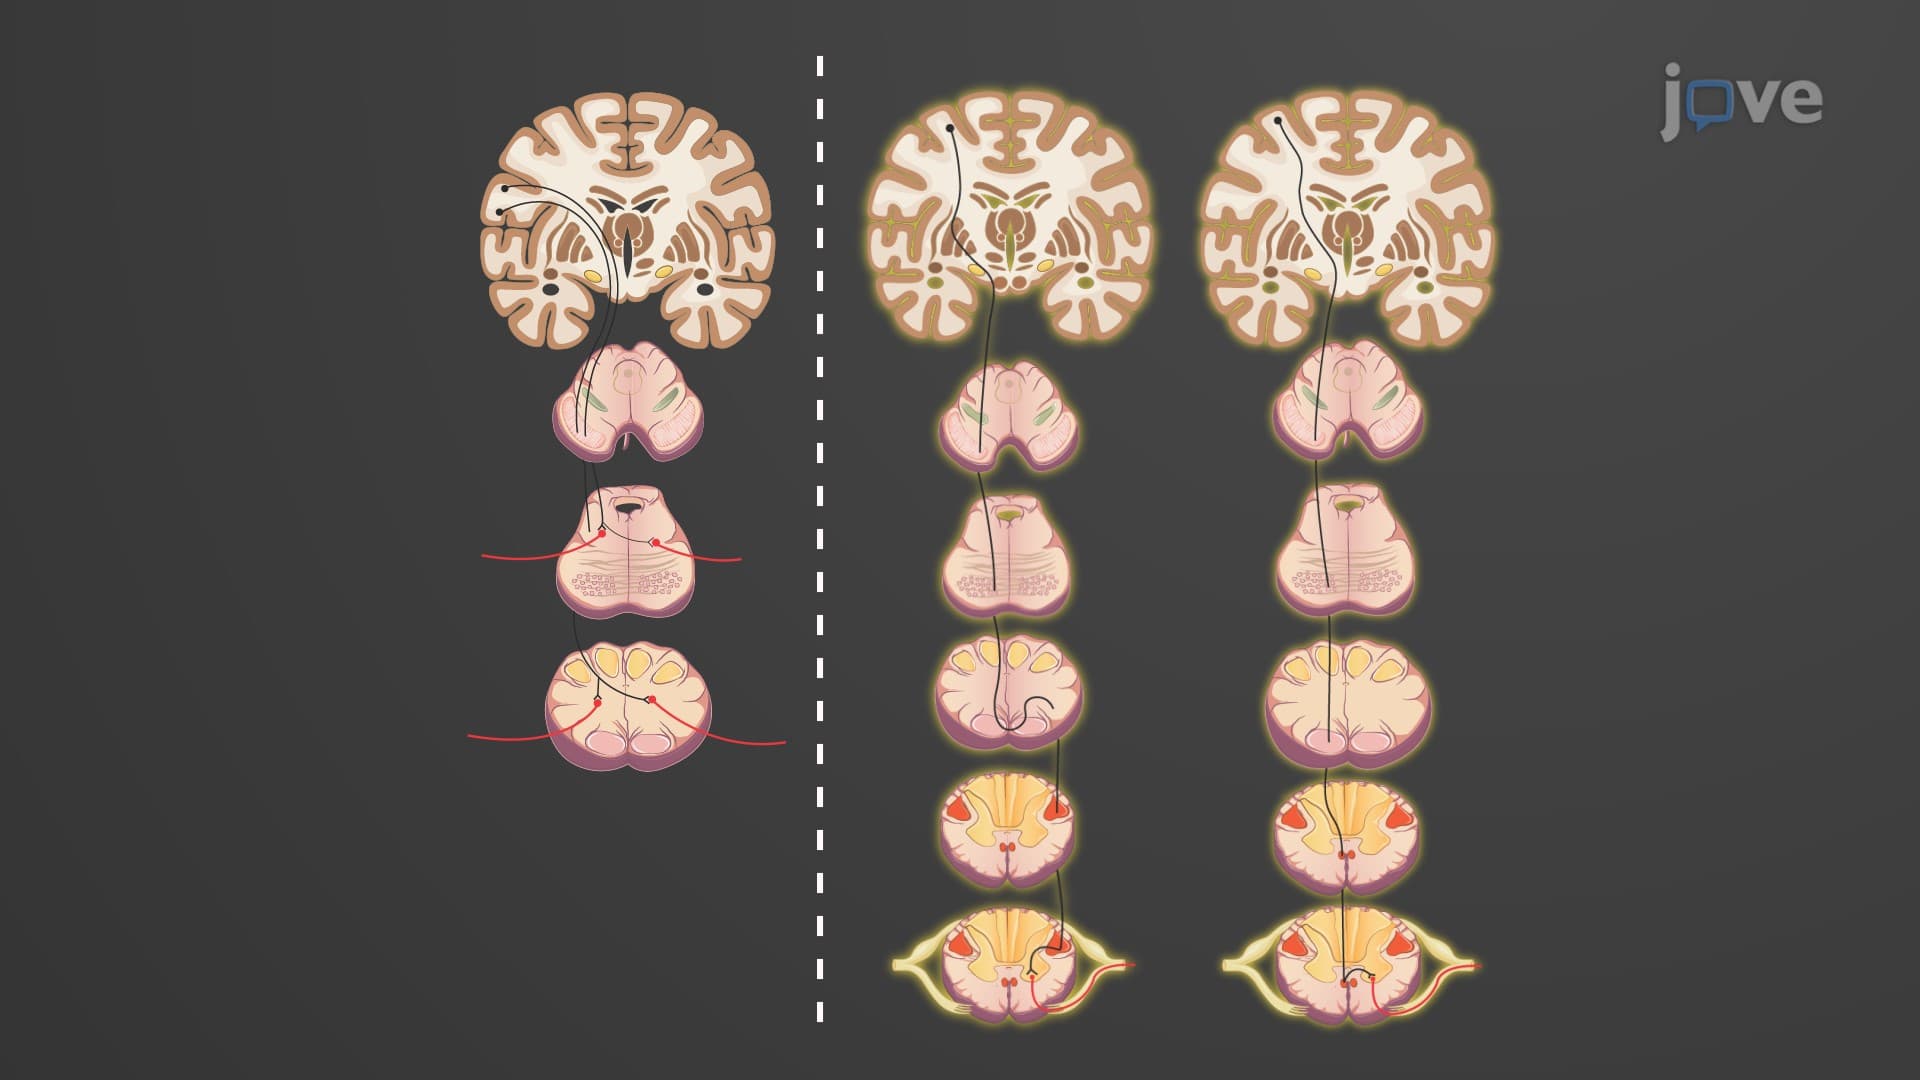
The direct motor pathways, also known as the pyramidal tracts, are a group of neural pathways that originate in the brain and descend through the spinal cord. They control the voluntary movement of the body. There are two major direct motor pathways: the corticospinal and the corticobulbar tracts.
The corticospinal tract is responsible for the voluntary movement of the limbs and trunk. It originates in the cerebral cortex of the brain and descends through the cerebrum's internal capsule and...
The corticospinal tract is responsible for the voluntary movement of the limbs and trunk. It originates in the cerebral cortex of the brain and descends through the cerebrum's internal capsule and...
5.3K
 01:17
Rolling Resistance: Problem Solving
925
Rolling resistance, also known as rolling friction, is the force that resists the motion of a rolling object, such as a wheel, tire, or ball, when it moves over a surface. It is caused by the deformation of the object and the surface in contact with each other, as well as other factors like internal friction, hysteresis, and energy losses within the materials. Rolling resistance opposes the object's motion, requiring additional energy to overcome it and maintain movement. In practical...
925
 01:20
Instantaneous Center of Zero Velocity
963
General plane motion, often observed in a rolling wheel, refers to a type of movement where the wheel is simultaneously rotating and translating. This complex motion can be understood by breaking it down into individual components.
To analyze this, consider two points on the wheel: point A and point B. The absolute velocity of point B can be expressed as the vector sum of the absolute velocity of point A and the relative velocity of point B with respect to point A. To simplify this analysis,...
To analyze this, consider two points on the wheel: point A and point B. The absolute velocity of point B can be expressed as the vector sum of the absolute velocity of point A and the relative velocity of point B with respect to point A. To simplify this analysis,...
963