
Forced synchronization of autonomous dynamical Boolean networks
R R Rivera-Durón1, E Campos-Cantón1, I Campos-Cantón2
1División de Matemáticas Aplicadas, Instituto Potosino de Investigación Científica y Tecnológica A. C., Camino a la Presa San José 2055, Col. Lomas 4 Sección, C.P. 78216, San Luis Potosí, S.L.P., Mexico.

Abstract:
We present the design of an autonomous time-delay Boolean network realized with readily available electronic components. Through simulations and experiments that account for the detailed nonlinear response of each circuit element, we demonstrate that a network with five Boolean nodes displays complex behavior. Furthermore, we show that the dynamics of two identical networks display near-instantaneous synchronization to a periodic state when forced by a common periodic Boolean signal. A theoretical analysis of the network reveals the conditions under which complex behavior is expected in an individual network and the occurrence of synchronization in the forced networks. This research will enable future experiments on autonomous time-delay networks using readily available electronic components with dynamics on a slow enough time-scale so that inexpensive data collection systems can faithfully record the dynamics.


Related Concept Videos
 01:24
Sequence Networks of Rotating Machines
Zero-sequence current induces a voltage drop across the generator's neutral impedance and other...
 01:30
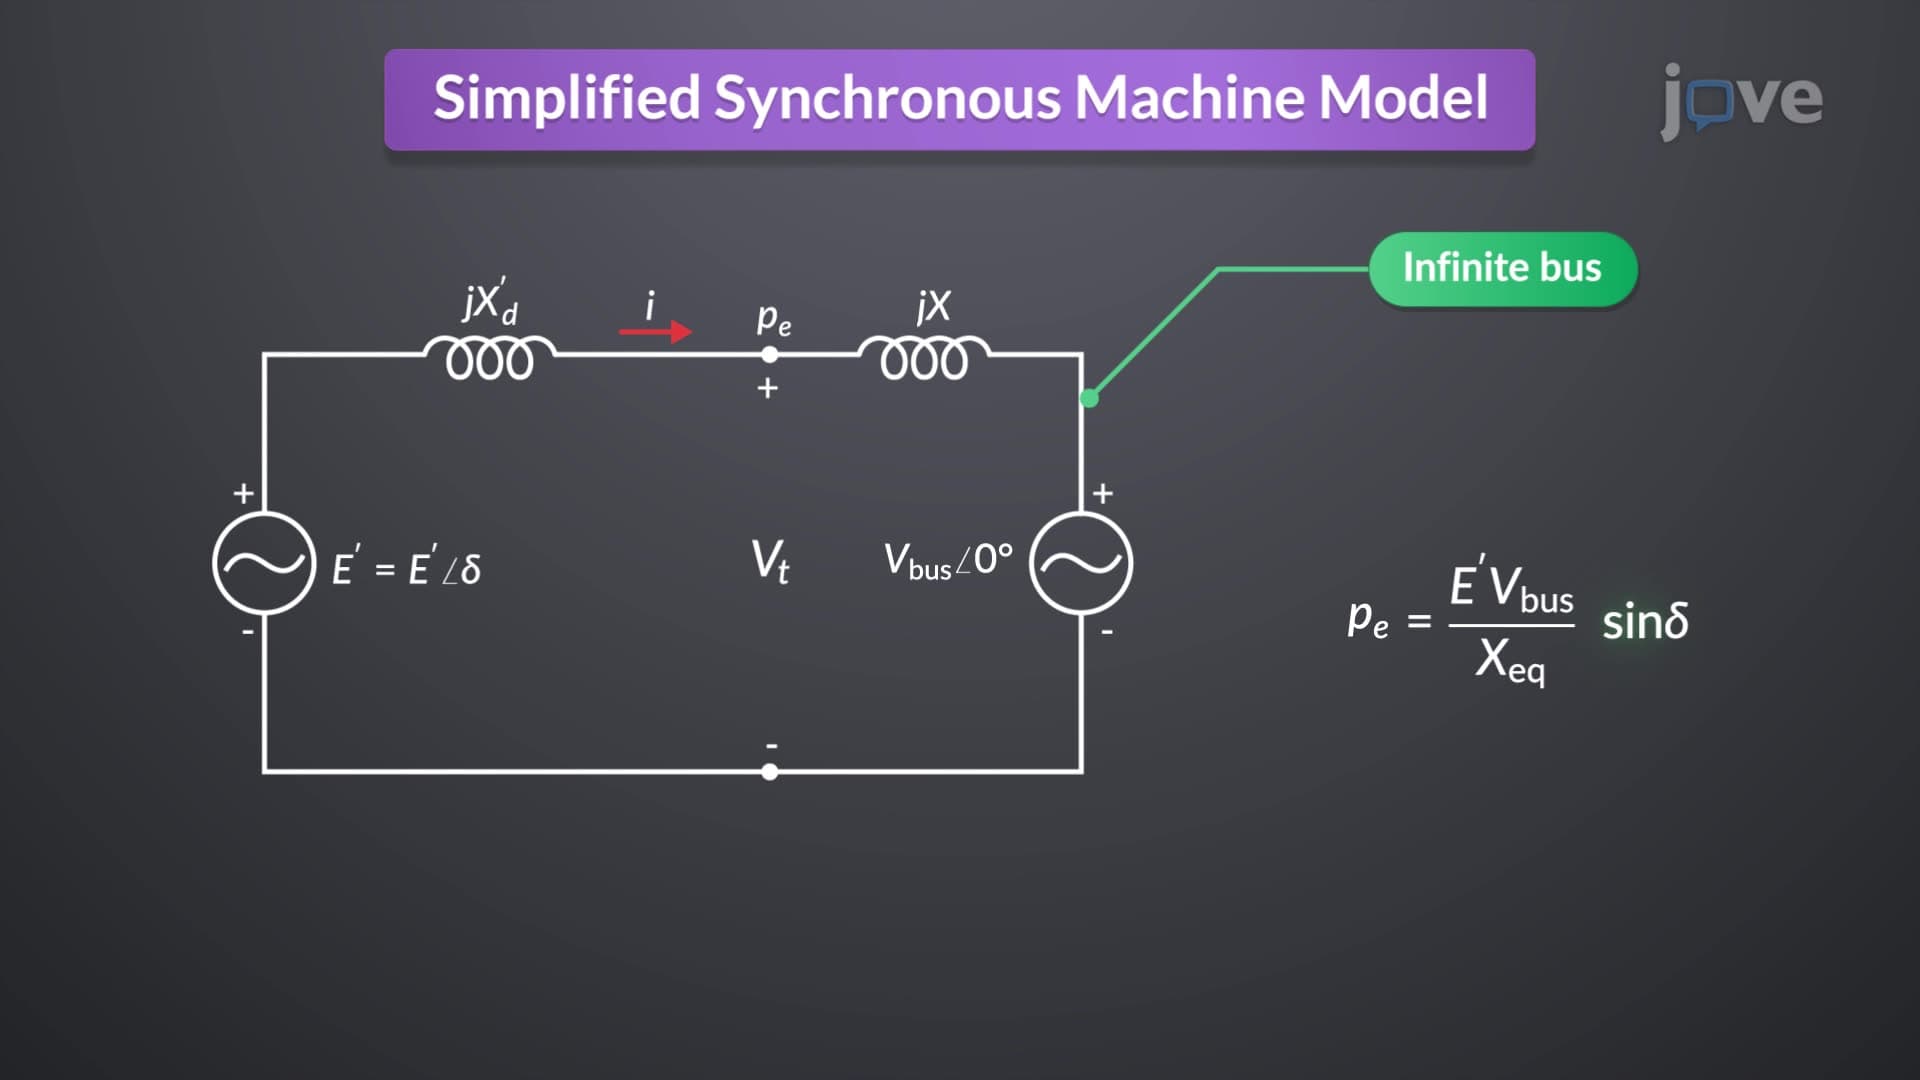
Simplified Synchronous Machine Model
In this model, each generator is connected to a...
 01:24
BIBO stability of continuous and discrete -time systems
To determine the BIBO stability, the convolution integral is utilized when a bounded continuous-time input is applied to a Linear Time-Invariant (LTI) system....
 01:24
One-Degree-of-Freedom System
A one-degree-of-freedom system is defined by an independent variable that determines its state and behavior. One example of a one-degree-of-freedom system is a simple harmonic oscillator, such as a...
 01:20
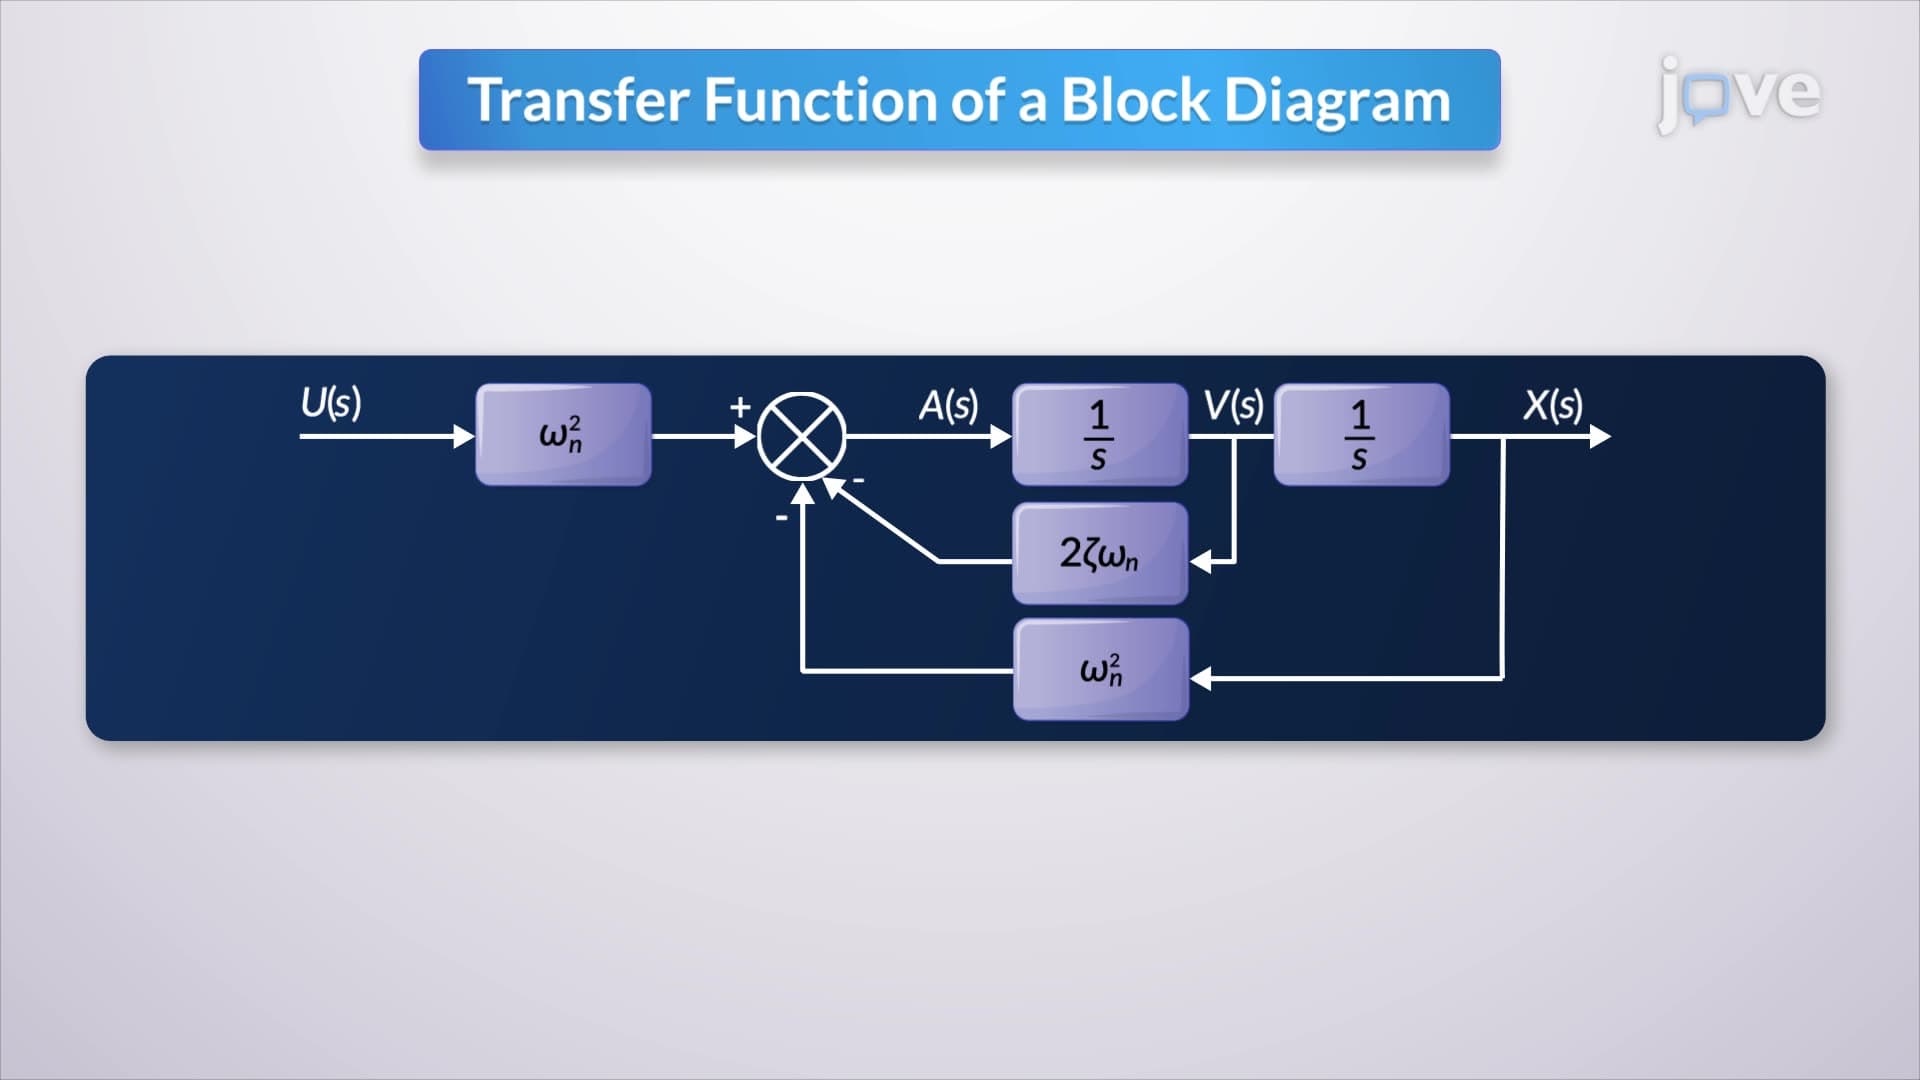
Relation between Mathematical Equations and Block Diagrams
 01:22
Multi-input and Multi-variable systems
In the absence of...