Multilinear Discriminant Analysis for Higher-Order Tensor Data Classification
Related Experiment Video
Updated: Apr 4, 2026
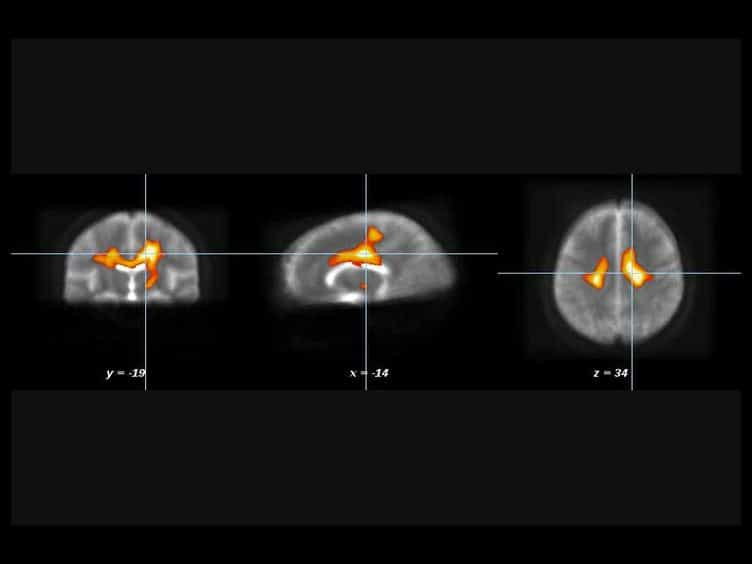
Diffusion Tensor Magnetic Resonance Imaging in the Analysis of Neurodegenerative Diseases
Published on: July 28, 2013

Abstract:
In the past decade, great efforts have been made to extend linear discriminant analysis for higher-order data classification, generally referred to as multilinear discriminant analysis (MDA). Existing examples include general tensor discriminant analysis (GTDA) and discriminant analysis with tensor representation (DATER). Both the two methods attempt to resolve the problem of tensor mode dependency by iterative approximation. GTDA is known to be the first MDA method that converges over iterations. However, its performance relies highly on the tuning of the parameter in the scatter difference criterion. Although DATER usually results in better classification performance, it does not converge, yet the number of iterations executed has a direct impact on DATER's performance. In this paper, we propose a closed-form solution to the scatter difference objective in GTDA, namely, direct GTDA (DGTDA) which also gets rid of parameter tuning. We demonstrate that DGTDA outperforms GTDA in terms of both efficiency and accuracy. In addition, we propose constrained multilinear discriminant analysis (CMDA) that learns the optimal tensor subspace by iteratively maximizing the scatter ratio criterion. We prove both theoretically and experimentally that the value of the scatter ratio criterion in CMDA approaches its extreme value, if it exists, with bounded error, leading to superior and more stable performance in comparison to DATER.


Related Concept Videos
 01:06
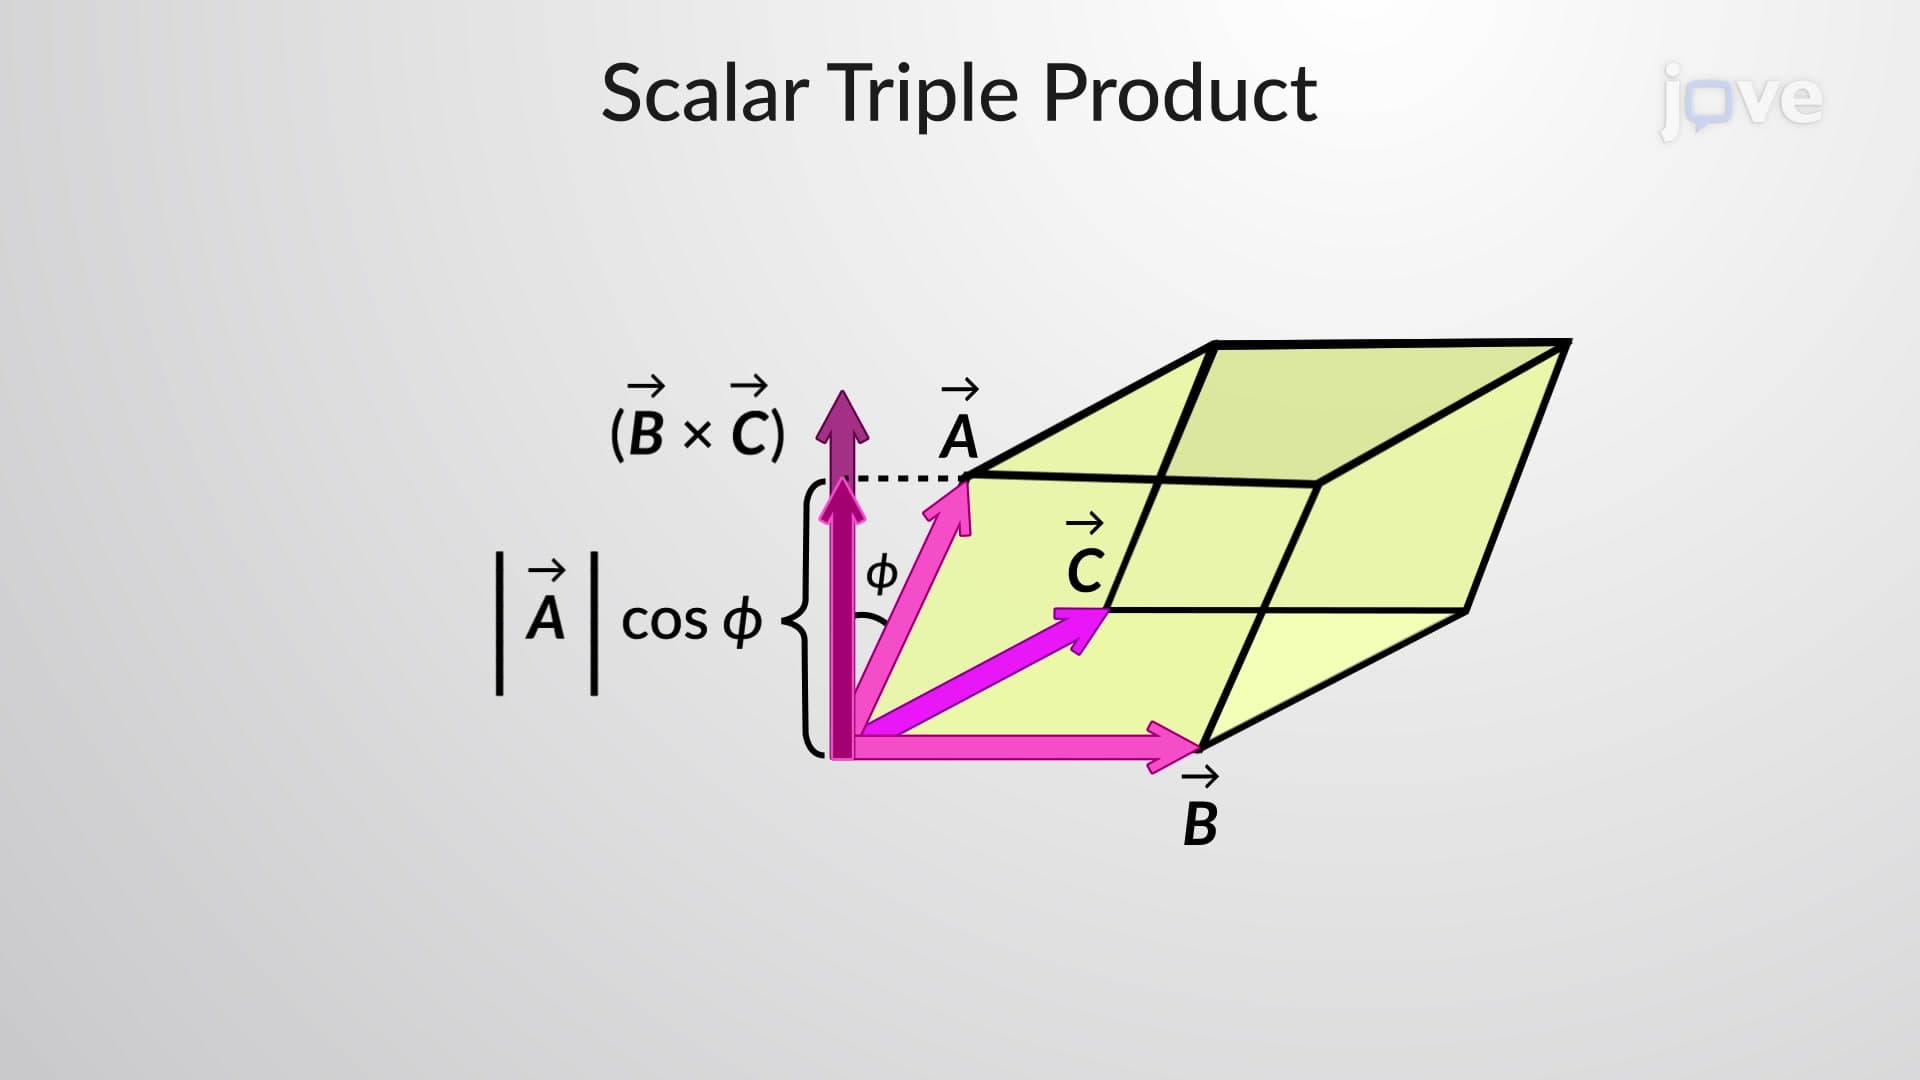
Scalar and Vector Triple Products
The scalar triple product is the dot product of a vector with the cross product of two vectors....
 01:22
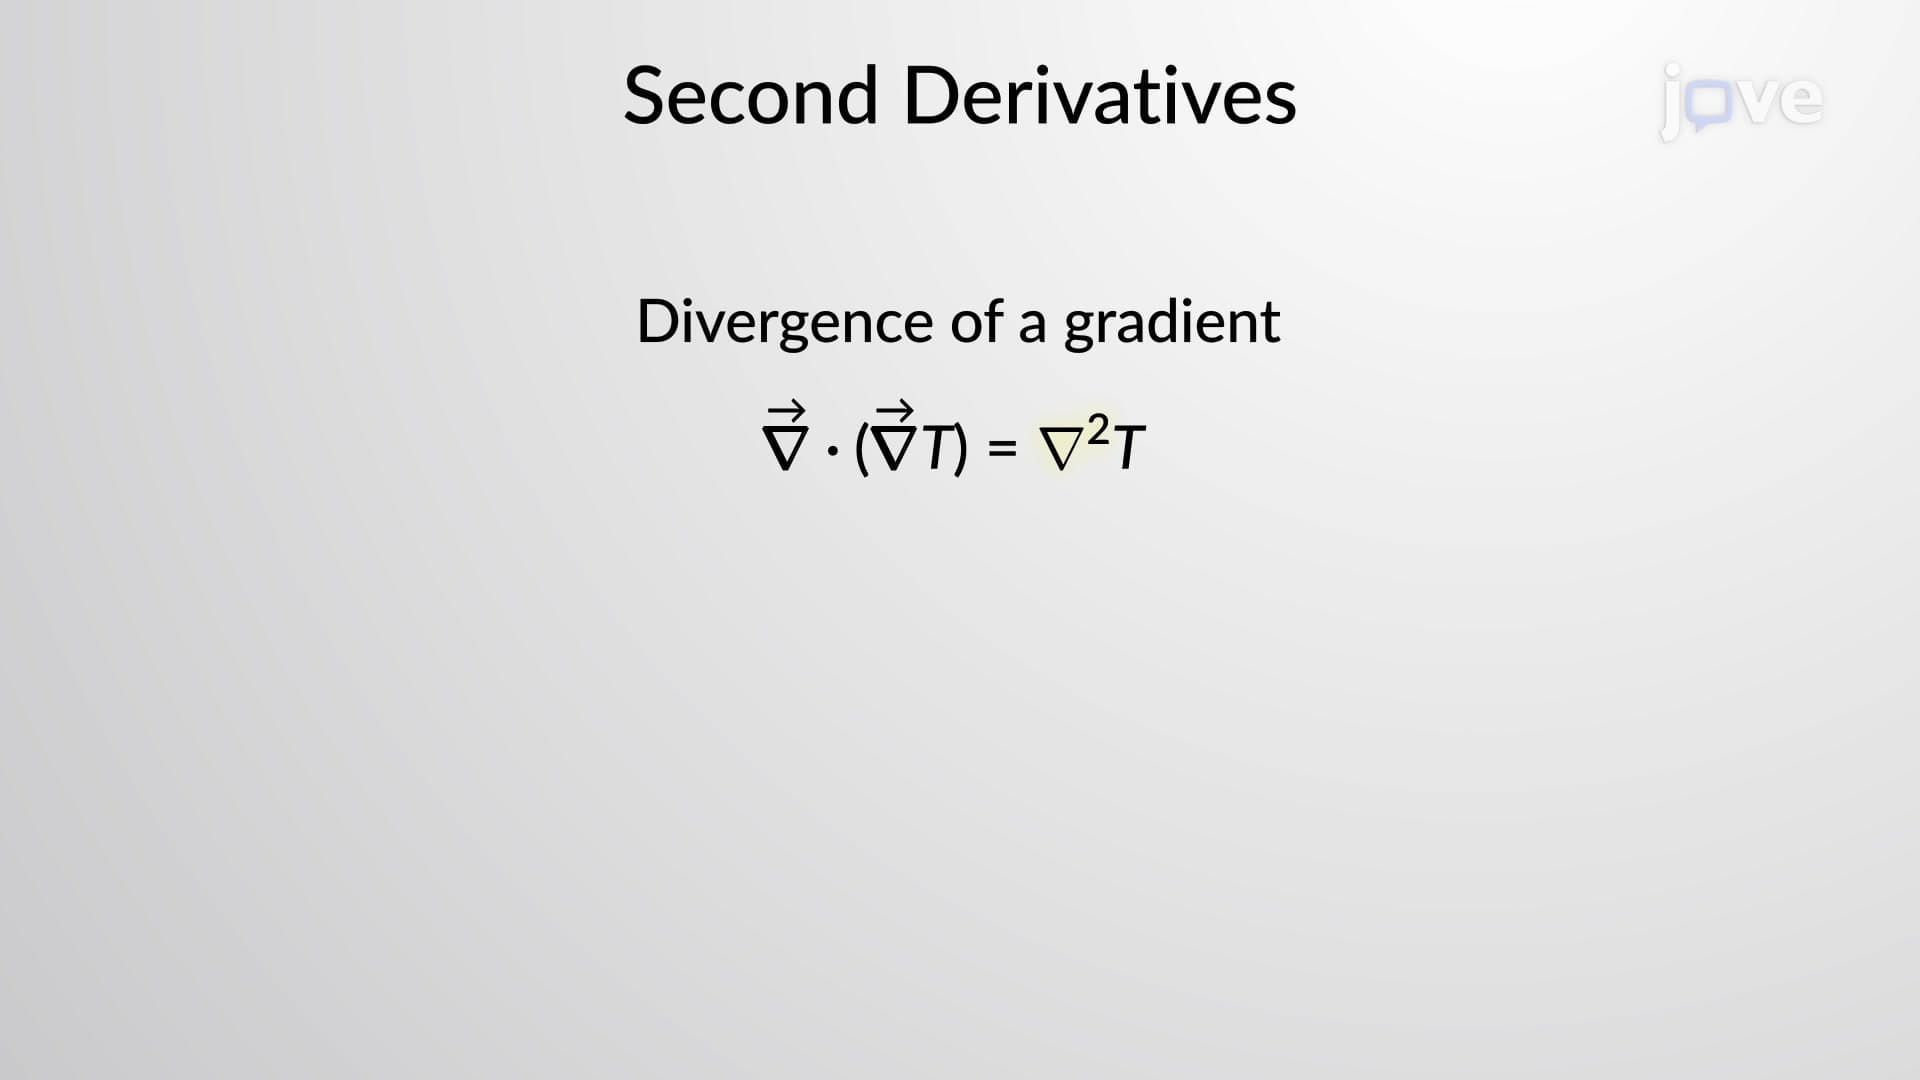
Second Derivatives and Laplace Operator
Consider a scalar function. The curl of its...
 01:08
Vector Algebra: Method of Components
In many applications, the magnitudes and directions of...
 01:26
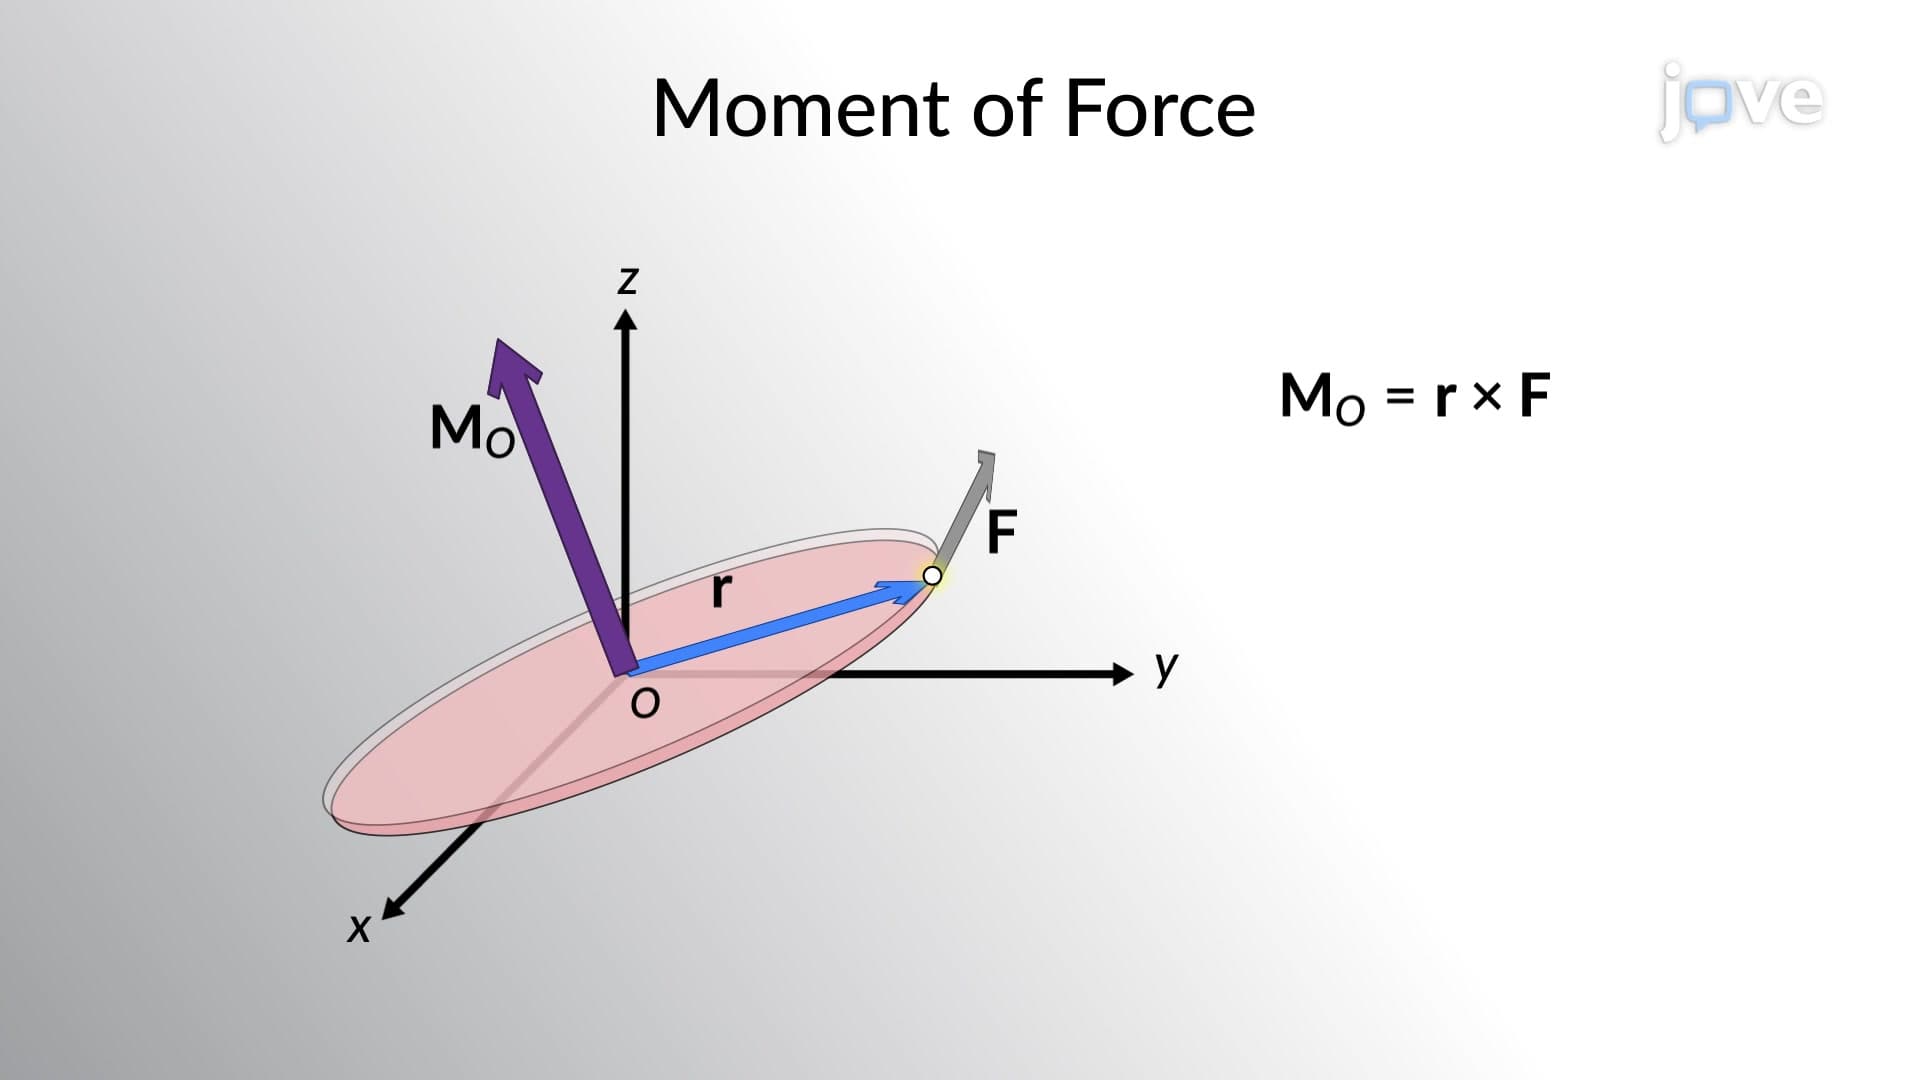
Cartesian Form for Vector Formulation
 01:24
Inertia Tensor
The diagonal components of the inertia tensor matrix represent the moments of inertia concerning the principal axes of the object. These primary axes are defined as the axes where the object experiences the least...
 01:23
Quadratic Models