Globally Optimal Hand-Eye Calibration Using Branch-and-Bound
Related Experiment Video
Updated: Apr 4, 2026
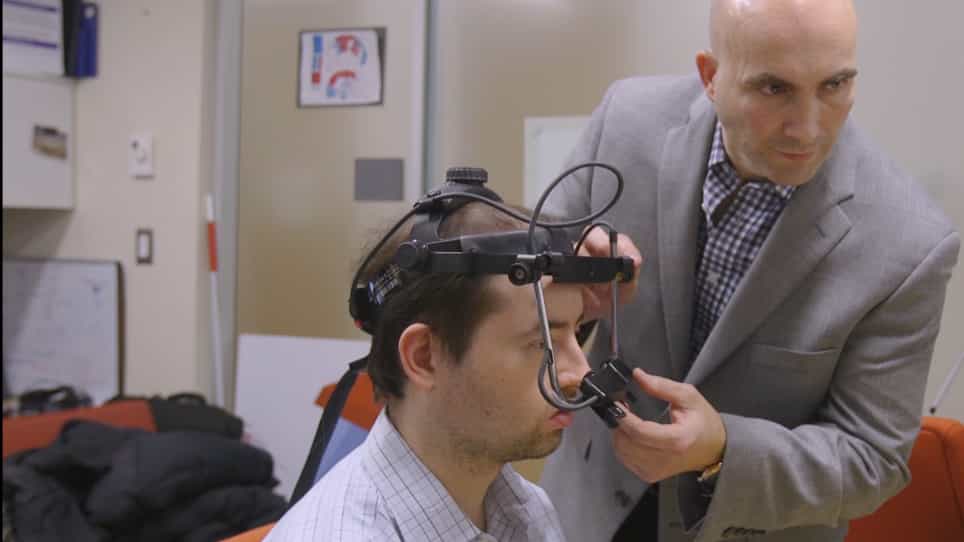
Efficiently Recording the Eye-Hand Coordination to Incoordination Spectrum
Published on: March 21, 2019

Abstract:
This paper introduces a novel solution to the hand-eye calibration problem. It uses camera measurements directly and, at the same time, requires neither prior knowledge of the external camera calibrations nor a known calibration target. Our algorithm uses branch-and-bound approach to minimize an objective function based on the epipolar constraint. Further, it employs Linear Programming to decide the bounding step of the algorithm.Our technique is able to recover both the unknown rotation and translation simultaneously and the solution is guaranteed to be globally optimal with respect to the L∞-norm.
More Related Videos
Related Concept Videos
 01:20
Calibration Curves: Linear Least Squares
For data that follow a straight line, the standard method for fitting is the linear...
 01:11
Glassware Calibration
Volumetric flasks: Volumetric flasks are designed to prepare aqueous solutions of precise volumes accurately with a calibration line on the neck. To calibrate a volumetric flask, it is important to fill it with distilled...
 01:16
Statically Indeterminate Problem Solving
 01:03
Centroid of a Body: Problem Solving
The x-coordinates and y-coordinates of each element's...
 01:10
Calibration Curves: Correlation Coefficient
 01:30
Three-Dimensional Force System:Problem Solving
To solve a three-dimensional force system, first resolve each force into its respective scalar components. Do this using...