Regularization Based Iterative Point Match Weighting for Accurate Rigid Transformation Estimation
Related Experiment Video
Updated: Apr 4, 2026
Three-dimensional Super Resolution Microscopy of F-actin Filaments by Interferometric PhotoActivated Localization Microscopy iPALM
Published on: December 1, 2016

Abstract:
Feature extraction and matching (FEM) for 3D shapes finds numerous applications in computer graphics and vision for object modeling, retrieval, morphing, and recognition. However, unavoidable incorrect matches lead to inaccurate estimation of the transformation relating different datasets. Inspired by AdaBoost, this paper proposes a novel iterative re-weighting method to tackle the challenging problem of evaluating point matches established by typical FEM methods. Weights are used to indicate the degree of belief that each point match is correct. Our method has three key steps: (i) estimation of the underlying transformation using weighted least squares, (ii) penalty parameter estimation via minimization of the weighted variance of the matching errors, and (iii) weight re-estimation taking into account both matching errors and information learnt in previous iterations. A comparative study, based on real shapes captured by two laser scanners, shows that the proposed method outperforms four other state-of-the-art methods in terms of evaluating point matches between overlapping shapes established by two typical FEM methods, resulting in more accurate estimates of the underlying transformation. This improved transformation can be used to better initialize the iterative closest point algorithm and its variants, making 3D shape registration more likely to succeed.
Related Concept Videos
 00:49
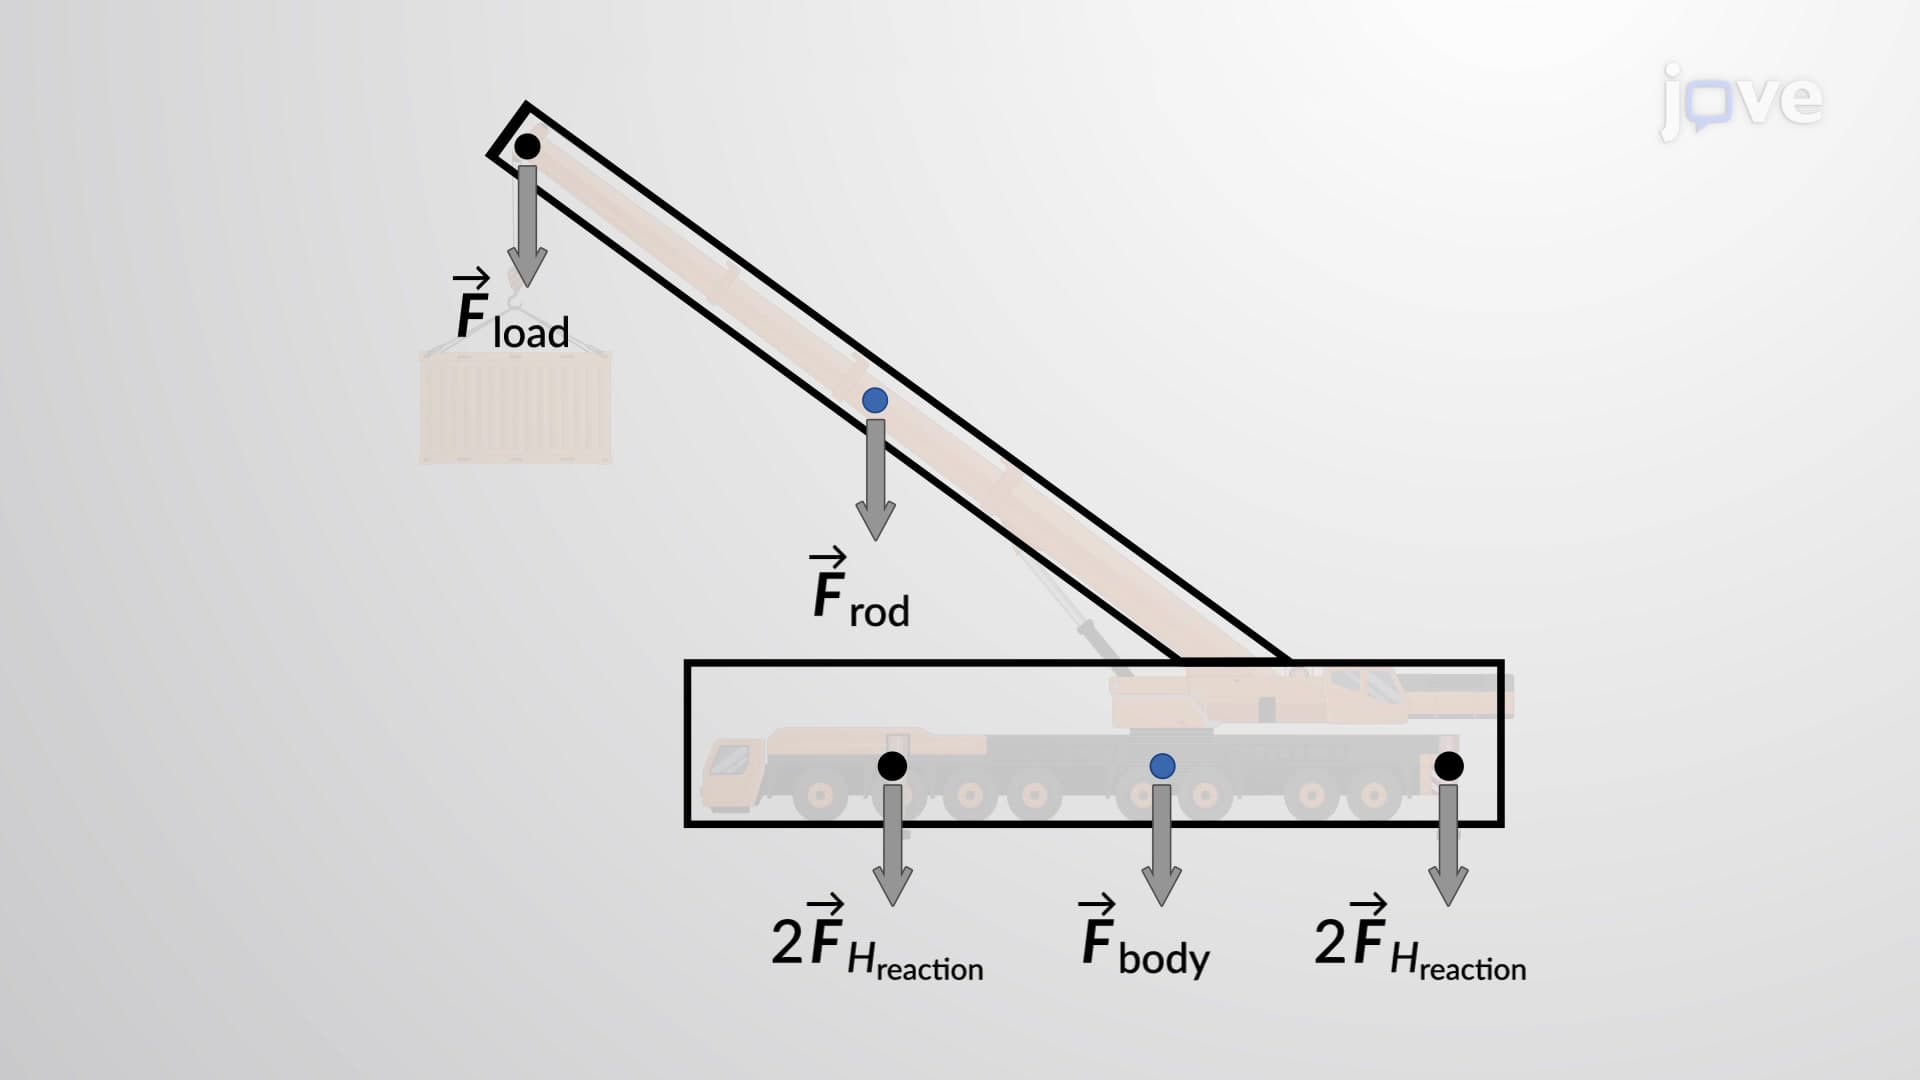
Rigid Body Equilibrium Problems - I
 01:23
Curvilinear Motion: Rectangular Components
As the car advances, its position evolves over time. Quantifying the car's velocity involves computing the...
 01:26
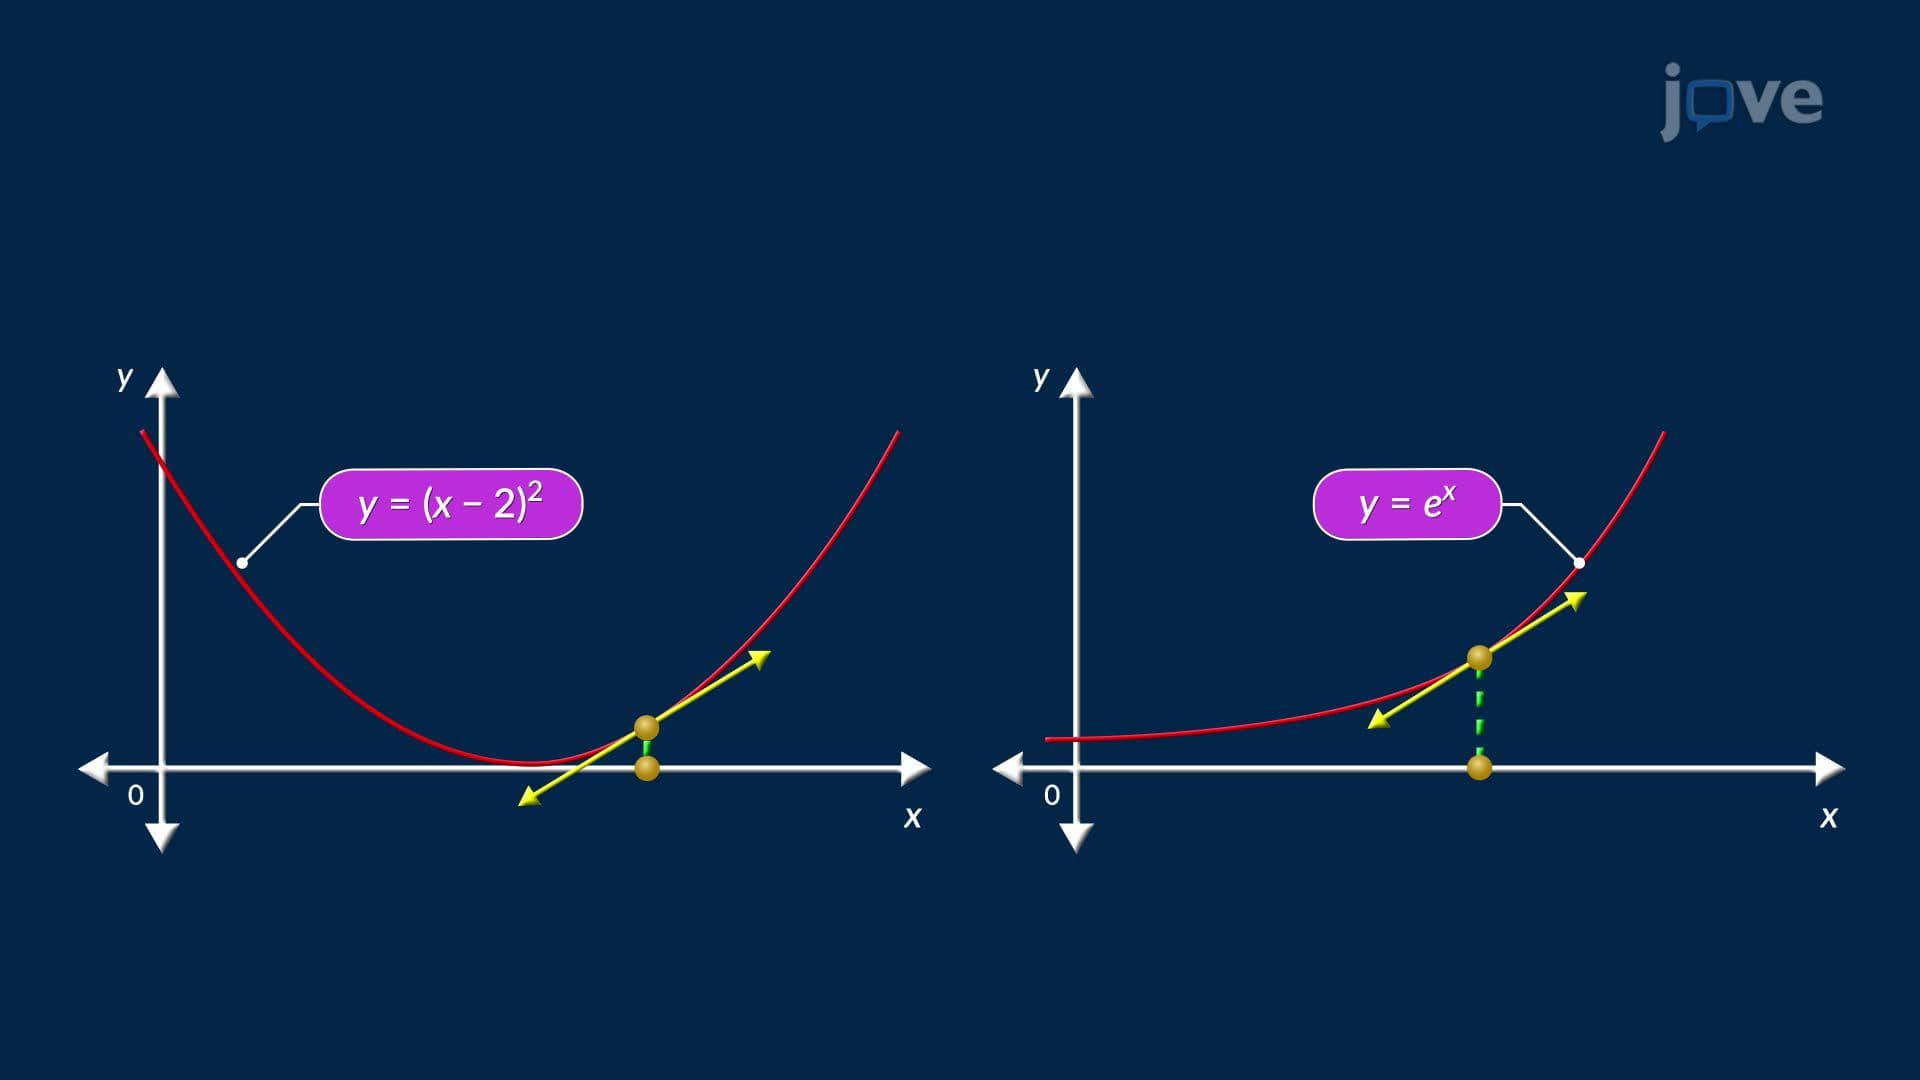
Linearization and Approximation
 01:12
Equation of Motion for a Rigid Body
The combined moments generated about the center of mass of the object are equal to the rate of change of the angular momentum of the body. An external force, when applied at a different...
 01:21
Rigid Body Equilibrium Problems - II
Consider two children sitting on a seesaw, which has negligible mass. The first child has a mass (m1) of 26 kg and sits at point A, which is 1.6 meters (r1) from the pivot point B; the second child has a mass (m2) of 32 kg and sits at point C. How far from the pivot point B should the second child sit (r2) to balance the seesaw?
 01:30
Kinematic Equations for Rotation
For instance, imagine a point A on a rigid body engaged in circular motion. The translational velocity of this particular point can be calculated by taking the time derivatives of the displacement equation, which essentially measures the...