Implicit Multibody Penalty-BasedDistributed Contact
Related Experiment Video
Updated: Apr 4, 2026

Estimation of Contact Regions Between Hands and Objects During Human Multi-Digit Grasping
Published on: April 21, 2023

Abstract:
The penalty method is a simple and popular approach to resolving contact in computer graphics and robotics. Penalty-based contact, however, suffers from stability problems due to the highly variable and unpredictable net stiffness, and this is particularly pronounced in simulations with time-varying distributed geometrically complex contact. We employ semi-implicit integration, exact analytical contact gradients, symbolic Gaussian elimination and a SVD solver to simulate stable penalty-based frictional contact with large, time-varying contact areas, involving many rigid objects and articulated rigid objects in complex conforming contact and self-contact. We also derive implicit proportional-derivative control forces for real-time control of articulated structures with loops. We present challenging contact scenarios such as screwing a hexbolt into a hole, bowls stacked in perfectly conforming configurations, and manipulating many objects using actively controlled articulated mechanisms in real time.


Related Concept Videos
 01:19
Distributed Loads
For example, consider a bookshelf filled with books stacked vertically adjacent to each other. The weight of the books is evenly distributed over the length of the shelf. As a result, the pressure at different locations on the surface of the...
 01:21
Distributed Loads: Problem Solving
 01:06
Virtual Work for a System of Connected Rigid Bodies
Next,...
 01:10
Second Law: Motion under Same Force
Let's imagine a person is...
 01:22
Generalized Hooke's Law
 01:27
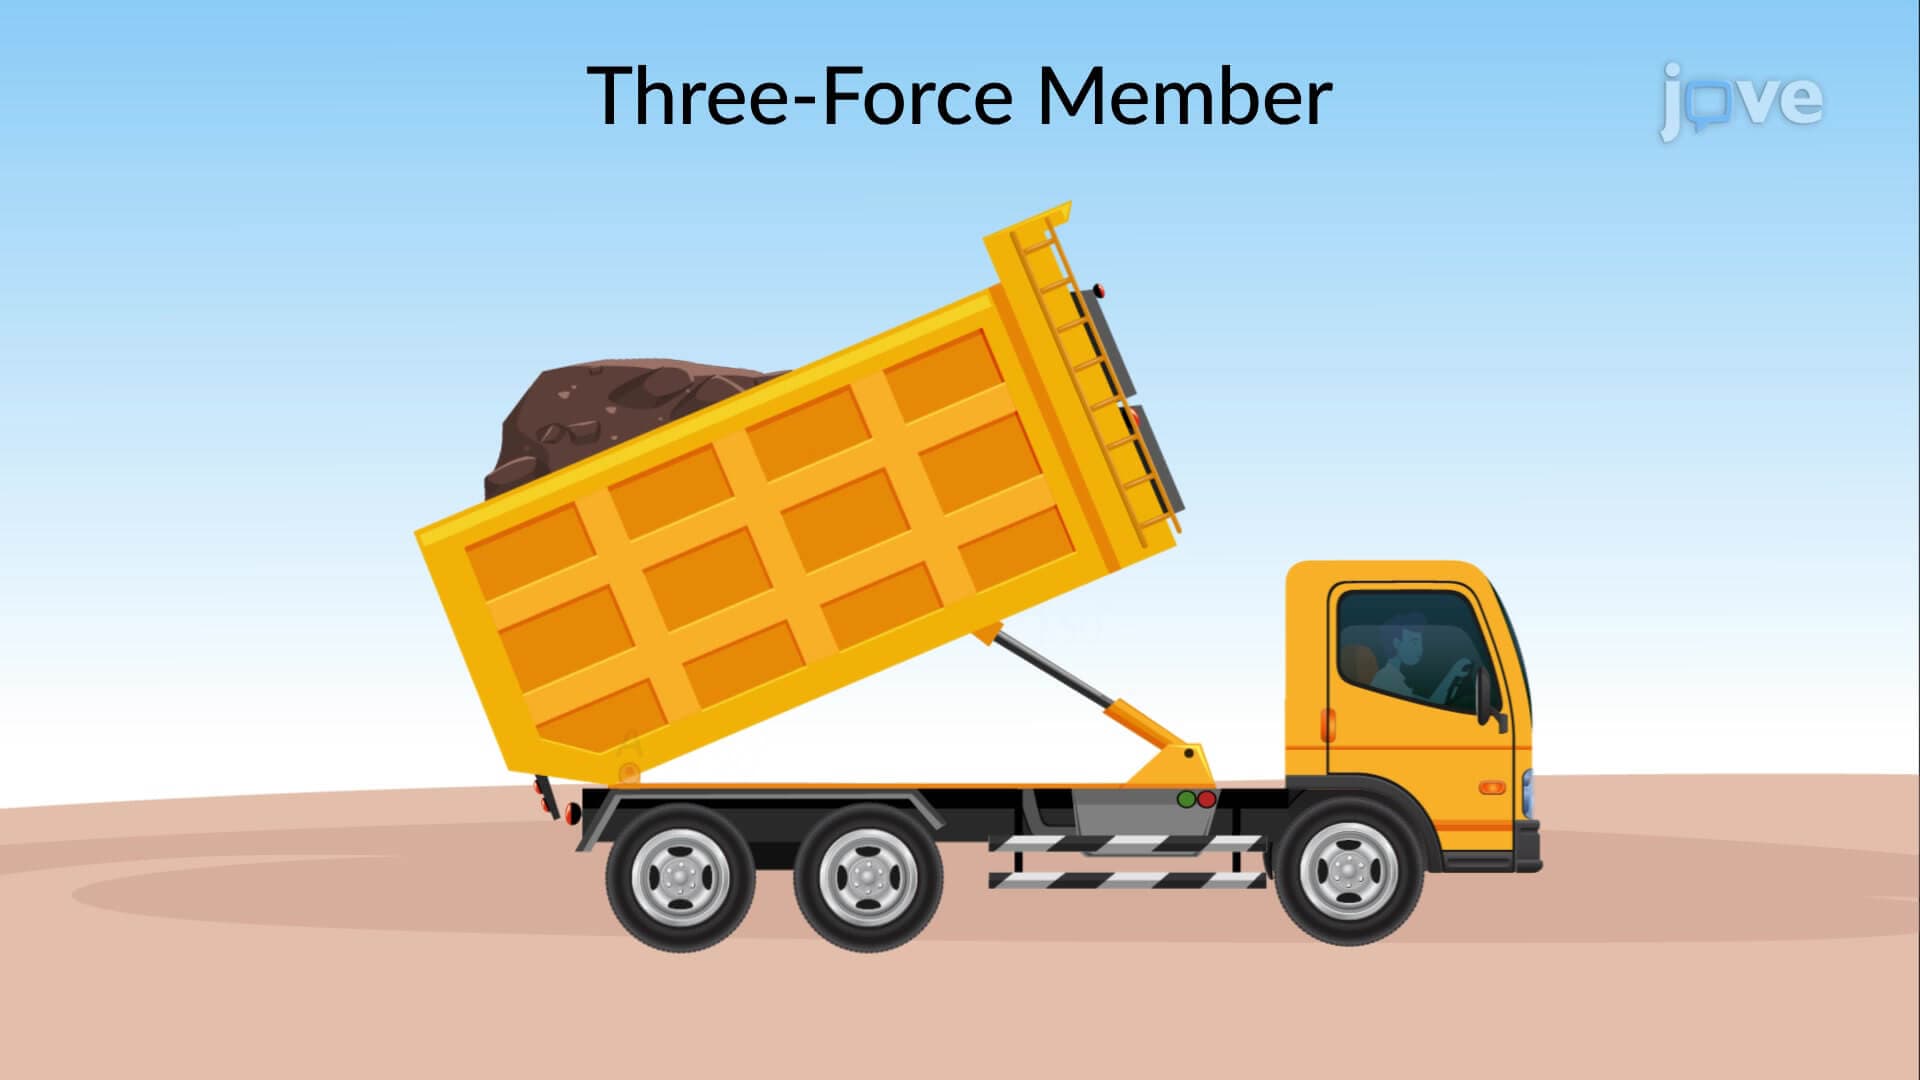
Three Force Member
For example, consider a dumpster connected to a pin support at point A and a pin attached to a hydraulic cylinder at point B.