A Structured Rehabilitation Protocol for Improved Multifunctional Prosthetic Control: A Case Study
Related Experiment Video
Updated: Mar 30, 2026

A Structured Rehabilitation Protocol for Improved Multifunctional Prosthetic Control: A Case Study
Published on: November 6, 2015
Aidan Dominic Roche1, Ivan Vujaklija2, Sebastian Amsüss2
1Christian Doppler Laboratory for Restoration of Extremity Function; Department of Surgery, Division of Plastic and Reconstructive Surgery, Medical University of Vienna; aidan.roche@meduniwien.ac.at.

Abstract:
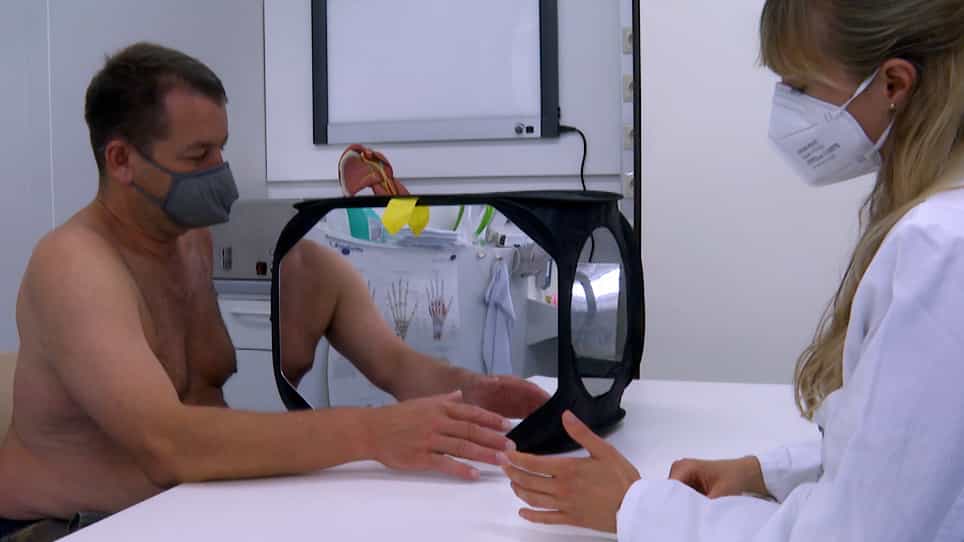
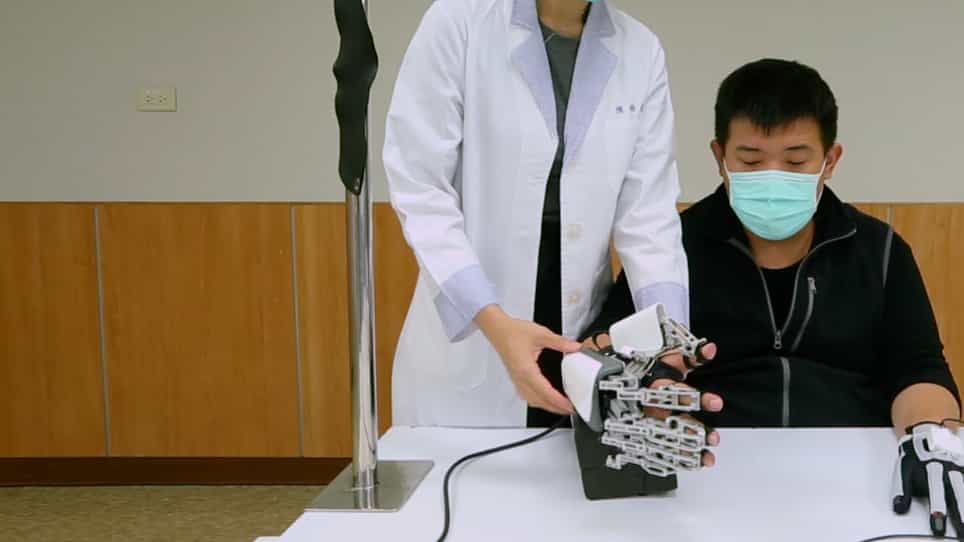
Advances in robotic systems have resulted in prostheses for the upper limb that can produce multifunctional movements. However, these sophisticated systems require upper limb amputees to learn complex control schemes. Humans have the ability to learn new movements through imitation and other learning strategies. This protocol describes a structured rehabilitation method, which includes imitation, repetition, and reinforcement learning, and aims to assess if this method can improve multifunctional prosthetic control. A left below elbow amputee, with 4 years of experience in prosthetic use, took part in this case study. The prosthesis used was a Michelangelo hand with wrist rotation, and the added features of wrist flexion and extension, which allowed more combinations of hand movements. The participant's Southampton Hand Assessment Procedure score improved from 58 to 71 following structured training. This suggests that a structured training protocol of imitation, repetition and reinforcement may have a role in learning to control a new prosthetic hand. A larger clinical study is however required to support these findings.