Observation and physical practice: different practice contexts lead to similar outcomes for the acquisition of kinematic information
Related Experiment Video
Updated: Mar 30, 2026
An Inertial Measurement Unit Based Method to Estimate Hip and Knee Joint Kinematics in Team Sport Athletes on the Field
Published on: May 26, 2020
John J Buchanan1, Inchon Park2
1Human Performance Labs, Perception-Action Division, Department of Health and Kinesiology, Texas A&M University, 4243 TAMU, College Station, TX, USA. jbuchanan@hlkn.tamu.edu.

Abstract:
This study differentiated the contributions of physical and observational practice to the learning of a single-limb multi-joint coordination pattern. Three groups (physical-practice, observation-practice, observation-physical) practiced for 2 days and were given two performance tests 24 h after the second practice session. The performance tests revealed that physical and observational practice contributed similarly to identifying and using kinematic information related to the relative motion direction between joints (lead/lag relationship) and to the to-be-learned relative phase pattern (ϕ = 90°). Physical practice resulted in more stable coordination during performance tests and in the ability to produce different joint amplitudes with less variability. A serendipitous finding was that maximum elbow flexion (point of movement reversal) emerged as a kinematic event around which elbow and wrist coordination were organized. Movement reversals often serve to anchor the movement dynamics, and this anchoring effect was evident following both physical and observational practice, yet physical practice resulted in an advantage with regard to this anchor point on several kinematic measures. The results are discussed within the context of contemporary behavioral theories (coordination dynamics, visual perception perspective) of observational learning.
Related Concept Videos
 01:15
Kinematic Equations: Problem Solving
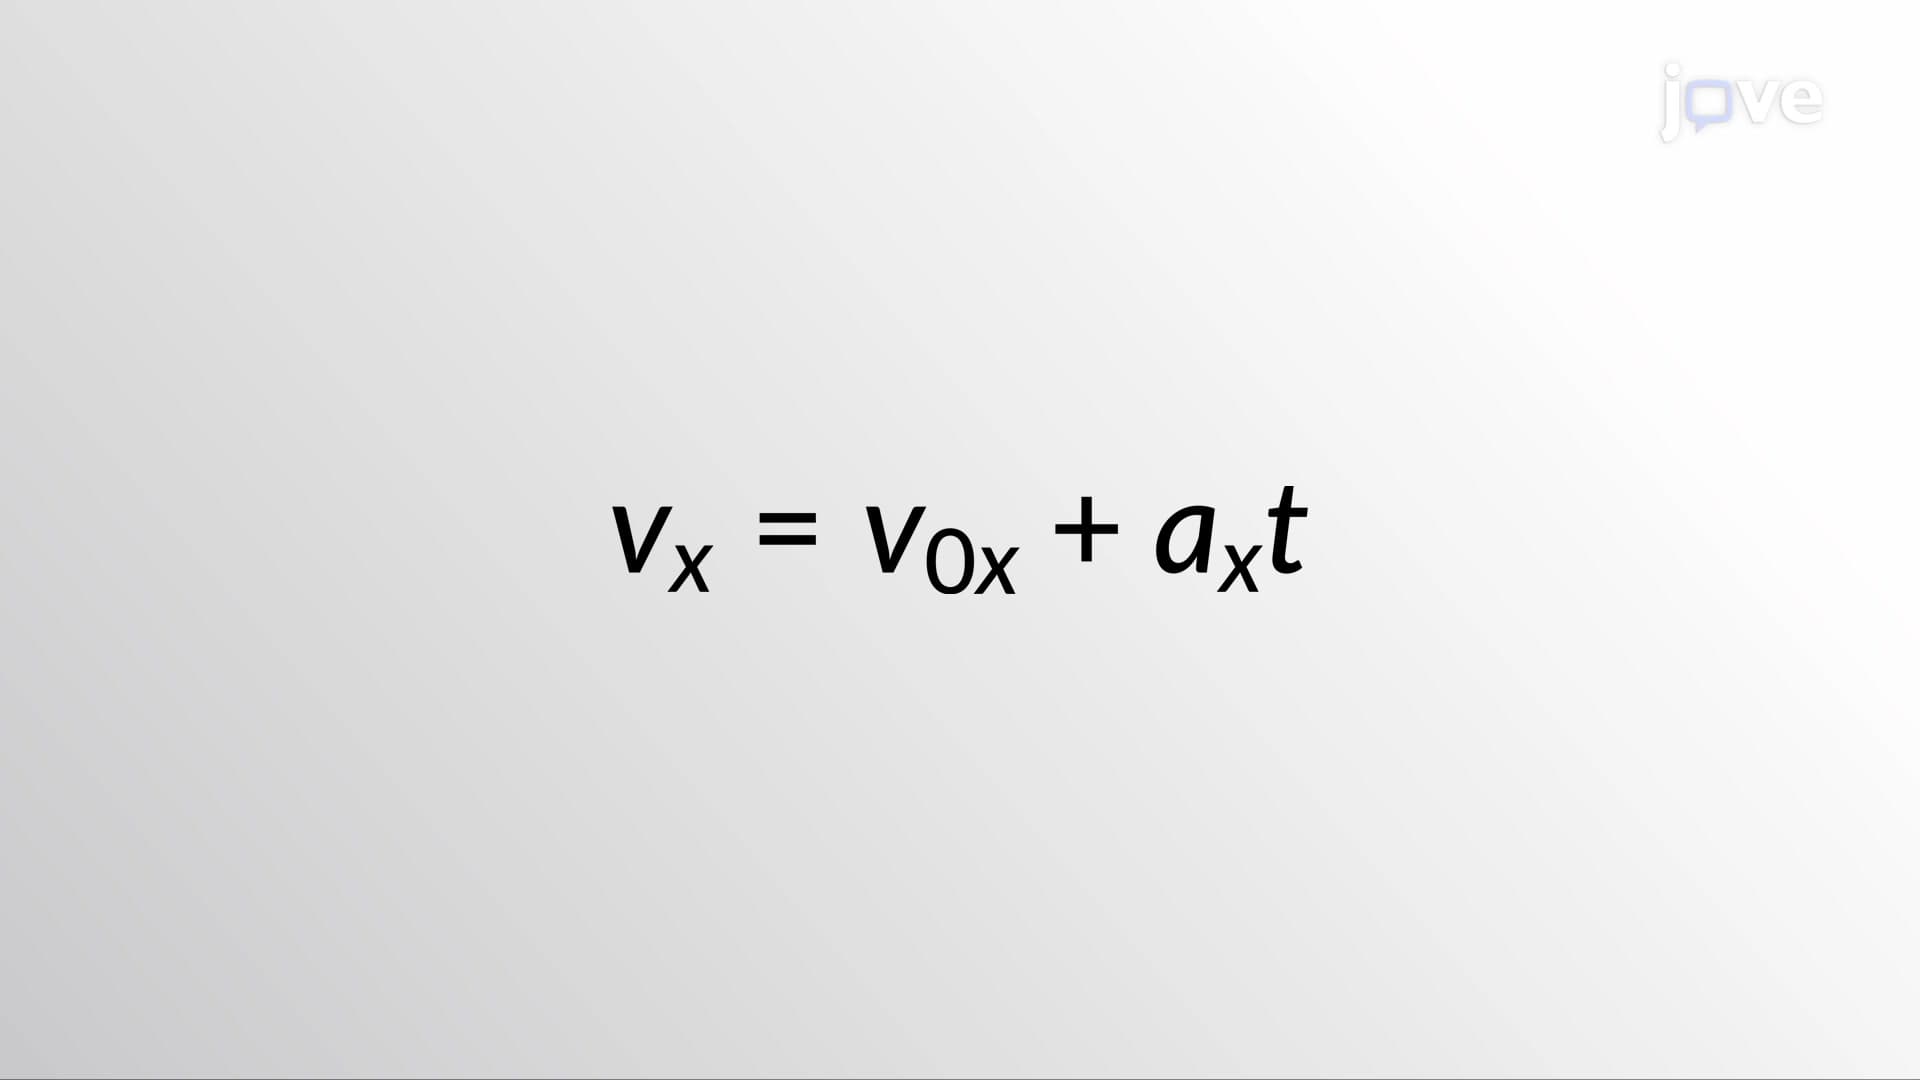 01:26
Kinematic Equations - I
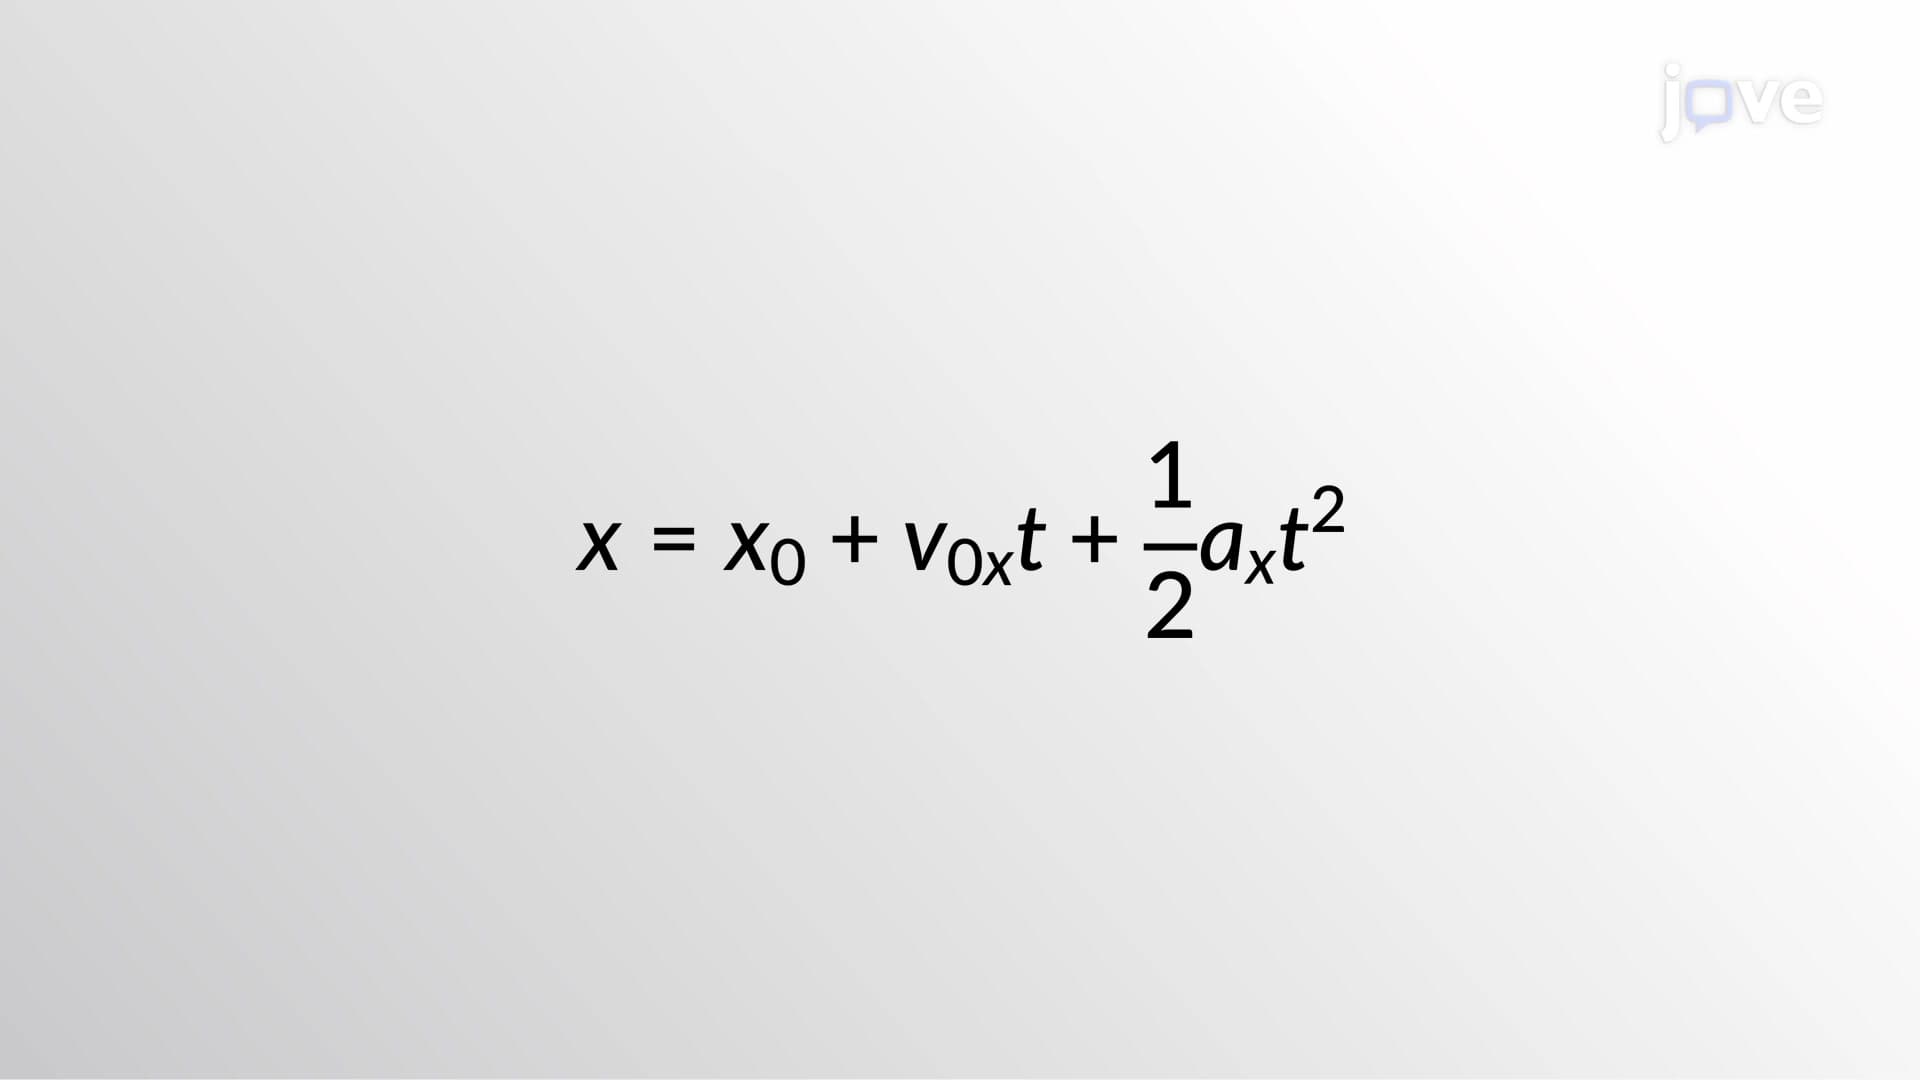 01:17
Kinematic Equations - II
Suppose a car merges into freeway traffic on a 200 m long ramp. If its initial velocity is 10 m/s and it accelerates at 2 m/s2, then the...
 01:30
Kinematic Equations for Rotation
For instance, imagine a point A on a rigid body engaged in circular motion. The translational velocity of this particular point can be calculated by taking the time derivatives of the displacement equation, which essentially measures the...
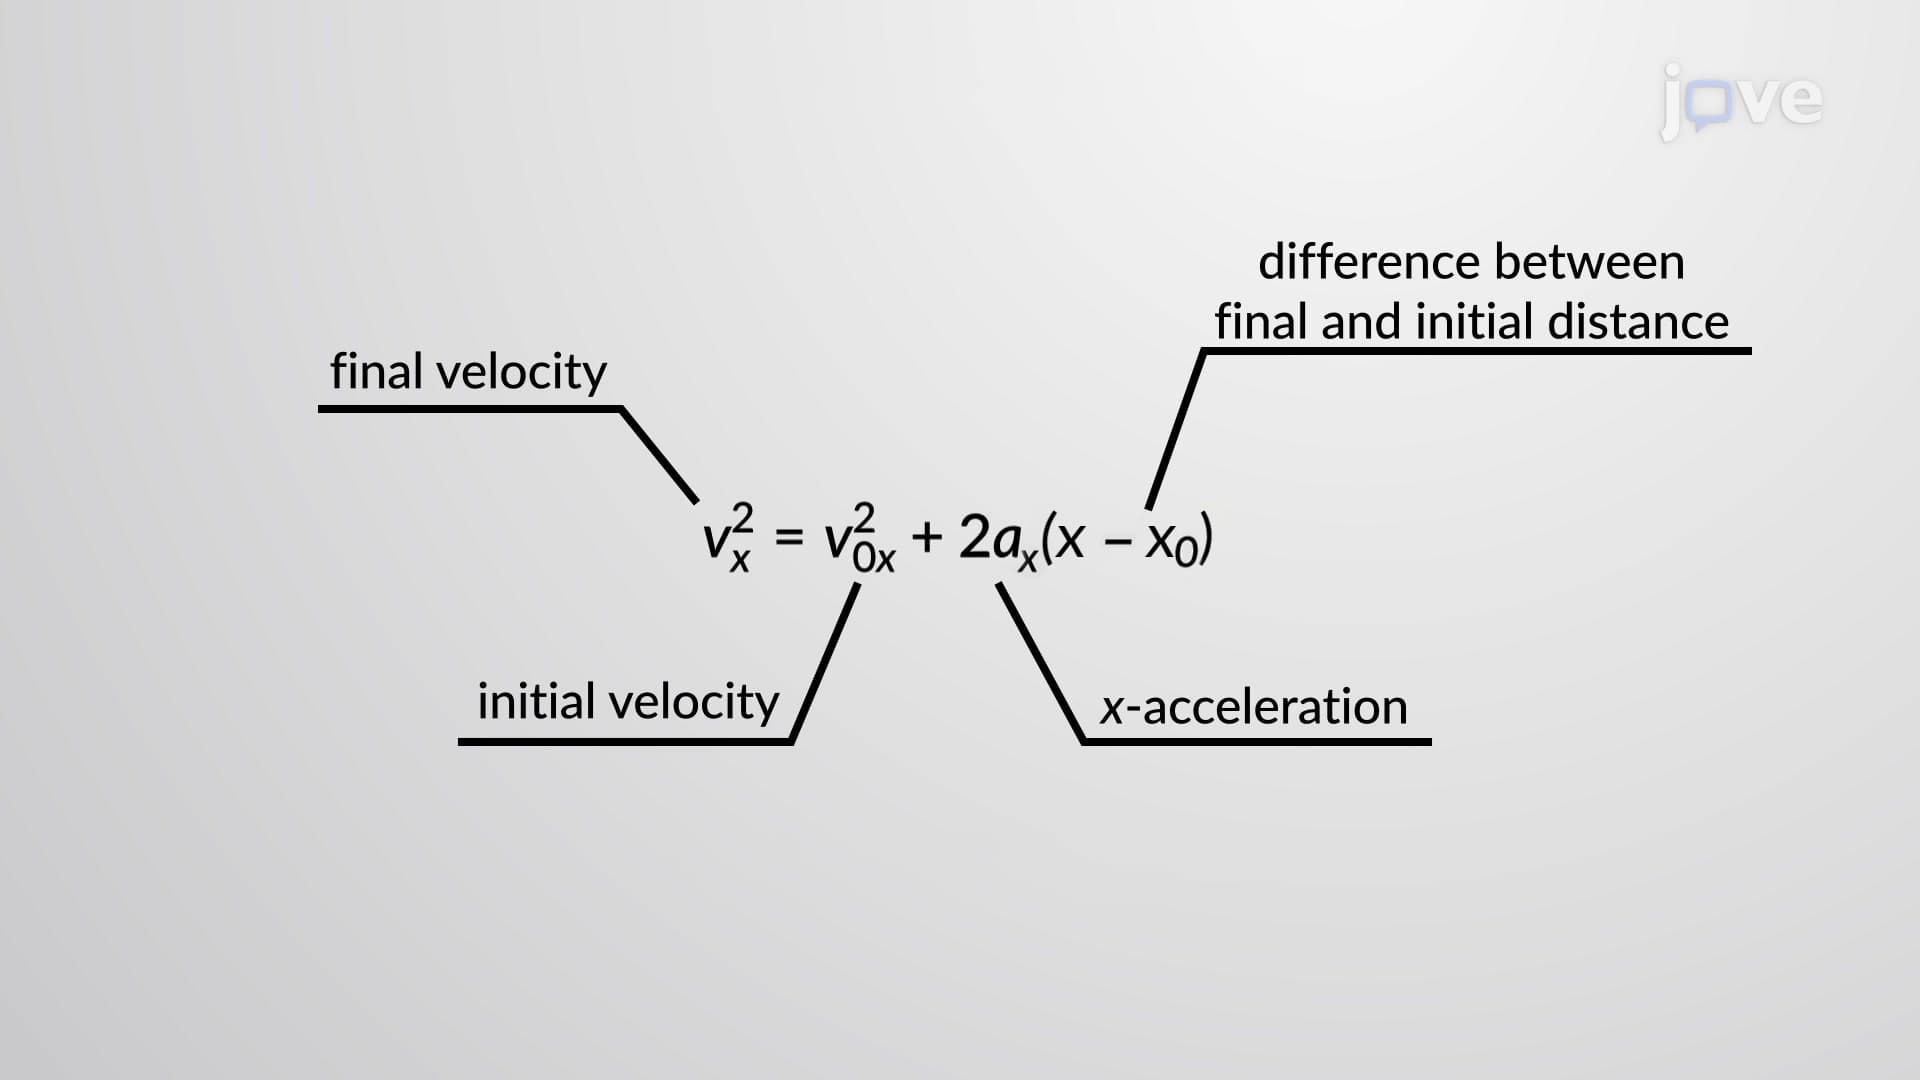 01:18
Kinematic Equations - III
Using the kinematic equations,...
 01:24
Absolute Motion Analysis- General Plane Motion
As the drone's propellers rotate, an upward force is generated that counteracts the force of gravity, enabling the drone to lift off from the ground. This initial movement of the drone is along a straight path, representing a form of translational motion. In this phase, every point on the...