Related Experiment Video
Updated: Oct 29, 2026
Quantifying Learning in Young Infants: Tracking Leg Actions During a Discovery-learning Task
Published on: June 1, 2015
Lower-limb coordination during the rear-leg roundhouse kick in competitive taekwondo: a vector-coding analysis
Qi Guo1,2,3, Yong Ma4,5,6,7, Lin Liu8,9
1School of Intelligent Sports Engineering, Wuhan Sports University, No. 461 Luoyu Road, Wuhan, Hubei Province, 430079, China.

Objective:
To investigate whether differences exist in coupling angle (CA)-derived joint coordination pattern characteristics and coordination variability between the dominant side (DS) and non-dominant side (NS) during successful scoring rear-leg roundhouse kick (RLRK) in competitive taekwondo athletes.
Methods:
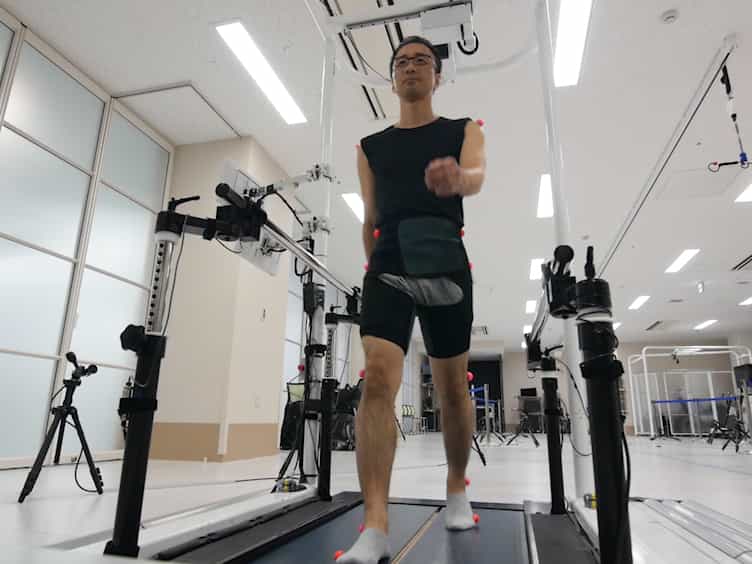
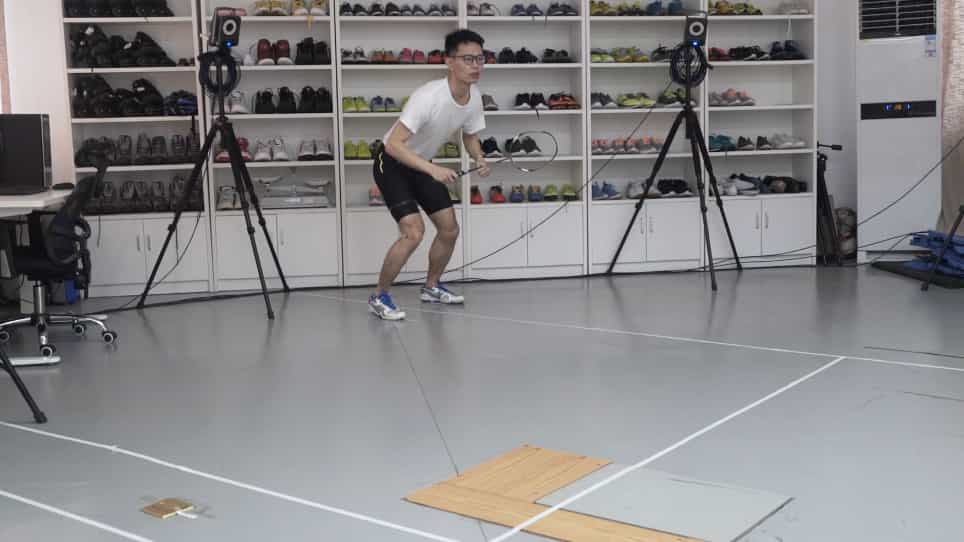
Twelve male taekwondo athletes were recruited to perform RLRK with both the DS and NS. Lower-limb kinematic data were collected using a Vicon three-dimensional motion capture system. Signals from the Daedo electronic protector and a Kistler force platform were used for valid trial selection and movement event identification. Custom-written MATLAB code was used to calculate CA trajectories and coordination variability for lower-limb joint couplings. CA data were analyzed using circular statistics, with mean CA used to characterize CA-derived joint coordination pattern characteristics, and coordination variability was compared using paired-samples t-tests.
Results:
No significant bilateral differences in mean CA were observed during the knee-lift phase. The bilateral differences in mean CA were mainly observed during the kicking and recovery phases, reflecting side-related differences in coordination characteristics represented by CA. Specifically, significant bilateral differences were found in the frontal-plane hip-ankle coupling and sagittal-plane knee-ankle coupling during the kicking phase (p = 0.037; p = 0.026), and in the sagittal-plane knee-ankle coupling during the recovery phase (p = 0.016). Significant side-related differences in coordination variability were observed across all three movement phases. During the knee-lift and kicking phases, significant differences were found in the sagittal-plane knee-ankle coupling (p = 0.002; p = 0.015). During the recovery phase, significant bilateral differences were observed in the frontal-plane hip-ankle coupling (p = 0.008), sagittal-plane hip-knee coupling (p = 0.027), and sagittal-plane knee-ankle coupling (p = 0.044).
Conclusions:
Competitive taekwondo athletes exhibit side-specific lower-limb joint coordination control strategies when executing RLRK. These differences were reflected in mean CA-based coordination pattern characteristics and coordination variability. Lower coordination variability in certain joint couplings on the DS during the knee-lift and kicking phases suggests that the DS may adopt a relatively more stable coordination control strategy during the key output stages of the movement. In the recovery phase, bilateral differences were mainly reflected in joint-specific coordination organization and in the distribution of coordination variability.
Related Concept Videos
 01:30
Vector Functions and Motion: Problem Solving
 01:15
Kinematic Equations: Problem Solving
 01:24
Muscle Coordination and Action
Agonists
Agonist muscles, often called prime movers, are the primary muscles responsible for producing a specific movement.
 01:29
Relative Motion Analysis using Rotating Axes-Problem Solving
Here, in order to determine the magnitude of velocity and acceleration for point...
 01:25
Relative Motion Analysis using Rotating Axes
However, to express the relative position of point B relative to point A, an additional frame of reference, denoted as x'y', is necessary. This additional frame not only translates but also rotates relative to the fixed frame, making it instrumental in...
 01:22
Relative Motion Analysis using Rotating Axes - Acceleration
Time differentiation is...