Related Experiment Video
Updated: Mar 27, 2026

Magnetically-Assisted Remote Controlled Microcatheter Tip Deflection under Magnetic Resonance Imaging
Published on: April 4, 2013
Modeling and Validation of the Three-Dimensional Deflection of an MRI-Compatible Magnetically Actuated Steerable

Objective:
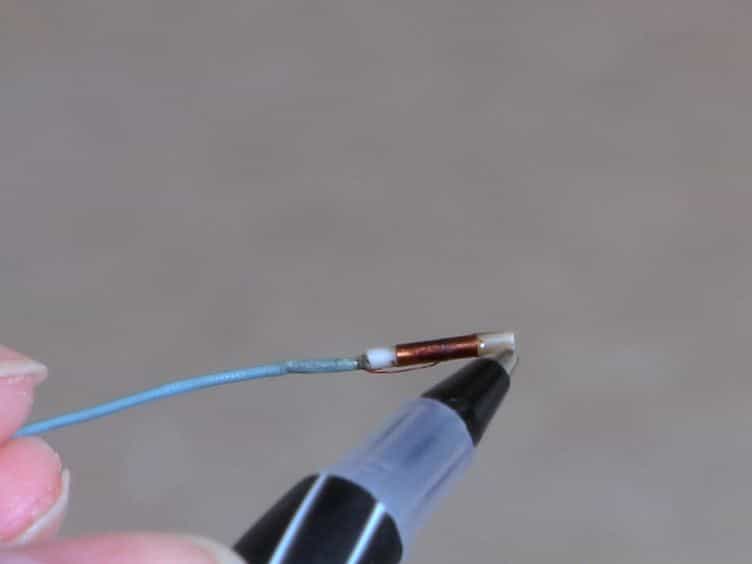
This paper presents the 3-D kinematic modeling of a novel steerable robotic ablation catheter system. The catheter, embedded with a set of current-carrying microcoils, is actuated by the magnetic forces generated by the magnetic field of the magnetic resonance imaging (MRI) scanner.
Methods:
This paper develops a 3-D model of the MRI-actuated steerable catheter system by using finite differences approach. For each finite segment, a quasi-static torque-deflection equilibrium equation is calculated using beam theory. By using the deflection displacements and torsion angles, the kinematic model of the catheter system is derived.
Results:
The proposed models are validated by comparing the simulation results of the proposed model with the experimental results of a hardware prototype of the catheter design. The maximum tip deflection error is 4.70 mm and the maximum root-mean-square error of the shape estimation is 3.48 mm.
Conclusion:
The results demonstrate that the proposed model can successfully estimate the deflection motion of the catheter.
Significance:
The presented 3-D deflection model of the magnetically controlled catheter design paves the way to efficient control of the robotic catheter for the treatment of atrial fibrillation.