Related Experiment Video
Updated: Mar 27, 2026
Development of a Novel Task-oriented Rehabilitation Program using a Bimanual Exoskeleton Robotic Hand
Published on: May 20, 2020
Design and fabrication of a three dimensional printable non-assembly articulated hand exoskeleton for rehabilitation

Abstract:
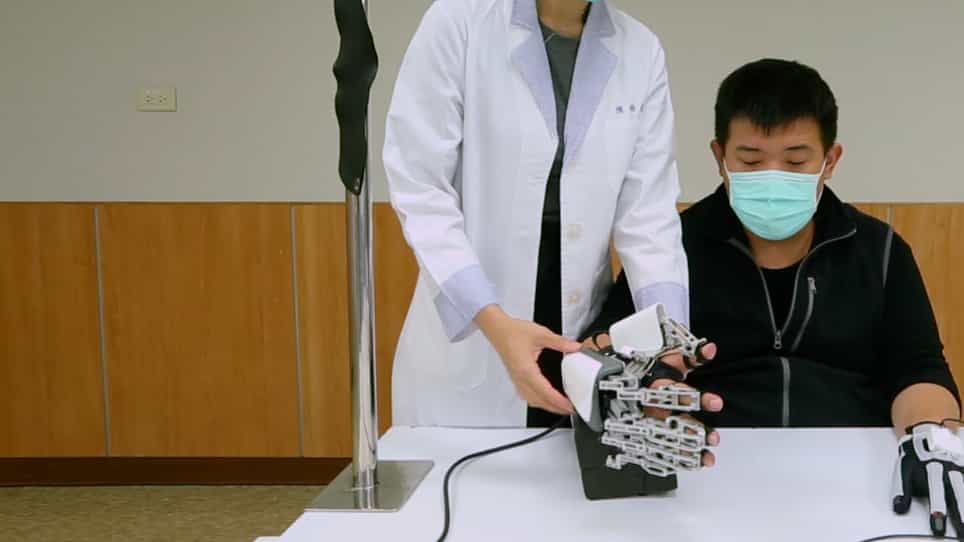
Robotic rehabilitation has proven to be cost-effective in accelerating the rehabilitation process by eliminating the constant need for supervision by a therapist. This work aimed to design and develop a novel three-dimensional (3D) printable non-assembly five-fingered robotic hand exoskeleton for rehabilitation. A single degree-of-freedom (DOF) linkage was designed to actuate each finger with 3 output links that correspond to the three phalanxes of the human finger. We used a parametric modelling approach that suits the dimensions of individual's hand. The fabrication of this dynamic model was achieved by printing the complete assembly including all the driving links, output links, and joints. We manufactured a prototype and developed real-time actuation and control. The reported unique linkage design, combined with parametric modelling and 3D printing technology, will pave the way for mass customization of active assistive and resistive hand exoskeletons.