Related Experiment Video

Updated: Mar 27, 2026
Measurement of Spatial Stability in Precision Grip
09:36

Measurement of Spatial Stability in Precision Grip

Published on: June 4, 2020

3.6K

Human precision manipulation workspace: Effects of object size and number of fingers used

Ian M Bullock, Thomas Feix, Aaron M Dollar

    Annual International Conference of the IEEE Engineering in Medicine and Biology Society. IEEE Engineering in Medicine and Biology Society. Annual International Conference
    |January 7, 2016
    PubMed

    Abstract:

    Precision manipulation, or moving small objects in the fingertips, is important for daily tasks such as writing and key insertion, as well as medically relevant tasks such as scalpel cuts and surgical teleoperation. While fingertip force coordination has been studied in some detail, few previous works have experimentally studied the kinematics of human precision manipulation with real objects. The present work focuses on studying the effects of varying object size and the number of fingers used on the resulting manipulation workspace, or range of motions that the object can be moved through. To study object size effects, seven bar-shaped objects ranging from 20 to 80 mm length were tested; after scaling object length to the equivalent for a 17.5 cm hand, the peak volume was obtained for 48-59 mm object length range (23% above average), and the minimum volume was obtained for the smallest 17-27 mm range (72% of average). 50 mm and 80 mm circular objects were used to study the effect of using different numbers of fingers; the five-finger manipulation volume dropped to less than half the two-finger volume (p<;0.001). We anticipate these results will be useful in designing devices such as hand held tools, as well as in designing protocols for effectively testing and rehabilitating hand function. Finally, the results can provide a benchmark for the manipulation capability of prosthetic hands.

    More Related Videos

    Estimation of Contact Regions Between Hands and Objects During Human Multi-Digit Grasping
    09:41

    Estimation of Contact Regions Between Hands and Objects During Human Multi-Digit Grasping

    Published on: April 21, 2023

    2.4K
    Frame-by-Frame Video Analysis of Idiosyncratic Reach-to-Grasp Movements in Humans
    10:51

    Frame-by-Frame Video Analysis of Idiosyncratic Reach-to-Grasp Movements in Humans

    Published on: January 15, 2018

    9.0K

    Related Experiment Videos

    Last Updated: Mar 27, 2026

    Measurement of Spatial Stability in Precision Grip
    09:36

    Measurement of Spatial Stability in Precision Grip

    Published on: June 4, 2020

    3.6K
    Estimation of Contact Regions Between Hands and Objects During Human Multi-Digit Grasping
    09:41

    Estimation of Contact Regions Between Hands and Objects During Human Multi-Digit Grasping

    Published on: April 21, 2023

    2.4K
    Frame-by-Frame Video Analysis of Idiosyncratic Reach-to-Grasp Movements in Humans
    10:51

    Frame-by-Frame Video Analysis of Idiosyncratic Reach-to-Grasp Movements in Humans

    Published on: January 15, 2018

    9.0K

    Related Concept Videos

    Muscles of the Forearm that Move the Hand and Fingers01:16

    Muscles of the Forearm that Move the Hand and Fingers

    3.0K
    The muscles of the forearm that move the wrist, hand, and digits are numerous and diverse. They can be classified into two groups based on their location and function — the anterior and posterior compartment muscles.
    Anterior Compartment
    The anterior compartment muscles originate from the humerus. They primarily function as flexors and are also known as flexor muscles. They typically insert on the carpals, metacarpals, and phalanges. The superficial layer includes the flexor carpi...
    3.0K
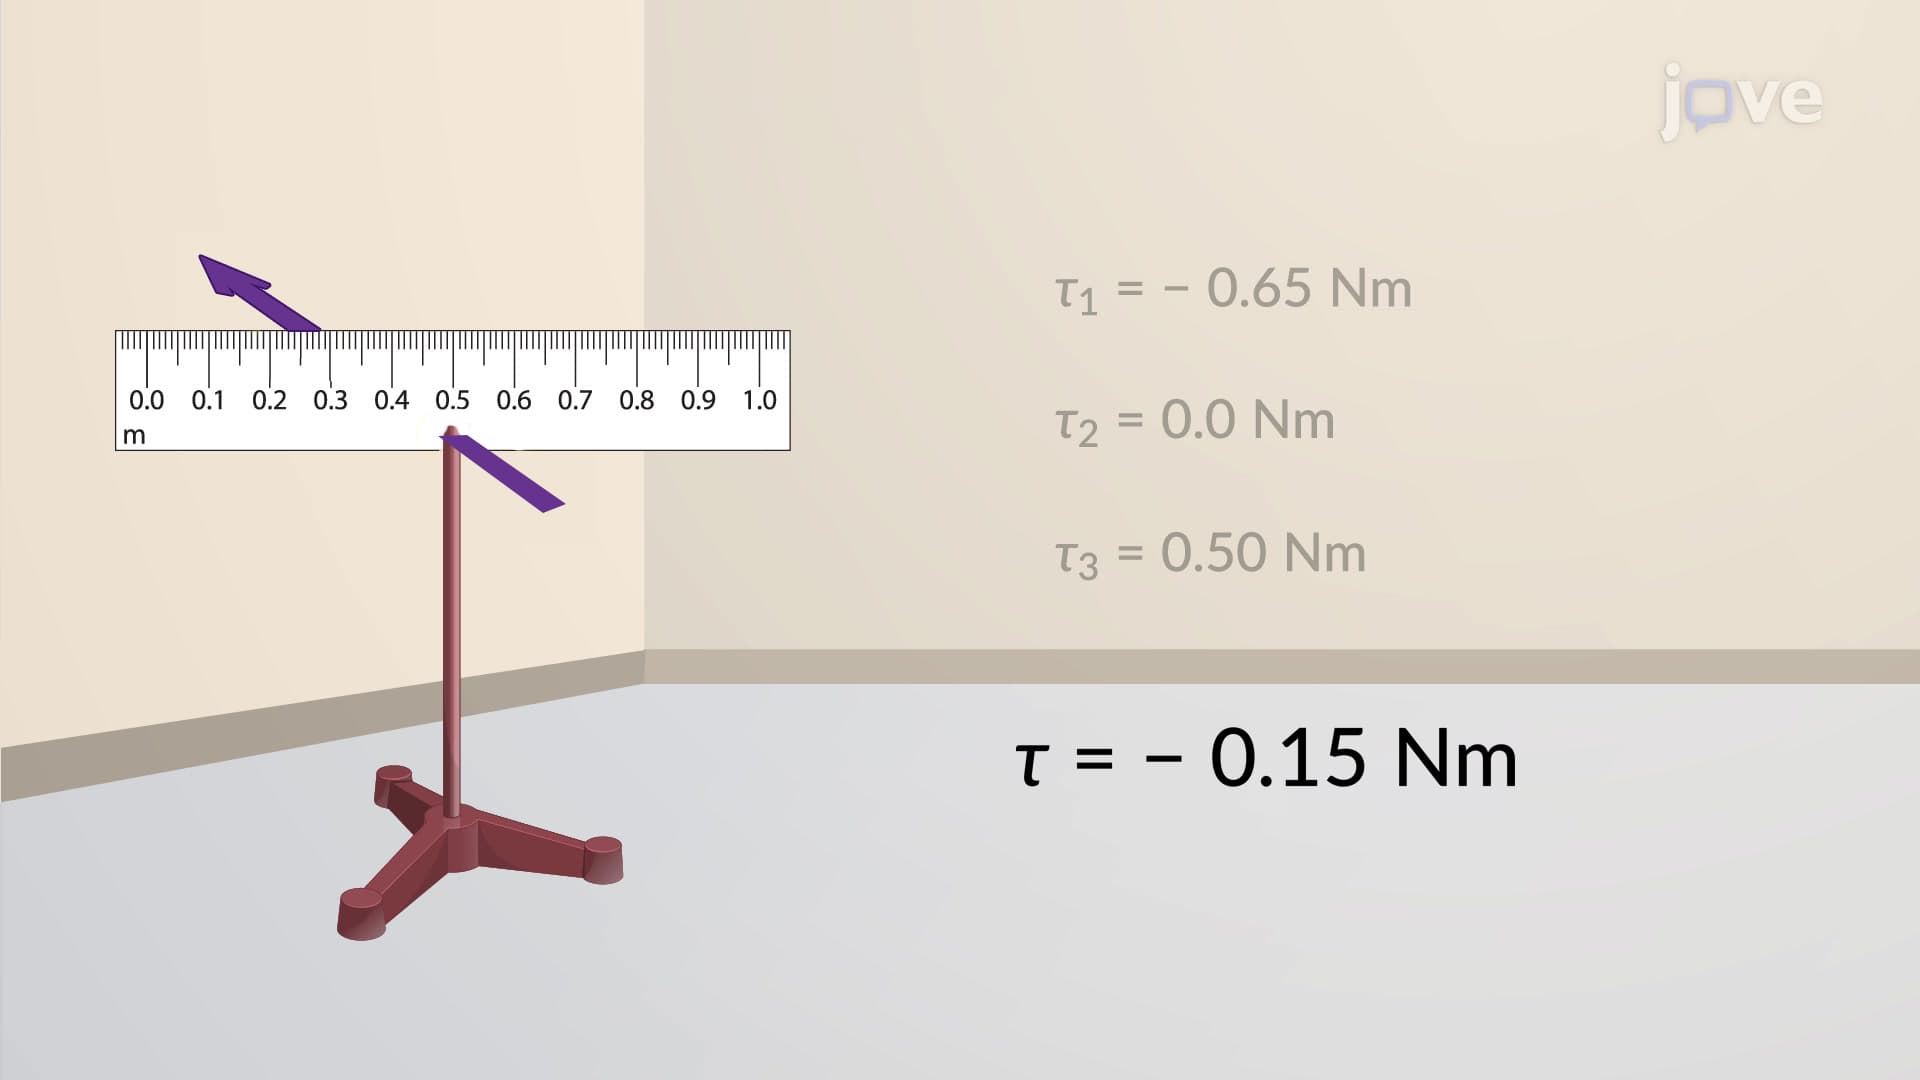
    Net Torque Calculations01:19

    Net Torque Calculations

    12.1K
    When a mechanic tries to remove a hex nut with a wrench, it is easier if the force is applied at the farthest end of the wrench handle. The lever arm is the distance from the pivot point (the hex nut in this case) to the person’s hand. If this distance is large, the torque is higher. Only the component of the force perpendicular to the lever arm contributes to the torque. Therefore, pushing the wrench perpendicular to the lever arm is more advantageous. If multiple people apply force to...
    12.1K

    Articles linked to this work by shared authors, journal, and citation graph.

    Improving the accuracy of automated labeling of specimen images datasets via a confidence-based process.

    PLoS computational biology·2025

    Forces for free: Vision-based contact force estimation with a compliant hand.

    Science robotics·2025

    Chain-based lattice printing for efficient robotically-assembled structures.

    Communications engineering·2024

    Robust whole-hand spatial manipulation via energy maps with caging, rolling, and sliding.

    Frontiers in robotics and AI·2023

    Trajectory Control-An Effective Strategy for Controlling Multi-DOF Upper Limb Prosthetic Devices.

    IEEE transactions on neural systems and rehabilitation engineering : a publication of the IEEE Engineering in Medicine and Biology Society·2022

    Manipulation for self-Identification, and self-Identification for better manipulation.

    Science robotics·2021

    Analysis of End-Tidal CO2 Variability During Plateau Waves Episodes: An Information Theoretic Approach.

    Annual International Conference of the IEEE Engineering in Medicine and Biology Society. IEEE Engineering in Medicine and Biology Society. Annual International Conference·2025

    AI and Tomosynthesis for Breast Cancer Molecular Subtyping: A step toward precision medicine.

    Annual International Conference of the IEEE Engineering in Medicine and Biology Society. IEEE Engineering in Medicine and Biology Society. Annual International Conference·2025

    Towards Sustainable Protein Recovery from Biological Waste: Assessing Polyethersulfone-based Microfiltration.

    Annual International Conference of the IEEE Engineering in Medicine and Biology Society. IEEE Engineering in Medicine and Biology Society. Annual International Conference·2025

    Analysis of the cardiovascular response to standardized polymicrobial peritonitis experimental model.

    Annual International Conference of the IEEE Engineering in Medicine and Biology Society. IEEE Engineering in Medicine and Biology Society. Annual International Conference·2025

    Automated Wrist Ultrasound Image Bone Enhancement and Segmentation Using Deep Learning.

    Annual International Conference of the IEEE Engineering in Medicine and Biology Society. IEEE Engineering in Medicine and Biology Society. Annual International Conference·2025

    A Deep Learning approach for Depressive Symptoms assessment in Parkinson's disease patients using facial videos.

    Annual International Conference of the IEEE Engineering in Medicine and Biology Society. IEEE Engineering in Medicine and Biology Society. Annual International Conference·2025

    Beyond ER-Golgi trafficking: unconventional protein secretion as a new design frontier for synthetic secretion switches in mammalian cells.

    Communications biology·2026

    Soft bioelectronics for wireless drug delivery: programmable, minimally invasive and closed-loop therapeutics.

    npj soft matter·2026

    Interlimb differences in reach-to-grasp coordination under goal- and dynamics-related perturbations.

    Journal of neurophysiology·2026

    Locus-specific rewriting of DNA methylation in mammalian cells.

    Current opinion in chemical biology·2026

    Techniques - Single keyhole puncture microsurgical vasovasostomy.

    Canadian Urological Association journal = Journal de l'Association des urologues du Canada·2026

    Comparison of Visual Feedback Conditions While Learning a Redundant Novel Visuomotor Task.

    Journal of motor behavior·2026
    See all related articles
    JoVE
    x logofacebook logolinkedin logoyoutube logo
    ABOUT JoVE
    OverviewLeadershipBlogJoVE Help Center
    AUTHORS
    Publishing ProcessEditorial BoardScope & PoliciesPeer ReviewFAQSubmit
    LIBRARIANS
    TestimonialsSubscriptionsAccessResourcesLibrary Advisory BoardFAQ
    RESEARCH
    JoVE JournalMethods CollectionsJoVE Encyclopedia of ExperimentsArchive
    EDUCATION
    JoVE CoreJoVE BusinessJoVE Science EducationJoVE Lab ManualFaculty Resource CenterFaculty Site
    Terms & Conditions of Use
    Privacy Policy
    Policies
    Jove
    Visualize
    Contact Us