Related Experiment Video
Updated: Mar 27, 2026
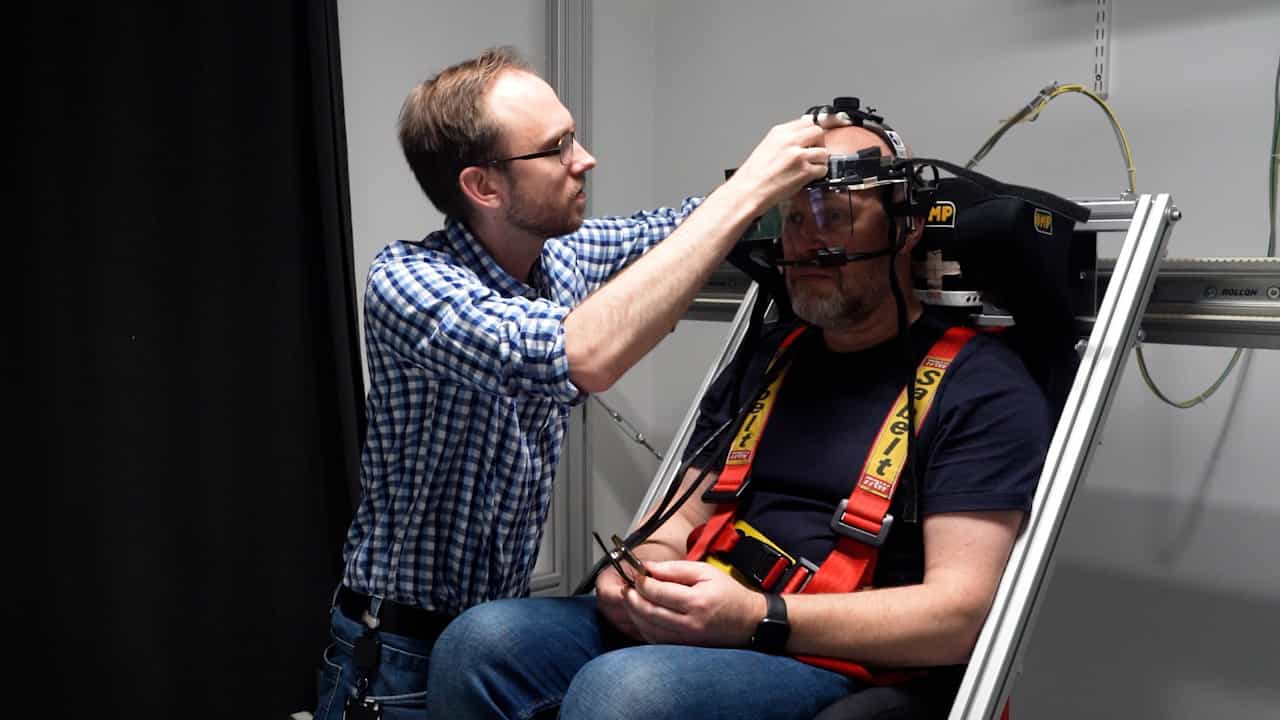

Using Eye-tracking to Assess the Relative Importance of Visual and Vestibular Input to Subcortical Motion Processing in the Roll Plane
Published on: August 22, 2025
The influence of yaw motion on the perception of active vs passive visual curvilinear displacement
Florian Savona1,2, Anca Melania Stratulat2, Vincent Roussarie2
1Aix Marseille University, CNRS, ISM UMR 7287, 13288, Marseille, France.

Abstract:
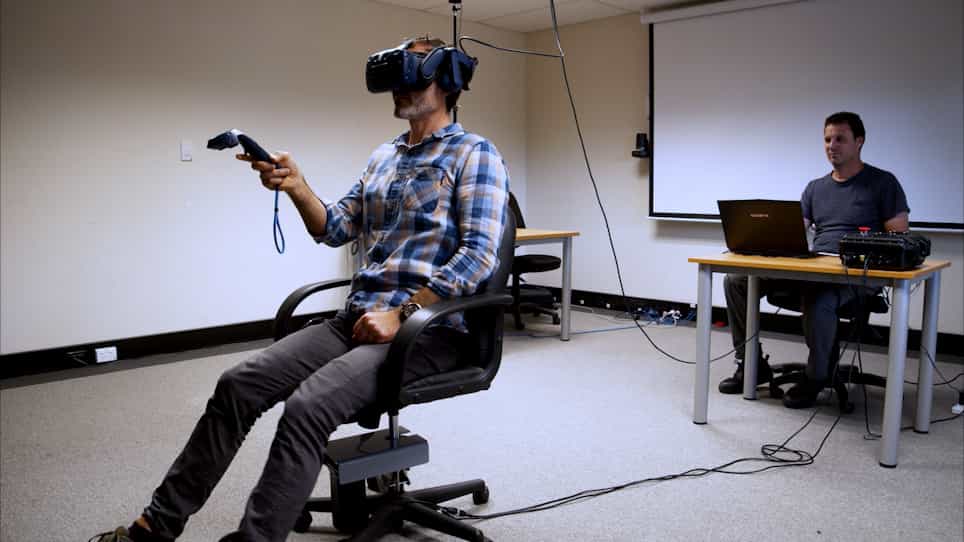
Self-motion perception, which partly determines the realism of dynamic driving simulators, is based on multisensory integration. However, it remains unclear how the brain integrates these cues to create adequate motion perception, especially for curvilinear displacements. In the present study, the effect of visual, inertial and visuo-inertial cues (concordant or discordant bimodal cues) on self-motion perception was analyzed. Subjects were asked to evaluate (externally produced) or produce (self-controlled) curvilinear displacements as accurately as possible. The results show systematic overestimation of displacement, with better performance for active subjects than for passive ones. Furthermore, it was demonstrated that participants used unimodal or bimodal cues differently in performing their activity. When passive, subjects systematically integrated visual and inertial cues even when discordant, but with weightings that depended on the dynamics. On the contrary, active subjects were able to reject the inertial cue when the discordance became too high, producing self-motion perception on the basis of more reliable information. Thereby, multisensory integration seems to follow a non-linear integration model of, i.e., the cues' weight changes with the cue reliability and/or the intensity of the stimuli, as reported by previous studies. These results represent a basis for the adaptation of motion cueing algorithms are developed for dynamic driving simulators, by taking into account the dynamics of simulated motion in line with the status of the participants (driver or passenger).
Related Concept Videos
 01:23
Curvilinear Motion: Rectangular Components
As the car advances, its position evolves over time. Quantifying the car's velocity involves computing the...
 01:27
Curvilinear Motion: Normal and Tangential Components
The positive direction of the t-axis aligns with the increasing position of the car along the curved path, denoted by the unit vector ut. Simultaneously, the n-axis, perpendicular to the t-axis, dissects the curved path into differential arc segments, each forming the arc of a circle with a radius of...
 01:27
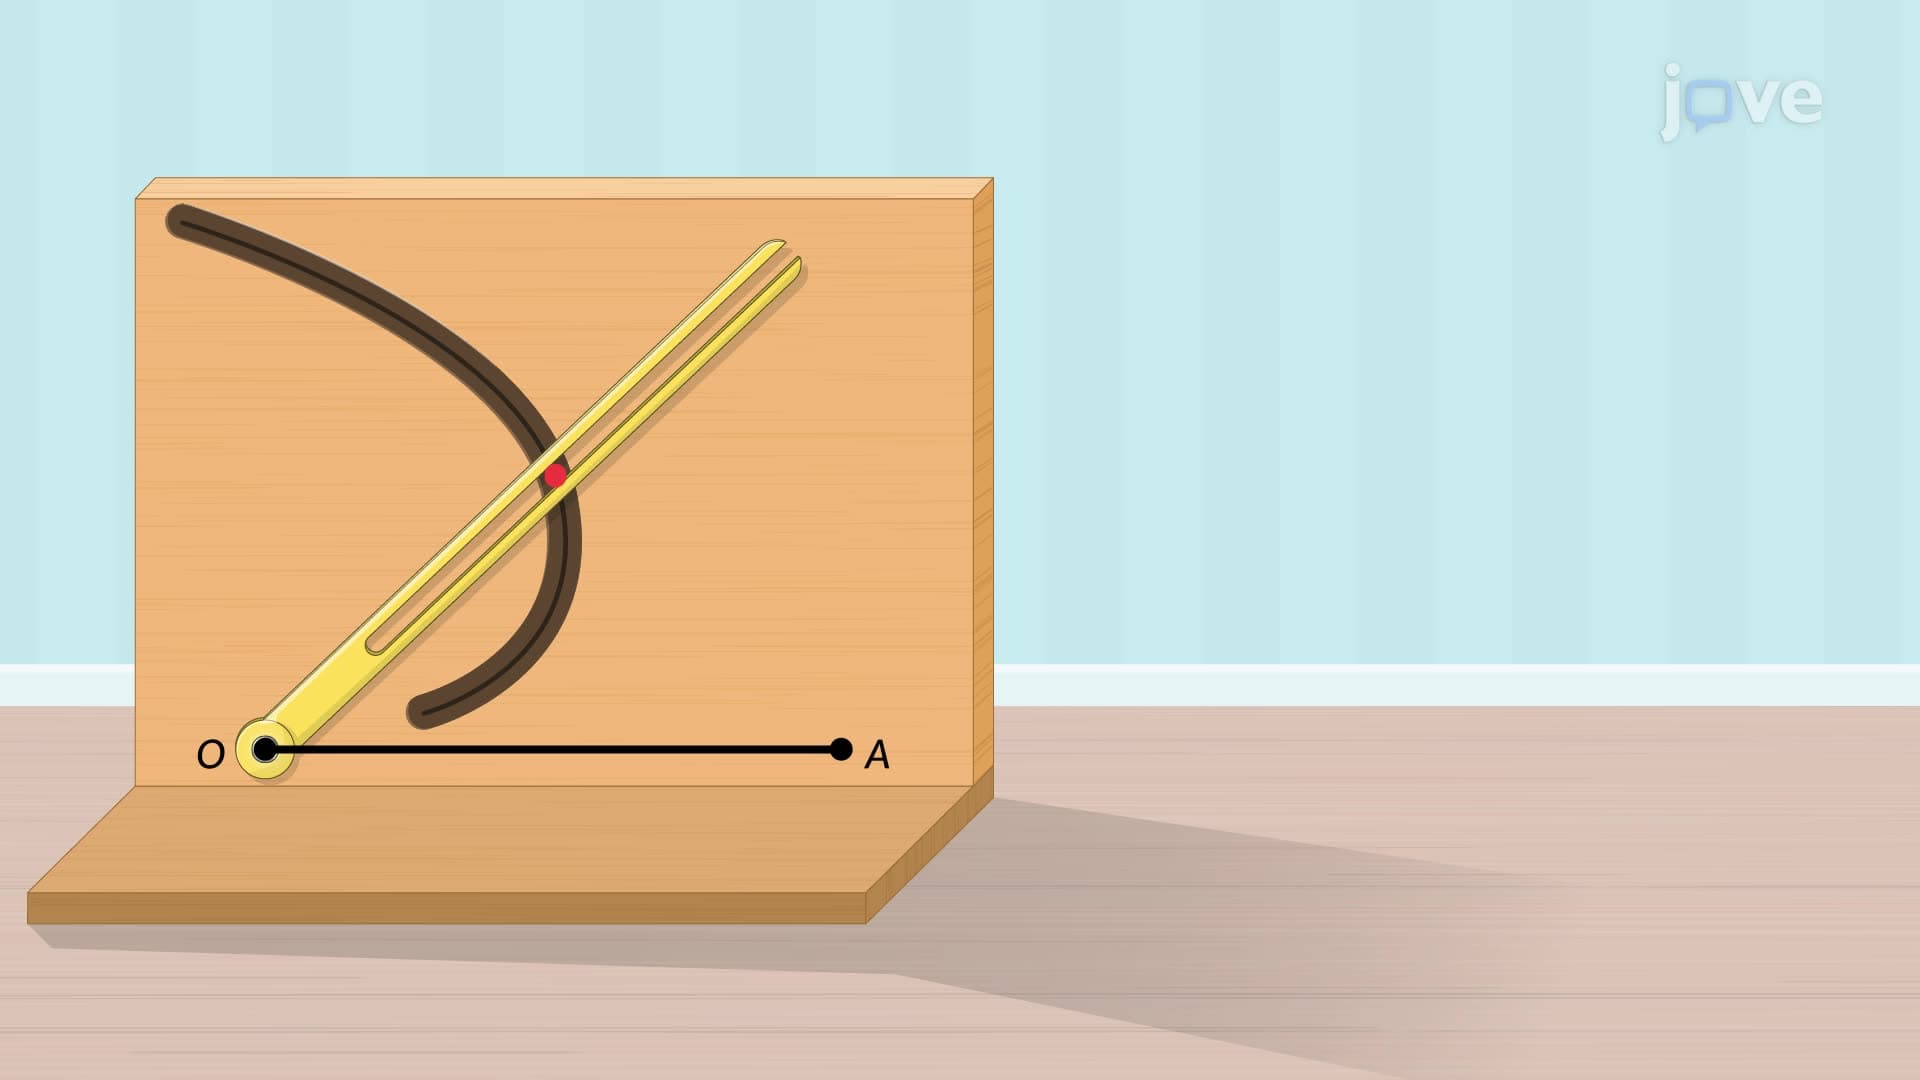
Curvilinear Motion: Polar Coordinates
The particle's location is described using a unit vector along the radial direction. Deriving the particle's position...
 01:25
Relative Motion Analysis using Rotating Axes
However, to express the relative position of point B relative to point A, an additional frame of reference, denoted as x'y', is necessary. This additional frame not only translates but also rotates relative to the fixed frame, making it...
 01:15
Depth Perception and Spatial Vision
 01:22
Relative Motion Analysis using Rotating Axes - Acceleration
Time differentiation is...