Affordance-based perception-action dynamics: A model of visually guided braking
Related Experiment Video
Updated: Mar 25, 2026
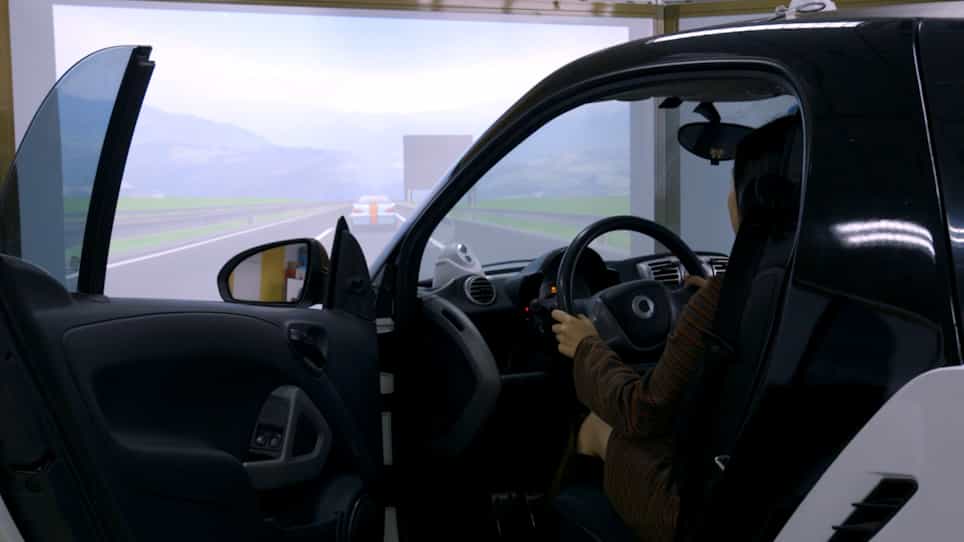
Tactile Vibrating Toolkit and Driving Simulation Platform for Driving-Related Research
Published on: December 18, 2020
Henry S Harrison1, Michael T Turvey1, Till D Frank1
1Center for the Ecological Study of Perception and Action, Department of Psychological Sciences, University of Connecticut.

Abstract:
Behavioral dynamics is a framework for understanding adaptive behavior as arising from the self-organizing interaction between animal and environment. The methods of nonlinear dynamics provide a language for describing behavior that is both stable and flexible. Behavioral dynamics has been criticized for ignoring the animal's sensitivity to its own capabilities, leading to the development of an alternative framework: affordance-based control. Although it is theoretically sound and empirically motivated, affordance-based control has resisted characterization in terms of nonlinear dynamics. Here, we provide a dynamical description of affordance-based control, extending behavioral dynamics to meet its criticisms. We propose a general modeling strategy consistent with both theories. We use visually guided braking as a representative behavior and construct a novel dynamical model. This model demonstrates the possibility of understanding visually guided action as respecting the limits of the actor's capabilities, while still being guided by informational variables associated with desired states of affairs. In addition to such "hard" constraints on behavior, our framework allows for the influence of "soft" constraints such as preference and comfort, opening a new area of inquiry in perception-action dynamics.

Related Concept Videos
 01:17
Rolling Resistance: Problem Solving
 01:26
Kinetic Friction
 01:05
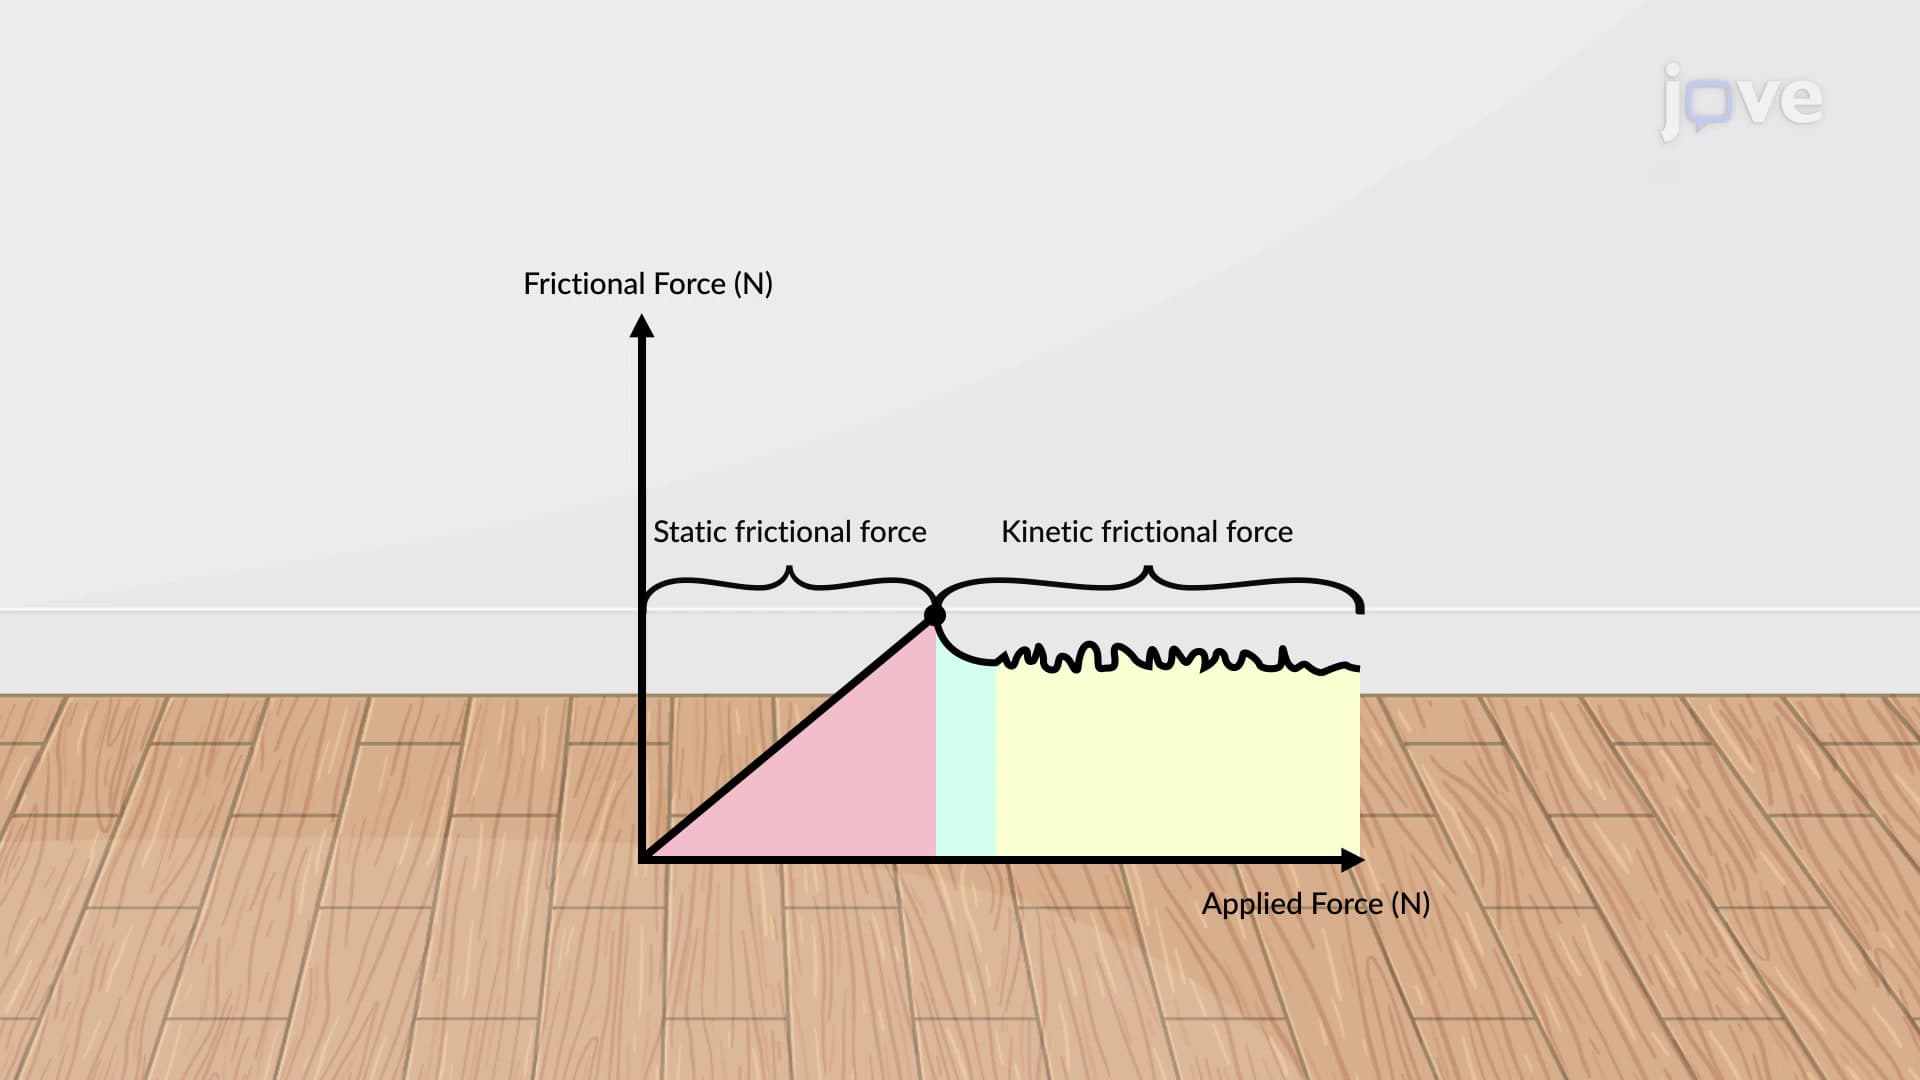
Static and Kinetic Frictional Force
However, if two systems are in contact and are stationary relative to one...
 01:18
Hierarchy of Motor Control
 01:28
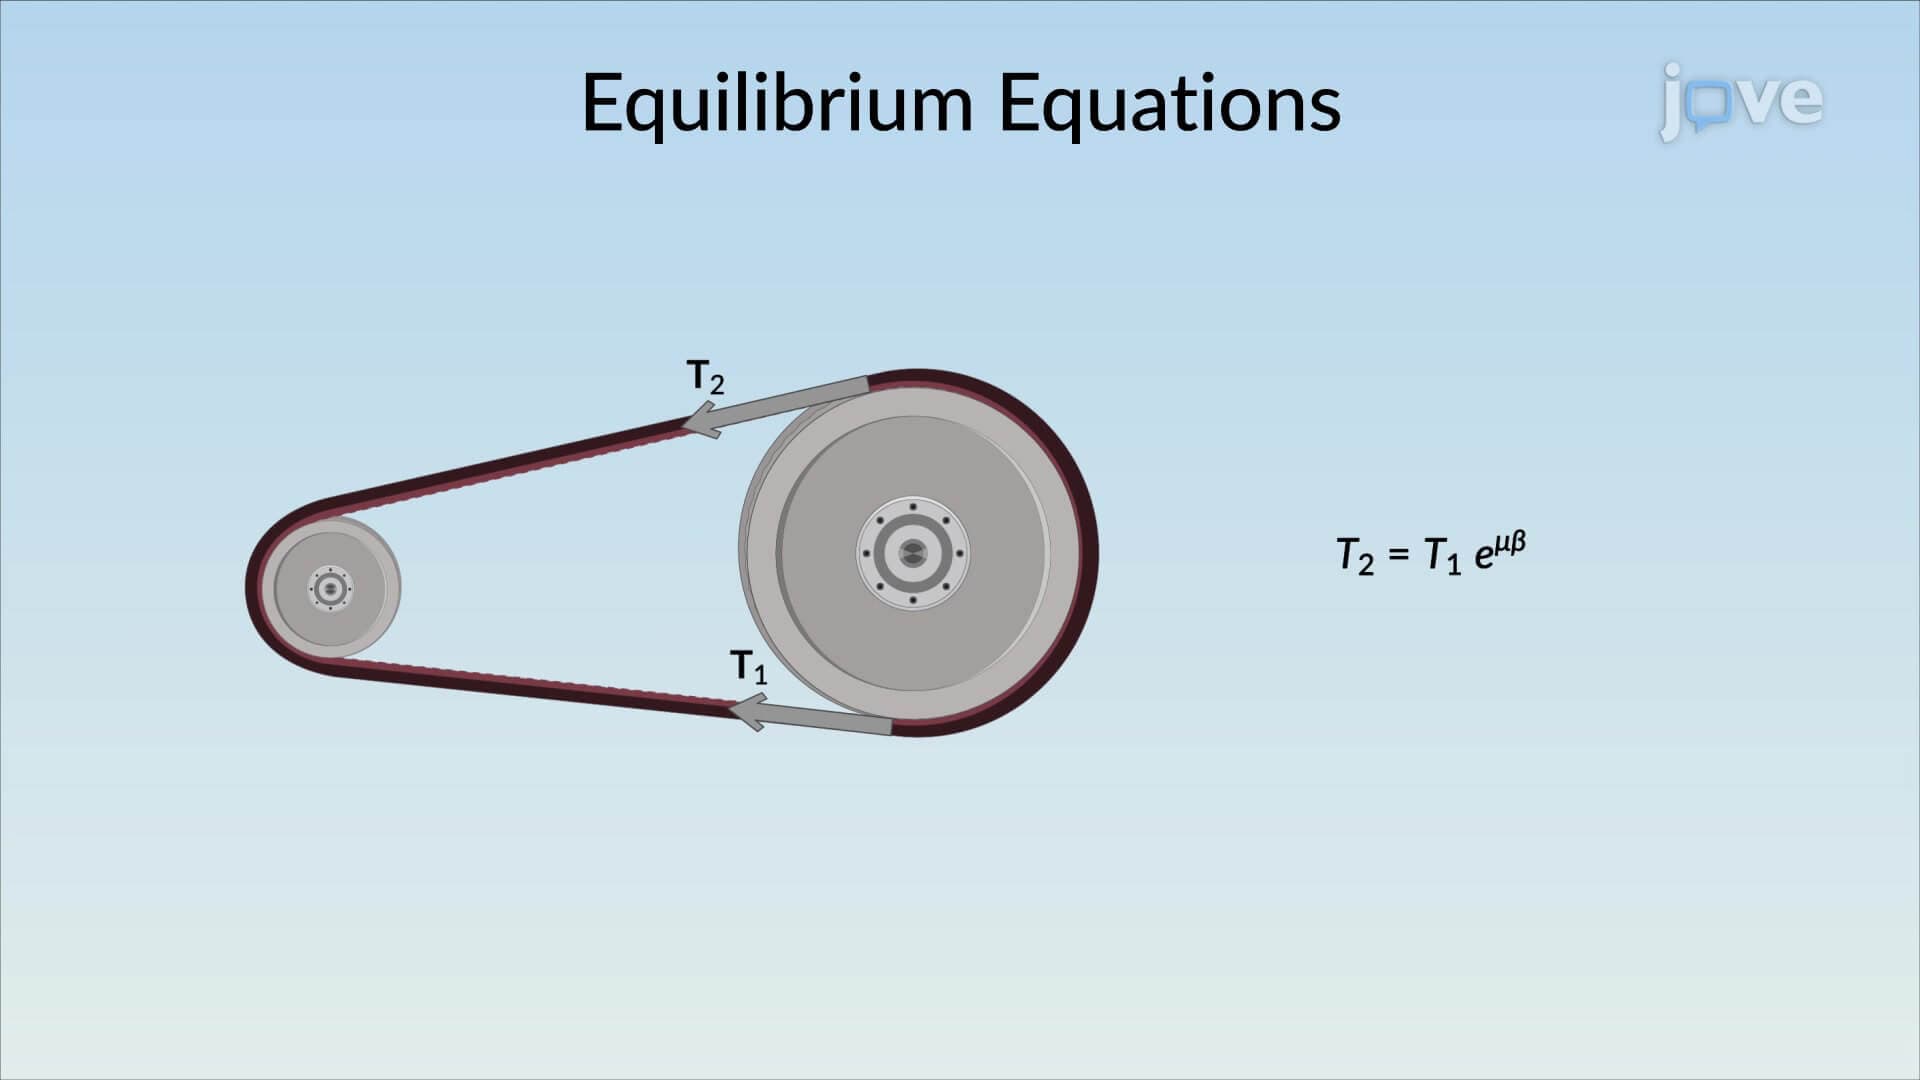
Frictional Forces on Flat Belts
 01:22
Relative Motion Analysis using Rotating Axes - Acceleration
Time differentiation is...