

A Digitalized Gyroscope System Based on a Modified Adaptive Control Method
Dunzhu Xia1, Yiwei Hu2, Peizhen Ni3
1Key Laboratory of Micro-inertial Instrument and Advanced Navigation Technology, Ministry of Education, School of Instrument Science and Engineering, Southeast University, Nanjing 210096, China. 101010203@seu.edu.cn.

Abstract:
In this work we investigate the possibility of applying the adaptive control algorithm to Micro-Electro-Mechanical System (MEMS) gyroscopes. Through comparing the gyroscope working conditions with the reference model, the adaptive control method can provide online estimation of the key parameters and the proper control strategy for the system. The digital second-order oscillators in the reference model are substituted for two phase locked loops (PLLs) to achieve a more steady amplitude and frequency control. The adaptive law is modified to satisfy the condition of unequal coupling stiffness and coupling damping coefficient. The rotation mode of the gyroscope system is considered in our work and a rotation elimination section is added to the digitalized system. Before implementing the algorithm in the hardware platform, different simulations are conducted to ensure the algorithm can meet the requirement of the angular rate sensor, and some of the key adaptive law coefficients are optimized. The coupling components are detected and suppressed respectively and Lyapunov criterion is applied to prove the stability of the system. The modified adaptive control algorithm is verified in a set of digitalized gyroscope system, the control system is realized in digital domain, with the application of Field Programmable Gate Array (FPGA). Key structure parameters are measured and compared with the estimation results, which validated that the algorithm is feasible in the setup. Extra gyroscopes are used in repeated experiments to prove the commonality of the algorithm.
More Related Videos
 06:45
Design and Application of a Fault Detection Method Based on Adaptive Filters and Rotational Speed Estimation for an Electro-Hydrostatic Actuator
Published on: October 28, 2022
 10:51
An Experimental Platform to Study the Closed-loop Performance of Brain-machine Interfaces
Published on: March 10, 2011
Related Concept Videos
 01:02
Gyroscope
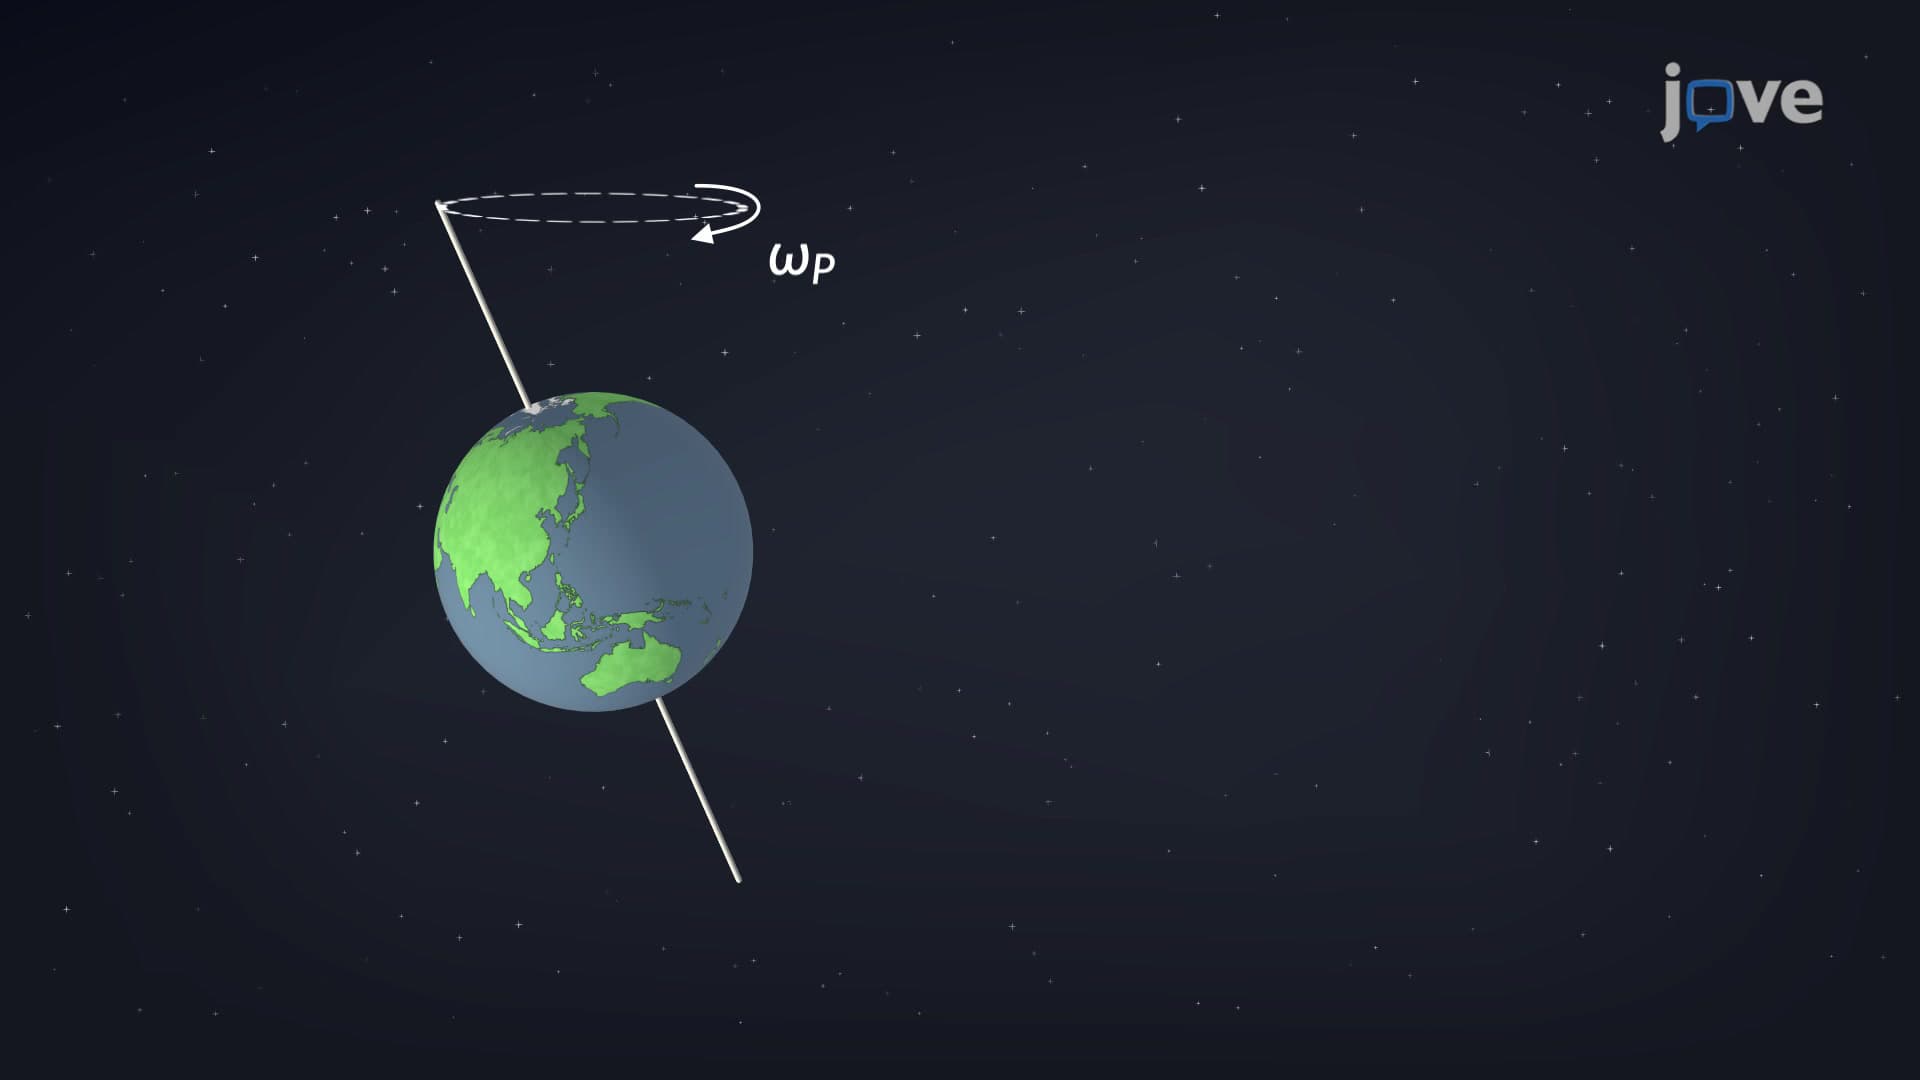 01:24
Gyroscope: Precession
 01:10
Control Systems
At the heart...
 01:26
Feedback control systems
Linear feedback systems are theoretical models that simplify analysis and design. These systems operate under the principle that their output is directly proportional to their input within certain ranges. For instance, an amplifier in a control system behaves linearly as long as the input signal remains within a specific range. However, most physical systems exhibit inherent nonlinearity...
 01:07
Time-Domain Interpretation of PD Control
Consider the example of control of motor torque. Initially, a positive...
 01:17
Open and closed-loop control systems
An open-loop control system operates without feedback from the output. It consists of two primary elements: the controller and the controlled process. The controller receives an input signal...