Related Experiment Video
Updated: Mar 24, 2026
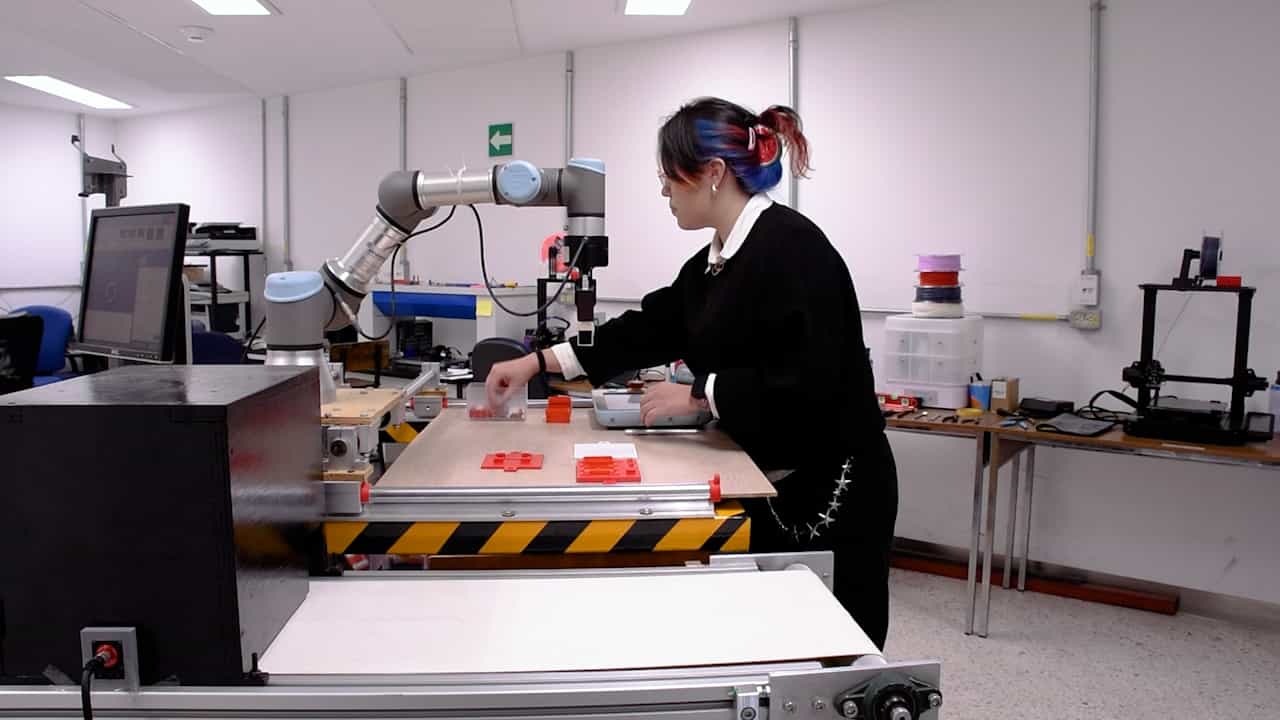

Simulation of a Scaled Assembly Process with Collaboration of a Robotic Arm and Monitoring through a Vision System for Quality Control
Published on: August 29, 2025
Robot Guidance Using Machine Vision Techniques in Industrial Environments: A Comparative Review
Luis Pérez1, Íñigo Rodríguez2, Nuria Rodríguez3
1Fundación PRODINTEC, Avda. Jardín Botánico 1345, 33203 Gijón (Asturias), Spain. lcp@prodintec.com.

Abstract:
In the factory of the future, most of the operations will be done by autonomous robots that need visual feedback to move around the working space avoiding obstacles, to work collaboratively with humans, to identify and locate the working parts, to complete the information provided by other sensors to improve their positioning accuracy, etc. Different vision techniques, such as photogrammetry, stereo vision, structured light, time of flight and laser triangulation, among others, are widely used for inspection and quality control processes in the industry and now for robot guidance. Choosing which type of vision system to use is highly dependent on the parts that need to be located or measured. Thus, in this paper a comparative review of different machine vision techniques for robot guidance is presented. This work analyzes accuracy, range and weight of the sensors, safety, processing time and environmental influences. Researchers and developers can take it as a background information for their future works.


