Related Experiment Video
Updated: Mar 24, 2026

Four-Dimensional CT Analysis Using Sequential 3D-3D Registration
Published on: November 23, 2019
Non-Iterative Rigid 2D/3D Point-Set Registration Using Semidefinite Programming

Abstract:
We describe a convex programming framework for pose estimation in 2D/3D point-set registration with unknown point correspondences. We give two mixed-integer nonlinear program (MINLP) formulations of the 2D/3D registration problem when there are multiple 2D images, and propose convex relaxations for both the MINLPs to semidefinite programs that can be solved efficiently by interior point methods. Our approach to the 2D/3D registration problem is non-iterative in nature as we jointly solve for pose and correspondence. Furthermore, these convex programs can readily incorporate feature descriptors of points to enhance registration results. We prove that the convex programs exactly recover the solution to the MINLPs under certain noiseless condition. We apply these formulations to the registration of 3D models of coronary vessels to their 2D projections obtained from multiple intra-operative fluoroscopic images. For this application, we experimentally corroborate the exact recovery property in the absence of noise and further demonstrate robustness of the convex programs in the presence of noise.
More Related Videos
 02:09
Multi-modal Pulmonary Imaging: Using Complementary Information from CT and Hyperpolarized 129Xe MRI to Evaluate Lung Structure-Function
Published on: April 12, 2024
 09:41
A Pipeline for 3D Multimodality Image Integration and Computer-assisted Planning in Epilepsy Surgery
Published on: May 20, 2016
Related Concept Videos
 01:16
Statically Indeterminate Problem Solving
 01:19
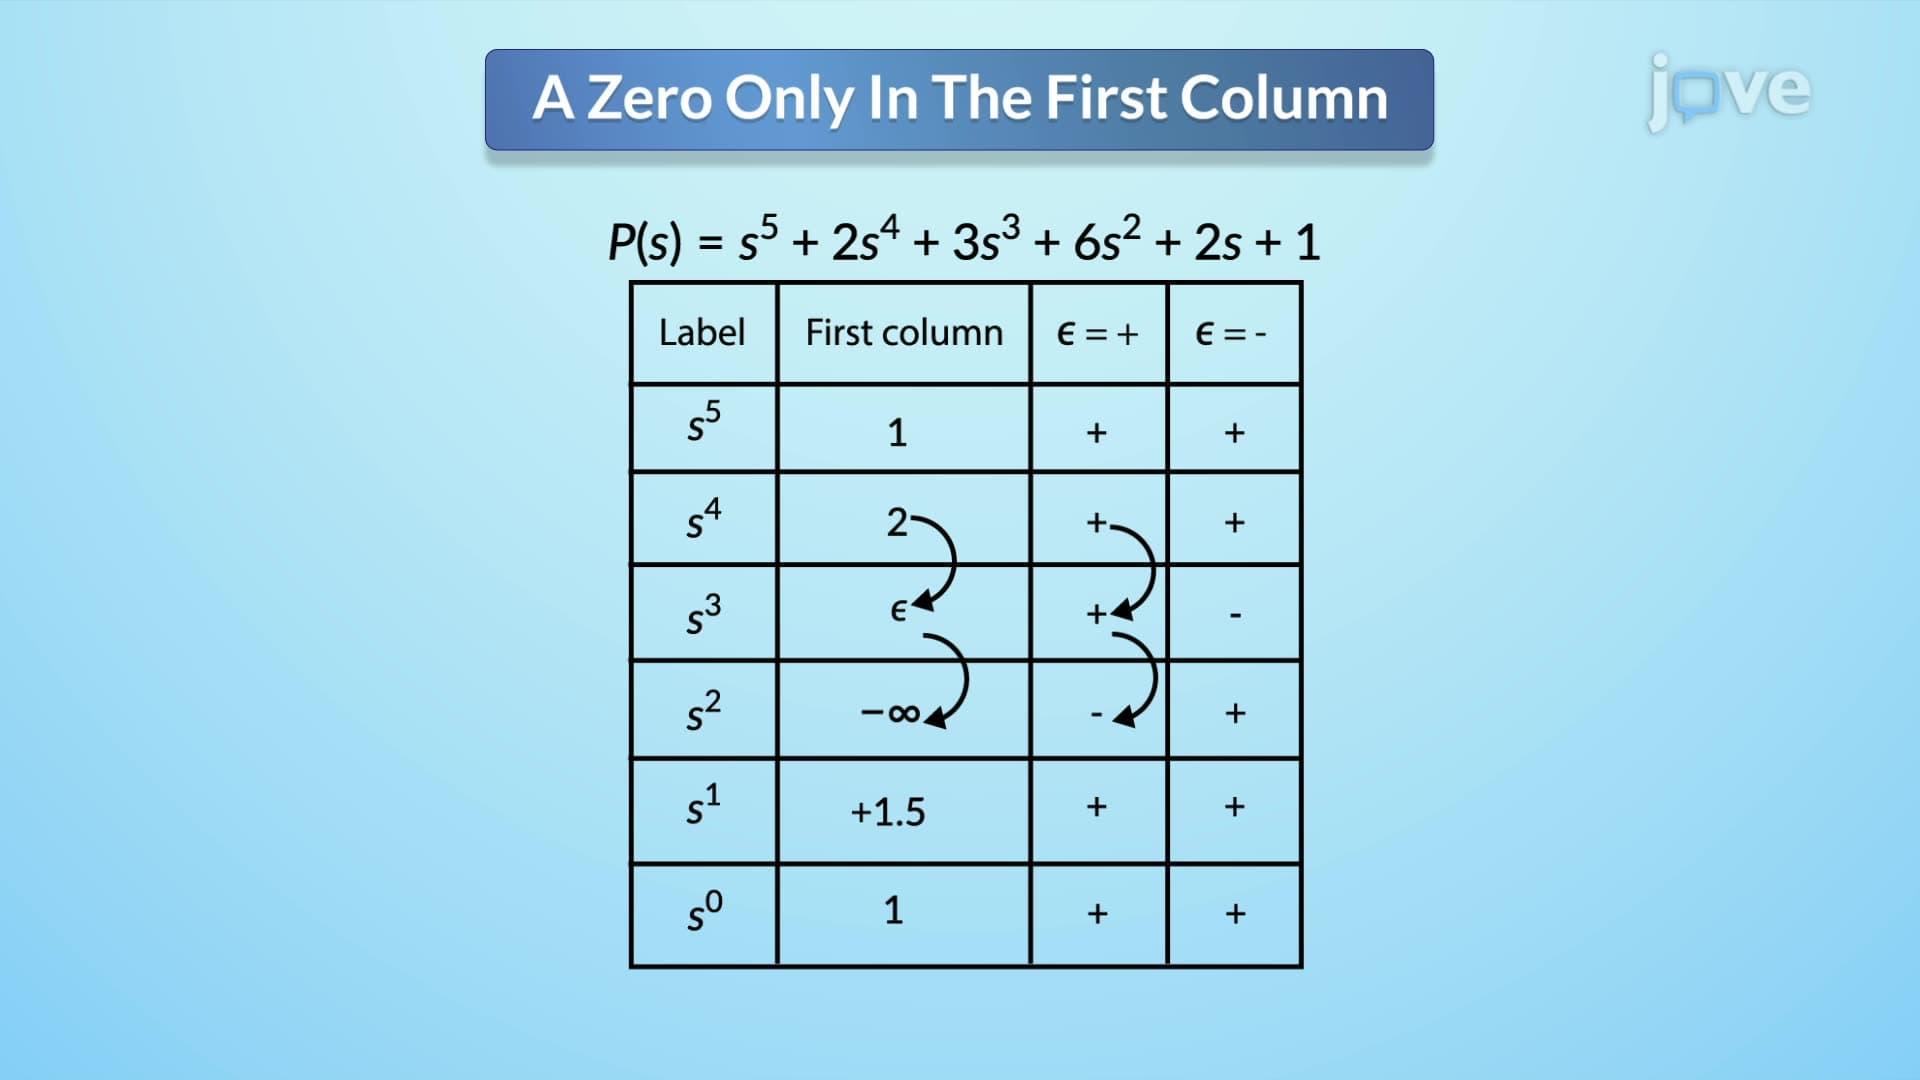
Routh-Hurwitz Criterion II
The first scenario occurs when a singular zero appears in the first column of the Routh table. This situation creates a division by zero issues. To resolve this, a small positive or negative number, denoted as epsilon (∈), is substituted for the zero. The stability analysis proceeds by assuming a sign for ∈. If ∈ is positive, any sign change in the first...
 01:26
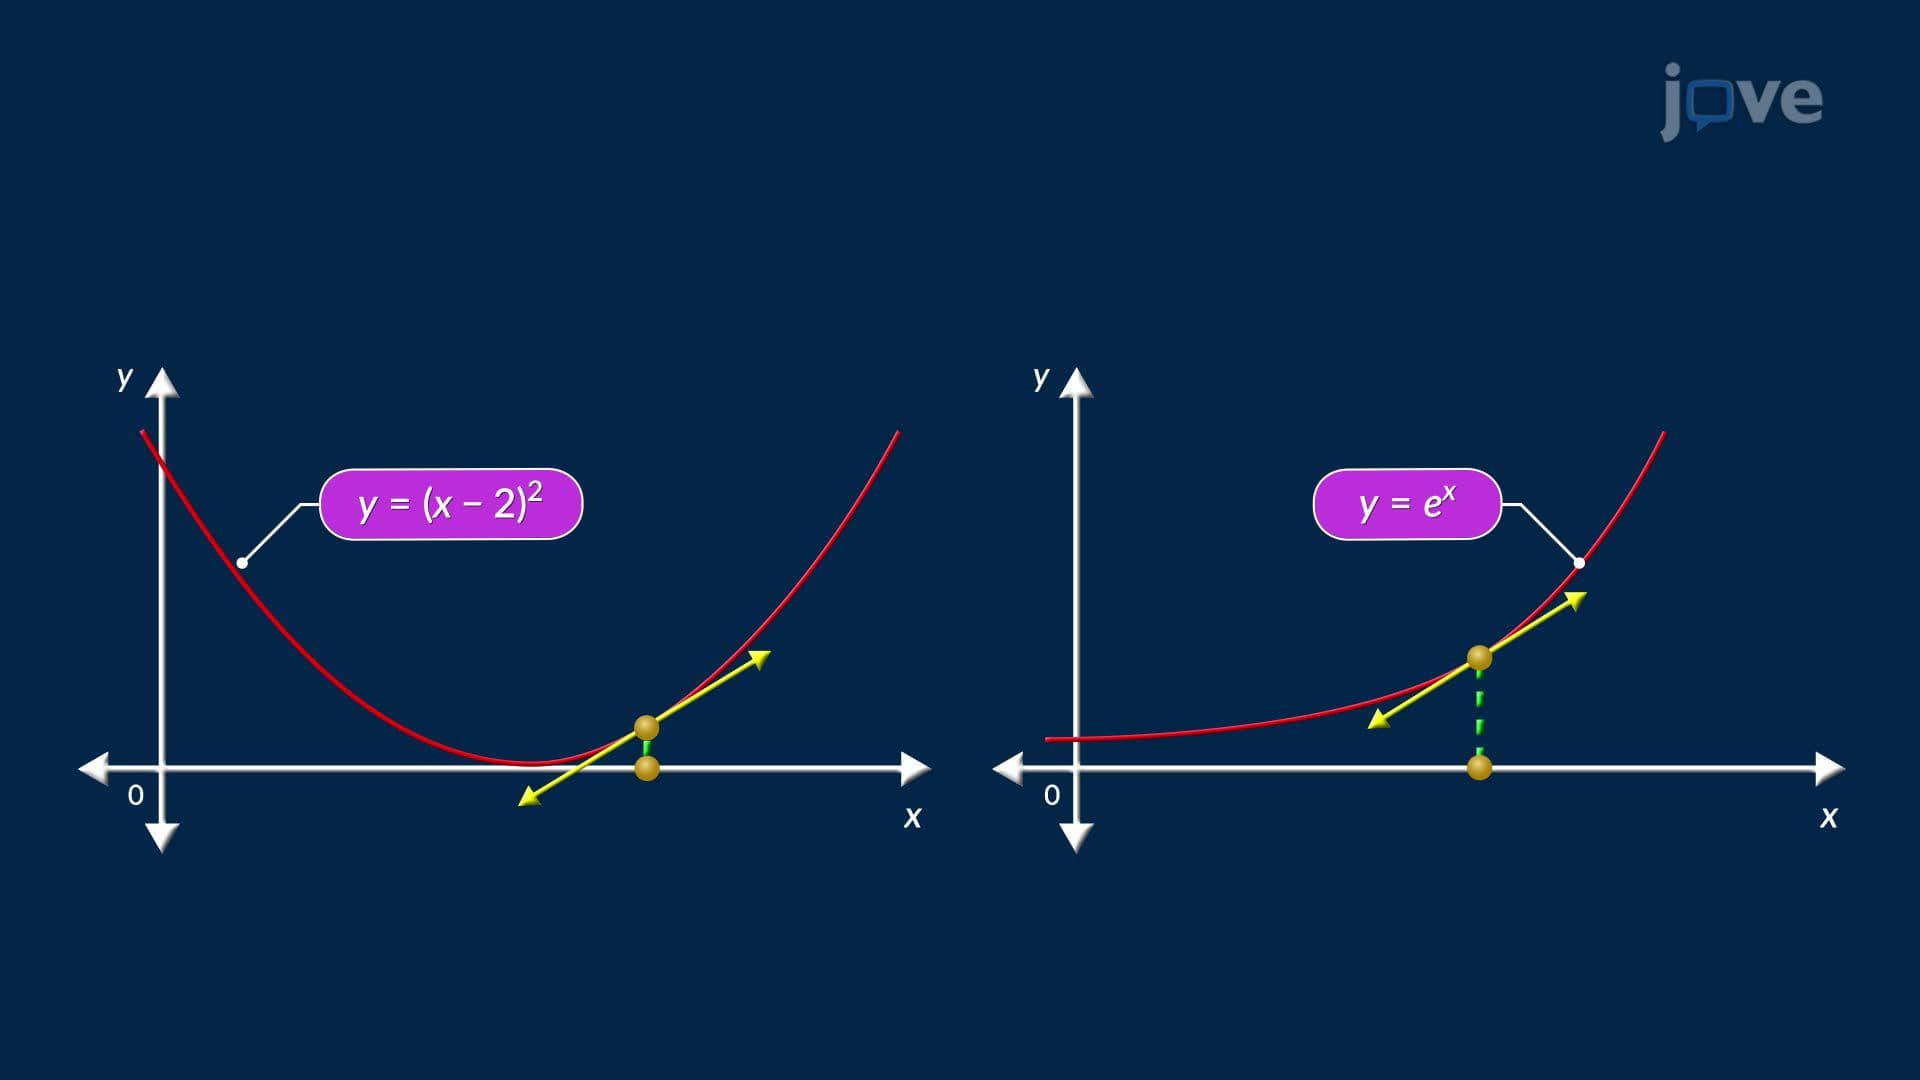
Linearization and Approximation
 01:15
Routh-Hurwitz Criterion I
To apply the Routh-Hurwitz criterion, a Routh table is constructed. The table's rows are labeled with powers of the complex frequency variable s, starting from the...
 01:21
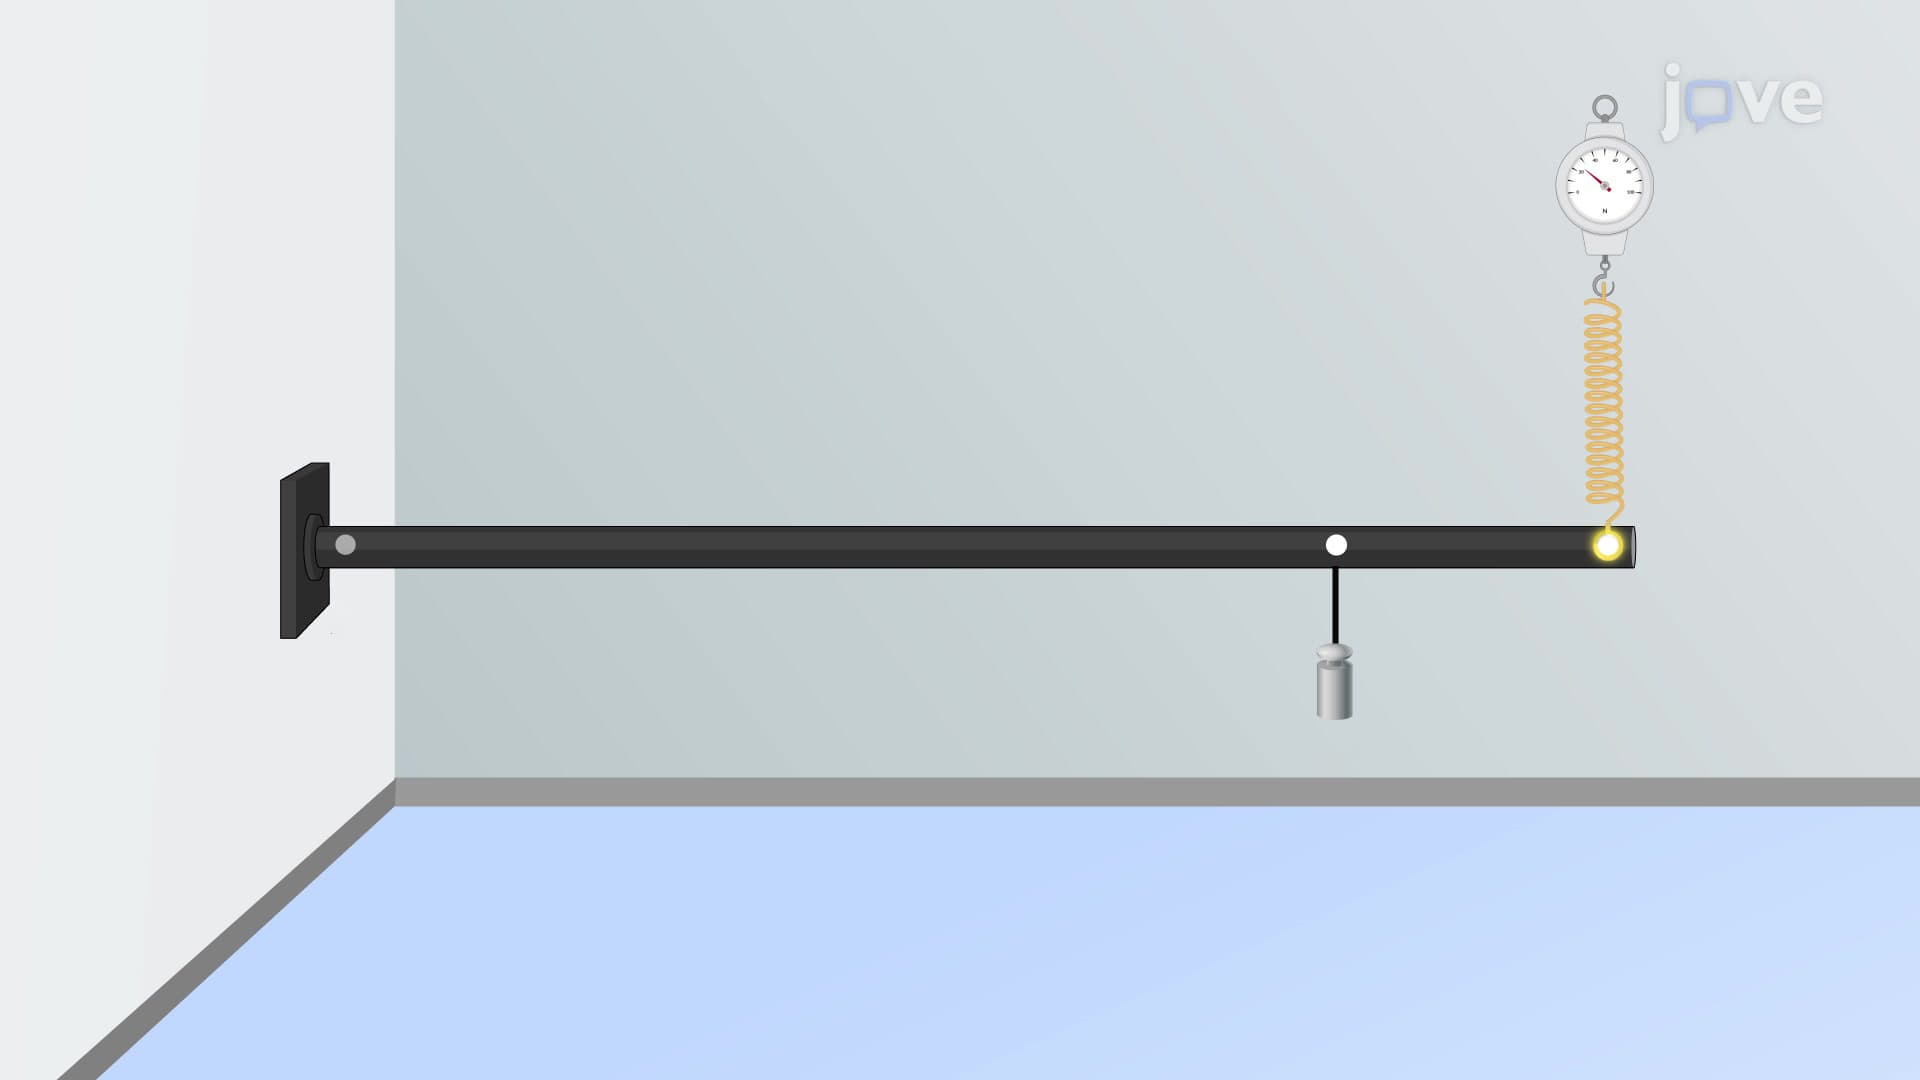
Rigid Body Equilibrium Problems - II
Consider two children sitting on a seesaw, which has negligible mass. The first child has a mass (m1) of 26 kg and sits at point A, which is 1.6 meters (r1) from the pivot point B; the second child has a mass (m2) of 32 kg and sits at point C. How far from the pivot point B should the second child sit (r2) to balance the seesaw?
 01:23
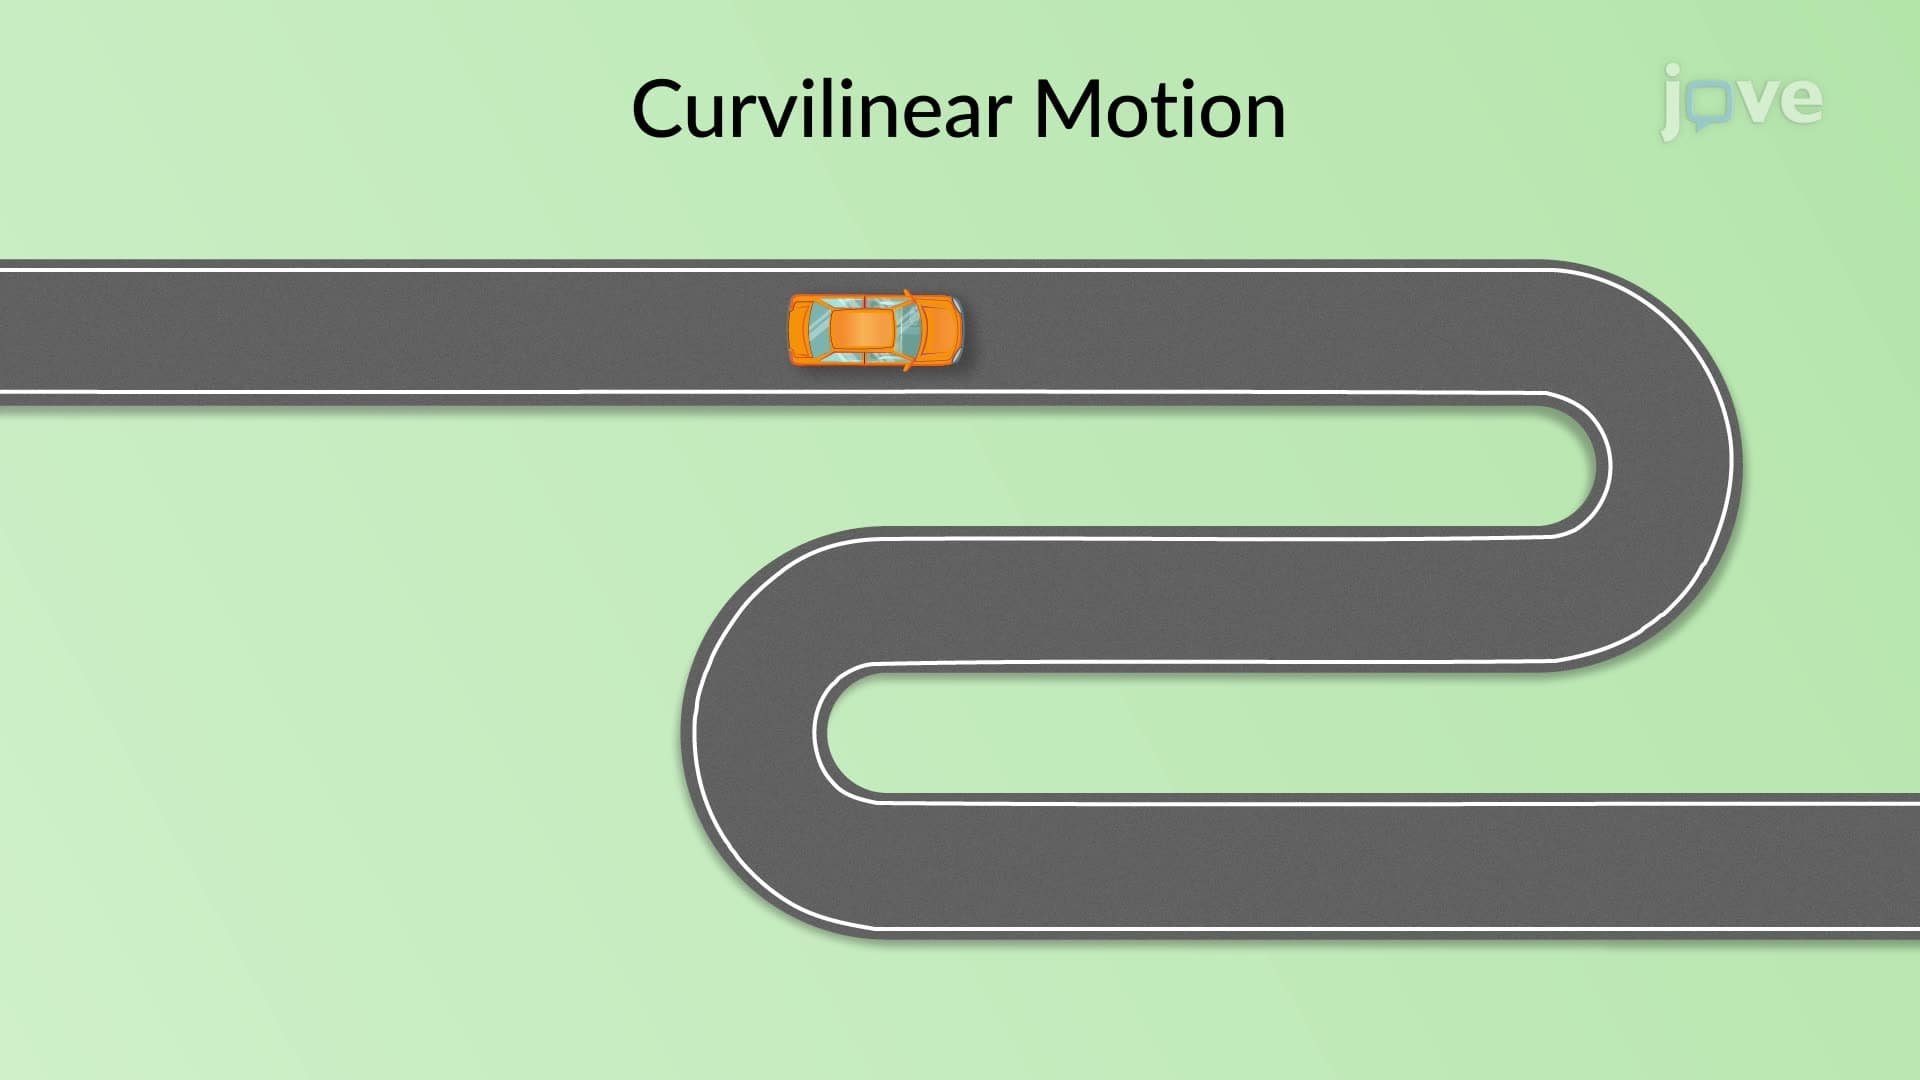
Curvilinear Motion: Rectangular Components
As the car advances, its position evolves over time. Quantifying the car's velocity involves computing the...